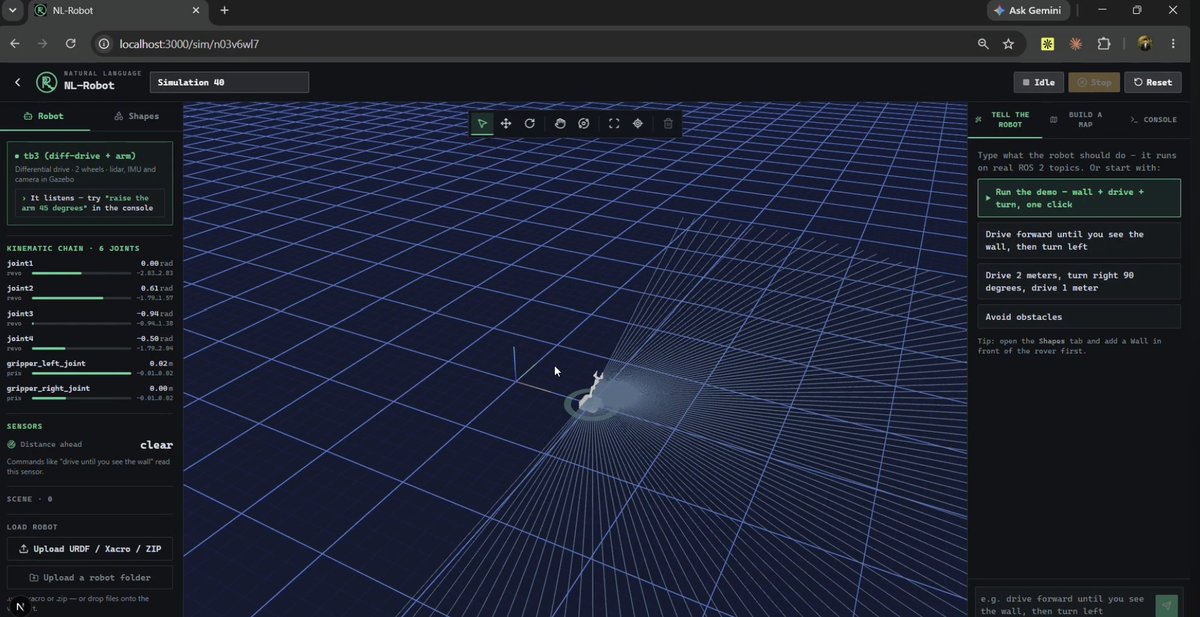
We built a "GPT-4 for ROS" @HackTheNorth... at least we attempted to😂.
> We built a chatbot that turns plain English into robot motion
> Upload your own URDF/Xacro files + test in simulation
Thank you to my teammates @mubarkparacha , Vanessa, and Ahmad. Had a lot of fun making this🙏. Shoutout to everyone I met at HTN as well!
https://t.co/nMg6reCVxh
My First Project with ROS! I built TeleARM, an autonomous driving forklift that can avoid obstacles using a LiDAR and sort boxes by colour using an RGB camera to their respective route markers. Mapped everything out with SLAM!
I built VentBuddy! An AI-speaking "therapist" that listens to your problems and gives you advice on how to deal with them. It provides a document report at the end to summarize the key moments of the chat! Uses LangChain, Flask, and speech recognition.
https://t.co/82ReS2RFWw
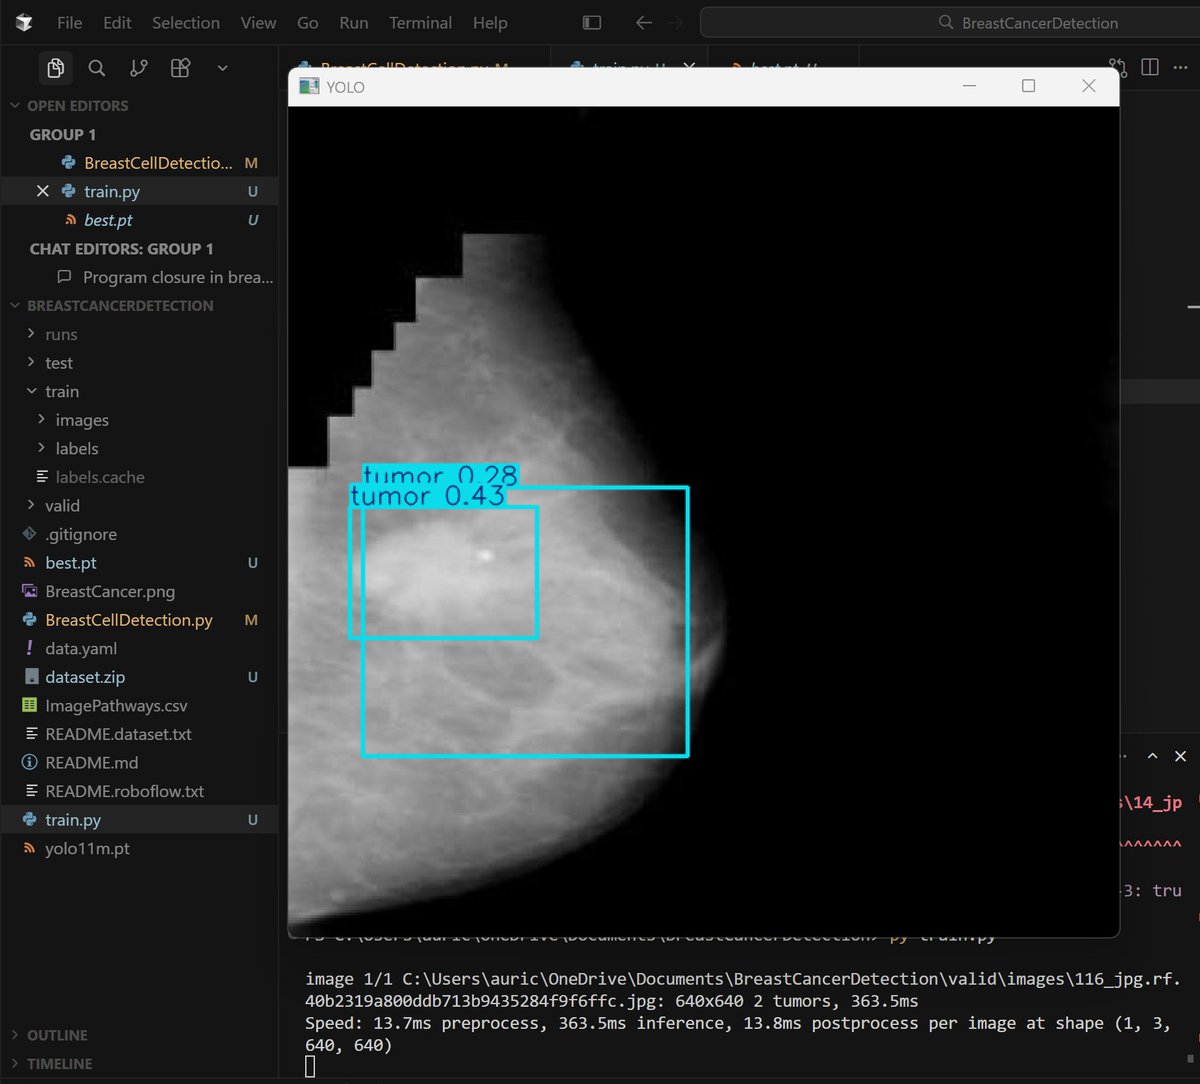
Currently building a Breast Cancer Cell detection. I downloaded the tech stack from Roboflow, so the YOLO model is integrated with just 10 lines of code. I'm gonna add some heatmaps with Grad-Cam.
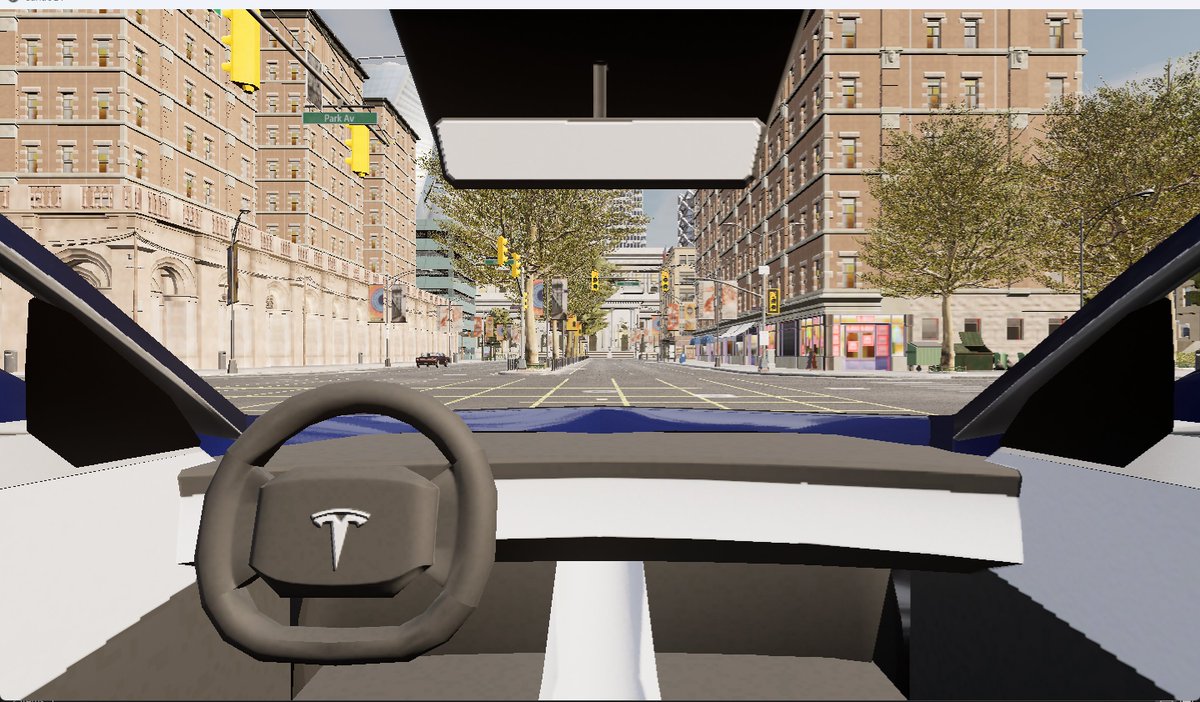
Little update: got YOLOv11 integrated. The vehicle's camera is going frame by frame. Also, I didn't know that there was an autopilot on Carla, which makes my life 10x easier. My last step is to build a PyTorch model to predict the vehicle's next movement and update the dashboard!
I'm currently building an autonomous driving sim in CARLA using YOLOv11 for real-time object detection and PyTorch for action prediction (accelerate, brake, turn, reverse); CARLA setup and controls already completed.