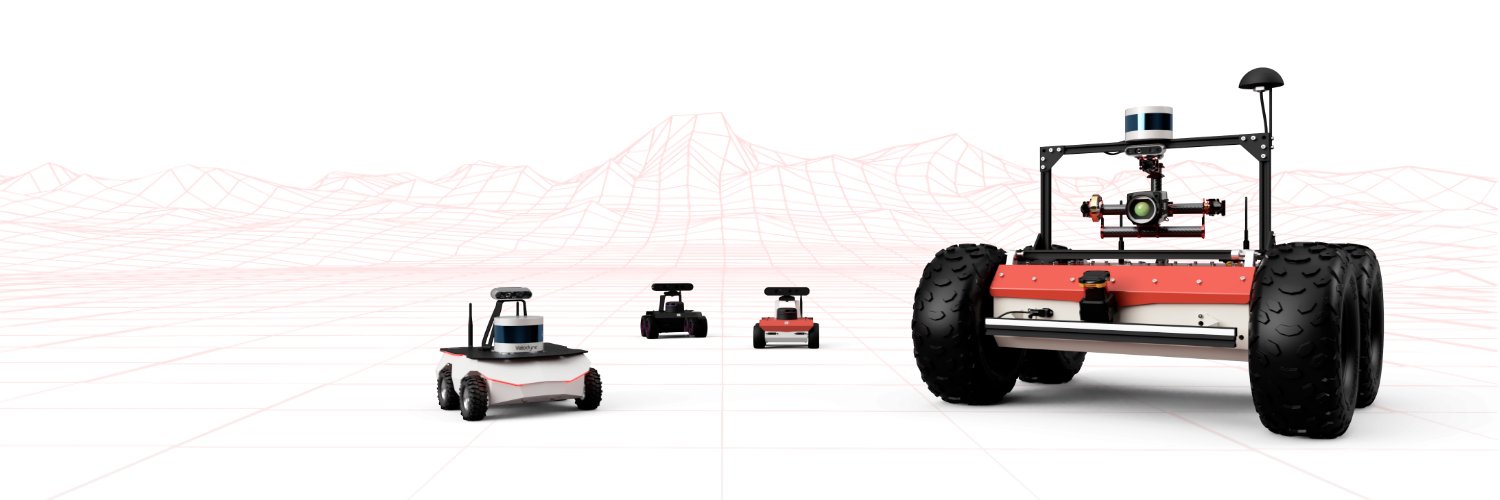
Husarion provides mobile robotic platforms, software and connectivity solutions, allowing you to build your own autonomous systems based on ROS & ROS 2.
Are you familiar with all of our robots❓
✔️ Panther - for industrial use cases in an outdoor environment
✔️ ROSbot 2R - for #education and #research
✔️ ROSbot 2 PRO - for R&D and prototyping purposes
✔️ ROSbot XL - for real-life indoor use cases
🤖 Husarion OS 2026.09.30 is out for ROSbot 3 & XL:
▸ Husarion Cockpit - drive, configure & update it from a phone
▸ set domain ID / namespace / RMW once, every sensor follows
▸ Nav2 + SLAM Toolbox built into the rosbot snap
Release notes 👇
https://t.co/5ooFNwTuVk
#ROS2
🤖 ROSbot #ROS 2 driver v1.0.0 is out - one software stack for ROSbot 3 & XL:
▸ full ROS 2 namespaces, so robots stop fighting over /cmd_vel on shared Wi-Fi
▸ 10× IMU, 5× odometry, 2× PID rates
▸ set the ROS 2 config once - accessory snaps inherit it
▸ Cartesian gamepad control of the arm
Release notes 👇
https://t.co/xIgzFGqAYy
🇨🇭 #ELROB 2026, Thun: Husarion Panther ran the Mule scenario - teach a route by walking it on a wire (patent-pending Follow Me), then let it shuttle autonomously.
No camera/LiDAR teach-in. Robust in dust, night & changing light.
Field report 👇
https://t.co/euY0QuMFGD
#UGV
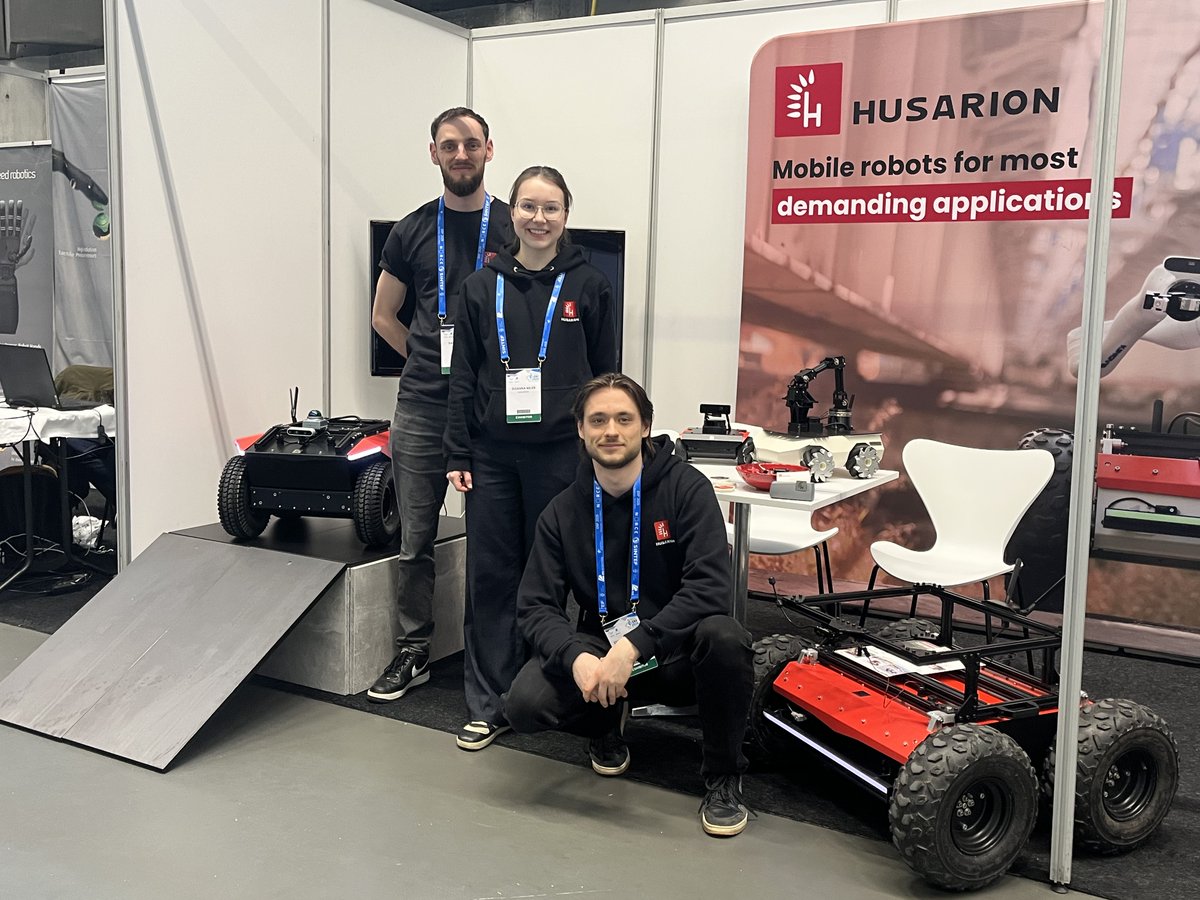
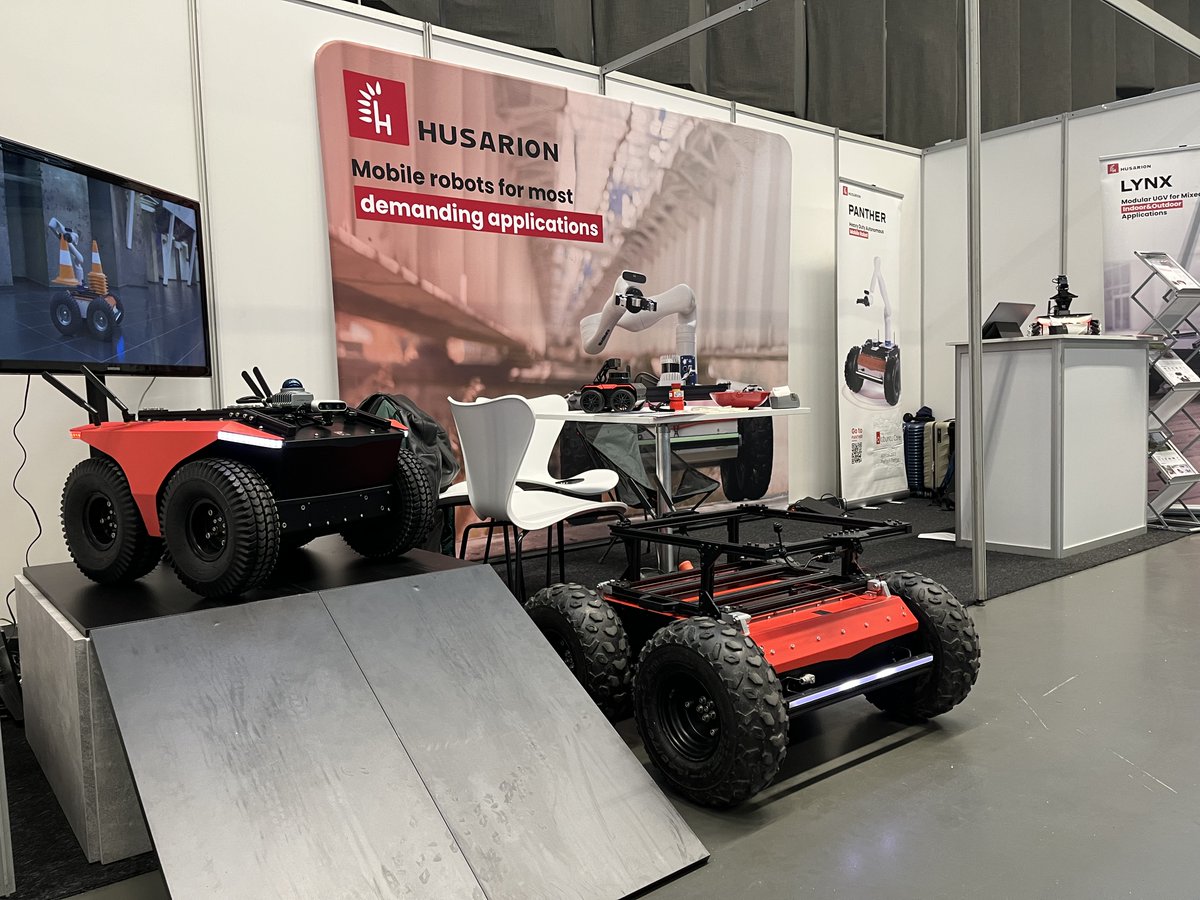
ERF 2026 is underway, and we’re here in Stavanger, Norway until March 27. Visit Husarion at booths 116 & 117 to see Panther, Lynx, and the ROSbot family up close. Stop by to talk about autonomous systems, mobile robot applications, and ROS-based deployments.
#ERF2026 #ROS2 #UGV #MobileRobots
Last month we shared that #HusarionLynx#UGV won Best Radiation Mapping at #EnRicH2025
The event, held inside the inactive Zwentendorf NPP (Austria), was organized by ADTA, Fraunhofer FKI, EVN & European Robotics.
Now we’re sharing the tech details: https://t.co/UemmuePJY5
Check out the brand new Husarion UGV Configurator — an intuitive TUI tool for Panther & Lynx UGVs!
✅ROS config management
✅Driver control & logs
✅Robot info at a glance
Pre-installed on new robots or via OS upgrade.
🔗https://t.co/cOJyNvnCfP
We're half-way through #ENRICH2025 in the Zwentendorf nuclear plant.
Our #HusarionLynx#UGV is charting radiation & 3D maps (powered by #ROS 2) deep inside meters-thick concrete.
To keep the data flowing when RF signals vanish, we came prepared: a rugged fibre-optic tether, Wi-Fi HaLow backup, 3D LiDAR, HD vision and a brand-new modular mission-control centre designed just for this hackathon.
The result? Smooth, high-frame-rate telemetry all the way back to HQ – even in the deepest corners of the plant! 🚀
Something new (and tiny) just rolled out of our lab!
(Well… kind of 😉 )
We know parting with your Panther at the end of the day can be tough.
So we found a solution.
From now on, every Panther robot ships with a mini 3D-printed Panther- because why shouldn’t you take your favorite UGV home too?
Full-sized power at work.
Bite-sized buddy on your desk.
No drivers, no LiDARs — just pure desk-candy.
You’re welcome. 😎
#MakersGonnaMake
Flashing OS images across SBCs is messy—SD vs eMMC/SSD, rescue OS, dd roulette 🔄
🚀HOFI is a minimal Yocto USB stick that flashes any board (Pi, Jetson, x64…) the same way:
1⃣copy .img to os_images partition
2⃣boot from USB
3⃣flash via HDMI+keyboard, SSH, or web UI
Now the default for #ROS2 Husarion robots—give it a try here: https://t.co/MvKokcfB81
🚀Big news from the #Husarion dev team!
The new Husarion UGV ROS 2 driver is out — now supporting #HusarionPanther & #HusarionLynx
🔁One driver for all UGVs
💡Overlapping LED animations
⚙️Easy configuration
🪐New WebUI
🎮XInput gamepad support
👉https://t.co/rL0uST8x2w
#UGV #ROS2 #robotics
Autonomy just got easier! Set up mapping, navigation & docking on your #HusarionPanther and #HusarionLynx with our open-source reference setup powered by #ROS2, #Nav2 & #Docker.
🛠️ Modular setup
🌍 Real-world + #Gazebo sim
🔓 100% open-source
👉 https://t.co/gqM0jxilxq
Experience the magic of a #ROS 2 powered Christmas Tree! ✨🎄
Our Panther UGV is spreading cheer with a Christmas tree mounted on top, synchronized lights, and festive music!
🎅Wishing you a wonderful holiday season filled with groundbreaking robotic ideas for the year ahead!
Master the physics & math behind any #robotic system.
In the Cyber World Robot Lab of the Robotics Developer Masterclass(https://t.co/JILJtXgb1x), you’ll master:
🔹 Simple #kinematics
🔹 Advanced planning & control algorithms
All with real ROSbot XL (@husarion) practice.
See how @CranfieldUni's DARTeC uses our #HusarionPanther#UGV for precise aircraft inspection in GPS-denied hangars.
Discover cutting-edge methods: visual tracking with YOLOv8 & UWB-based localisation for accurate navigation. 💡✈️
Read more: https://t.co/PJeB8rhIM2
#Robotics