This spider robot climbs the wall, slips through an access hole, and even welds. You may have already seen it.
It’s Diden Spider, our quadruped. We build Physical AI for real industrial sites. The bipedal platform and humanoid are also on the bench now.
Diden Spider started out shaped like a dog. COO Youngha Shin explains why it became a spider.
Turned sideways on a wall, a dog-like form holds its body on only 4 of 12 joint actuators. A spider-like form keeps the body close to the wall.
Full interview:
https://t.co/wnrmuAUhlk
"People have never walked on a steel wall held on by magnets, so there's no human motion for a robot to imitate," says CTO Soonpyo Kwon.
An algorithm calculates how to cross a longi. Reinforcement learning imitates it with less jitter.
Full interview:
https://t.co/tbyBwGZQCz
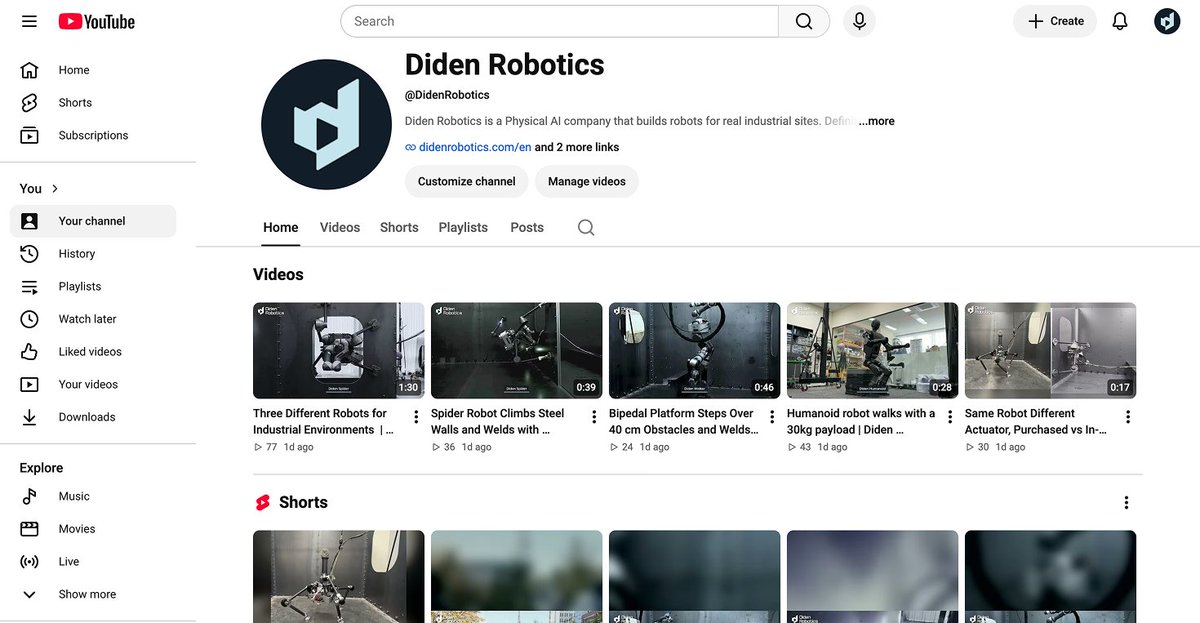
🎉 Diden Robotics has opened its YouTube channel!
Diden Spider, Diden Walker and the Diden Humanoid unveiled a few days ago, all on video. Subscribe to see what our robots do next.
https://t.co/xNgvplwQMZ
ROBOTWORLD 2026 opened today, and Diden Humanoid is giving its first public demonstration there. Beside it, Diden Spider climbs the steel wall and passes through an access hole, while Diden Walker steps smoothly over a longi. Come and see them in person if you are in Korea.
Christopher Miller, who leads the U.S. Navy’s robotic and autonomous systems portfolio, brought up a video of Diden Spider at the Ironclad Maritime Summit in Norfolk while discussing hull cleaning and inspection.
“It’s really cool. It’s like a spider.”
Thanks for the shout-out
In our interview with CTO Soonpyo Kwon, he puts a structure built for collaboration ahead of code.
A separate platform software team works on exactly that. The people behind Diden Spider, Walker and Humanoid are coming together on it.
Full interview:
https://t.co/MHtUqtNcOr
In the lab, 5 out of 10 shows potential. In the field, a robot must succeed 100 out of 100.
A purchased shoulder actuator got pulled right out mid-walk. So we built our own: 194 N·m/kg, among the highest in the world.
Interview with COO Youngha Shin:
https://t.co/T5d9eYiDux
Hull blocks are connected by access holes, and a robot that cannot fit through one is stuck in the block it started in. Diden Spider goes through this one in a minute. 🕷️
People are asking what this quadruped is for.
Diden Spider carries a task module up a vertical steel wall and holds itself there on four magnetic feet.
Here, that module is a welding torch, but it could be inspection equipment too.
What else would you put on it?
We are proud to welcome Byungchan Jung as our new Chief Product Officer! He has led robots from development to launch, as CTO and then CEO of Hanwha Robotics, and will lead productization of Diden Spider, Diden Walker and Diden Humanoid.
https://t.co/dd1fMBNpmH
During a recent field test, our quadruped Diden Spider found the original spider already on the wall.
One of our engineers summed it up: “It climbs just fine without magnets.”
Diden Spider doesn’t have the original’s foot hairs. It has magnetic feet instead. 🕷️🧲
Diden Spider is walking up a steel wall here, and the only thing holding it there is its own feet.
Watch the transition. It does not stop when the floor runs out. 🕷️
@nexta_tv Thanks for highlighting our Spider🕷️! An electro-permanent-magnet (EPM) foot switches on and off within a single step and carries the robot's own weight up a vertical steel wall.
@MarioNawfal Thanks for the spotlight on our robot. Scaffolding is exactly the right thing to point at. Before a robot can weld inside a hull block, it has to get up a vertical steel wall and take its tools with it.
@lukas_m_ziegler Thanks for taking a proper look at our quadruped robot. That electrical problem is one of the hardest parts of this job. Grounding is definitely a design-stage decision.