🎉 Excited to share HuRo, accepted to CoRL 2026!
Can robotized human videos provide scalable robot learning supervision?
HuRo turns human videos into robot aligned observations and actions.
In VLA pretraining, OOD completion rises from 34.9% to 72.2%.
🧵 More in replies.
As we get closer to a world where we live among robots, it’s becoming more and more valuable for robots to learn quickly with and from people.
I’m very excited to share Steertuning, a novel approach that adapts robots to new tasks from 5 human demonstrations in under 5 minutes, from demonstration to deployment.
Website: https://t.co/H6l1IseeCz
Code: https://t.co/cqUstbwAgU
@GautamSalhotra@GoogleDeepMind Hi Gautam. I'm a CS PhD student working on dexterous manipulation RL at NYU and first author of HuRo (CoRL 2026), turning everyday human videos into scalable supervision for robot foundation models. I emailed you and will be at CoRL next week. Would love to chat.
❓I keep coming back to this: what tactile representation does manipulation need?
We introduce PanoTac: A dense three-axis Tactile Sensor.
In the demo, the robot reorients and inserts a tube, then wiggles the stopper free while the tube sits loosely in the rack. The right side show the tactile signals that helps robot detect when the stopper releases and when to switch from wiggling to lifting. (1/7)
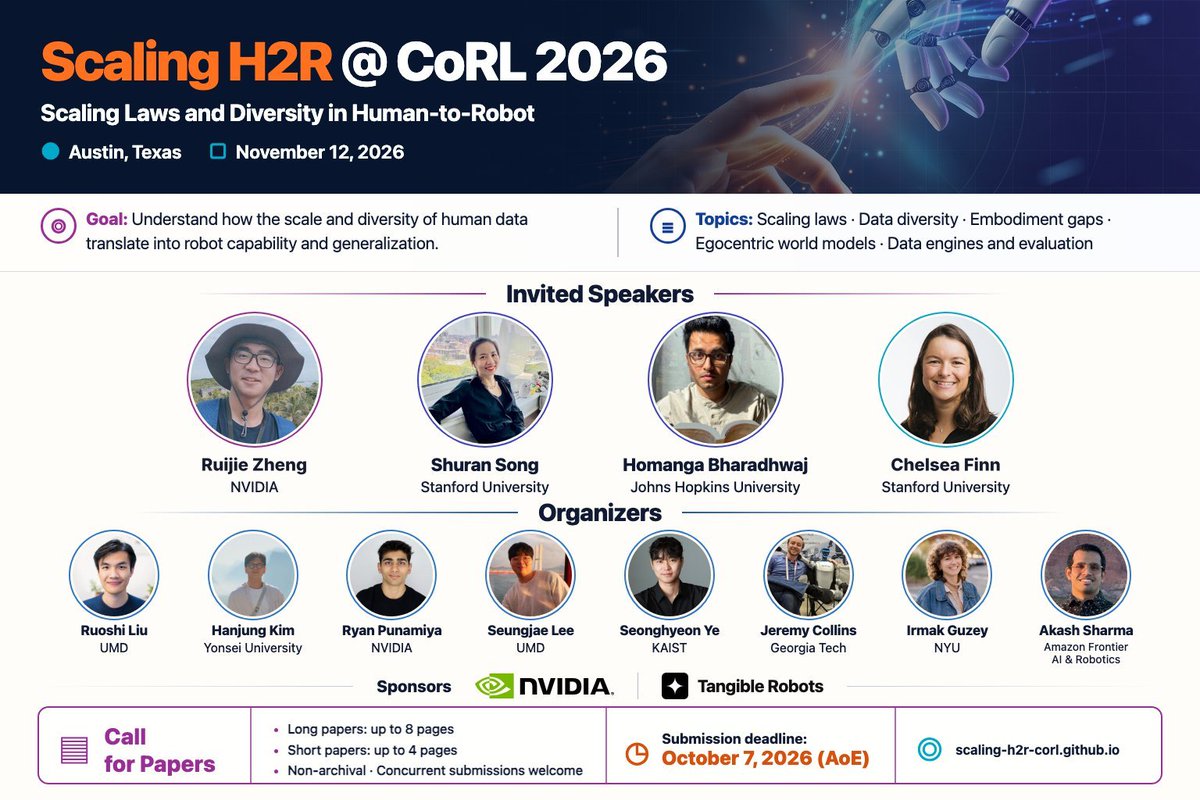
🚨 Submissions close October 7! #CoRL2026
Working on human-to-robot learning? Submit your work to Scaling H2R @ CoRL 2026!
We welcome new results, work in progress, and position papers on scaling and diversifying human data for robot learning. We’d love to hear your ideas and discuss them at the workshop!
🏆 Workshop sponsors: @nvidia and @tangiblerobots
🌐 Website: https://t.co/QViMDmgnK4
📝 Submit: https://t.co/W7sS50y4gg
🎉 Excited to share HuRo, accepted to CoRL 2026!
Can robotized human videos provide scalable robot learning supervision?
HuRo turns human videos into robot aligned observations and actions.
In VLA pretraining, OOD completion rises from 34.9% to 72.2%.
🧵 More in replies.
Our current retargeting is kinematic, so it does not explicitly guarantee physical feasibility under the robot’s dynamics and contact constraints. We discuss this limitation in the paper, and whether it becomes a bottleneck at scale for contact-rich tasks is an interesting open question.
One promising direction is to infer contact cues from human videos and incorporate them into object-aware retargeting, with scalability remaining a key consideration.
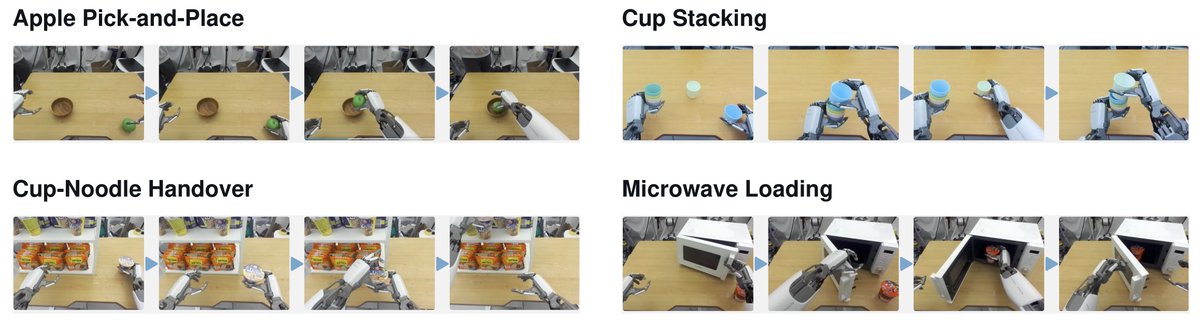
The scaling (4/7) and visual robotization (5/7) results use these four tasks: Apple Pick-and-Place, Cup Stacking, Cup-Noodle Handover, and Microwave Loading.
After per-task finetuning, OOD evaluation tests spatial and/or visual shifts.
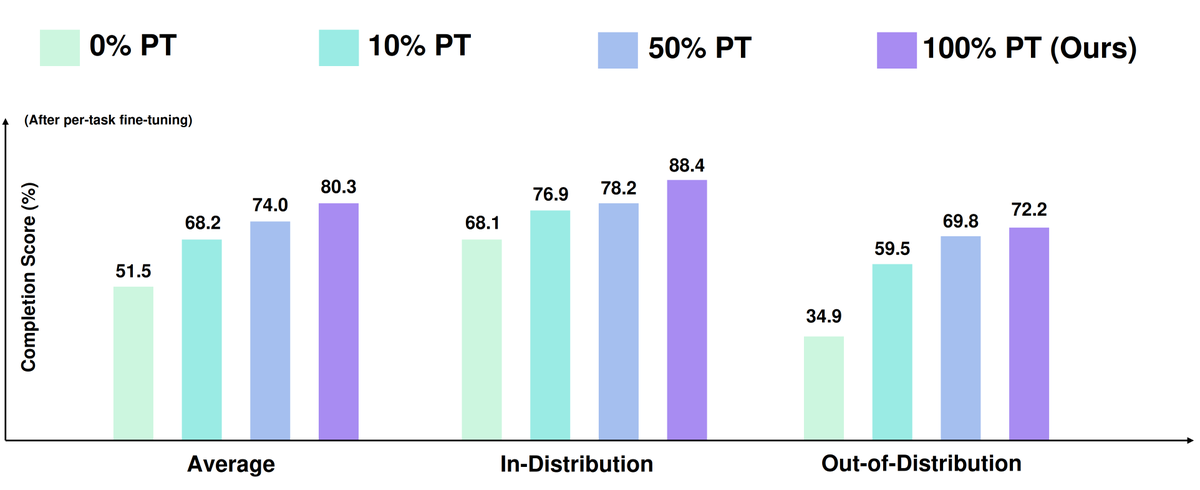
4/7 Does more robotized human video data help?
Across increasing HuRo pretraining scales, downstream real world manipulation improves:
Overall: 51.5% → 80.3%
ID: 68.1% → 88.4%
OOD: 34.9% → 72.2%
Pretraining steps and downstream finetuning are held fixed across HuRo scales.
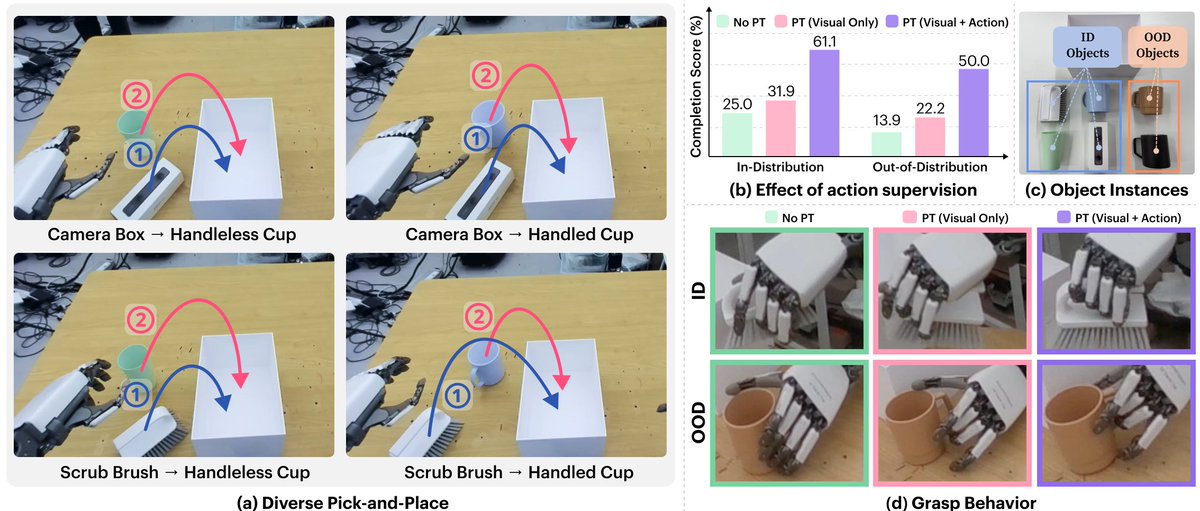
7/7 Takeaway: robotized human videos can scale supervision for robot learning.
More data helps, and both visual robotization and retargeted actions matter.
🌐 https://t.co/3owgOidZAd
🤗 https://t.co/8jVZtUsp9J
💻 https://t.co/7pURe6dl36
@corl_conf#CoRL2026