Can an agent learn a pool table’s physics by playing on it? 🎱
While agents can close the visual gap, the difference between real world and sim dynamics remains significant. For CoRL late breaking🤠, we let an agent take real shots to try and close this real2sim dynamics gap: https://t.co/g12jkuuB4n
Very fun short project with @XilunZhangXZ@MatthewFoutter@Luis_A_Pabon@drmapavone
If you think arranging the balls into letters is too easy, I challenge you to come by our poster on Tuesday, Nov 10 at CoRL during lunch and see how many tries you need. We're bringing the mini pool table and it's actually trickier than you'd think.
Also, to hear why we think real2sim is not yet solved, read our full blog post here: https://t.co/1Q8AGs4yRw
Opus5.5 wrote its own controller to hit pool balls, built its own vision tools to track ball trajectories and chose actions that would better inform the sim dynamics reconstruction. In the end it was able to match the real pool table dynamics much better than visual reconstruction only.
If you are serious about robotics (aka Physical AI), hire students from the Robotics, Systems and Control master’s at @ETH . In my opinion, it is THE strongest robotics program in the world:
•control,
•optimization,
•perception,
•locomotion,
•aerial robotics,
•learning,
•systems engineering, robot dynamics
If the student has GPA > 5.75, you can probably skip the technical interview.
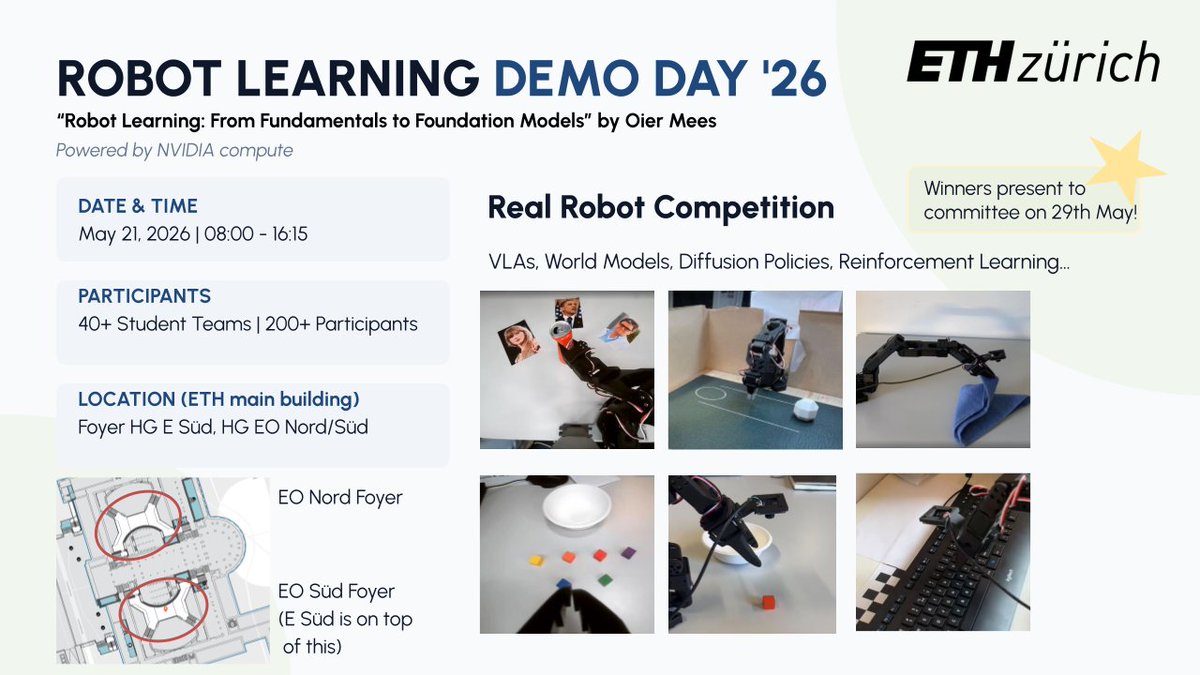
🏁 𝗧𝗵𝗲 𝗚𝗿𝗮𝗻𝗱 𝗙𝗶𝗻𝗮𝗹𝗲: 𝗧𝗼𝗺𝗼𝗿𝗿𝗼𝘄 𝗶𝘀 𝗘𝗧𝗛 𝗥𝗼𝗯𝗼𝘁 𝗟𝗲𝗮𝗿𝗻𝗶𝗻𝗴 𝗗𝗲𝗺𝗼 𝗗𝗮𝘆 '𝟮𝟲! 🤖⚡
Tomorrow, the final showcase of our "Robot Learning: From Fundamentals to Foundation Models" course at @ETH is open to everyone, and you are invited to come see the results live! 🚀
After mastering the fundamentals in the first half of the course in simulation, 300 students assembled 55 real-world SO-101 robots 🛠️ and took the leap to real hardware—deploying 𝗩𝗟𝗔𝘀, 𝗪𝗼𝗿𝗹𝗱 𝗠𝗼𝗱𝗲𝗹𝘀, 𝗩𝗶𝗱𝗲𝗼-𝗔𝗰𝘁𝗶𝗼𝗻 𝗠𝗼𝗱𝗲𝗹𝘀, 𝗗𝗶𝗳𝗳𝘂𝘀𝗶𝗼𝗻 and 𝗥𝗟 𝗽𝗼𝗹𝗶𝗰𝗶𝗲𝘀 directly onto the physical robots they built with their own hands.
If you are in Zurich and want to see cutting-edge AI running on real hardware, drop by to see 40+ student teams tackle an incredible variety of live tasks. For example, teams will face semantic generalization with VLAs using the classic RT-2 benchmark task: instructing robots to "move the coke can to Taylor Swift." 🥤⭐ To truly evaluate zero-shot generalization, we have printed pictures of famous people that the teams won't even see until competition day! Other challenges the student's policies will tackle include cloth folding 👕, keyboard typing ⌨️, singulating cluttered objects, poking, pushing and grasping.
The stakes are high: beyond counting towards their final course grades, the top teams will win the incredible opportunity to present their work to an evaluation committee featuring @ylecun , @SongShuran and @JitendraMalikCV on May 29th! 🏆
📍 Event Details (Open to the Public)
📅 Date: Tomorrow, May 21, 2026
🕒 Time: 08:00 – 16:15
🏢 Location: ETH Main Building (Rämistrasse 101, 8006 Zürich | Foyer HG E Süd, HG EO Nord/Süd)
A massive thank you to our 14 dedicated TAs for their incredible support during this journey 🙏 to @nvidia for the compute.
If you are around Zurich or the ETH campus tomorrow, come by the foyers to watch the live demos, chat with the students and see the future of robot learning in action!
📣 𝗧𝗵𝗿𝗶𝗹𝗹𝗲𝗱 𝘁𝗼 𝗵𝗼𝘀𝘁 𝗗𝗶𝗲𝘁𝗲𝗿 𝗙𝗼𝘅 (@fox_dieter17849) 𝗳𝗼𝗿 𝗮 𝗴𝘂𝗲𝘀𝘁 𝗹𝗲𝗰𝘁𝘂𝗿𝗲 𝗮𝘁 𝘁𝗼𝗱𝗮𝘆'𝘀 𝘀𝗲𝘀𝘀𝗶𝗼𝗻 𝗼𝗳 𝗥𝗼𝗯𝗼𝘁 𝗟𝗲𝗮𝗿𝗻𝗶𝗻𝗴: 𝗙𝗿𝗼𝗺 𝗙𝘂𝗻𝗱𝗮𝗺𝗲𝗻𝘁𝗮𝗹𝘀 𝘁𝗼 𝗙𝗼𝘂𝗻𝗱𝗮𝘁𝗶𝗼𝗻 𝗠𝗼𝗱𝗲𝗹𝘀 ����𝘁 @ETH!
Today's speaker almost needs no introduction. Dieter is Professor at the @UW and Senior Research Director at @allen_ai, co-author of the landmark textbook 𝗣𝗿𝗼𝗯𝗮𝗯𝗶𝗹𝗶𝘀𝘁𝗶𝗰 𝗥𝗼𝗯𝗼𝘁𝗶𝗰𝘀, Fellow of @IEEEorg, @RealAAAI, and @TheOfficialACM, and recipient of the 𝟮𝟬𝟮𝟬 𝗜𝗘𝗘𝗘 𝗣𝗶𝗼𝗻𝗲𝗲𝗿 𝗶𝗻 𝗥𝗼𝗯𝗼𝘁𝗶𝗰𝘀 𝗮𝗻𝗱 𝗔𝘂𝘁𝗼𝗺𝗮𝘁𝗶𝗼𝗻 𝗔𝘄𝗮𝗿𝗱 and the 𝟮𝟬𝟮𝟯 𝗜𝗝𝗖𝗔𝗜 𝗝𝗼𝗵𝗻 𝗠𝗰𝗖𝗮𝗿𝘁𝗵𝘆 𝗔𝘄𝗮𝗿𝗱.
Today he will be talking about: "𝗧𝗼𝘄𝗮𝗿𝗱 𝗙𝗼𝘂𝗻𝗱𝗮𝘁𝗶𝗼𝗻 𝗠𝗼𝗱𝗲𝗹𝘀 𝗳𝗼𝗿 𝗖𝗼𝗺𝗽𝗲𝘁𝗲𝗻𝘁 𝗥𝗼𝗯𝗼𝘁𝘀" 🤖
His talk will cover large-scale data generation for robot manipulation, the role of simulation and sim-to-real transfer, and ongoing work at Ai2 on training models that are genuinely competent across a broad set of tasks — moving beyond narrowly trained, disconnected skills 🚀
If you are in Zürich and want to join us:
📍 Where: Room NO C 60, Sonneggstrasse 5
🕓 When: Today, May 18, 17:00 – 18:00
See you there!
📣 𝗧𝗵𝗿𝗶𝗹𝗹𝗲𝗱 𝘁𝗼 𝗵𝗼𝘀𝘁 𝗟𝘂𝗰𝗮𝘀 𝗕𝗲𝘆𝗲𝗿 (@giffmana) 𝗳𝗼𝗿 𝗮𝗻 𝗶𝗻-𝗽��𝗿𝘀𝗼𝗻 𝗴𝘂𝗲𝘀𝘁 𝗹𝗲𝗰𝘁𝘂𝗿𝗲 𝗮𝘁 𝘁𝗼𝗱𝗮𝘆'𝘀 𝘀𝗲𝘀𝘀𝗶𝗼𝗻 𝗼𝗳 𝗥𝗼𝗯𝗼𝘁 𝗟𝗲𝗮𝗿𝗻𝗶𝗻𝗴: 𝗙𝗿𝗼𝗺 𝗙𝘂𝗻𝗱𝗮𝗺𝗲𝗻𝘁𝗮𝗹𝘀 𝘁𝗼 𝗙𝗼𝘂𝗻𝗱𝗮𝘁𝗶𝗼𝗻 𝗠𝗼𝗱𝗲𝗹𝘀 𝗮𝘁 @ETH !
I will be starting the afternoon at 16:15 with a lecture on Frontier & Open Problems in robot learning and how to do research in the field, before handing over to Lucas at 17:15 to close out the session.
Lucas has been behind some of the most impactful work in computer vision and multimodal AI in recent years: co-author of the 𝗩𝗶𝘀𝗶𝗼𝗻 𝗧𝗿𝗮𝗻𝘀𝗳𝗼𝗿𝗺𝗲𝗿 (𝗩𝗶𝗧), the landmark paper that helped establish transformers as a core architecture for image understanding, 𝗦𝗶𝗴𝗟𝗜𝗣, the contrastive vision-language model that underpins much of today's multimodal AI, and 𝗣𝗮𝗹𝗶𝗚𝗲𝗺𝗺𝗮, @GoogleDeepMind's open vision-language model that has powered many VLAs in robotics. After @GoogleDeepMind and @OpenAI, he is now at @Meta @AIatMeta Superintelligence Labs. Today he will be talking about: "𝗩𝗶𝘀𝗶𝗼𝗻 𝗶𝗻 𝘁𝗵𝗲 𝗔𝗴𝗲 𝗼𝗳 𝗟𝗟𝗠𝘀 " 🚀
If you are in Zurich and want to join us:
📍 Where: Room NO C 60, Sonneggstrasse 5
🕓 When: Today, May 11, 16:15 – 18:00
See you there!
🎉 𝗺𝗶𝗺𝗶𝗰-𝘃𝗶𝗱𝗲𝗼 𝗵𝗮𝘀 𝗯𝗲𝗲𝗻 𝗮𝗰𝗰𝗲𝗽𝘁𝗲𝗱 𝘁𝗼 #𝗥𝗦𝗦𝟮𝟬𝟮𝟲 𝗶𝗻 𝗦𝘆��𝗻𝗲𝘆!
Sharing this one with a lot of pride. This work was led by my two students, @jjonpai and @Liam862373. Both are Master's students at @ETH who I have the privilege of advising at @Microsoft, and TAs for my new robot learning course at ETHZ. Watching them take an ambitious idea and carry it all the way to RSS has been one of my highlights of the past year. They are going to do extraordinary things.
For those new to the work: mimic-video is a Video-Action Model that grounds robot policies in pretrained video models (NVIDIA Cosmos) instead of static image-text VLM backbones. The result is 𝟭𝟬𝘅 𝗯𝗲𝘁��𝗲𝗿 𝘀𝗮𝗺𝗽𝗹𝗲 𝗲𝗳𝗳𝗶𝗰𝗶𝗲𝗻𝗰𝘆 📉and 𝟮𝘅 𝗳𝗮𝘀𝘁𝗲𝗿 𝘁𝗿𝗮𝗶𝗻𝗶𝗻𝗴 ⏩than standard VLAs, with performance that scales directly with video model quality, and no expensive video reconstruction at inference time.
And we have recently 𝗼𝗽𝗲𝗻-𝘀𝗼𝘂𝗿𝗰𝗲𝗱 𝗲𝘃𝗲𝗿𝘆𝘁𝗵𝗶𝗻𝗴: code, models, the works. If you are building in robot learning, please take it, break it, build on it. We genuinely cannot wait to see where the community takes this.
Last but not least: huge shoutout to the team at @mimicrobotics, they brought world-class robot systems, deep dexterity expertise and a genuine research partnership that shaped this work from day one. This is exactly the kind of partnerships between @Microsoft and cutting-edge robotics startups that I believe moves the field fastest.
See you in Sydney! 🇦🇺
Code: https://t.co/mxqrIFa4Z1
Project: https://t.co/s1QWGVNzeV
Paper: https://t.co/ZLakdfOwyg
I am thrilled to host @QuanVng (Co-Founder of @physical_int ) as our Guest Spotlight at @ETH!
I will be starting the afternoon with a lecture on Generalist Robot Policies and how to train VLAs, before handing over to Quan to close out the session. Quan has been a central figure in the push toward large-scale pre-training for generalist robot policies. From co-leading the RT-X and Open X-Embodiment projects at Google DeepMind to his current work at Physical Intelligence, his efforts in scaling physical AI are defining the next frontier of robotics.
𝗧𝗵𝗲 ����𝗶𝘀𝘀𝗶𝗼𝗻: 𝗔𝘀𝘀𝗲𝗺𝗯𝗹𝗶𝗻𝗴 𝟱𝟱 𝗿𝗼𝗯𝗼𝘁𝘀 𝘄𝗶𝘁𝗵 𝟯𝟬𝟬 𝘀𝘁𝘂𝗱𝗲𝗻𝘁𝘀 𝗶𝗻 𝗷𝘂𝘀𝘁 𝟮.𝟱 𝗵𝗼𝘂𝗿𝘀 🤖⚡
Today, our @ETH Robot Learning course successfully assembled 𝟱𝟱 𝗦𝗢-𝟭𝟬𝟭 𝗿𝗼𝗯𝗼𝘁𝘀 robots to kick off the second half of the semester!
In parallel to my weekly lectures, we have spent the first weeks mastering the fundamentals of robot learning in simulation with homework assignments. Now we finally move to real robots. I am excited to see what the students will build as they spend the coming weeks implementing 𝗩𝗟𝗔𝘀, 𝗩𝗶𝗱𝗲𝗼-𝗔𝗰𝘁𝗶𝗼𝗻 𝗠𝗼𝗱𝗲𝗹𝘀, 𝗪𝗼𝗿𝗹𝗱 𝗠𝗼𝗱𝗲𝗹𝘀, 𝗮𝗻𝗱 𝗥𝗟 𝗽𝗼𝗹𝗶𝗰𝗶𝗲𝘀 directly on real hardware!
Huge thanks to my TA team for making this hardware marathon possible. This is very much a collective effort: together, we are striving to build a scalable, hands-on robot learning course that brings cutting-edge research into the classroom 🚀
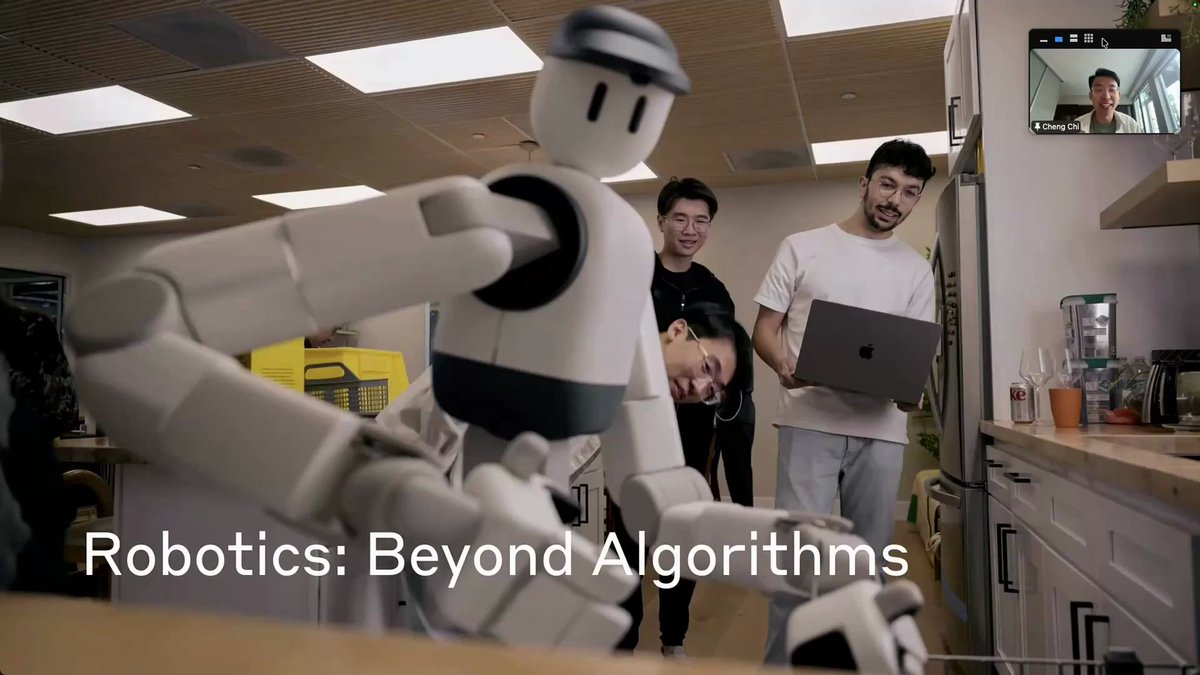
If you missed @chichengcc's guest lecture on "Robotics: Beyond Algorithms" from my @ETH robot learning course, check it out on YouTube! He shares insights that are rarely taught & hard to learn in academia.
📽️ YouTube: https://t.co/coRqOHHB3n
📚 Course: https://t.co/QJcfXJRfX8
Excited to welcome @ajwagenmaker for a Guest Spotlight to close today's session of my robot learning course at @ETH today!
He'll dive into "Robots That Learn From Experience" and how physical interaction scales robotics beyond imitation learning.
Excited to share the recording of @aviral_kumar2's guest lecture on "How to Replicate the LLM Recipe in Robot Learning" from my @ETH_en robot learning course on YouTube!
🎥 https://t.co/u0yCEe5mRv
🏠 https://t.co/dL0gKA0StO
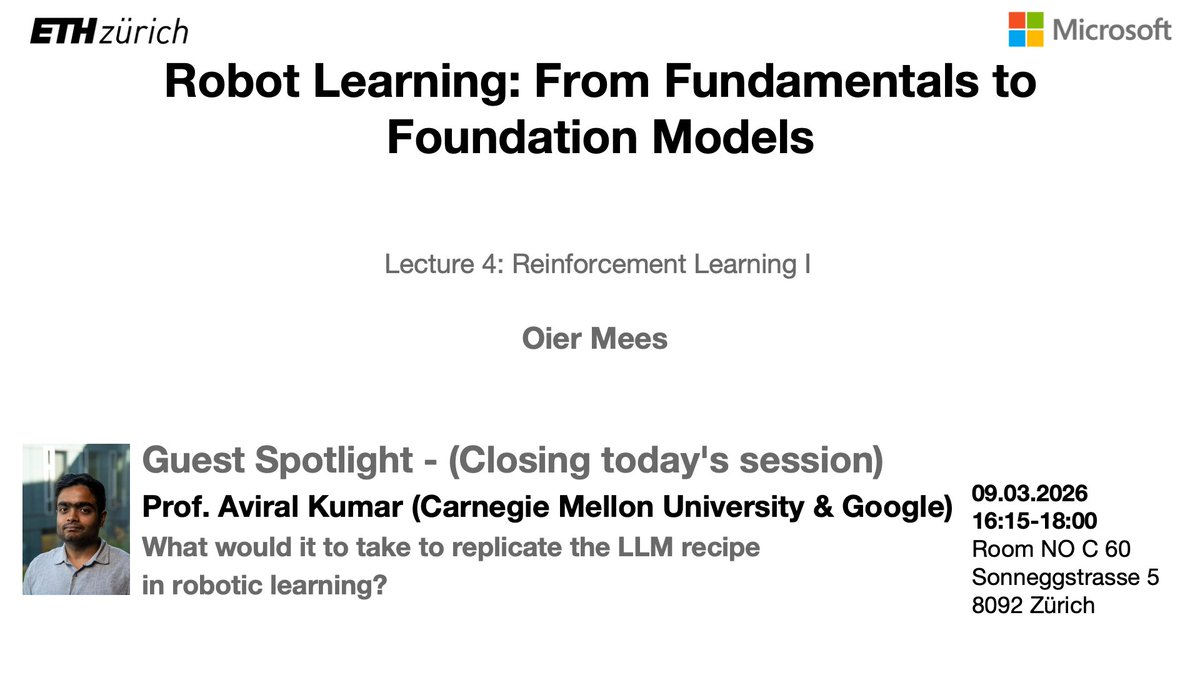
Excited to have @aviralku join us today for a Guest Spotlight to close today's session of my robot learning course at @ETH_en! He'll be tackling one of the biggest open questions in the field: "What Would It Take to Replicate the LLM Recipe in Robot Learning?"
Excited to share that by popular demand, the recording of @danfei_xu's guest lecture on "Human Data as a Foundation for Robot Learning" from my @ETH_en Robot Learning course is now public on YouTube!
🎥 https://t.co/TLycJ06UJd
🏠https://t.co/QJcfXJRfX8
Excited to have @abhishekunique7 join us today for a special Guest Spotlight to close today's lecture in my robot learning course!
If you are a robot learner in Zürich, please join us:
📍 Where: Room NO C 60, Sonneggstrasse 5, 8092 Zürich
🕓 When: Today, Feb 23, 16:15 - 18:00