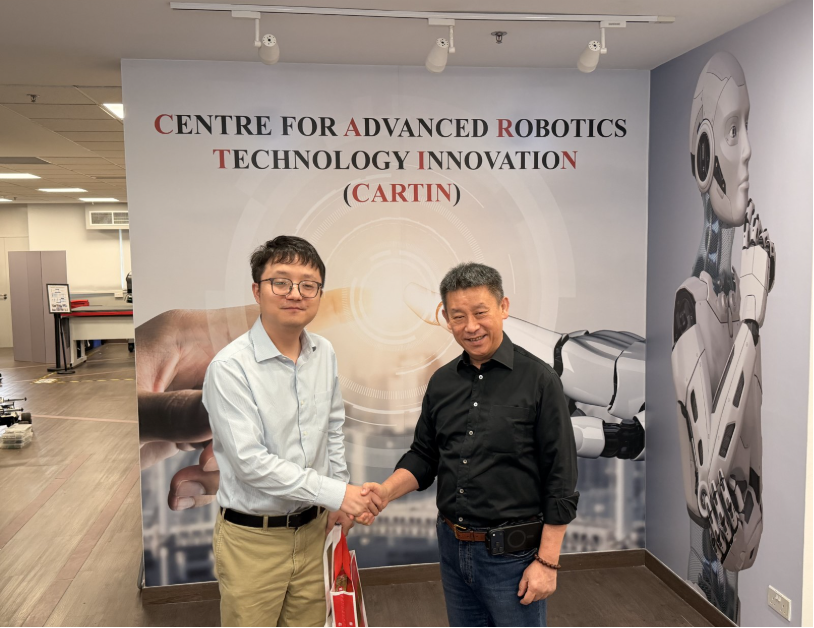
Delta Electronics Chairman and CEO Cheng Ping led a senior delegation to PINE Lab at NTU Singapore.
The visit featured robotic assembly, tactile sensing, teleoperation and robot learning, followed by discussions on deeper collaboration in industrial automation. 🤖
#DeltaElectronics #PINELab #NTUsg #IndustrialRobotics #SmartManufacturing #Automation #EmbodiedIntelligence #RobotLearning
PINE Lab Open Day was successfully held on Aug 5! 🤖
We welcomed 70+ guests from nearly 10 companies, universities, and research institutions. Visitors explored our work in mobile robotics, tactile sensing, robot data collection, automated assembly, dexterous manipulation, and real-world reinforcement learning.
Thank you to everyone who joined us. Looking forward to future collaborations in embodied AI and intelligent manufacturing!
#Robotics #EmbodiedAI #IntelligentManufacturing #PINELab
📢 PINE Lab Open Day — Final Slot Selection
Please scan the QR code and submit your final availability. Where possible, select multiple available slots to help us coordinate the schedule.
The assigned slot for each team or individual will be confirmed by email on 3 August.
📍 Centre for Advanced Robotics Technology Innovation (S2.1)
EEE, NTU — Block S2.1, Floor B3
🤖 Registration is now open for the PINE Lab Open Day!
How can robots become more reliable, precise, and data-efficient for the future of manufacturing?
Join us on 5 August at the PINE Lab, Nanyang Technological University, and discover our latest work in manufacturing data foundries, tactile sensing, dexterous manipulation, reinforcement learning and vision-language-action models, as well as mobile robotic systems.
The event will feature lab tours, live robot demonstrations, hands-on interactions, project showcases, and opportunities for collaboration and exchange. We warmly welcome researchers, students, and professionals from robotics, AI, automation, and advanced manufacturing, as well as industry partners and anyone interested in emerging technologies and real-world applications.
📅 Date: 5 August
📍 Venue: PINE Lab, Nanyang Technological University
🔗 Scan the QR code on the poster to register
We look forward to welcoming you to PINE Lab and exploring the future of embodied intelligence and autonomous manufacturing together!
#PINELab #NTUsg #Robotics #EmbodiedAI #ArtificialIntelligence #AdvancedManufacturing #Automation
Proud to be a sponsor of the RoCo Challenge at IROS 2026! 🦾
The RoCo Challenge puts robotic collaborative assembly to the test in real-world manufacturing scenarios: precision gearbox assembly, error recovery, multi-step planning. These are the hard problems that matter most when you're deploying robots on actual factory floors. Challenges like this push the entire community forward, and we're thrilled to support it.
See you in Pittsburgh! Let's build. 🔧
#RoCoChallenge #IROS2026 #Dexmate #PhysicalAI #DexterousManipulation
Our paper E2HiL has been accepted to RA-L 2026!
Human-in-the-loop RL helps robots learn in the real world, but not every human correction is equally useful.
E2HiL selects intervention samples by their effect on policy entropy, pruning both shortcut samples and noisy samples.
Across 10 real-world manipulation tasks, E2HiL achieves +24.9% success rate with 9.3% fewer human interventions.
Project: https://t.co/NzXUPnTVTn
#RobotLearning #ReinforcementLearning #Robotics
🚨 Join Our LIVE INFO SESSION — May 21 at 9:30 PM EST 🚨
Curious about the 2026 #RoCoChallenge at #IROS? Join our live session to learn more about this year’s competition, tasks, evaluation, and how to participate!
🎥 Live session link available on our website:
https://t.co/ak9DRISDSM
This year, the RoCo Challenge at #IROS26 is expanding to include:
🤖 More robot embodiments — including bimanual grippers and dexterous hands
🛠️ More assembly tasks — including industrial board assembly and brick assembly
🙌 Huge thanks to our co-organizers: Haichao Liu, @philipYHuang , @yushijinhun , Yuheng Zhou, Liming Chen, @Ken_Goldberg , Yejun Gu, @JiaoyangLi9 , Jun Liu, @soujanyaporia , Masayoshi Tomizuka, @Jianfei_AI, Steven Yeung, Hao Zhao, @ZiweiWangNTU , @ChangliuL. Special thanks to our sponsors: @DexmateAI, @SharpaRobotics, @TARSRobotics, @roboforce_ai for making this competition possible.
🔗 Ready to join us?
🔹 🌐 Learn more: https://t.co/ak9DRISDSM
🔹 📝 Register here: https://t.co/62ROVLe63t
We’re excited to push the frontier of robot manipulation and embodied intelligence together with the community! 🔥
#PhysicalAI #EmbodiedAI #Robotics #AI #Assembly #BrickAssembly #IndustrialAssembly #Pittsburgh
🚀 RoCo Challenge @ AAAI 2026 — On-site Competition Live!
RoCo Challenge @ AAAI 2026 (Robotic Collaborative Assembling for Human-Centered Manufacturing) is a research challenge jointly organized by Nanyang Technological University (NTU) and Agency for Science, Technology and Research (A*STAR).
The challenge focuses on robotic collaborative assembly in industrial manufacturing, where robots must:
1. Perform high-quality assembly,
2. Understand human progress,
3. Detect and recover from realistic human errors.
🤖 Task: Gearbox assembly under evolving workspace conditions
📌 Key scenarios:
1. Assembly from scratch
2. Resume from partial state
3. Error detection & recovery
After intense online competition, 6 teams advanced to the on-site physical track, taking place on Jan 24–25, 2026, with bilingual live streaming begins at Jan 25 13:30:
🌲 Chinese platforms: Rednote & Bilibili @ PINE_Lab_NTU
🌲 English platform: YouTube @ Pine-wn4gh
🏆 The challenge concludes with an award ceremony and technical presentations at AAAI Conference on Jan 26, 2026.
📡 Stay tuned for live demos of robust, error-aware robotic assembly in the real world!
🚀 Postdoc Position in Embodied AI & Robotics @ NTU (Singapore)
PINE Lab (Perception and embodied INtElligence Lab) at Nanyang Technological University (NTU) is actively recruiting Postdoctoral Research Fellows to work on cutting-edge research in Embodied AI and Robot Learning.
👤 Supervisor
Dr. Ziwei Wang is an Assistant Professor in the School of Electrical and Electronic Engineering, NTU. He received his B.E. (2018) and Ph.D. (2023) from Tsinghua University, and was a Postdoctoral Researcher at the Robotics Institute, Carnegie Mellon University. His research focuses on embodied foundation models and generalizable visuomotor policies across environments, tasks, and embodiments (single-arm, bimanual, mobile manipulation, dexterous hands). He has published 50+ papers in top venues including CVPR, NeurIPS, TPAMI, ICRA, CoRL and IROS.
🔗 Homepage: https://t.co/lo0j0L7V1N
🔬 Research Topics (including but not limited to):
1. VLA with Real-world Reinforcement Learning
2. Skill-based VLA
3. World Models for VLA Training and Planning
4. Mobile Bimanual Manipulation
5. Dexterous Manipulation & Tactile Sensing
🎯 Who We Are Looking For
1. PhD in Robotics, CS, AI, EE, or related fields
2. Strong background in robot learning / RL / vision / multimodal learning
3. Solid research and engineering skills; real-robot experience is a plus
4. Highly self-motivated and collaborative
📩 How to Apply
Please email your application to [email protected] with subject: Postdoc Application – Your Name – Institution
Include: CV, cover letter, representative papers, and referee contacts.
🌐 Lab website: https://t.co/EApw8A9W55
Feel free to share or reach out if interested
The first comprehensive survey of RL-VLA:
A Survey on Reinforcement Learning of Vision-Language-Action Models for Robotic Manipulation!
🔗:https://t.co/fD7xmiodKW
🚩 Explain how RL enhances VLA systems by introducing reward driven exploration and self corrective behavior, which helps overcome the limitations of imitation based training and improves performance in real world and out of distribution scenarios.
🚩 Organize recent advance into a unified RL VLA framework that covers model architecture, training methodologies, deployment in real environments and evaluation practices.
🚩 Summarizes key challenges in action representation, reward design, dynamics modeling, stable optimization and safe exploration, while outlining important directions for future research.
The survey provides a clear and structured reference for researchers working on robot learning, multimodal foundation models, VLA systems and autonomous manipulation.
🤖 Join the RoCo Challenge @ AAAI 2026!
🏁 The RoCo Challenge 2026 invites researchers and innovators worldwide to explore the future of Human-Robot Collaboration (HRC). Hosted during AAAI 2026, this competition—jointly organized by Nanyang Technological University (NTU), A*STAR, and Carnegie Mellon University (CMU)—focuses on embodied intelligence in complex, real-world manufacturing and service environments.
🏆 Participants will tackle multi-stage collaborative tasks in both simulation and physical settings, showcasing perception, reasoning, and coordination skills. Attractive cash prizes, AAAI exposure, and publication opportunities await top teams!
https://t.co/tO0s2Gewu3
@IROS2025 Challenge
🥈🏆 Thrilled to announce that our team ranked 2nd/100 teams in the Challenge on Multimodal Robot Learning in Simulation and the Real World !
Our end-to-end VLA model demonstrated strong generalization across complex real-world scenarios — from 🥪 making sandwiches and 🧹 cleaning hazardous waste to 🤖 understanding precise natural language instructions.
Proud to see how far we’ve come on the journey toward truly embodied, everyday intelligence. The future of living with intelligent robots is getting closer! 🤖✨
@ICCV2025 paper!
🆕 Meet AnyBimanual: a plug-and-play way to transfer any pretrained unimanual policy into a general bimanual policy with just a few demos.
�� Skill Manager: dynamically schedules reusable unimanual skill primitives for each arm 👀 Visual Aligner: soft-masking to align single-arm visual representations in bimanual scenes
📈 +17.33% avg success on 12 RLBench2 tasks vs SOTA 🤖 84.62% average success on 9 real-world bimanual tasks
📄 Paper Link: https://t.co/ge9qs8uB8T 🔗 Project Page: https://t.co/TIccKp1Gyh
#EmbodiedAI #Robotics #Bimanual #EmbodiedAI #ICCV2025
@ICCV2025 paper!
🆕 Meet GWM: Towards Scalable Gaussian World Models for Robotic Manipulation
🌍 3D Gaussian splats → scalable, geometry-aware world modeling 🎥 Action-conditioned future imagination with diffusion transformers 🤖 Serves as both a strong encoder for imitation & a neural simulator for RL
⚡️ 30% higher real-world success vs. SOTA
📄 Paper Link: https://t.co/1lwXEVheWM 🔗 Project Page: https://t.co/m5TDPHMU7j
#EmbodiedAI #Robotics #WorldModels #GaussianSplating #ICCV2025
@IROS2025 paper!
🆕 Meet ManiGaussian++: the first hierarchical Gaussian world model for general bimanual manipulation.
✌️ From single-arm → dual-arm: learns multi-body spatiotemporal dynamics
🤖 Handles acting & stabilizing arms with leader–follower world modeling
⚡️ 20.2% boost in simulation, 60% success on 9 real-world tasks
📄 Paper Link: https://t.co/T7VzTN3JHu
🔗 Code: https://t.co/pBtui1MQa7
#EmbodiedAI #Robotics #Manipulation #GaussianWorldModel #IROS2025
🚀 New @IROS2025 paper!
🆕 Meet AnyView: the 3D object detector that adapts to your frames — 1 or 50, it just works.
📦 No more overfitting to fixed views
🤖 Built for real-world real-time mobile robots
⚡️ Efficient, scalable, deployable
📄 Paper Link: https://t.co/6HVUa67AH4
#Robotics #AI #ComputerVision #IROS2025