6/6 Resources 🔗
Paper: https://t.co/qCSxFLEn7P
Code: https://t.co/Z4rbq4B8VA
Model: https://t.co/rLeEsZM03N
Benchmark: https://t.co/ZRDYaDwHpK
See you in Sydney this December! 🇦🇺
Excited to share our work AnyMo: Geometry-Aware Setup-Agnostic Modeling of Human Motion in the Wild, accepted at #NeurIPS2026! 🎉
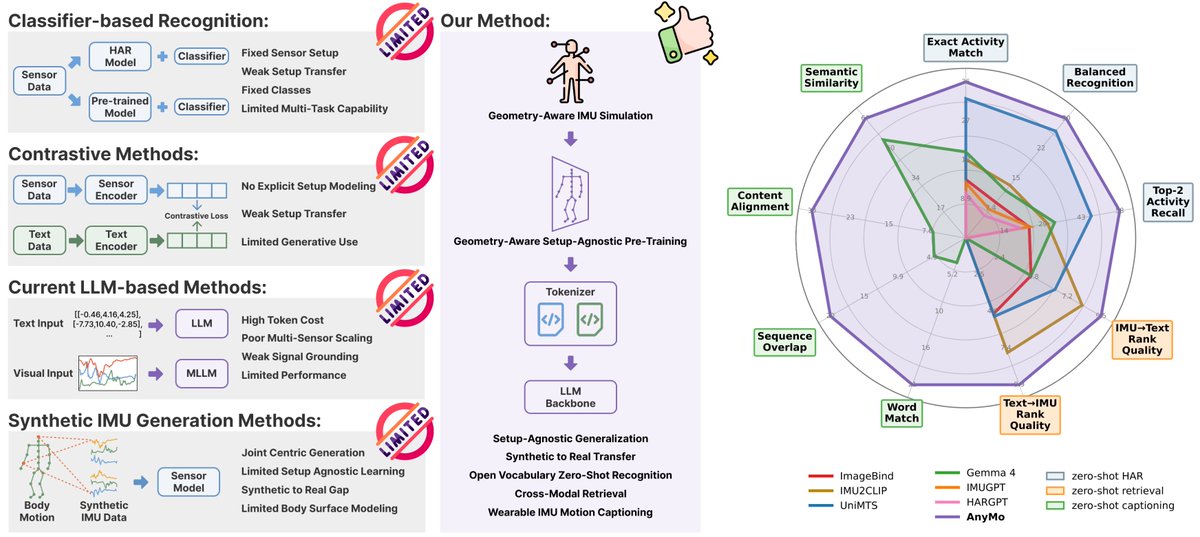
AnyMo enables IMU understanding across different sensor setups and datasets for recognition, retrieval, and captioning.
https://t.co/T3xYNP5lez
🧵⬇️
5/6 We also release AnyMo-Bench: 211.6 hours of real-world IMU data from 196 participants, covering 150 fine-grained daily activities.
To our knowledge, it is the most fine-grained real-world IMU HAR dataset and benchmark, supporting unseen-subject and cross-device evaluation.
4/6 Across 14 unseen HAR datasets, AnyMo improves average Accuracy/F1/R@2 by 11.7%/11.6%/22.6%.
It also improves IMU→Text/Text→IMU retrieval MRR by 15.9%/28.6%, and zero-shot motion-captioning BERT-F1 by 18.8%.
3/6 AnyMo compresses multi-position IMU streams into compact full-body motion tokens and aligns them with an LLM, enabling:
• zero-shot HAR
• IMU↔text retrieval
• wearable motion captioning
1/6 Wearable IMU signals vary substantially with body location, mounting orientation, hardware, and sampling protocol.
Our key insight: setup variation is not arbitrary noise, it is structured by body-surface geometry, motion, and sensor physics.
The workshop will include paper presentations, demos/discussions and a Best Paper Award.
Last year in Espoo, UbiSense had 75+ attendees. This year, IMWUT editor in chief Prof. Thomas Ploetz will join as a keynote speaker.
CFP: https://t.co/cipVpuPzjp
This year UbiSense workshop focuses on emerging techniques in ubiquitous sensing & interaction, especially how AI agents, LLMs and foundation models can be integrated into real-world UbiComp sensing and interaction scenarios.