Humanoid Robots
As intelligent automation systems, they are embedded within existing upstream and downstream processes, complementing and enhancing the capabilities of full-chain automation, such as production lines and warehouses.
As auxiliary assistants, collaborating with humans and participating in human-led work and life, humanoid robots are learning and evolving from their masters, evolving from passive to active.
As remote agents: Humans control robots through AR/VR and brain-computer interfaces, while humanoid robots act on their behalf, handling extreme tasks and meeting the human's needs.
As complete agents: Humans empower the robots(AI), understanding their intentions, patterns, and preferences, autonomously planning and executing tasks, and establishing a symbiotic relationship with them.
As human-machine symbionts: Humanoid robots' hands, legs, and other parts of the human body enhance the human being.
As a replica of the human, embedding human memories, knowledge, experience, ego, and superego,a digital copy,within the human body,a kind of superhuman and real-world immortality.
The AI companion of the replicant K in Blade Runner 2049 has been embodied in a physical form.
A Shenzhen-based embodied intelligence company, Aiyo Technology, is developing a humanoid robot called Eva.i, an embodied AI companion.
It's like bringing the virtual AI girlfriend from a science fiction movie into reality. Users can wake her up simply by touching her.
She combines robotic hardware with a virtual avatar app, incorporating AI multi-modal interaction (visual, audio, and tactile) and emotional recognition.
The body features an aluminum alloy frame and a three-layer composite skin (maintaining a constant temperature of approximately 37°C, FPC electronic skin tactile feedback, and a precision outer shell), supporting natural postures, micro-expressions, and synchronized breathing, among other human-like characteristics.
Simultaneously, the AI supports offline processing, personalized learning, and tone/expression analysis; the app includes features such as an intimacy system and emotion tracking, which can be adjusted to constantly meet user needs and provide timely feedback. Privacy measures include local encryption and a detachable camera.
In short, the team is creating another type of human-machine relationship. They call it the fourth relationship: a relaxed, burden-free emotional relationship without the fear of rejection. The team states that it promotes emotional independence and is not intended to replace real human relationships.
The project is currently preparing for crowdfunding on Kickstarter, with plans for a limited edition of 200 units.
In order to constantly perform diverse, novel tasks in unstructured environments, robots must be able to continuously improve using data. Join us at the CoRL workshop on Continually Self Improving Robots tomorrow at the JW Marriott room 202 to discuss and learn more.
Humanoid robots sort parcels during China shopping festival peak
On Nov 10 at SF Express’s Chengdu Changxing Transfer Center, two RobotEra M7 humanoids were still being debugged and trained--
They’re sorting mixed parcels--small items, document bags, waterproof bags, and cartons,at 1,200 pieces per hour on continuous 24-hour shifts to handle China’s biggest annual Double 11 order surge.
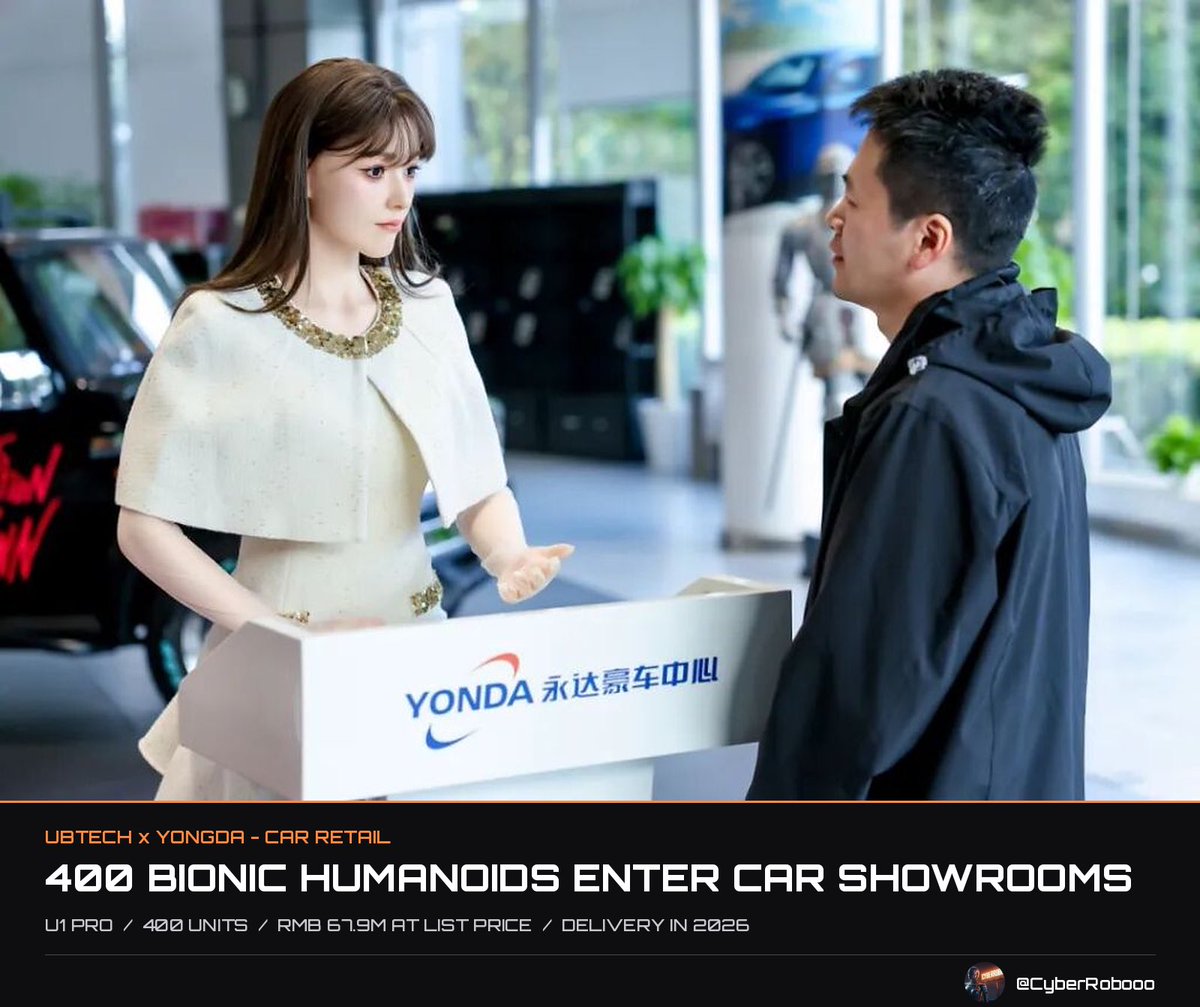
400 bionic humanoids are heading into car showrooms…
Next time you shop for a car, your salesperson might be a bionic humanoid.
UBTECH signed a strategic deal with Yongda Auto, one of China's largest luxury car dealer groups. Yongda is buying 400 U1 Pro bionic humanoids, with delivery planned this year. UBTech calls it the first large order for this line, worth about 68M yuan(~$10M)at list price.
The robots will be used for product experience, sales and customer service. The two companies will also open a robot showroom center in Shanghai, explore store-in-store displays at Yongda dealerships, and sell and lease the robots to others.
A car dealer already knows how to sell, deliver and service expensive machines. That's exactly what humanoids need to reach ordinary customers.
Hand the tedious lab steps to a humanoid researcher.
GR00T 2 looks production-ready. It lets the robot run the full experiment end-to-end…very smooth.fully autonomous,1X.
Still, I want to see if it can do tomato-egg scramble or wrap dumplings…
Autonomous, uncut, 1x speed. This is GR00T 2 controlling real dexterous hands to perform a chemistry lab experiment (and clean up after itself) end to end.
Episode 1 of a new series! I’ll keep dropping real-time robot videos, with none of the “4x” or “8x” labels you usually see in the corner. No one can speed up reality, except Dr. Strange ;)
This feels almost surreal
A Unitree G1 wearing Antigravity Vision Goggles and holding a Motion Controller, operating an A1 360° drone.
The video is already 11 months old, but the idea still feels futuristic.
Imagine humanoid robots deploying drones for factory inspections, warehouse operations, or infrastructure monitoring…The humanoid handles the ground, while the drone provides an aerial view of places it cannot reach.
Ground robots and aerial robots working together could open up a whole new dimension of multi-robot collaboration.
Teach a robot a chore in 5 minutes
You wipe your kitchen table five times while a camera watches. Five minutes later, a robot is wiping it for you.
That's Steertuning, from Lerrel Pinto's group at NYU: 5 human demos, under 5 minutes, 71% success across 12 tasks in 12 new environments, including kitchens in real homes.
This is a wheeled semi-humanoid, a YOR mobile base with two Wuji dexterous hands, learning straight from how people use theirs.
Under it is a 400M-parameter diffusion policy pretrained on about 110 hours of first-person human video. Hands are erased from the footage and each scene becomes 5,000 3D points, so human motion transfers to robot hands.
A new task takes 2 minutes of finetuning. At deployment, the robot picks the demo closest to the scene in front of it and uses that trajectory to steer its actions as they're generated. Gemini ER 1.6 plans the bigger steps.
71% is still a research number. But show it a few times, and it learns. That's how robots start giving people their time back.
Humanoid robots: I need more, much more data…
I just watched an interview with the Memories AI team. One thing really stood out to me: by next year, Physical AI data collection could be entering the 10-million-hour range.
The entire field is desperately hungry for real-world data.
Just a few months ago, the egocentric data volumes being discussed across the industry were still around 1 million hours. More recently, we've been seeing figures to 2 million hours.
But that's still not enough. Even 10 million hours may not be enough...
Across the Pacific, at the World Internet Conference in Wuzhen, China, Li Shuai, deputy director of the AI Center at China's Ministry of Industry and Information Technology's Fifth Electronics Research Institute, put the gap into perspective:
The core supply-demand gap in embodied AI data is roughly two orders of magnitude. Effective data stock is at the million-hour level, while leading companies estimate their demand at 100 million hours.
It's pretty clear that demand for data is far ahead of supply at the upstream end of Physical AI. This is becoming a genuine must-have business.
Look at what's happening--
On one side, companies are building dedicated humanoid robot data-collection and training facilities. China alone has more than 100 publicly disclosed embodied AI data centers and training bases. and like the NEURA's RoboGym with TUM in Germany, Apptronik's Robot Park in the US, and Tesla's Optimus Academy are all part of this push…
On the other side, NVIDIA, Google DeepMind and World Labs are pushing world models, synthetic data and simulation to expand the training pool. NVIDIA generates synthetic robot trajectories from human demonstrations. Google's Gemini Robotics 2.5 combines real-world demonstrations with simulated practice, while World Labs' Marble generates 3D environments for robot training and testing.
Then there's another layer: companies like Memories AI are building platform-based, one-stop data infrastructure to collect, organize and supply first-person real-world data at scale.
These three routes may look like different technical bets, but I think they will increasingly converge.We're already seeing this in models like Google's Gemini Robotics 2.5, NVIDIA's GR00T 2 and Skild AI's S1. They all bring together different combinations of human egocentric video, wearable demonstrations, robot teleoperation and simulation.
The boundaries between these data pipelines are becoming less distinct.
And there's another side to this race(this sounds rather unhumanistic)--access to real industrial environments, frontline workers, skilled technicians and service professionals around the world. Their practical experience is an enormous source of knowledge that robots need to learn from.
I've said this more than once…
This really is the gold rush for Physical AI data.
But data is not the goal.
Humanoid robots: I need more, much more data…
I just watched an interview with the Memories AI team. One thing really stood out to me: by next year, Physical AI data collection could be entering the 10-million-hour range.
The entire field is desperately hungry for real-world data.
Just a few months ago, the egocentric data volumes being discussed across the industry were still around 1 million hours. More recently, we've been seeing figures to 2 million hours.
But that's still not enough. Even 10 million hours may not be enough...
Across the Pacific, at the World Internet Conference in Wuzhen, China, Li Shuai, deputy director of the AI Center at China's Ministry of Industry and Information Technology's Fifth Electronics Research Institute, put the gap into perspective:
The core supply-demand gap in embodied AI data is roughly two orders of magnitude. Effective data stock is at the million-hour level, while leading companies estimate their demand at 100 million hours.
It's pretty clear that demand for data is far ahead of supply at the upstream end of Physical AI. This is becoming a genuine must-have business.
Look at what's happening--
On one side, companies are building dedicated humanoid robot data-collection and training facilities. China alone has more than 100 publicly disclosed embodied AI data centers and training bases. and like the NEURA's RoboGym with TUM in Germany, Apptronik's Robot Park in the US, and Tesla's Optimus Academy are all part of this push…
On the other side, NVIDIA, Google DeepMind and World Labs are pushing world models, synthetic data and simulation to expand the training pool. NVIDIA generates synthetic robot trajectories from human demonstrations. Google's Gemini Robotics 2.5 combines real-world demonstrations with simulated practice, while World Labs' Marble generates 3D environments for robot training and testing.
Then there's another layer: companies like Memories AI are building platform-based, one-stop data infrastructure to collect, organize and supply first-person real-world data at scale.
These three routes may look like different technical bets, but I think they will increasingly converge.We're already seeing this in models like Google's Gemini Robotics 2.5, NVIDIA's GR00T 2 and Skild AI's S1. They all bring together different combinations of human egocentric video, wearable demonstrations, robot teleoperation and simulation.
The boundaries between these data pipelines are becoming less distinct.
And there's another side to this race(this sounds rather unhumanistic)--access to real industrial environments, frontline workers, skilled technicians and service professionals around the world. Their practical experience is an enormous source of knowledge that robots need to learn from.
I've said this more than once…
This really is the gold rush for Physical AI data.
But data is not the goal.
Learning from human work can improve humanoid dexterity.
@memories_ai turns first-person video into searchable Physical AI training data, tracking each hand’s actions.
High-quality curated data at scale could shape humanoid robots performance.
Learning from human work can improve humanoid dexterity.
@memories_ai turns first-person video into searchable Physical AI training data, tracking each hand’s actions.
High-quality curated data at scale could shape humanoid robots performance.
I've watched this toothpaste-dispensing demo several times, and it got me thinking about what a truly capable home humanoid robot will need.
It needs to understand human intent, recognize objects, and know how to interact with them through touch.
A robot shouldn't just see a toothpaste tube. It needs to know how much pressure to apply, how the tube deforms, and when to adjust its grip and force.
This matters when helping a child or an older adult with limited mobility squeeze toothpaste without the tube slipping out of their hands and landing on the floor. (I'm sure most of us have done that at some point. Hahah)
Across Physical AI, egocentric and human activity datasets are already reaching millions of hours. Larger and more diverse human experience is helping robots learn and generalize better.
LingBot-Touch demonstrates what's possible with just 4,983 hours of tactile pretraining data.
Now imagine tactile datasets growing to hundreds of thousands or even millions of hours.
Could tactile intelligence follow a similar scaling curve? I don't know.
But combining richer tactile experience with vision, language and memory could fundamentally change how home robots understand and interact with the people around them.
Perhaps this is how home humanoids will eventually learn to understand the different needs of every family member, from elderly people,children to even pets.
I've watched this toothpaste-dispensing demo several times, and it got me thinking about what a truly capable home humanoid robot will need.
It needs to understand human intent, recognize objects, and know how to interact with them through touch.
A robot shouldn't just see a toothpaste tube. It needs to know how much pressure to apply, how the tube deforms, and when to adjust its grip and force.
This matters when helping a child or an older adult with limited mobility squeeze toothpaste without the tube slipping out of their hands and landing on the floor. (I'm sure most of us have done that at some point. Hahah)
Across Physical AI, egocentric and human activity datasets are already reaching millions of hours. Larger and more diverse human experience is helping robots learn and generalize better.
LingBot-Touch demonstrates what's possible with just 4,983 hours of tactile pretraining data.
Now imagine tactile datasets growing to hundreds of thousands or even millions of hours.
Could tactile intelligence follow a similar scaling curve? I don't know.
But combining richer tactile experience with vision, language and memory could fundamentally change how home robots understand and interact with the people around them.
Perhaps this is how home humanoids will eventually learn to understand the different needs of every family member, from elderly people,children to even pets.
1/
Twist a bottle cap with your eyes closed. Your fingertips already know when the cap is about to slip.
Humanoid robots will need that kind of touch before their hands can do real work. Robbyant (@robbyant_brain) just released LingBot-Touch, a model that helps robot hands make sense of what they touch.
1/
Twist a bottle cap with your eyes closed. Your fingertips already know when the cap is about to slip.
Humanoid robots will need that kind of touch before their hands can do real work. Robbyant (@robbyant_brain) just released LingBot-Touch, a model that helps robot hands make sense of what they touch.
Gemini Robotics 2.5 is now on the factory floor.
Google DeepMind released the new VLA model. In a POC with Apptronik and Mercedes-Benz, Apollo 2 picked automotive brackets from bulk bins and sorted them into trays in the right sequence for assembly. It hit 96% success after a few weeks of post-training, with almost no drop from the lab to the line.
The same model was also tested on 200+ tasks, including tying bows, serving food with tongs, and pipetting.
Gemini 4 Argon handled most of the practice by turning real camera views into digital twins, running thousands of simulated runs, and reviewing failure replays to tighten the training.