16 parallel runs of Gemma 4 26B A4B on a single NVIDIA DGX Spark!
Pushing 18 tok/s per instance and a 300 tok/s aggregate. It can even hit 32 parallel runs.
This level of concurrency highlights how efficient the architecture is.
GLM-5.1 is here!
Try it on OpenClaw🦞🦞🦞
ollama launch openclaw --model glm-5.1:cloud
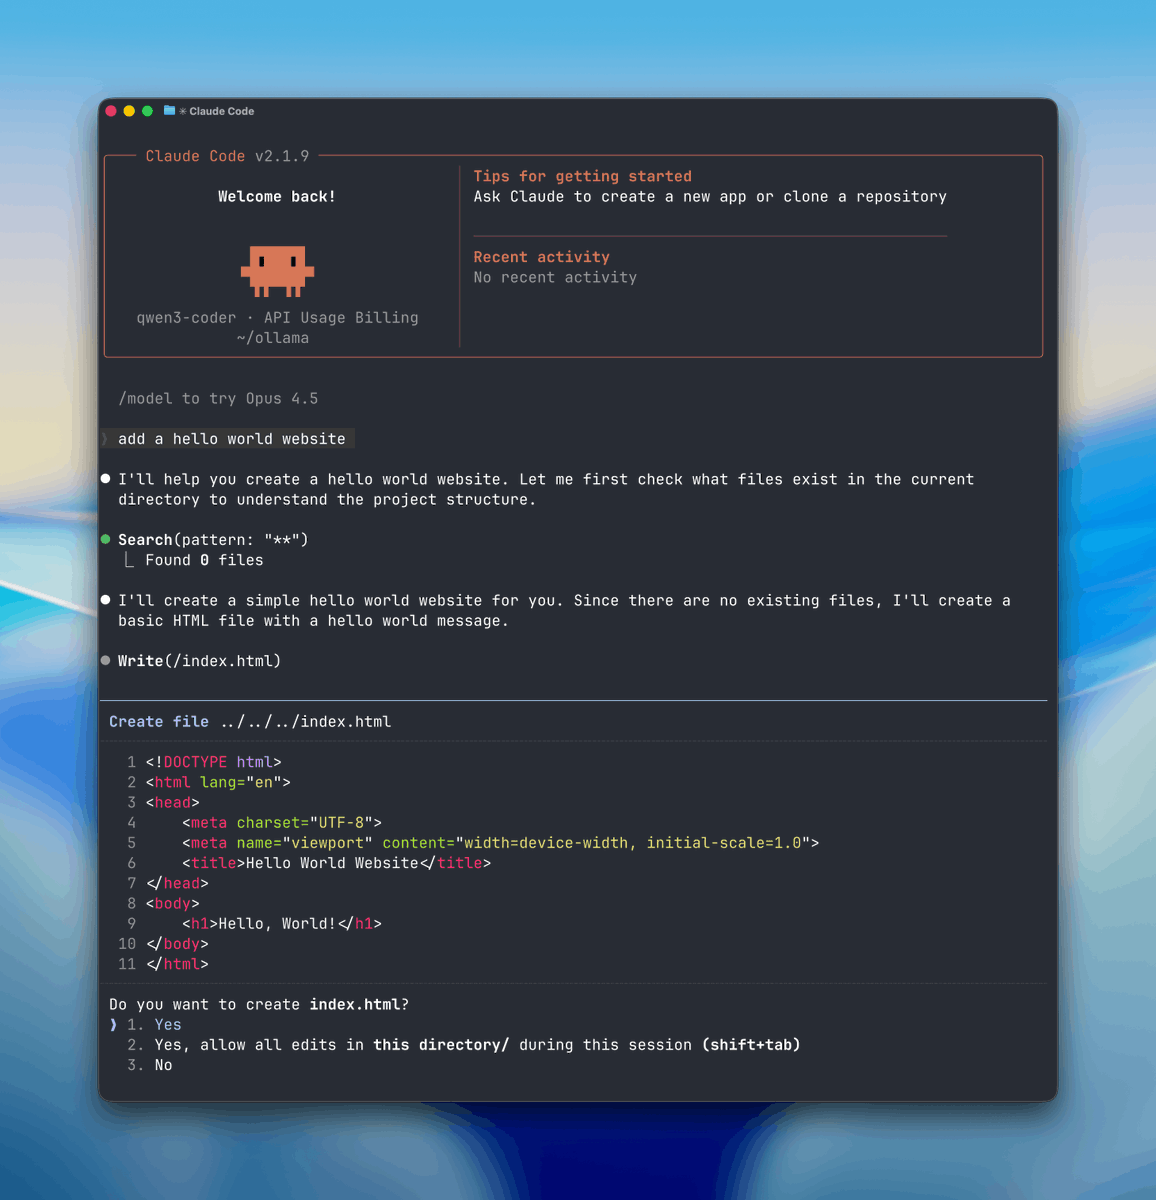
Claude Code
ollama launch claude --model glm-5.1:cloud
Chat with the model
ollama run glm-5.1:cloud
ollama launch pi --model kimi-k2.5:cloud
Ollama can now launch Pi, the coding agent that powers OpenClaw.
Designed to be a minimal coding harness that can be adapted to your workflows to create your own coding agent.
Comes bundled with powerful primitives to build on, and can be extended with extensions, skills, prompt templates, and themes.
All Pi packages work with Pi & Ollama, making it infinitely customizable for different tasks and use cases.
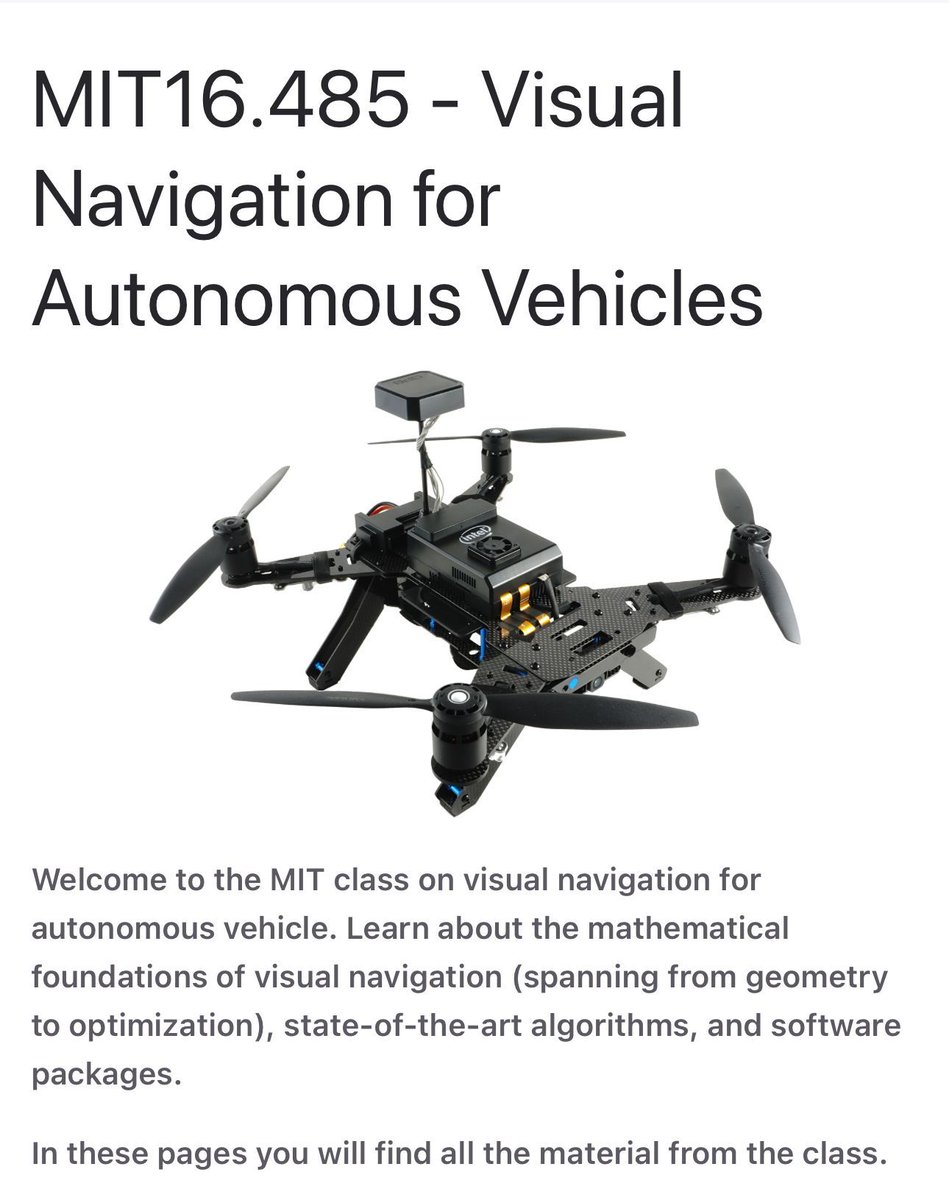
A full MIT course on visual autonomous navigation.
If you work on robotics, drones, or self-driving systems, this one is worth bookmarking‼️
MIT’s Visual Navigation for Autonomous Vehicles course covers the full perception-to-control stack, not just isolated algorithms.
What it focuses on:
• 2D and 3D vision for navigation
• Visual and visual-inertial odometry for state estimation
• Place recognition and SLAM for localization and mapping
• Trajectory optimization for motion planning
• Learning-based perception in geometric settings
All material is available publicly, including slides and notes.
📍https://t.co/HxdJKYIgsf
If you know other solid resources on vision-based autonomy, feel free to share them.
—-
Weekly robotics and AI insights.
Subscribe free: https://t.co/dsa6wcvq6n
Thrilled for #SciPy2025! As an active open-source contributor, I'm excited to share my work and learn from fellow developers. See you there! https://t.co/dY5OxxVM3Q
🌟Registration is open! 🐝
Join us for Beam Summit 2025 in NYC this July 8 & 9th, 2025 to bridge the data streams using Beam! Learn more about its ability to seamlessly integrate with Apache Kafka, Apache Iceberg, and Machine Learning. Register now! 🙌 (link to registration)
Have you ever wished to view the world from a completely new perspective? This thread on cool maps is here to blow your mind.
1. The Mississippi River and its tributaries
Today on the blog, we discuss how we improved the probabilistic reasoning capabilities of LLMs. By incorporating real-world context and simplifying assumptions, we show that these models can make more accurate inferences about distributions. Learn more at: https://t.co/aJC436vcKf