[ICRA '25] BEINGS: Bayesian Embodied Image-goal Navigation with Gaussian Splatting
Contributions:
• Reformulating ImageNav as an optimal control problem and solving it using a Monte Carlo-based MPC.
• Introducing 3D Gaussian Splatting (3DGS) as a scene
prior to enable efficient prediction of future observations and enhance ImageNav.
• Reducing data dependency and allowing dynamic ad-
justment of ImageNav strategies using Bayesian updates informed by real-time data.
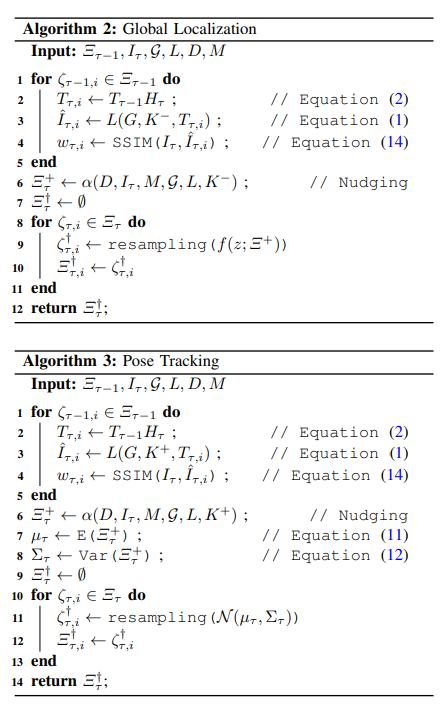
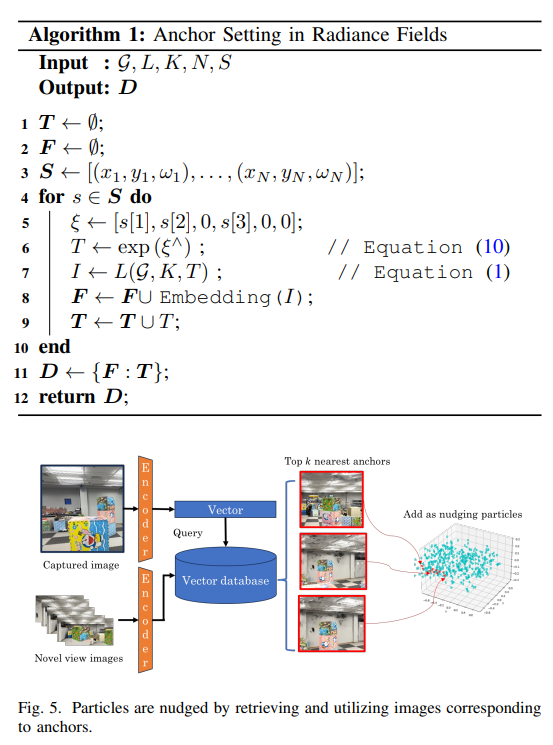
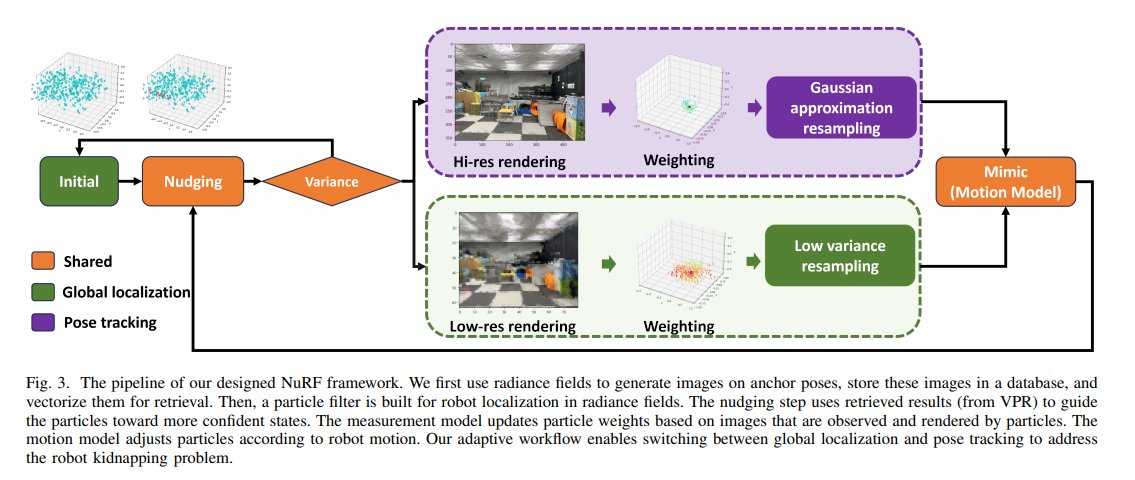
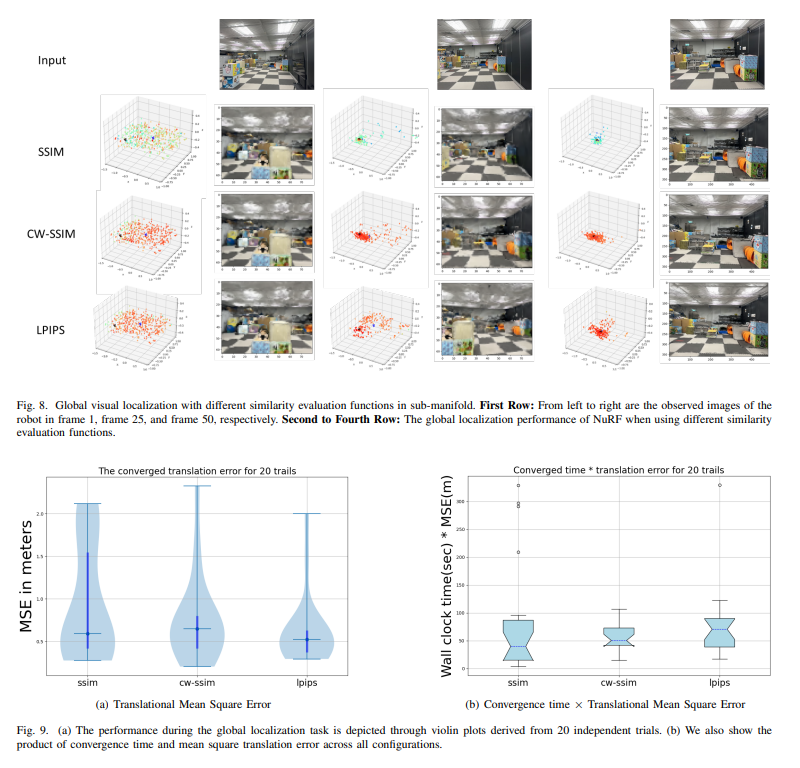
NuRF: Nudging the Particle Filter in Radiance Fields for Robot Visual Localization
Wugang Meng, Tianfu Wu, Huan Yin, Fumin Zhang
tl;dr: visual place recognition for nudging and adaptive scheme for both global localization and pose tracking
https://t.co/g59ZxwAFPl