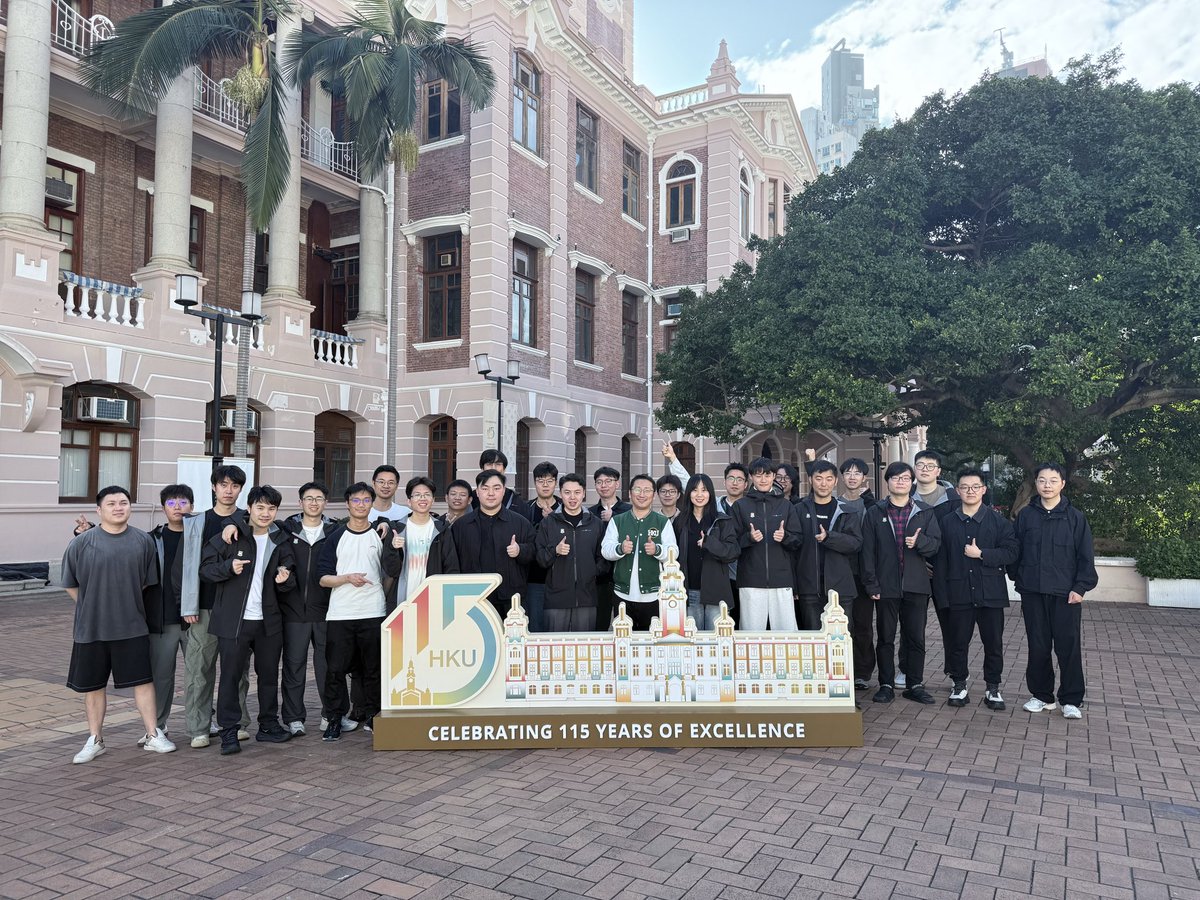
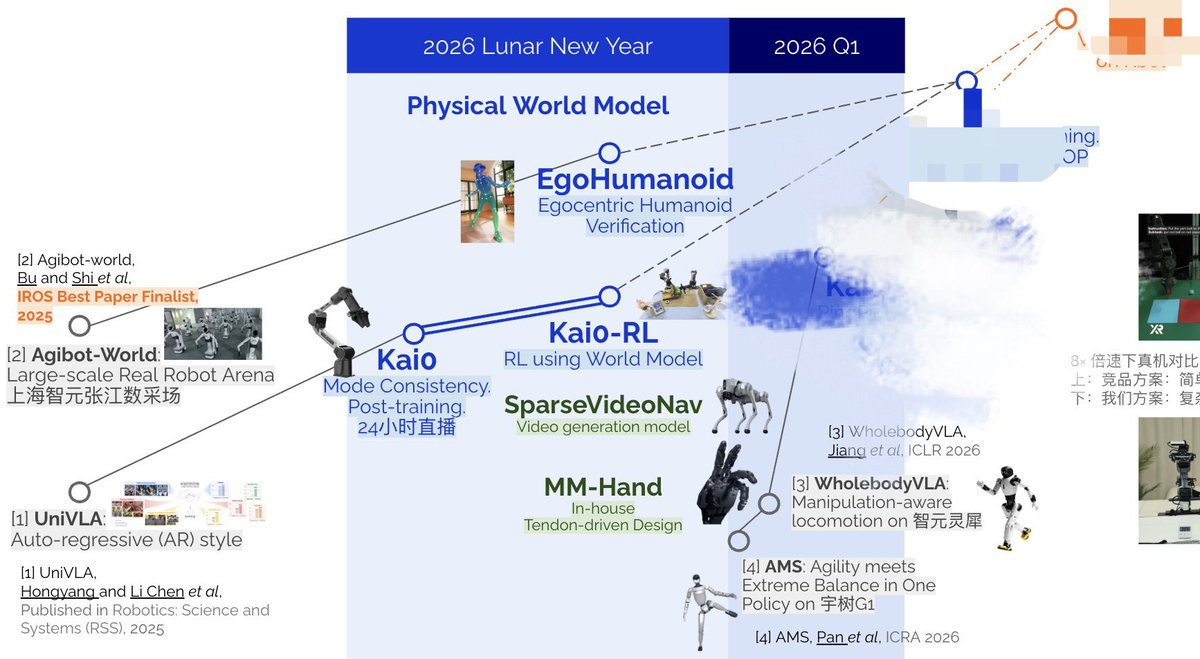
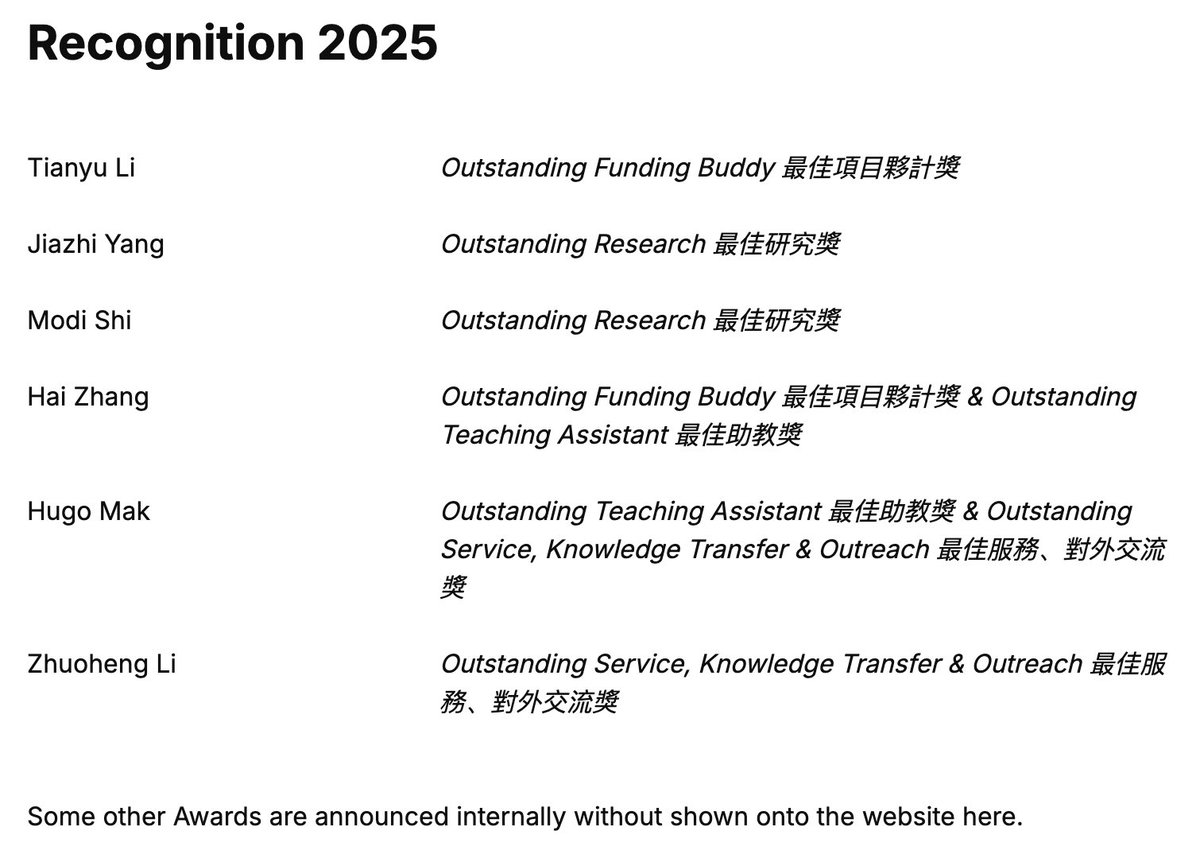
📣 #Recognition#ResearchAward As we usher in the Year of Horse, our team recognizes outstanding members from the past year in the exceptional contribution of areas. Congratulations!!! Let’s rock ‘n’ roll in 2026 🕶️🍾🎆🥂#opendrivelab
Proud to co-organize the AlpaSim E2E Closed-Loop Challenge with @kesai_labs and NVIDIA’s ASPIRE Group. This post traces the journey from NAVSIM to photorealistic closed-loop evaluation—and our shared effort to make progress in autonomous driving measurable. Learn more ↓
Full episode dropping soon!
Geeking out with @idomihs on EgoHumanoid: Unlocking In-the-Wild Loco-Manipulation with Robot-Free Egocentric Demonstration https://t.co/NooyUn4vXN
Co-hosted by @micoolcho@DJiafei
Huge shout-out to our amazing organizing team @2318hhhz@wongfaikit@lucy_x_shi@smch_1127 Yasemin_Bekiroglu @francislee2020 — this wouldn't have happened without you! 🙌
📺 Our workshop recap is now live: RSS 2026 | Towards Robust Execution of Long-Horizon Whole-Body Control Tasks
Catch the full playlist here 👇
https://t.co/VnlQ01utRn from @YouTube
#rss226 #WholeBodyIntelligence #embodiedAI
🚀 Excited to announce our real world VLN dataset !
📦 Human first-person collected indoor & outdoor & night.
🏆 LARGEST to date.
Check it out now on Hugging Face and accelerate your real world navigation research!
👇 🔗 https://t.co/qo7cgrGT7S
#EmbodiedAI#VLN
Sydney-bound for #RSS2026, and not gonna lie, we’re buzzing! 🔥
On our slate:
https://t.co/2UsSCILPcw
🎤 Dr. Hongyang Li — Early Career Spotlight
📄 Two papers we're proud of: RISE & EgoHumanoid
🤖 A humanoid doing real work on the floor - July 13th Morning Workshop
Full rundown + where to find us 👇
https://t.co/H7sMKj9jTJ
Come have a yarn.
#EmbodiedAI #WholebodyIntelligence #VLA #WorldModels #Sydney #ICC
Sydney, come sundown. 🌃
OpenDriveLab x @archon_robotics are throwing an afterparty!
TopTalents for Embodied AI, a social mixer at W Sydney, harbour views, golden hour, and the people building the next gen of Embodied Intelligence.
📅 Jul 14 · 7–10PM
📍 W Sydney
🎟️ Apply: https://t.co/zihfBy0E9e
#RSS2026 #EmbodiedAI #Sydney #WorldModel #FoundationModel
🚀 Join us at the #CVPR 2026 Workshop:
From Labs to Life: Embodied Intelligence in the Wild
(https://t.co/XORtHTzefX)
As embodied AI moves into the real world, we ask: how can agents perceive, reason, and act reliably in the wild?
Featuring invited talks from: Hao Su, Zhiyu Huang, Jiahui Lei, Yilun Du, Rika Antonova, Jiatao Gu.
📅 9:00 AM - 5:30 PM, June 3, 2026
📍 Four Seasons 1, Colorado Convention Center.
#CVPR #EmbodiedAI #PhysicalAI #Robotics
🎉 Excited to share our recent work SimScale, which has been accepted to CVPR 2026 as Oral presentation!
🤖Can we improve policies via scaling synthetic experience?
😢End-to-end driving policies struggles on safety-critical & OOD scenarios that are rare in human logs.
To tackle this, SimScale features:
🏗️ A scalable simulation pipeline synthesizes diverse, high-fidelity reactive driving scenarios upon existing logs. (See attached visualization as one synthetic data sample).
🚀 With pseudo-expert demonstrations, Sim-real co-training boosts LTF / DiffusionDrive / GTRS-Dense, up to +8.6 EPDMS on navhard, +2.9 on navtest.
🔬 Performance scales smoothly by adding simulation data alone, with no extra real-world data needed.
Joint effort by @HCTian713, @francislee2020, @OpenDriveLab, @sephy_li
📢📢📢 Call for Contributions @ RSS 2026
Towards Robust Execution of Long-Horizon Whole-Body Control Tasks
🧑💻👩💻🧑💻 Speakers:
- Javier Alonso-Mora (TU Delft)
- Leslie Pack Kaelbling (MIT)
- Shan Luo (King's College London)
- Hamidreza Kasaei (University of Groningen)
- Roberto Martín-Martín (UT Austin)
- Fan Shi (NUS)
📝📝📝 Call for Contributions:
We invite researchers to share their work with the community through submissions to the workshop in a variety of formats beyond traditional papers, including reports, demos, video, and etc. Submissions may include research papers or reports, but we equally welcome alternative formats such as videos demonstrating systems in action, demos, interactive artifacts, or other creative presentations of research ideas. We particularly welcome ongoing, preliminary, or exploratory work.
🌍🌍🌍 Website:
https://t.co/qIdp1JDVqj
#RSS2026 #AI #Embodied
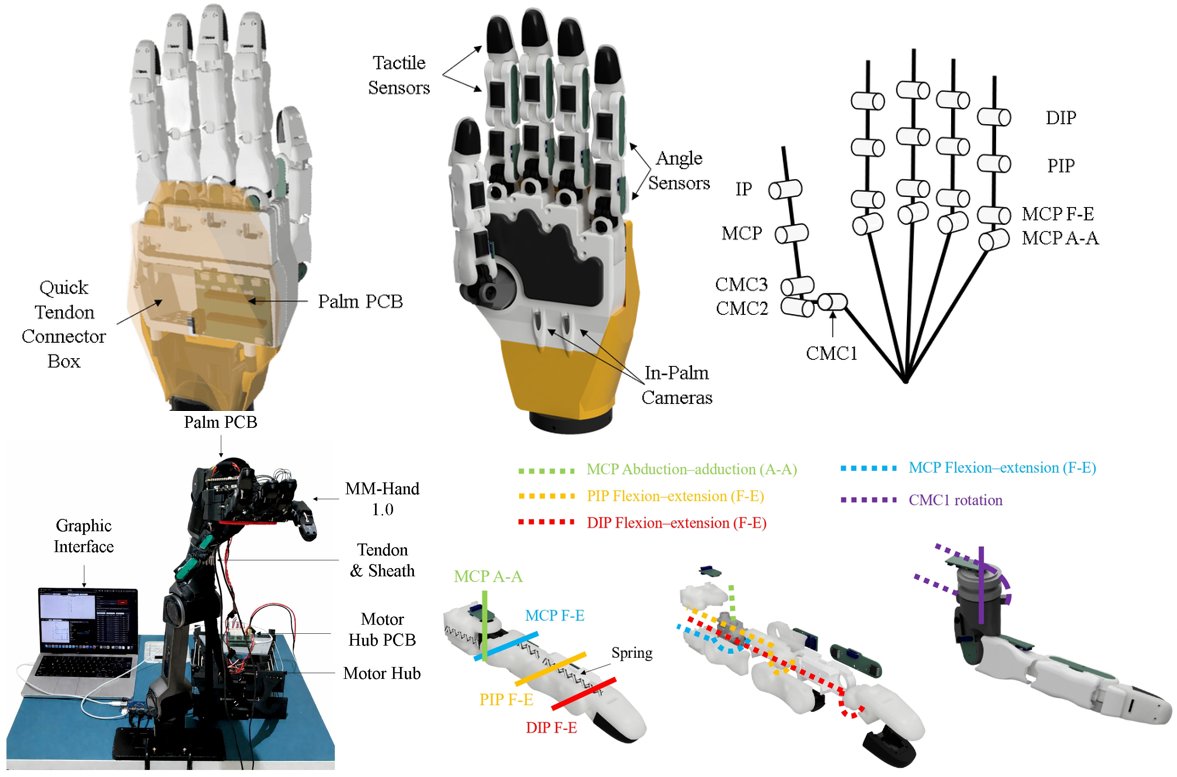
🚀 MM-Hand 1.0 Tech Report released: a 21-DoF multi-modal modular dexterous robotic hand with remote tendon-driven actuation.
Motors are relocated outside the hand, freeing space for tactile sensors, joint encoders, in-palm stereo vision, and maintainable modular fingers.
MM-Hand achieves 25N fingertip force through 1m tendon-sheath transmission and supports closed-loop joint control for dexterous manipulation research.
Paper: https://t.co/K7L7BaW8uS
Page: https://t.co/8QpHEZeTQi
#Robotics #DexterousHand #EmbodiedAI
【5/5】That's all!
Hope #WorldEngine brings you fresh insights into post-training infrastructure for Physical AI.
If you find it useful, please give it a star 🌟!
Github: https://t.co/tGfsaQm91z
Huggingface: https://t.co/mYNC9MWqAZ
Project Page: https://t.co/c2ikAQjddE
Teamwork from @OpenDriveLab
Shoutout to @sephy_li@ilnehc@francislee2020@CaojunWang@GeorgeL94133026 📢
【1/5】🌍 WorldEngine: Towards the Era of Post-Training for Physical AI
🎯 A post-training framework for Physical AI that systematically addresses the long-tail safety-critical data scarcity problem in autonomous driving.
🧱The missing infrastructure for Physical AI post-training in AD. Open-source. Production-validated.
https://t.co/tGfsaQm91z
#WorldEngine #PhysicalAI #OpenDriveLab