We trained a robot policy to run at ~4x faster than the teleop data they were trained on. It held >95% success rate across 500 real-robot runs. Here’s a thread on our first blog at https://t.co/OE1dgDUduB 🧵
Something unreal happened yesterday.
Our robot learned how to close a dishwasher by itself.
The robot learned this purely from deployment data. The robot had never seen this particular task before. Every time, a human had to step in and finish the task.
Over time, with the deployment experience, the robot learned to do it on its own. Now, as it does more of this, it will speed itself up. @PranayGupt97167 wrote a nice article about this on X
We are deploying at scale across kitchens. If that sounds interesting, reach out to us!
Yeok landed in San Francisco and, two days later, flew to Taiwan to get Caldera’s motors built.
He slept in bunk beds with factory workers, took cold showers, and stayed focused on getting the job done.
He and Raghav met through EF. Now they’re building Caldera with one goal: to build the best robotic manufacturing company in the world.
Next week, they’ll be pitching at Demo Day in San Francisco.
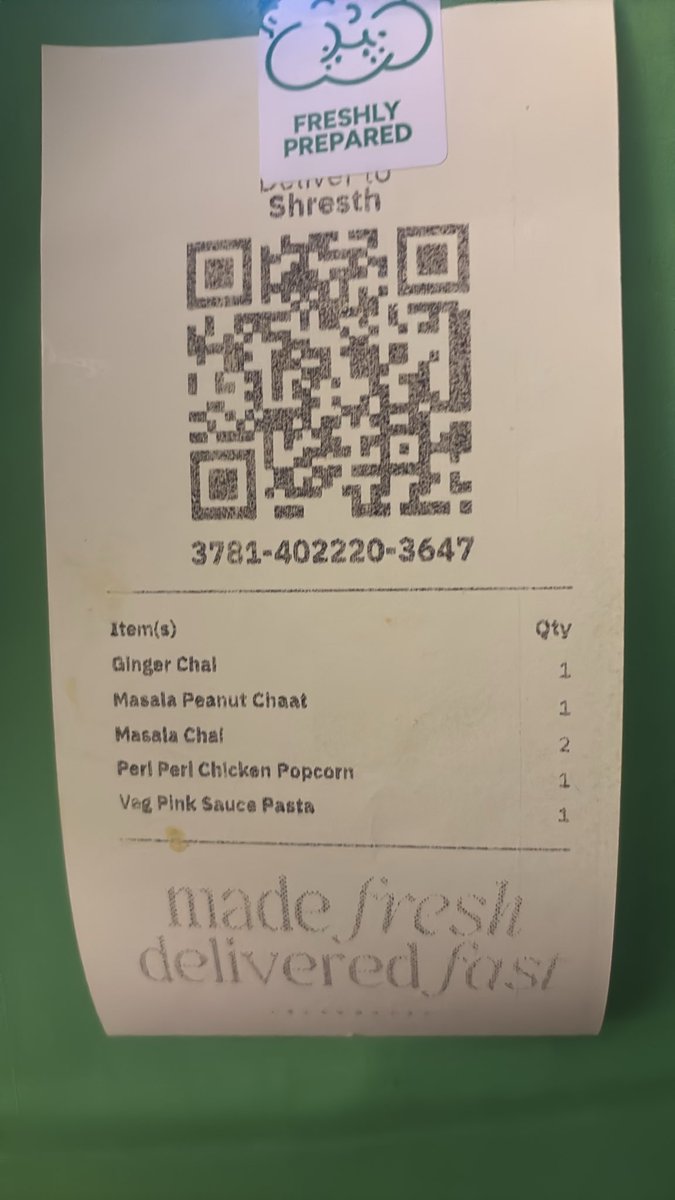
Ordered veg pasta, got chicken ate some.
On the auspicious day of Paryushan Parva !
I really trusted swish but this is such a huge let down.
This has hurt my religious beliefs ! Is this the kind of service you want to provide @ujjwal_sukheja@aniketshah30@fssaiindia !
We trained a robot policy to run at ~4x faster than the teleop data they were trained on. It held >95% success rate across 500 real-robot runs. Here’s a thread on our first blog at https://t.co/OE1dgDUduB 🧵
5/5
All of this combined, our MTT (median task time) for bimanual handover dropped from 37.3sec to 9.4sec at >95% success rate running π0.5.
Full writeup: https://t.co/w8BHULAMKh
Google having the worst ai model is genuinely insane considering they had the most data, compute, resources and they invented the transformer architecture