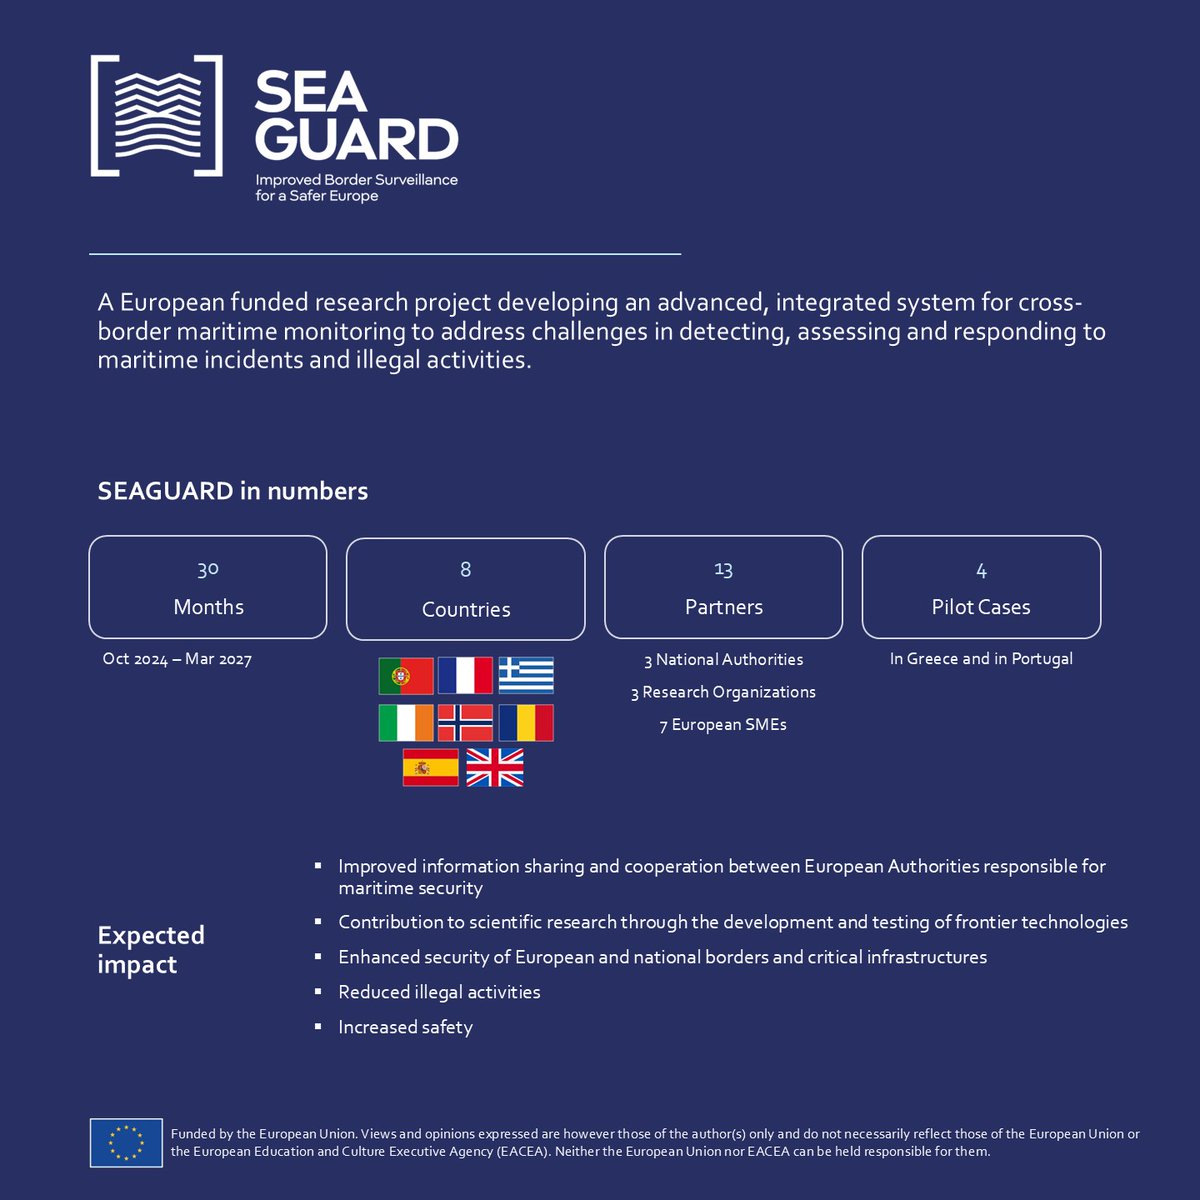
The Seagurd Project is a European-funded research initiative focused on enhancing maritime border surveillance by developing an advanced integrated cross-border
Excited to share the publication of "A Case Study using Model Predictive Control and Dubins Path Method to Enhance Autonomous Surface Vehicle Docking" at https://t.co/aYklXZGuPm
Read also https://t.co/0lbt1ihx5H
#MarineRobotics#AutonomousDocking#SEAGUARD#INESCTEC
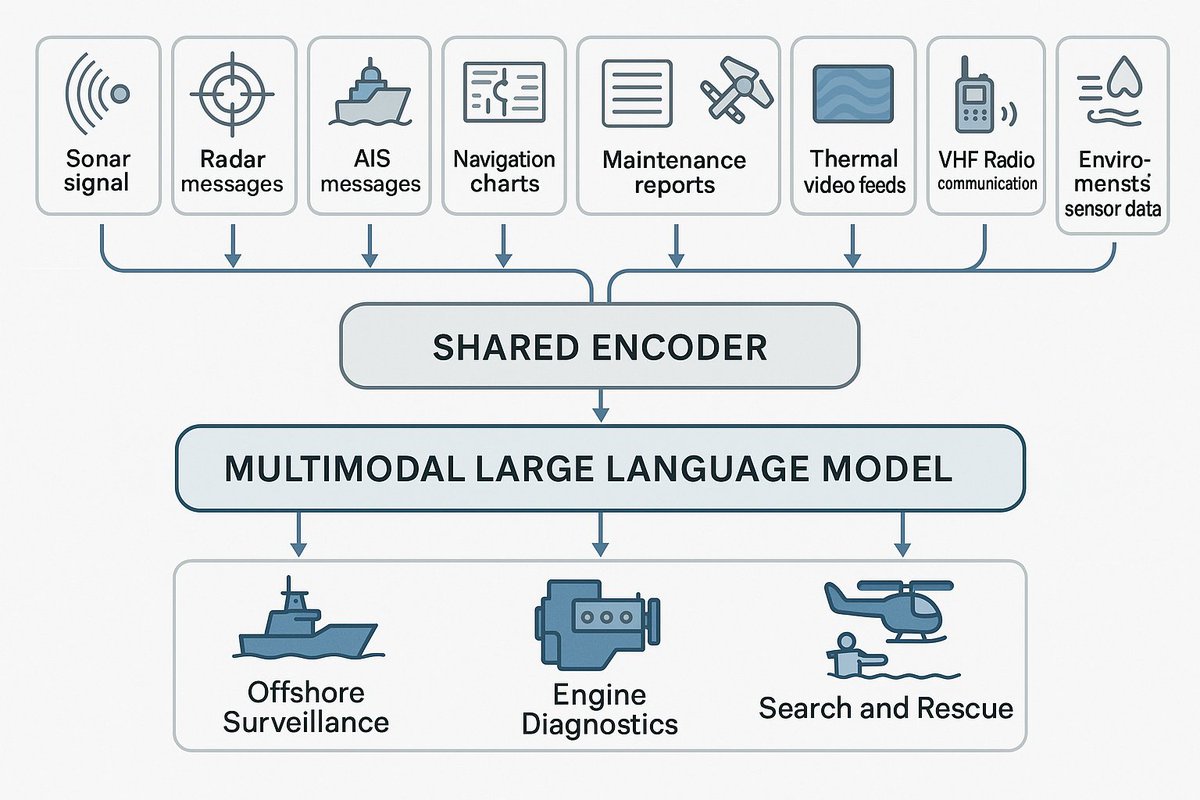
“Toward Intelligent Data and Security in Maritime Environments: A Vision for Multimodal Foundation Models” paper published. Discover the work https://t.co/pSZ51sXaRE
Take a look at project newsletter, highlighting the key activities, milestones, and achievements from the first half of 2026. Thank you to everyone contributed to this journey so far.
https://t.co/JzzDCtqg6w
Linkedin: https://t.co/iHMLmOKlpU
#HorizonEurope#MaritimeSecurity
Prof. Capt Zakirul Bhuiyan of Solent University presented SEAGUARD at #EASRF2026, contributing to discussions on autonomous shipping, AI-driven systems, and maritime innovation.
https://t.co/MUmhNvnZjb
#HorizonEurope#MaritimeAI#TheSeaguardProject
Prof. Nuno Cruz presented at Oceans 2026 in Sanya: A Case Study using Model Predictive Control and Dubins Path Method to Enhance Autonomous Surface Vehicle Docking. https://t.co/3dbsNyuXmg
#HorizonEurope#TheSeaguardProject
BENE Cercetare took part in BSDA 2026 in Bucharest, presented the SEAGUARD project and exchanged insights on cutting-edge research developments in maritime security. Stay tuned for what’s next! https://t.co/53CuEAjGNi
#HorizonEurope#MaritimeSecurity#TheSeaguardProject
USN presented the paper “Toward Intelligent Data and Security in Maritime Environments: A Vision for Multimodal Foundation Models” at IEEE IDS 2026!
#HorizonEurope#MaritimeSecurity#USN#TheSeaguardProject
https://t.co/SK4oehFLet