Sharpa is an AI robotics company dedicated to developing ultra-high performance robots and core components.
We Manufacture Time by Making Robots Useful.
Robots don't just need to see the world. They need to feel it.
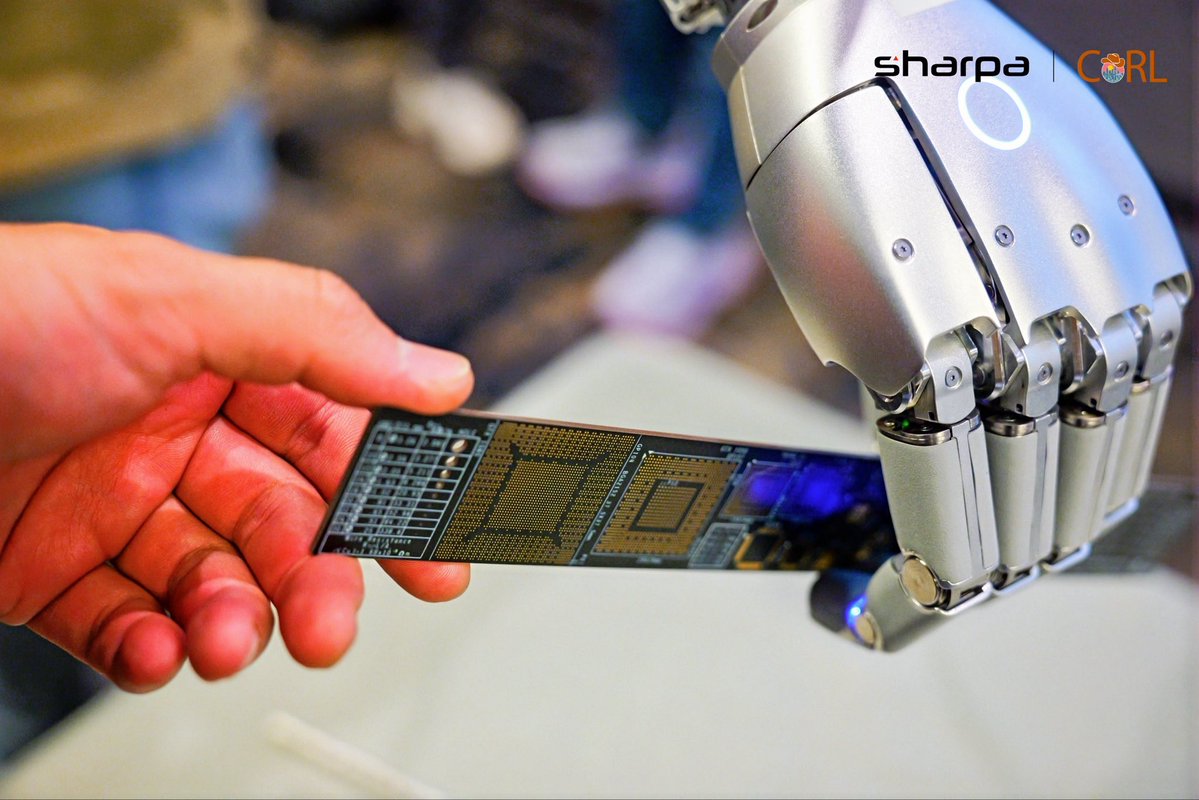
A light touch on Sharpa D01's body is enough to trigger a response. Its whole-body electronic skin detects physical contact and enables the robot to react to interactions beyond what cameras alone can perceive.
A closer look at the tactile system behind this capability:
- 100 Hz tactile sampling rate
- 0.2 N force resolution
- 10 mm spatial resolution
Touch gives robots another way to understand and interact with the physical world.
#CoRL2026 #Sharpa #Robotics #TactileSensing #ElectronicSkin #HumanoidRobotics #EmbodiedAI
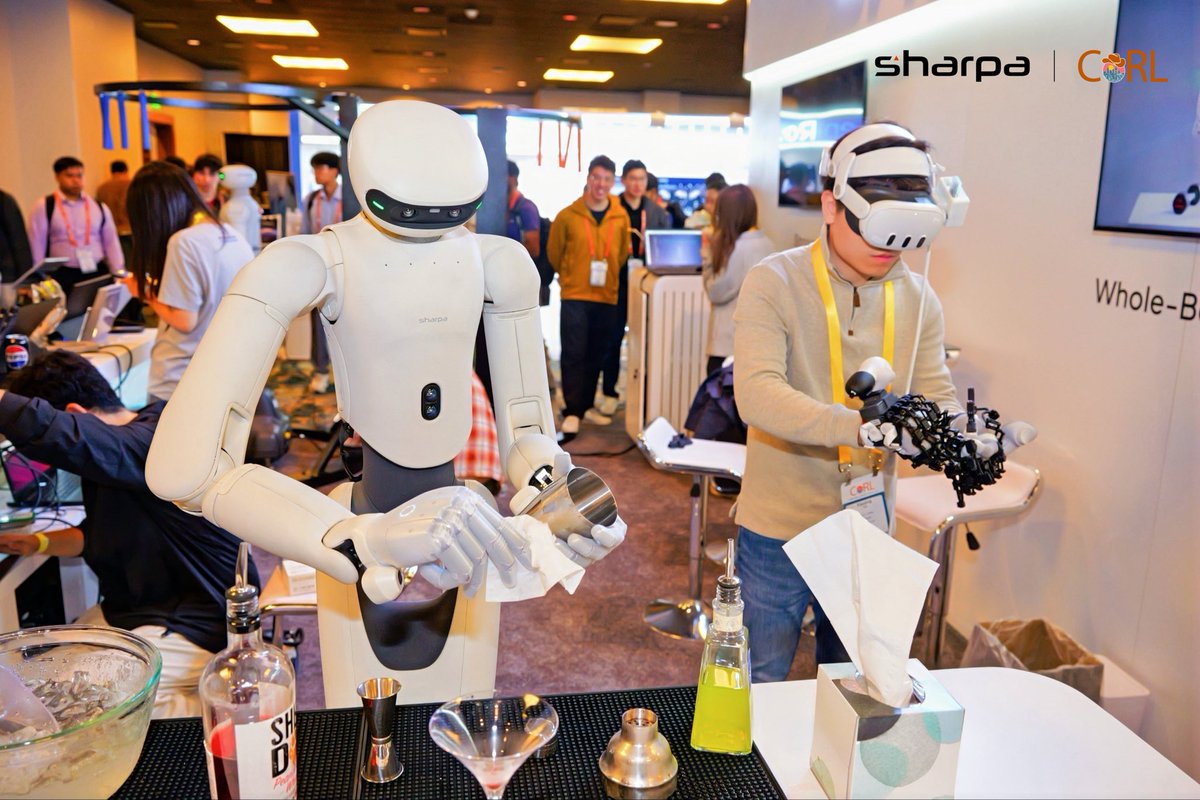
What does it take to make a robot bartender? A good sense of timing, precise movements, and a steady pour.
Watch AE01 translate the operator's hand movements into Sharpa D01's actions — picking up a container, pouring, and setting it down with controlled precision.
This is teleoperation in action: human movement translated into real-world robotic manipulation through Sharpa's 22-DoF hand-glove twin design.
#CoRL2026 #Sharpa #Robotics #Teleoperation #DexterousManipulation #EmbodiedAI
Putting Sharpa D01's speed and precision to the test with the Catch the Stick Challenge.
A random stick drop puts human and robotic reflexes to the test, with both racing to make the catch. Watch Sharpa D01 track the falling stick, move into position, and secure the grasp in a rapid, coordinated motion.
With a maximum end-effector speed of over 10.5 m/s and 0.2 mm repeatability, Sharpa D01 is built to handle both speed and precision.
#CoRL2026 #Sharpa #Robotics #DexterousManipulation #HumanoidRobotics #EmbodiedAI
Different teams. Different layers of robotics intelligence. The same pair of Sharpa Wave hands at #CoRL2026! 🤖
A few highlights from across the exhibition floor:
✨ @GoogleDeepMind — Gemini Robotics 2.5 powering autonomous manipulation across robotic platforms
🧠 @amazon — Advancing tactile learning, robot control, and humanoid manipulation
🦾 @GenrobotAI — Human motion capture and robot demonstrations with DAS Dex 2.0
⚙️ @microagi — Bringing agentic planning into robotic manipulation with Play2Perfect
From human demonstrations to intelligent policies and real-world execution, advancing embodied AI takes both smarter models and more capable hardware.
Proud to see Sharpa Wave dexterous hands helping turn robotic intelligence into physical action. 🦾
#CoRL2026 #Sharpa #Robotics #TactileSensing #ElectronicSkin #HumanoidRobotics #EmbodiedAI
Great to see more of NVIDIA's GR00T 2 in action! 🤖
Excited to be part of this project, with Sharpa's dexterous hands contributing to advanced robotic manipulation research.
From handling shipping labels to lighting a lab lamp, these multi-step tasks require precise grip adjustments and coordinated hand movements.
A closer look at how GR00T 2 brings learned skills into real-world robotic tasks.
Watch the hands—and then watch the whole job come together. This is GR00T 2. 💚
Cut a shipping label. Peel away the backing. Press it onto a box. Scan it.
Or pick up a match, strike it, light a lab lamp, and extinguish it in water.
Each sequence demands changing grips, careful contact, and coordination between two hands. What excites me is how GR00T 2 brings those abilities together:
Precision that lasts: Coordinating delicate manipulation and whole-body movement through tasks spanning 20+ steps and 5+ minutes.
Experience that carries over: Learning from human wearables and simulated practice, then transferring skills zero-shot to real robots.
Reasoning throughout the task: Frontier agents help plan the work, respond when execution goes wrong, and monitor safety.
Underneath is a world-action model that learns actions and their physical consequences together. Explore the research and demos.
We’re also giving builders more of the foundation: tools for simulation, annotation, and agentic control, hardware designs, and 100,000 hours of human video. GR00T 2 weights and adaptation recipes are planned for December. Release details.
Bring a task you wish a robot could handle. Let’s push what’s possible—build with us. 💚
#Robotics #PhysicalAI #OpenSource
What will it take to bring general-purpose robots into everyday life?
Our co-founder, Dr. David Li, joined CNN's Global Perspectives in Doha to discuss the future of robotics—from general-purpose intelligence and dexterous manipulation to how robots can enhance human productivity.
Here we laid out four things we believe about the next era of robots:
- One shared model, dataset, and physical architecture will allow robots to learn across many different tasks.
- Dexterous hand is the key interface: our world is built for people, robots need tactile, capable hands to use everyday tools and appliances.
- Automation is a way to lift overall productivity and shift how people spend their time, supporting people rather than replacing.
- Sharpa's mission is to return more time to people, so they can focus on family and the work they care about most.
Watch the full interview →
https://t.co/1in642JFSF
Credit CNN Global Perspectives @CNN
#CNNGlobalPerspectives #PhysicalAI #DexterousManipulation #Robotics #Sharpa #Humanoid
We’re hiring at #CoRL2026! 🚀
Great conversations, fresh ideas, and exciting opportunities in robotics.
Interested in building the future of dexterous manipulation and embodied AI? Come meet the Sharpa team!
📍 Room 302, Level 3
📅 Nov 9–11 | JW Marriott Austin
Let’s talk robotics, innovation, and your next career move.
🌐 https://t.co/wXJ3gA1AmU
Congratulations to @nvidia and the entire GR00T 2 team on the official launch!
Proud to see Sharpa's dexterous hands contributing to this milestone, enabling robots to perform precise, human-like tasks—from using scissors to handling delicate glass slides and operating a microscope.
Great to see GR00T 2 bringing advances in robot learning and dexterous manipulation together 🚀
Introducing GR00T 2: our most advanced, open System One model for robotics. It runs entirely on your robot’s onboard compute, fully untethered, and you own every weight of it. GR00T 2 features:
1. Long-horizon tasks: dexterous manipulation and whole-body control chained over 20+ steps and 5+ minutes, such as performing chemistry lab experiments or assembling model airplanes end to end.
2. X-Adapt: adapting from easy data sources (human wearables and simulation) and deploying zero-shot to diverse real robots.
3. Unified Cognition: native integrations with frontier agents for advanced physical reasoning, robust error recovery, and safety monitoring.
It's an open-source buffet! We are releasing not only the model weights and X-Adapt recipes (coming December), but also our agentic framework, simulation engine, annotation engine, hardware design, and even training data (100K hours, that's ~11 yrs of experience), all available today!
Everything that moves will be autonomous. Anyone can become a roboticist.
Lock in, build with us!
Deep dive in thread:
Thrilled to be at #CoRL2026 and proud to bring these demos to Austin!
On the Sharpa lineup:
🦾 D01 — Drop a stick for D01 to catch.
🖐️ W01 — Watch five fingers keep a pen spinning.
🧸 W02 — Try Catch the Toy as W02 mirrors your hand.
🍸 AE01 — See how an operator guides D01 to pour and mix drinks.
Which would you try first?
📍Catch us at Booth #400, Level 2, Griffin Hall.
🌐 https://t.co/wXJ3gA1AmU
Congratulations to the NVIDIA GEAR team on GR00T 2 — a world-action model that learns physics from human video and turns what it sees into real robot action. Dexterity is the hardest part of this release, and it was proven on Sharpa hands.
— 2,890 h of Sharpa W01 teleoperation in the pretraining mixture — the largest dexterous-hand share of the robot teleoperation.
— The 40% zero-shot → 95% five-shot result ran on a bimanual robot with two Sharpa W01 hands.
— Scaling curve: human video from 0% to 100% of the mixture lifts real-robot progress from 50% to 70% across 72 Dexter tasks.
Let's push the boundaries!
Human → Sim → Real: turning human videos into robot skills.
Join us at CoRL for “From Human Videos to Dexterous Robot Capability: A Hands-on Tutorial”! https://t.co/92R9yMjv6c
📅 Thursday, November 12, 2026 | 2:00–6:00 PM CST
📍 Hilton Austin, Salon D · Austin, Texas
We’ll share a detailed walkthrough of the complete end-to-end video-to-data pipeline that enables “Human → Sim → Real” adaptability for GR00T 2—from human demonstration videos through simulation to training data for real-world robot skills. https://t.co/LwhBs3yfO1
We’ll also feature:
• A panel on the future of robot learning from humans, exploring opportunities and open challenges.
• The announcement of the V2D Challenge winners, followed by presentations from the winning teams on their solutions.
Kudos to the panelists, instructors, and organizers bringing this tutorial to life!
Panelists:
• @Jeannette Bohg — Stanford University @leto__jean
• @Kuan Fang — Cornell University @KuanFang
• Yuting Ye — Meta
• Kaifeng “Alex” Zhang — Sharpa
• @Roei Herzig — UC Berkeley @roeiherzig
• Louis Lian — Lightwheel
• Javier Romero — Meta
• Yan Chang — NVIDIA @Dr_YanChang
Instructors: @zhu_xinghao, @Mrinal_Verghese, @bowenwen_me, Zeo Liu, @shalin_sj, @Naema Bhatti, and @_abraranwar .
Organizers: Xinghao Zhu, Yan Chang, Zixi (Zeo) Liu, Bowen Wen, Mrinal Verghese, Shalin Jain, John Welsh, Daniel Zou, Abrar Anwar, Naema Bhatti, Michael Lin, Kuan Fang, and Joydeep Biswas.
Thank you for sharing your expertise and making this hands-on learning experience possible!
Explore the agenda and join us: CoRL tutorial details.
#CoRL2026 #RobotLearning #PhysicalAI #GR00T #VideoToData #NVIDIA
Congratulations to the Robbyant team on the release of LingBot-Touch! By bringing together nearly 5,000 hours of real tactile data, the model establishes a unified framework for learning transferable tactile representations across sensors, robotic hands, and manipulation tasks, marking an important advancement in tactile intelligence.
We are proud that Sharpa Wave contributed to this research as a dexterous robotic hands partner. This collaboration demonstrates how advances in tactile intelligence, combined with real-world robotic capabilities, can push the boundaries of dexterous manipulation. Congratulations once again to the team on this impressive milestone!
What changes when robots can feel—not just see? 🤖✋
Meet LingBot-Touch, our open-source tactile foundation model towards dexterous manipulation, pretrained on nearly 5,000 hours of real tactile data.
Through unified heterogeneous tactile modeling, LingBot-Touch supports transfer across sensors, dexterous hands, tasks, and action models.
Watch it in action. 👇 #LingBot #EmbodiedAI #Robotics
Finally, we can release a bit of the work we have been doing at the DexHands team in Amazon FAR ❤️🔥
Pure RL, zero teleop, PICK ANYTHING
Come to Amazon Booth at CORL
(Sound on.)
In behavior cloning, we mastered how to learn robotics from "robot-complete" data – but what happens to data that is not so perfect? Intelligence is often about learning from incomplete references; to come up with a "story" given disparate datapoints. Our Pick Anything demo shows an ability of this sort: the policy learned human-like dexterity from absolutely no human-robot interactions, no teleop or handheld tool data, just letting humans be humans and robots be robots. How did we do this?
Learning from humans without actions is often reduced to a semantics problem, a fancy way to prompt the robot. What, if anything, can robots learn about the dynamics from them? RL for manipulation has the opposite problem – often we are stuck with "technically correct" solution that are nevertheless aesthetically unsatisfying. In Pick Anything, we found a way to unite the two in a way for dexterous manipulation that I personally find quite beautiful (and I can't wait to share the paper with you!) I believe what we have here is the key to human level dexterity for robots, and all of that without needing any real robot data whatsoever.
For this Monday/Tuesday, you can visit our demo booth at CoRL (Griffin hall, demo 12) and ask me more questions! It's a labor of love from my past year of work, and I'm very excited to be finally able to talk about it.
Robots that learn should generalize. Locomotion should show generalization across terrain; manipulation across object categories. Here is a video of “Pick Anything”, demonstrating human like grasps for 66 different objects, ranging in size and shape from air pods to dumbbells to pipe wrenches, using a *single* policy. The system uses the stereo camera head for vision (no wrist cameras) & Sharpa Wave hands for manipulation. It was trained using video and RL (zero teleoperation data). This is research from our Dex-Hands team at Amazon FAR and we will be doing live demos of the system at CoRL 2026 ( Demo 12, Nov. 9 &10). Please come by!
Austin, here we come 🤖
Sharpa will be at #CoRL2026 — find us at Booth #400 (Griffin Hall, L2, JW Marriott), Nov 9–11.
Plenty of live demos, dexterous-manipulation workshops, and an on-site recruitment session!
See you there!
#Sharpa#CoRL2026#Robotics #DexterousManipulation #Hiring
Congratulations to the AW-0 team on connecting code-based planning, future prediction, and robot control in one agentic world action model.
Validated with dual 22-DoF Sharpa dexterous hands, AW-0 takes on contact-rich tasks including dealing poker, flipping a scoreboard, and solving a Rubik’s Cube.
Excited to support the bridge from reasoning to real-world dexterity!
#Sharpa #EmbodiedAI #RobotLearning #DexterousManipulation #DexterousHand
We're excited to introduce AW-0: Agentic World Action Models! 🤖 (0/8)
The first World Action Model that plans in code, predicts the future, and controls the robot—all in one generative model.
AW-0 jointly generates:
🧠 Code - explicit skill calls, object arguments, and control flow
🎥 Future video - predictive visual dynamics
🦾 Robot actions - continuous motor control
All three are generated together through joint denoising, letting semantic plans directly shape both predicted futures and robot behavior, with:
🤝 Hybrid execution — generated programs can also run directly through perception and control APIs
⚡ Just 40 ms of additional inference latency over the base WAM on an RTX 5090
📚 Pretrained on ~3,000 hours of robot + human demonstrations
One model for planning, prediction, and execution.
🌐 Project: https://t.co/SkQY4O8RlS
📄 Paper: https://t.co/xmcdLxX8Bu
💻 Code: https://t.co/zWKuhEJCDk
🤗 Model: https://t.co/DOkQB27QGm
🧵 How it works—and what we found ↓
From simulation to reality. 🤖
Sharpa's dexterous hand is featured in NVIDIA's latest Into the Omniverse episode, showcasing how AI agents and simulation are accelerating the future of physical AI. @nvidia
Proud to be part of the journey from virtual worlds to real-world dexterity!
#PhysicalAI #NVIDIA #Robotics #Sharpa