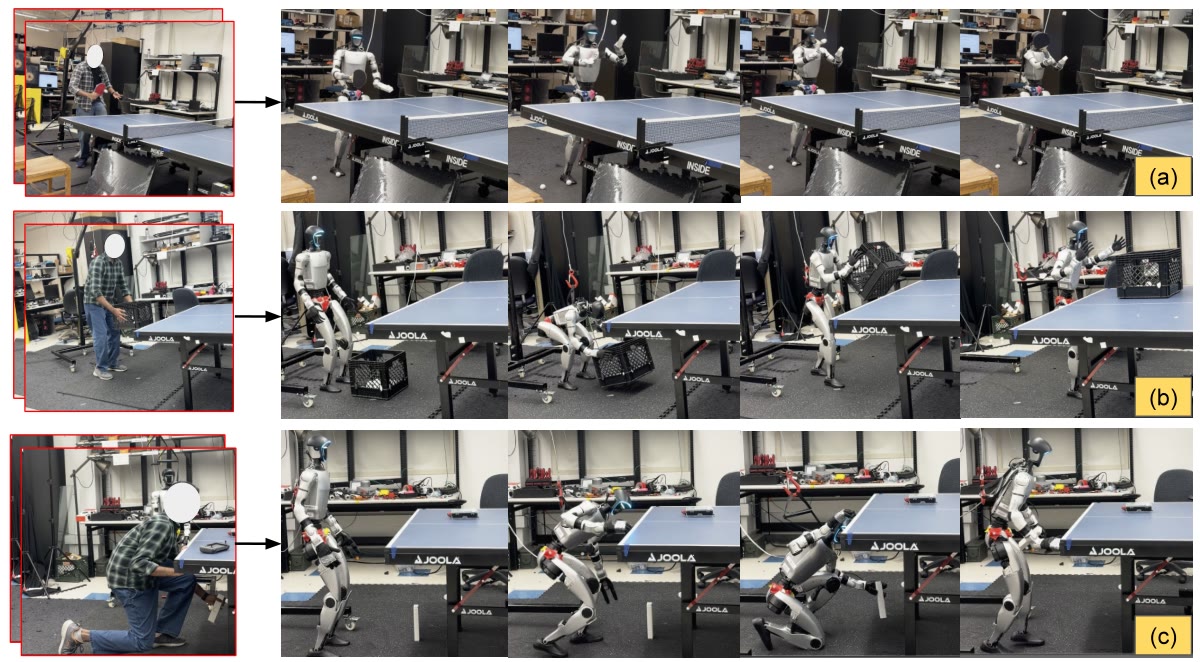
二足ヒューマノイドロボットのRL歩行を撮ってみました。
Isaac Labで学習した歩行ポリシーを実機デプロイ、ようやく安定歩容に近づいてきました。
基本的にフィルタなどは入れず、ポリシー出力を変換だけしてサーボ目標角度に入れてます。
#Humanoid#Robotics#Sim2Real#フィジカルAI
Sphinx: a git hook that quizzes you on the diff before you push to a protected branch.
Your answers never reach the coding agent.
Codex, Claude Code, Cursor, OpenCode, Pi or plain git. sphinx yolo skips it, and every skip is logged.
Ship only what you can explain.
Software maintenance is changing. A few months ago, I had to tell Codex exactly where to look for dead code. Now it can find candidates in Slack, check them against production telemetry, and draft cleanup PRs. Here’s how we do this at OpenAI.
https://t.co/PdQl43nLeQ