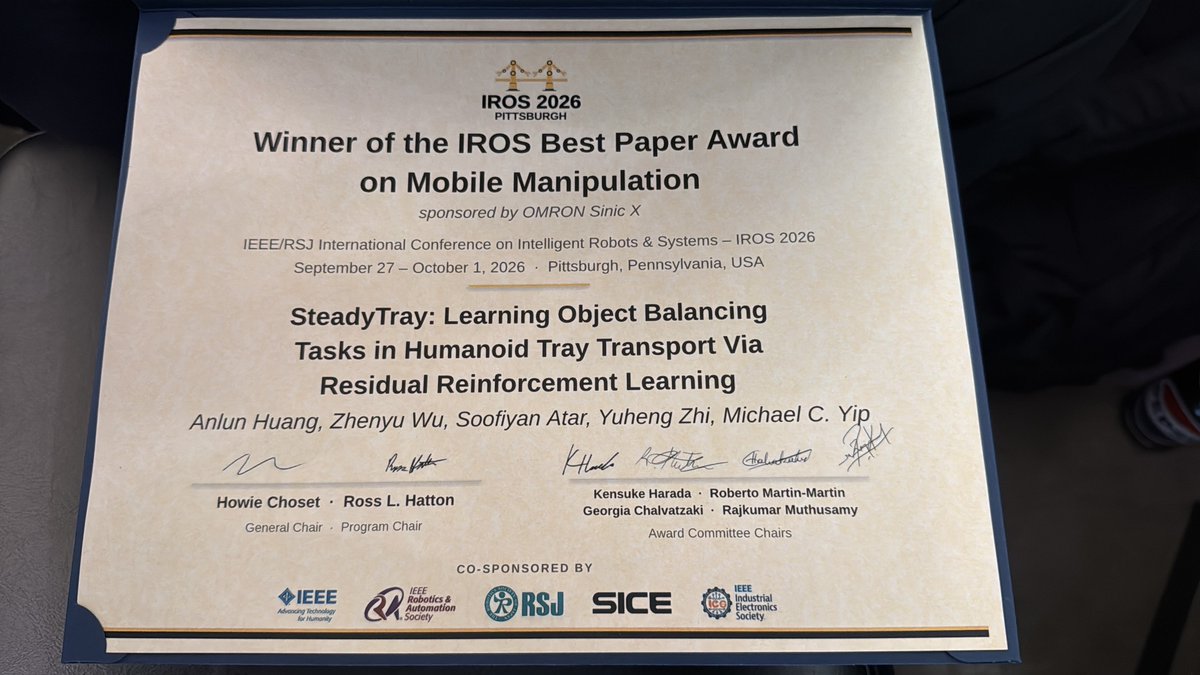
Excited to share that SteadyTray won the IROS 2026 Best Paper Award on Mobile Manipulation! 🏆
Grateful to my amazing coauthors and Prof. Michael Yip for making this work possible. A proud moment for our team!
Humanoid robots shouldn’t just walk — they should serve.
Meet SteadyTray: a robot waiter task where a humanoid transports unsecured objects on a tray without spilling, tipping, or dropping them.
We show stable transport of things like cups, glasses, food containers, and more — even under external disturbance.
Website: https://t.co/kxeNiNB7mJ
Method + demo below 👇
#Robotics #HumanoidRobots #ReinforcementLearning
Long-horizon tasks and dexterous manipulation on humanoid robots. Still crazy to think we built this in just three months!
This is just the beginning. Let’s keep pushing the frontier of general-purpose humanoids! 🚀
Check out the blog for more details:
👉https://t.co/tzA3EsYruM
Introducing Δ₀ (Delta-0), our humanoid foundation model for whole-body loco-manipulation.
One generalist policy. 69 degrees of freedom. Everyday tasks at near-human speed—from making a bed to putting on a record.
Watch Δ₀ in action.
The SteadyTray code is now available 🚀
If you’re interested in humanoid loco-manipulation, sim-to-real RL, and disturbance-robust tray transport on Unitree G1, check it out below:
Code: https://t.co/M2Geth1pr3
Humanoid robots shouldn’t just walk — they should serve.
Meet SteadyTray: a robot waiter task where a humanoid transports unsecured objects on a tray without spilling, tipping, or dropping them.
We show stable transport of things like cups, glasses, food containers, and more — even under external disturbance.
Website: https://t.co/kxeNiNB7mJ
Method + demo below 👇
#Robotics #HumanoidRobots #ReinforcementLearning
Huge shout-out to the amazing team — @ZhenyuWu323, @craigysoofiyan, and @ZhiYuheng — for making this work possible. Grateful as well to Prof. Michael Yip for his guidance and support.