Coming from a traditional controls background, I have often thought about robot safety in terms of physical constraint satisfaction and collision avoidance. However, with robot foundation models we need to start considering the new safety risks that arise and their mitigations 🤔
What does safety mean when your robot can do “anything”? 🦾💥
A few of us have been thinking about this Q for the past year and wrote a position paper:
Rethinking Safety for Generalist Robots
https://t.co/DXzmg31UHX
w/@RohanSinhaSU, @anushridixit111, @tianran_, @Majumdar_Ani!
As general-purpose robots edge closer to deployment, the ultimate question remains: Should we build safety into the architecture at the source, or catch failures at runtime?
Join us to hear from the incredible lineup of Invited Speakers at our RSS workshop this Friday!🤖✈️
Join our workshop at RSS on trustworthy foundation models this year. We have an exciting lineup of speakers that will be discussing safety by design and safety by practice for embodied AI.
🤖 Announcing our RSS 2026 workshop: Trustworthy Embodied Foundation Models: Safety by Design vs Safety by Practice
📝 Call for Papers: 4-page papers on safe & trustworthy embodied FMs | 📅 Deadline: June 15
📍 Sydney, July 17
More Information: 🌐 https://t.co/pFVOCkbZiB
#RSS2026 Call for participants 📢
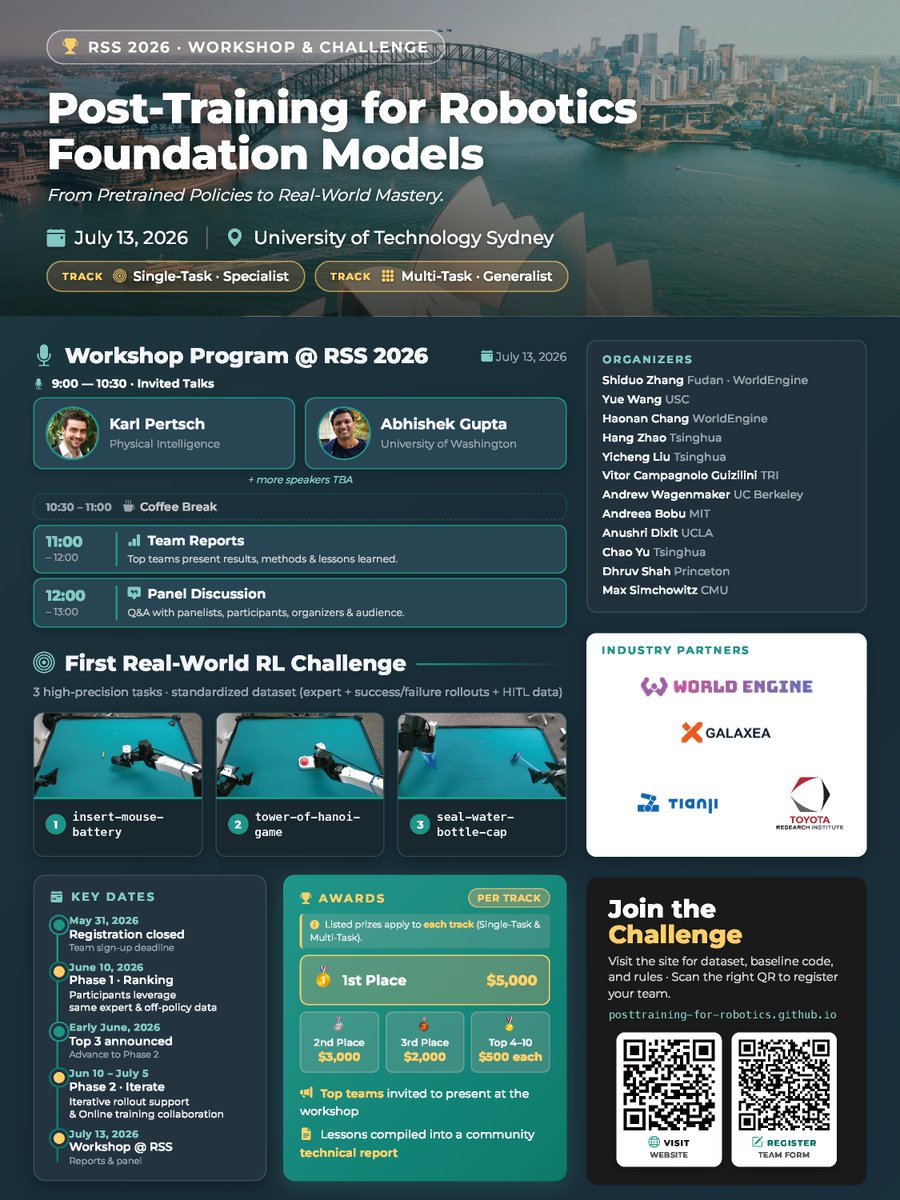
Excited to announce our RSS 2026 Workshop: Post-Training for Robotics Foundation Models, together with the first Real-World Reinforcement Learning Challenge!
The workshop is held on July 13 in Sydney.
https://t.co/c3Dy1CrI0L。
How do you combine a small number of hardware evals with large scale (but imperfect) simulation data for reliable policy evaluation? Check out our work SureSim, led by Apurva⬇️
Robotic manipulation has seen tremendous progress in recent years but rigorous evaluation of robot policies remains a challenge!
We present our work: "Reliable and Scalable Robot Policy Evaluation with Imperfect Simulators"!
🧵
Great visit with @UCLA robotics colleagues yesterday and speaking at @UCLAMechAeroEng seminar. Thanks, @anushridixit111 for inviting and hosting me.
My research group at @Princeton has an opening for a postdoc position. Recently, we have been working on foundational research for generalist robots that are safe, trustworthy, and capable:
https://t.co/oJcZcsjl3O
If you're interested, please email me with the tag [postdoc app] in the subject line.
📢 Excited for the second workshop on Out-of-Distribution Generalization in Robotics: Towards Reliable Learning-based Autonomy at RSS! #RSS2025
🎯 How can we build reliable robotic autonomy for the real world?
📅 Short papers due 05/25/25
🌐 https://t.co/wv8vqOEGk3
🧵(1/4)
Accepted to #CoRL2024: our work on calibrated uncertainty quantification for perception systems for end-to-end statistical assurances for navigation!
Perceive with Confidence:
https://t.co/BxMxt4MaZF
Work led by @anushridixit111 during her postdoc at @Princeton!
Attn: control systems community + folks on academic job market! With @css_nextcom we are crowd-sourcing an unofficial spreadsheet of control-adjacent open positions as a resource for candidates.
Tips about relevant openings can be sent via short form: https://t.co/VJDDqGNfec
All recordings from our @Princeton Robotics Seminar are now online!
https://t.co/Vwwe8OiBpF
We had a wonderful set of speakers spanning diffusion policies, self-supervised learning, human-robot interaction, safe model-based control, and much else. Stay tuned for next year!
This work is a collaboration with Prithvi Akella, Mohamadreza Ahmadi, @LarsLindemann2, Margaret Chapman, @pappasg69, Aaron Ames @AMBER_lab, and Joel Burdick
Interested in learning about risk assessment for robotics? Check out our survey on tail risk measures for control, planning, and verification https://t.co/lc3hNOCzpA
Forgot if you left the lights on in your bedroom? Ask your robot to check!
Excited to be a part of this work led by Allen on embodied Q&A through active exploration with VLMs and leveraging conformal prediction to know when to stop exploring ⬇️
How do we get robots to efficiently explore diverse scenes and answer realistic questions? e.g., is the dishwasher in the kitchen open❓
👇Explore until Confident — know where to explore (with VLMs) and when to stop exploring (with guarantees)
https://t.co/hvPEtr3Evu
We are continuing to make the videos from our @Princeton Robotics Seminar available online!
Check out Henny Admoni's (@hadmoni) talk here:
Robots that Learn From and Collaborate with People
https://t.co/Dam2Mwnk0Y