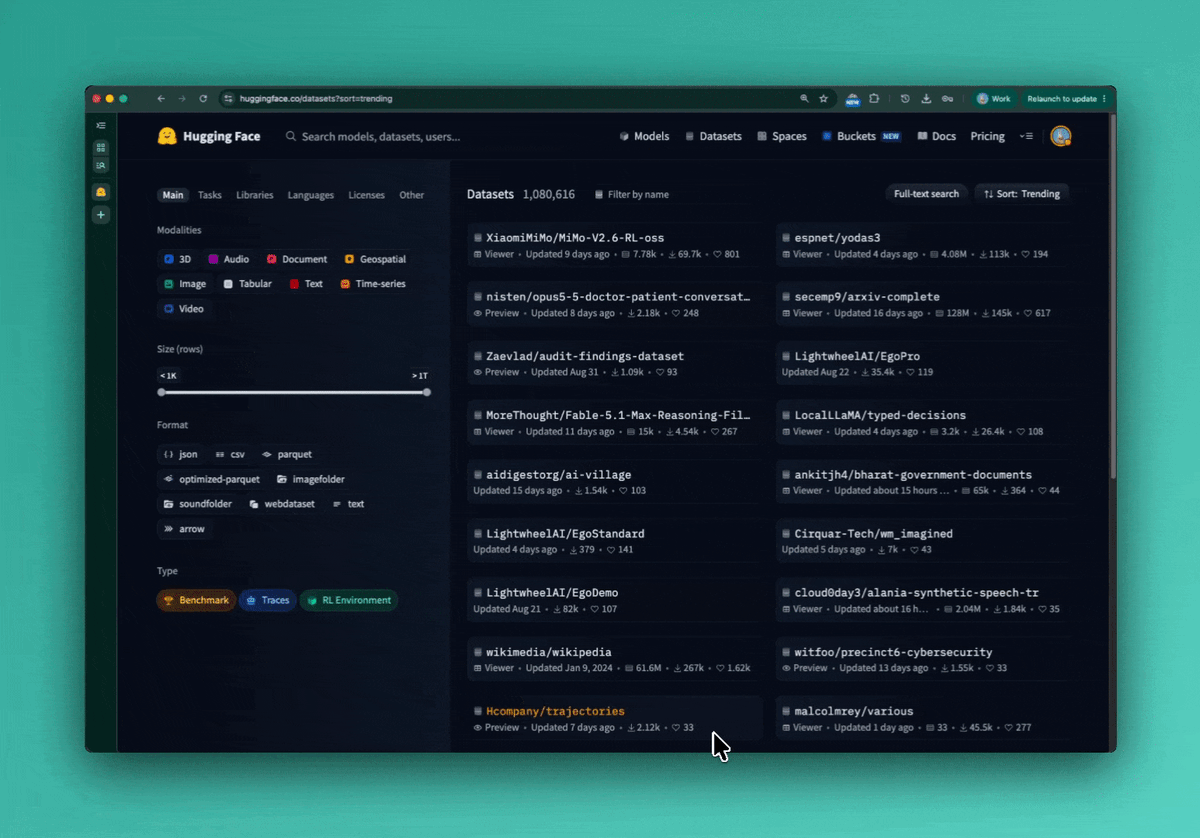
RL environments now have a home on the @huggingface Hub.
Every RL framework has its own way to find environments. Custom hubs, runtime registries, GitHub lists with a custom loader. If you publish for one framework, users of the others can’t load it.
We think that is wrong. Environments should be just like datasets because it’s made from tasks, tests, containers and reward functions. The Hub already stores, versions, gates and previews data for millions of people so it doesn’t need a second system.
Here’s how we’re shipping environments on the hub: https://t.co/1YUYvcqoED
ok what the fuck. this was a dry google doc a moment ago
gave Opus 5.5 my Open Alignment brainstorm gdoc and asked for a video. now I want one for every doc I’ve ever written hahaha
Humanoids are coming to LeRobot! 🤖
Learn what you can do with the @UnitreeRobotics G1 in LeRobot, how to use @NVIDIARobotics SONIC, and which open-source humanoid hardware we currently support!
Read more in our latest blog: https://t.co/Rmzsilz5jm
New JS package: huggingface/lerobot 🤖
Read LeRobot datasets on the Hub straight from the browser. No download.
Point your coding agent at it and build custom viewers fast. Example 3D camera-frustum replay streams 1.1 MB of a 793 MB dataset:
https://t.co/vIMGM1rBUd