🚀 Excited to share our new paper: Rendering-Free Lookahead for Question-Guided Active Vision (RFL)!
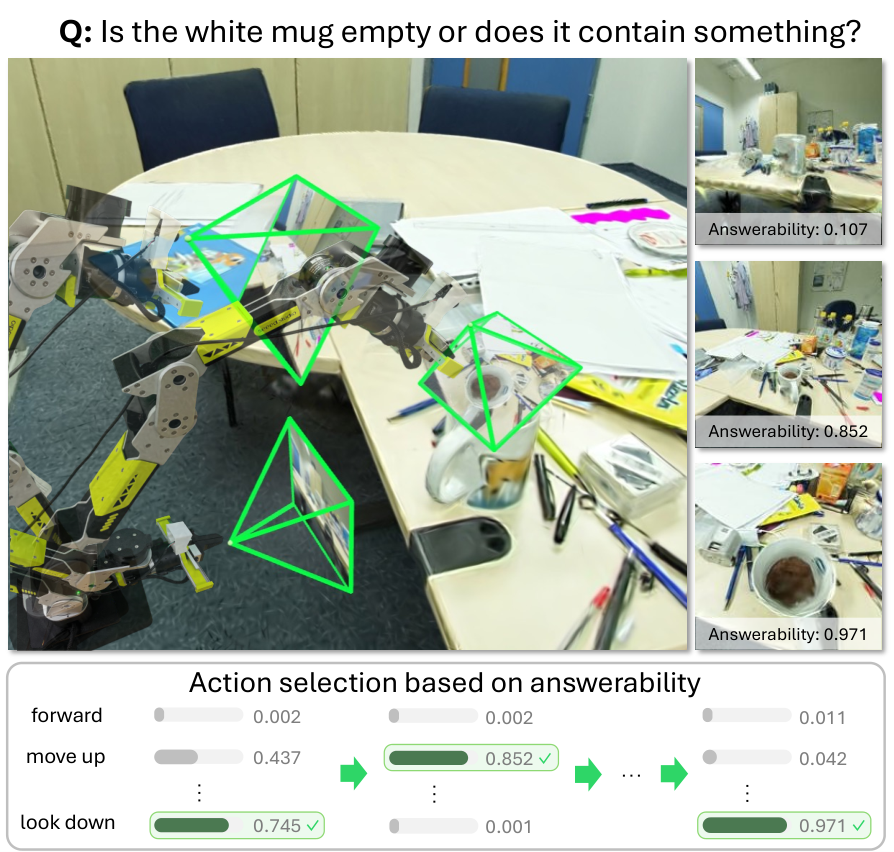
How can robots decide where to look without seeing the future?
RFL learns to predict the usefulness of unseen viewpoints, enabling camera control without future-view rendering.
���� +43% over a direct-action baseline on E3VS-Bench!
📄 Paper: https://t.co/aTUXNroPWN
🌐 Project: https://t.co/uPgG0Utg1G
MotionVLA accepted at CoRL 2026! 🎉
VLAs should remember motion, not just frames.
We convert short video history into queryable trajectory tokens—no drift, no fragmentation.
📄 https://t.co/nPRre4CnAN
🌐 https://t.co/HCcajXVGCL
Excited to share that Residual Copilot was accepted to #CoRL2026!!
Website: https://t.co/q6eeJ0rANX
Paper: https://t.co/Jb90mFR64L
Code: https://t.co/vsyMlalgN9