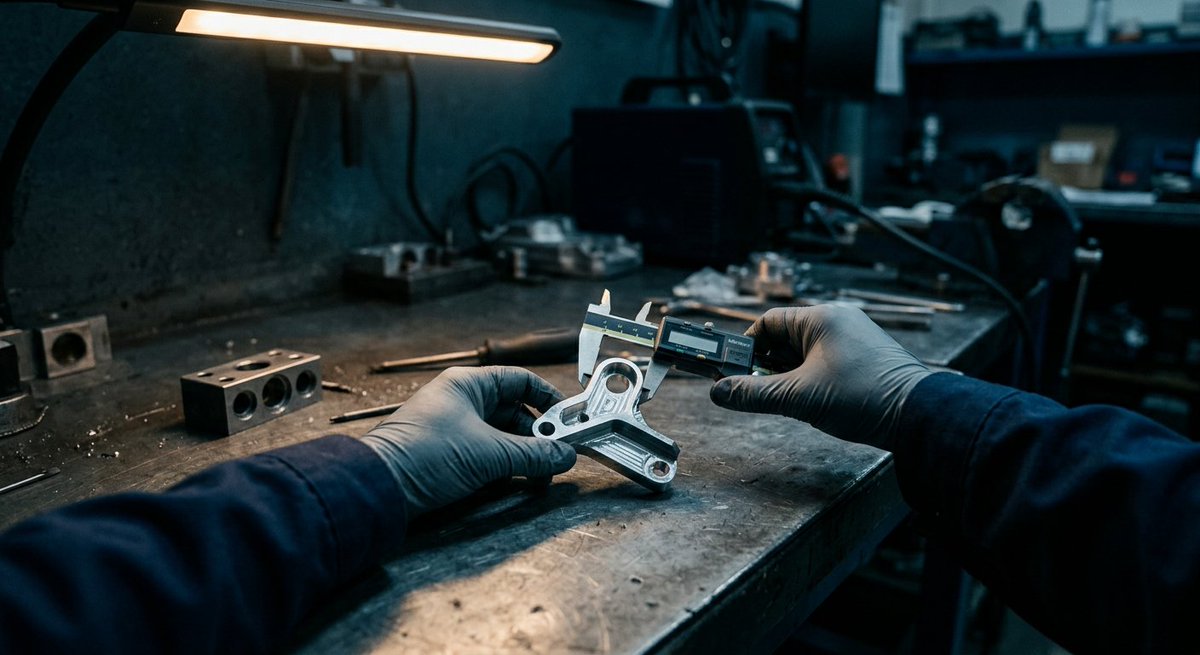
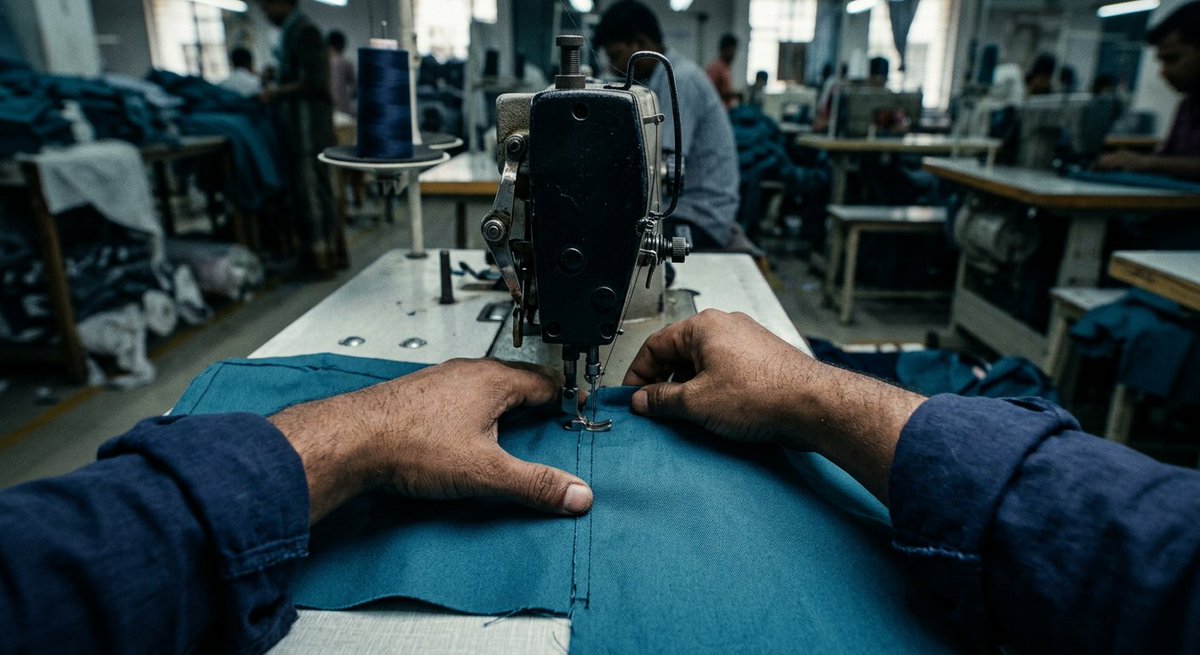
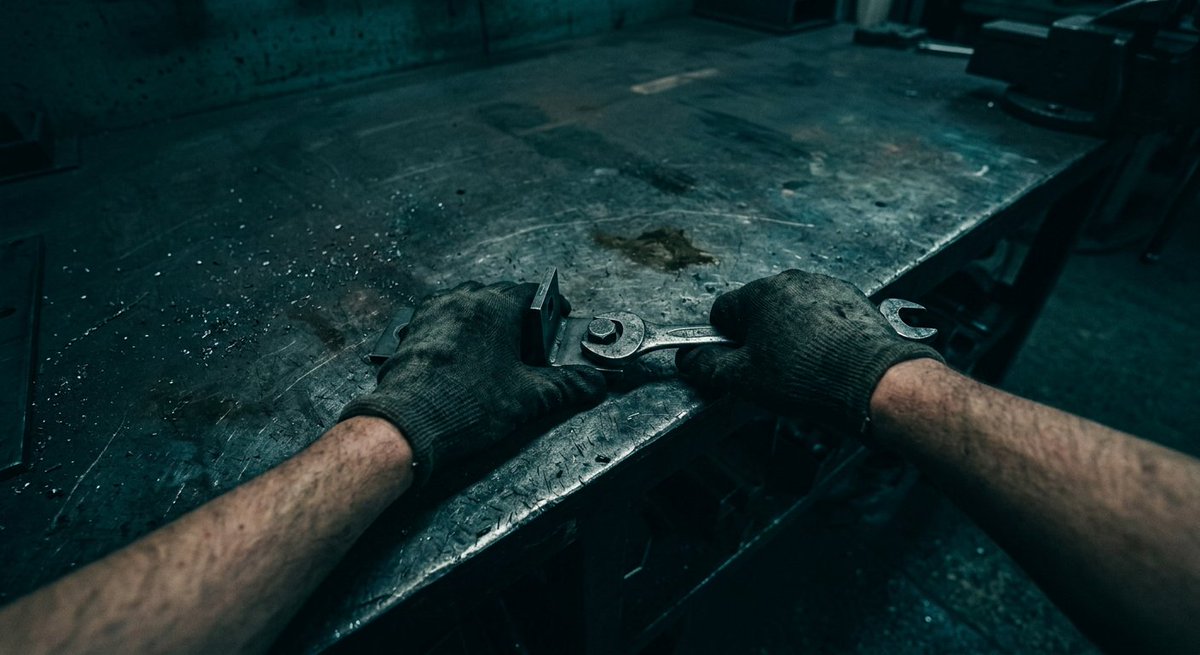
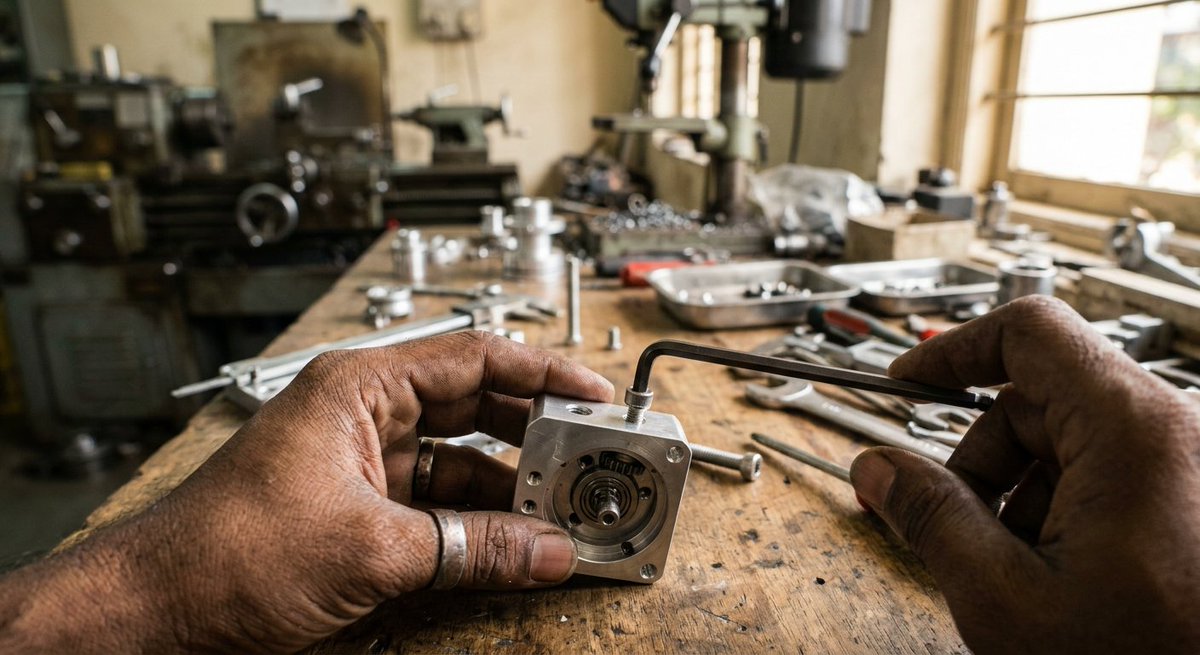
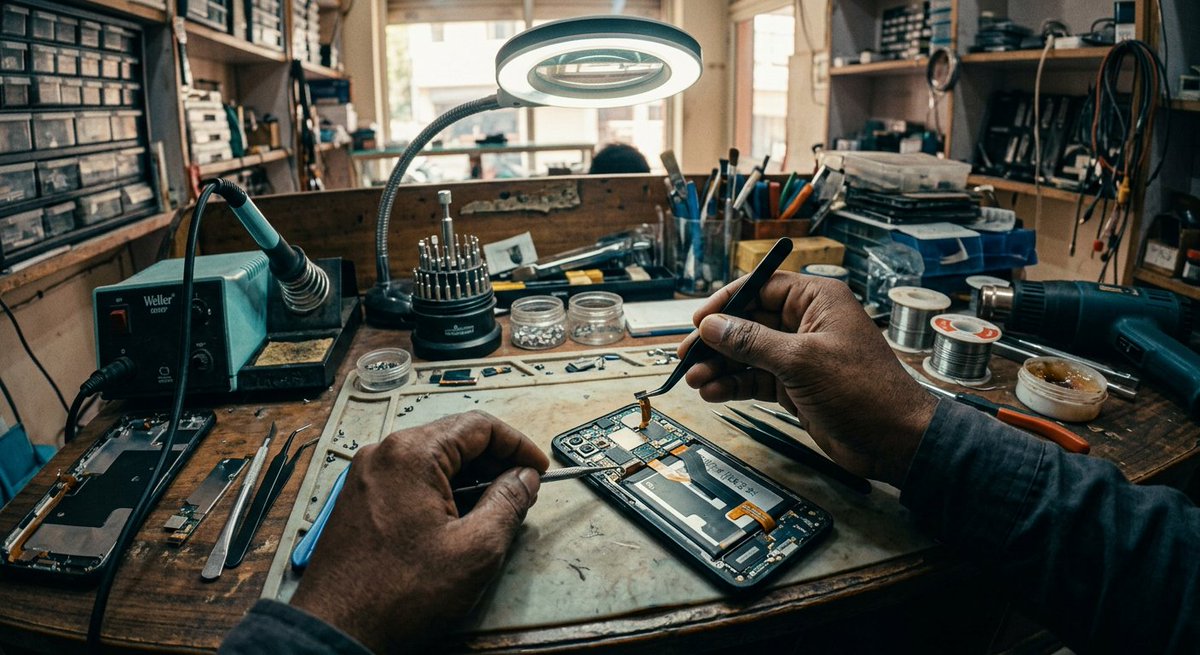
Robots won't learn real work from internet video. They need the world as a worker sees it. We capture egocentric video + 6-axis IMU at any scale, from small factories and metal shops to construction sites, mobile repair benches, farms and any manual work. Stereo demo: https://t.co/xUiObiNTiF
A label is only as good as its second reviewer. Every action segment and hand keypoint we deliver is checked by a second annotator, and clips that fail are rejected, not patched. https://t.co/VRrxxALigH #Robotics#PhysicalAI#RobotLearning#AIData
One episode, one file. Egocentric video, synced 6-axis IMU and timestamps packed in MCAP, so your training stack reads a task in a single pass. Delivered to your storage. https://t.co/VRrxxALQ6f #Robotics#PhysicalAI#RobotLearning#MCAP
Stereo egocentric video, synced 6-axis IMU, real manual work. Custom to your task list or off the shelf. Fully consented, delivered to your storage. Demo: https://t.co/vyFeKkVo2T #Robotics#PhysicalAI#EmbodiedAI#RobotLearning
Hardware is the easy part of egocentric data. Operators are the hard part. In Bengaluru we onboard, brief and consent roughly 7,000 people a day, then capture to your task list. https://t.co/VRrxxALigH #Robotics#PhysicalAI#EmbodiedAI#RobotLearning
A metal shop at 11 a.m. A steel bracket in a vise, a file in two hands. The head tilts to check the edge. We capture that view, with synced IMU, to your task list. https://t.co/VRrxxALigH #Robotics#PhysicalAI#EmbodiedAI#Metalworking
NEURA's Neuron AI (@NEURARobotics) trains on robot data, simulation and people wearing sensors. The human pillar is where new skills start. We capture that view: first-person video, synced IMU, real manual work. https://t.co/VRrxxALQ6f #Robotics#PhysicalAI#EmbodiedAI#NEURA
Head motion tells a robot what the hands are about to do. Our first-person video ships with synced 6-axis IMU, so gaze, head and hands share one clock. https://t.co/VRrxxALigH #Robotics#PhysicalAI#WorldModels#EgocentricData
Harvesting looks simple until a robot tries it. Grip the cluster. Find the stem. Cut without bruising the fruit. We record it as the worker sees it: head-mounted video, synced IMU, real farms. https://t.co/VRrxxALQ6f #Robotics#PhysicalAI#AgTech#EmbodiedAI
Construction is the hardest place to capture clean manual-work data. Rebar tying, formwork, wire cutting. Head-mounted video with synced IMU, from real crews. Any number of hours. https://t.co/VRrxxALQ6f #Robotics#PhysicalAI#EmbodiedAI#Construction
Stereo changes what a robot can learn from a human hand. Two views give metric depth, so grasp distance and contact are measured, not guessed. Synced 6-axis IMU on every clip. Demo: https://t.co/vyFeKkVo2T #Robotics#PhysicalAI#EmbodiedAI#RobotLearning
A phone repair bench, seen through the technician's eyes. Tweezers, a ribbon connector, two hands in sync. Robots can't learn this from internet video. We capture it as first-person video + 6-axis IMU, at any volume. #Robotics#PhysicalAI#EmbodiedAI#RobotLearning
Robots won't learn to sew from stock footage. They learn from the hands that do it every day. First-person video + synced 6-axis IMU from real garment lines, metal shops, construction sites and farms. Any volume. https://t.co/meQ2DhkNL6 #Robotics#PhysicalAI#EmbodiedAI #Humanoids
@TimLi_DR Congrats Tim! 🎉 This is exactly where physical AI is headed real world task data is the foundation. We’ve been doing the same across factories, garments, construction and more in India. Sent you a form as well looking forward to connecting soon!