

Top Tweets for #simulatelypapers

#SimulatelyPapers | May 29, 2025
📄 DexUMI: Using Human Hand as the Universal Manipulation Interface for Dexterous Manipulation 🔗 https://t.co/0QwdpHKcLM
📄 SCIZOR: A Self-Supervised Approach to Data Curation for Large-Scale Imitation Learning 🔗 https://t.co/L0tc9Ht48P | [Project](https://t.co/fEoli6PwHS)
📄 LabUtopia: High-Fidelity Simulation and Hierarchical Benchmark for Scientific Embodied Agents 🔗 https://t.co/TMD5N1IrH7
📄 FastTD3: Simple, Fast, and Capable Reinforcement Learning for Humanoid Control 🔗 https://t.co/TMBJ0wMayZ
📄 Learning Generalizable Robot Policy with Human Demonstration Video as a Prompt 🔗 https://t.co/Otb1bWLZ89
📄 Learning Unified Force and Position Control for Legged Loco-Manipulation 🔗 https://t.co/bCiyruZVMR
📄 Hume: Introducing System-2 Thinking in Visual-Language-Action Model 🔗 https://t.co/tdH6nSVTQm
📄 CLAMP: Crowdsourcing a LArge-scale in-the-wild haptic dataset with an open-source device for Multimodal robot Perception 🔗 https://t.co/KNT2SkGaKo | [Project](https://t.co/zYgleu2ShT)
📄 MaskedManipulator: Versatile Whole-Body Control for Loco-Manipulation 🔗 https://t.co/HS1H3J0kOI
📄 Genie Centurion: Accelerating Scalable Real-World Robot Training with Human Rewind-and-Refine Guidance 🔗 https://t.co/gYSxqPtsYT
📄 ManiFeel: Benchmarking and Understanding Visuotactile Manipulation Policy Learning 🔗 https://t.co/cEeYXHRQZW | [Project](https://t.co/dEanxRhHYM)
📄 EgoZero: Robot Learning from Smart Glasses 🔗 https://t.co/9wQUHnaUJh | [Project](https://t.co/OYA6IvH26s.)
Find more daily insights here: https://t.co/nXJyIf9GmN

📄 LabUtopia: High-Fidelity Simulation and Hierarchical Benchmark for Scientific Embodied Agents 🔗 https://t.co/TMD5N1IrH7
📄 FastTD3: Simple, Fast, and Capable Reinforcement Learning for Humanoid Control 🔗 https://t.co/TMBJ0wMayZ
📄 Learning Generalizable Robot Policy with Human Demonstration Video as a Prompt 🔗 https://t.co/Otb1bWLZ89
📄 Learning Unified Force and Position Control for Legged Loco-Manipulation 🔗 https://t.co/bCiyruZVMR
📄 Hume: Introducing System-2 Thinking in Visual-Language-Action Model 🔗 https://t.co/tdH6nSVTQm
📄 CLAMP: Crowdsourcing a LArge-scale in-the-wild haptic dataset with an open-source device for Multimodal robot Perception 🔗 https://t.co/KNT2SkGaKo | [Project](https://t.co/zYgleu2ShT)
📄 MaskedManipulator: Versatile Whole-Body Control for Loco-Manipulation 🔗 https://t.co/HS1H3J0kOI
📄 Genie Centurion: Accelerating Scalable Real-World Robot Training with Human Rewind-and-Refine Guidance 🔗 https://t.co/gYSxqPtsYT
📄 ManiFeel: Benchmarking and Understanding Visuotactile Manipulation Policy Learning 🔗 https://t.co/cEeYXHRQZW | [Project](https://t.co/dEanxRhHYM)
📄 EgoZero: Robot Learning from Smart Glasses 🔗 https://t.co/9wQUHnaUJh | [Project](https://t.co/OYA6IvH26s.)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GtImk2DaoAA9sbB.jpg)

📄 LabUtopia: High-Fidelity Simulation and Hierarchical Benchmark for Scientific Embodied Agents 🔗 https://t.co/TMD5N1IrH7
📄 FastTD3: Simple, Fast, and Capable Reinforcement Learning for Humanoid Control 🔗 https://t.co/TMBJ0wMayZ
📄 Learning Generalizable Robot Policy with Human Demonstration Video as a Prompt 🔗 https://t.co/Otb1bWLZ89
📄 Learning Unified Force and Position Control for Legged Loco-Manipulation 🔗 https://t.co/bCiyruZVMR
📄 Hume: Introducing System-2 Thinking in Visual-Language-Action Model 🔗 https://t.co/tdH6nSVTQm
📄 CLAMP: Crowdsourcing a LArge-scale in-the-wild haptic dataset with an open-source device for Multimodal robot Perception 🔗 https://t.co/KNT2SkGaKo | [Project](https://t.co/zYgleu2ShT)
📄 MaskedManipulator: Versatile Whole-Body Control for Loco-Manipulation 🔗 https://t.co/HS1H3J0kOI
📄 Genie Centurion: Accelerating Scalable Real-World Robot Training with Human Rewind-and-Refine Guidance 🔗 https://t.co/gYSxqPtsYT
📄 ManiFeel: Benchmarking and Understanding Visuotactile Manipulation Policy Learning 🔗 https://t.co/cEeYXHRQZW | [Project](https://t.co/dEanxRhHYM)
📄 EgoZero: Robot Learning from Smart Glasses 🔗 https://t.co/9wQUHnaUJh | [Project](https://t.co/OYA6IvH26s.)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GtImk0kboAAqVYv.jpg)

📄 LabUtopia: High-Fidelity Simulation and Hierarchical Benchmark for Scientific Embodied Agents 🔗 https://t.co/TMD5N1IrH7
📄 FastTD3: Simple, Fast, and Capable Reinforcement Learning for Humanoid Control 🔗 https://t.co/TMBJ0wMayZ
📄 Learning Generalizable Robot Policy with Human Demonstration Video as a Prompt 🔗 https://t.co/Otb1bWLZ89
📄 Learning Unified Force and Position Control for Legged Loco-Manipulation 🔗 https://t.co/bCiyruZVMR
📄 Hume: Introducing System-2 Thinking in Visual-Language-Action Model 🔗 https://t.co/tdH6nSVTQm
📄 CLAMP: Crowdsourcing a LArge-scale in-the-wild haptic dataset with an open-source device for Multimodal robot Perception 🔗 https://t.co/KNT2SkGaKo | [Project](https://t.co/zYgleu2ShT)
📄 MaskedManipulator: Versatile Whole-Body Control for Loco-Manipulation 🔗 https://t.co/HS1H3J0kOI
📄 Genie Centurion: Accelerating Scalable Real-World Robot Training with Human Rewind-and-Refine Guidance 🔗 https://t.co/gYSxqPtsYT
📄 ManiFeel: Benchmarking and Understanding Visuotactile Manipulation Policy Learning 🔗 https://t.co/cEeYXHRQZW | [Project](https://t.co/dEanxRhHYM)
📄 EgoZero: Robot Learning from Smart Glasses 🔗 https://t.co/9wQUHnaUJh | [Project](https://t.co/OYA6IvH26s.)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GtImk0hbMAYL9tC.jpg)
#SimulatelyPapers | February 26, 2025
📄 OpenFly: A Versatile Toolchain and Large-scale Benchmark for Aerial Vision-Language Navigation 🔗 https://t.co/M0KT2eAEpt
📄 Impact of Object Weight in Handovers: Inspiring Robotic Grip Release and Motion from Human Handovers 🔗 https://t.co/R8U5uxb5fN
📄 FetchBot: Object Fetching in Cluttered Shelves via Zero-Shot Sim2Real 🔗 https://t.co/MiX111dHl4
📄 From planning to policy: distilling $\texttt{Skill-RRT}$ for long-horizon prehensile and non-prehensile manipulation 🔗 https://t.co/1V6AI3Rc7g
📄 Retrieval Dexterity: Efficient Object Retrieval in Clutters with Dexterous Hand 🔗 https://t.co/TjujvJWO71 | [Project](https://t.co/q0iSCc89va.)
📄 COMPASS: Cross-embodiment Mobility Policy via Residual RL and Skill Synthesis 🔗 https://t.co/j0BpBRz3Is
📄 AnyDexGrasp: General Dexterous Grasping for Different Hands with Human-level Learning Efficiency 🔗 https://t.co/H9gAgKTqhs
📄 DemoGen: Synthetic Demonstration Generation for Data-Efficient Visuomotor Policy Learning 🔗 https://t.co/BmoGgfOXmz
📄 FACTR: Force-Attending Curriculum Training for Contact-Rich Policy Learning 🔗 https://t.co/aPQZ9Js9st | [Project](https://t.co/SBiT2KzKz2)
Find more daily insights here: https://t.co/nXJyIf9GmN

📄 COMPASS: Cross-embodiment Mobility Policy via Residual RL and Skill Synthesis 🔗 https://t.co/j0BpBRz3Is
📄 AnyDexGrasp: General Dexterous Grasping for Different Hands with Human-level Learning Efficiency 🔗 https://t.co/H9gAgKTqhs
📄 DemoGen: Synthetic Demonstration Generation for Data-Efficient Visuomotor Policy Learning 🔗 https://t.co/BmoGgfOXmz
📄 FACTR: Force-Attending Curriculum Training for Contact-Rich Policy Learning 🔗 https://t.co/aPQZ9Js9st | [Project](https://t.co/SBiT2KzKz2)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GlGCxpmWMAAcVIY.jpg)

📄 COMPASS: Cross-embodiment Mobility Policy via Residual RL and Skill Synthesis 🔗 https://t.co/j0BpBRz3Is
📄 AnyDexGrasp: General Dexterous Grasping for Different Hands with Human-level Learning Efficiency 🔗 https://t.co/H9gAgKTqhs
📄 DemoGen: Synthetic Demonstration Generation for Data-Efficient Visuomotor Policy Learning 🔗 https://t.co/BmoGgfOXmz
📄 FACTR: Force-Attending Curriculum Training for Contact-Rich Policy Learning 🔗 https://t.co/aPQZ9Js9st | [Project](https://t.co/SBiT2KzKz2)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GlGCxpjXkAAVQNX.jpg)

📄 COMPASS: Cross-embodiment Mobility Policy via Residual RL and Skill Synthesis 🔗 https://t.co/j0BpBRz3Is
📄 AnyDexGrasp: General Dexterous Grasping for Different Hands with Human-level Learning Efficiency 🔗 https://t.co/H9gAgKTqhs
📄 DemoGen: Synthetic Demonstration Generation for Data-Efficient Visuomotor Policy Learning 🔗 https://t.co/BmoGgfOXmz
📄 FACTR: Force-Attending Curriculum Training for Contact-Rich Policy Learning 🔗 https://t.co/aPQZ9Js9st | [Project](https://t.co/SBiT2KzKz2)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GlGCxpQa4AAxjYZ.jpg)

📄 COMPASS: Cross-embodiment Mobility Policy via Residual RL and Skill Synthesis 🔗 https://t.co/j0BpBRz3Is
📄 AnyDexGrasp: General Dexterous Grasping for Different Hands with Human-level Learning Efficiency 🔗 https://t.co/H9gAgKTqhs
📄 DemoGen: Synthetic Demonstration Generation for Data-Efficient Visuomotor Policy Learning 🔗 https://t.co/BmoGgfOXmz
📄 FACTR: Force-Attending Curriculum Training for Contact-Rich Policy Learning 🔗 https://t.co/aPQZ9Js9st | [Project](https://t.co/SBiT2KzKz2)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GlGCxpLagAA37a2.jpg)
#SimulatelyPapers | February 17, 2025
📄 MuJoCo Playground 🔗 https://t.co/vMkGDokyWI
📄 Learning Humanoid Standing-up Control across Diverse Postures 🔗 https://t.co/wNuHtnyMV8 | [Project](https://t.co/UIUNUWeCrc.)
📄 A Real-to-Sim-to-Real Approach to Robotic Manipulation with VLM-Generated Iterative Keypoint Rewards 🔗 https://t.co/mQtFDeg29P
📄 Re$^3$Sim: Generating High-Fidelity Simulation Data via 3D-Photorealistic Real-to-Sim for Robotic Manipulation 🔗 https://t.co/Pvft60ijA6 | [Project](https://t.co/2mklQXXKh4.)
Find more daily insights here: https://t.co/nXJyIf9GmN

📄 A Real-to-Sim-to-Real Approach to Robotic Manipulation with VLM-Generated Iterative Keypoint Rewards 🔗 https://t.co/mQtFDeg29P
📄 Re$^3$Sim: Generating High-Fidelity Simulation Data via 3D-Photorealistic Real-to-Sim for Robotic Manipulation 🔗 https://t.co/Pvft60ijA6 | [Project](https://t.co/2mklQXXKh4.)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GlBzYFnWsAAShTA.jpg)
#SimulatelyPapers | January 28, 2025
📄 SpatialVLA: Exploring Spatial Representations for Visual-Language-Action Model 🔗 https://t.co/fTMKK2Klvf
Find more daily insights here: https://t.co/qCbfpBdOuu
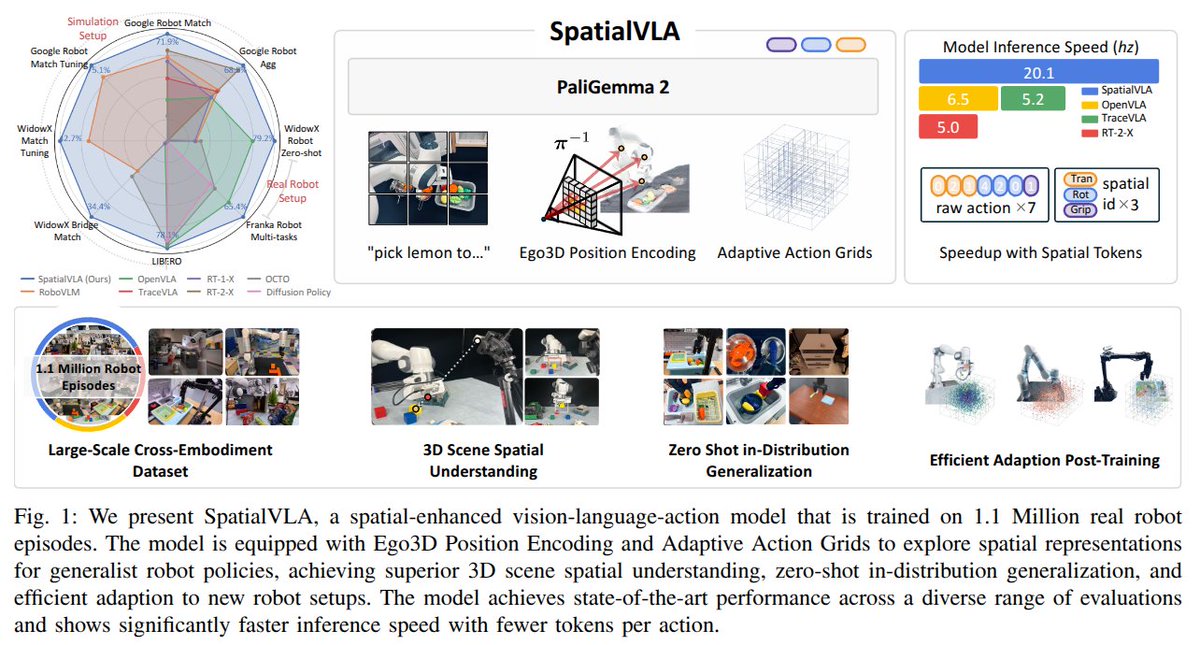
#SimulatelyPapers | January 20, 2025
📄 FoundationStereo: Zero-Shot Stereo Matching 🔗 https://t.co/Vs0a8vT0G2
📄 SLIM: Sim-to-Real Legged Instructive Manipulation via Long-Horizon Visuomotor Learning 🔗 https://t.co/bcgshMUvzR
📄 Robotic World Model: A Neural Network Simulator for Robust Policy Optimization in Robotics 🔗 https://t.co/RxzOyVHsO5
📄 DexForce: Extracting Force-informed Actions from Kinesthetic Demonstrations for Dexterous Manipulation 🔗 https://t.co/C0ByUBBEu3
Find more daily insights here: https://t.co/nXJyIf9GmN
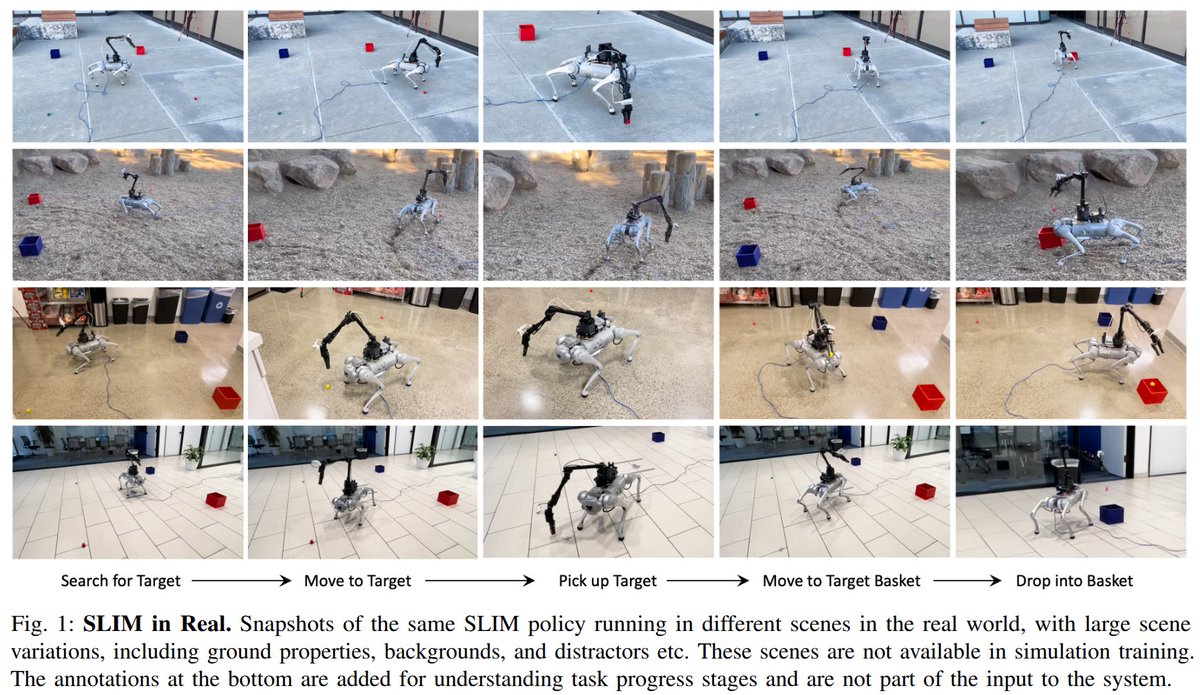


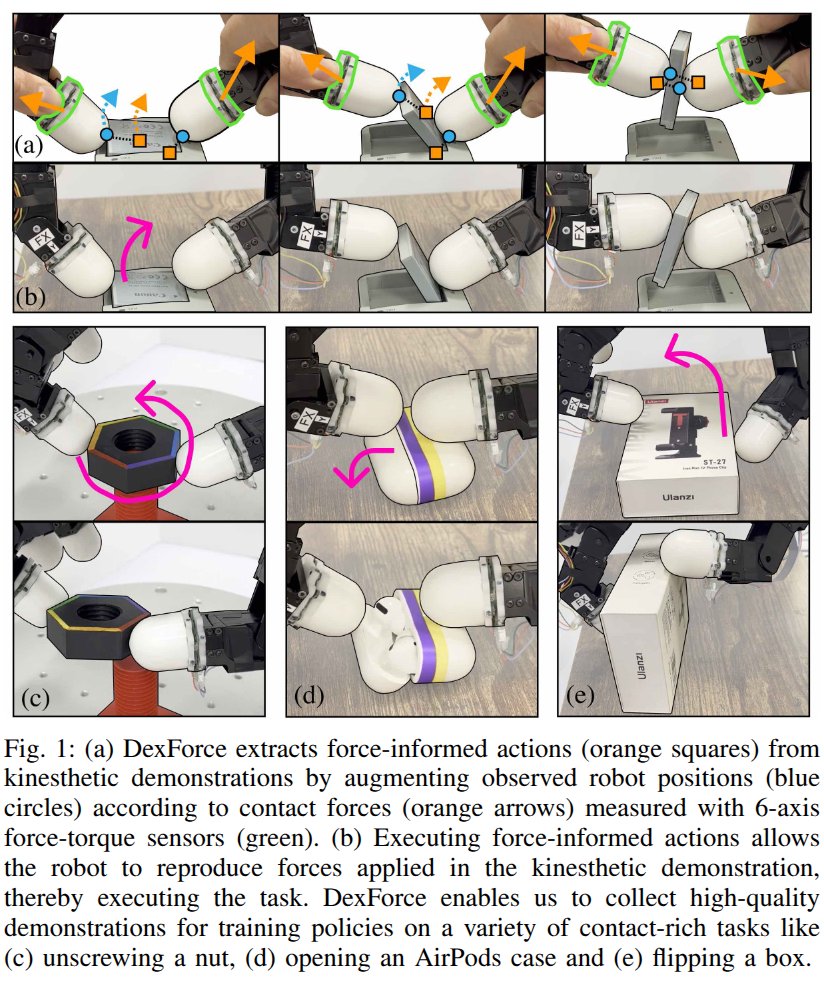
#SimulatelyPapers | January 09, 2025
📄 Learning to Transfer Human Hand Skills for Robot Manipulations 🔗 https://t.co/IqEaYGUvkU | [Project](https://t.co/tcB8R8dJyS.)
📄 Bridging Adaptivity and Safety: Learning Agile Collision-Free Locomotion Across Varied Physics 🔗 https://t.co/x8cGBNJXEF | [Project](https://t.co/6KF0Nn7mUS.)
📄 MobileH2R: Learning Generalizable Human to Mobile Robot Handover Exclusively from Scalable and Diverse Synthetic Data 🔗 https://t.co/0SOueLQlll
📄 FrontierNet: Learning Visual Cues to Explore 🔗 https://t.co/SylBSgRtym
📄 Beyond Sight: Finetuning Generalist Robot Policies with Heterogeneous Sensors via Language Grounding 🔗 https://t.co/tETdUT7acY
Find more daily insights here: https://t.co/nXJyIf9GmN

📄 Bridging Adaptivity and Safety: Learning Agile Collision-Free Locomotion Across Varied Physics 🔗 https://t.co/x8cGBNJXEF | [Project](https://t.co/6KF0Nn7mUS.)
📄 MobileH2R: Learning Generalizable Human to Mobile Robot Handover Exclusively from Scalable and Diverse Synthetic Data 🔗 https://t.co/0SOueLQlll
📄 FrontierNet: Learning Visual Cues to Explore 🔗 https://t.co/SylBSgRtym
📄 Beyond Sight: Finetuning Generalist Robot Policies with Heterogeneous Sensors via Language Grounding 🔗 https://t.co/tETdUT7acY
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gg1FphEaMAQX22u.png)

📄 Bridging Adaptivity and Safety: Learning Agile Collision-Free Locomotion Across Varied Physics 🔗 https://t.co/x8cGBNJXEF | [Project](https://t.co/6KF0Nn7mUS.)
📄 MobileH2R: Learning Generalizable Human to Mobile Robot Handover Exclusively from Scalable and Diverse Synthetic Data 🔗 https://t.co/0SOueLQlll
📄 FrontierNet: Learning Visual Cues to Explore 🔗 https://t.co/SylBSgRtym
📄 Beyond Sight: Finetuning Generalist Robot Policies with Heterogeneous Sensors via Language Grounding 🔗 https://t.co/tETdUT7acY
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gg1FphDbsAAUjTm.jpg)

📄 Bridging Adaptivity and Safety: Learning Agile Collision-Free Locomotion Across Varied Physics 🔗 https://t.co/x8cGBNJXEF | [Project](https://t.co/6KF0Nn7mUS.)
📄 MobileH2R: Learning Generalizable Human to Mobile Robot Handover Exclusively from Scalable and Diverse Synthetic Data 🔗 https://t.co/0SOueLQlll
📄 FrontierNet: Learning Visual Cues to Explore 🔗 https://t.co/SylBSgRtym
📄 Beyond Sight: Finetuning Generalist Robot Policies with Heterogeneous Sensors via Language Grounding 🔗 https://t.co/tETdUT7acY
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gg1FphDbcAA3ovN.jpg)

📄 Bridging Adaptivity and Safety: Learning Agile Collision-Free Locomotion Across Varied Physics 🔗 https://t.co/x8cGBNJXEF | [Project](https://t.co/6KF0Nn7mUS.)
📄 MobileH2R: Learning Generalizable Human to Mobile Robot Handover Exclusively from Scalable and Diverse Synthetic Data 🔗 https://t.co/0SOueLQlll
📄 FrontierNet: Learning Visual Cues to Explore 🔗 https://t.co/SylBSgRtym
📄 Beyond Sight: Finetuning Generalist Robot Policies with Heterogeneous Sensors via Language Grounding 🔗 https://t.co/tETdUT7acY
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gg1FphDaoAAf3ac.jpg)
#SimulatelyPapers | November 22, 2024
📄 Exploring the Adversarial Vulnerabilities of Vision-Language-Action Models in Robotics 🔗 https://t.co/q8HETYeEiN
📄 Bimanual Dexterity for Complex Tasks 🔗 https://t.co/Ih95k0NbvC | [Project](https://t.co/erQRkTn63T)
📄 Arm Robot: AR-Enhanced Embodied Control and Visualization for Intuitive Robot Arm Manipulation 🔗 https://t.co/ni8L0fRLwq
📄 Cooperative Grasping and Transportation using Multi-agent Reinforcement Learning with Ternary Force Representation 🔗 https://t.co/GHWZtR5k28
📄 Learning thin deformable object manipulation with a multi-sensory integrated soft hand 🔗 https://t.co/Un7klmlkPg
📄 Continual Learning and Lifting of Koopman Dynamics for Linear Control of Legged Robots 🔗 https://t.co/RFnuj4hstR
📄 SplatR : Experience Goal Visual Rearrangement with 3D Gaussian Splatting and Dense Feature Matching 🔗 https://t.co/RDgTj6vgyF
📄 Learning Humanoid Locomotion with Perceptive Internal Model 🔗 https://t.co/MdaznUqgB8
📄 23 DoF Grasping Policies from a Raw Point Cloud 🔗 https://t.co/bwmX05tkDS
Find more daily insights here: https://t.co/nXJyIf9GmN

📄 Arm Robot: AR-Enhanced Embodied Control and Visualization for Intuitive Robot Arm Manipulation 🔗 https://t.co/ni8L0fRLwq
📄 Cooperative Grasping and Transportation using Multi-agent Reinforcement Learning with Ternary Force Representation 🔗 https://t.co/GHWZtR5k28
📄 Learning thin deformable object manipulation with a multi-sensory integrated soft hand 🔗 https://t.co/Un7klmlkPg
📄 Continual Learning and Lifting of Koopman Dynamics for Linear Control of Legged Robots 🔗 https://t.co/RFnuj4hstR
📄 SplatR : Experience Goal Visual Rearrangement with 3D Gaussian Splatting and Dense Feature Matching 🔗 https://t.co/RDgTj6vgyF
📄 Learning Humanoid Locomotion with Perceptive Internal Model 🔗 https://t.co/MdaznUqgB8
📄 23 DoF Grasping Policies from a Raw Point Cloud 🔗 https://t.co/bwmX05tkDS
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gc9jhxsbMAAh2AD.jpg)

📄 Arm Robot: AR-Enhanced Embodied Control and Visualization for Intuitive Robot Arm Manipulation 🔗 https://t.co/ni8L0fRLwq
📄 Cooperative Grasping and Transportation using Multi-agent Reinforcement Learning with Ternary Force Representation 🔗 https://t.co/GHWZtR5k28
📄 Learning thin deformable object manipulation with a multi-sensory integrated soft hand 🔗 https://t.co/Un7klmlkPg
📄 Continual Learning and Lifting of Koopman Dynamics for Linear Control of Legged Robots 🔗 https://t.co/RFnuj4hstR
📄 SplatR : Experience Goal Visual Rearrangement with 3D Gaussian Splatting and Dense Feature Matching 🔗 https://t.co/RDgTj6vgyF
📄 Learning Humanoid Locomotion with Perceptive Internal Model 🔗 https://t.co/MdaznUqgB8
📄 23 DoF Grasping Policies from a Raw Point Cloud 🔗 https://t.co/bwmX05tkDS
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gc9jhxrbgAAC2Ry.jpg)

📄 Arm Robot: AR-Enhanced Embodied Control and Visualization for Intuitive Robot Arm Manipulation 🔗 https://t.co/ni8L0fRLwq
📄 Cooperative Grasping and Transportation using Multi-agent Reinforcement Learning with Ternary Force Representation 🔗 https://t.co/GHWZtR5k28
📄 Learning thin deformable object manipulation with a multi-sensory integrated soft hand 🔗 https://t.co/Un7klmlkPg
📄 Continual Learning and Lifting of Koopman Dynamics for Linear Control of Legged Robots 🔗 https://t.co/RFnuj4hstR
📄 SplatR : Experience Goal Visual Rearrangement with 3D Gaussian Splatting and Dense Feature Matching 🔗 https://t.co/RDgTj6vgyF
📄 Learning Humanoid Locomotion with Perceptive Internal Model 🔗 https://t.co/MdaznUqgB8
📄 23 DoF Grasping Policies from a Raw Point Cloud 🔗 https://t.co/bwmX05tkDS
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gc9jhxragAAH1AK.jpg)

📄 Arm Robot: AR-Enhanced Embodied Control and Visualization for Intuitive Robot Arm Manipulation 🔗 https://t.co/ni8L0fRLwq
📄 Cooperative Grasping and Transportation using Multi-agent Reinforcement Learning with Ternary Force Representation 🔗 https://t.co/GHWZtR5k28
📄 Learning thin deformable object manipulation with a multi-sensory integrated soft hand 🔗 https://t.co/Un7klmlkPg
📄 Continual Learning and Lifting of Koopman Dynamics for Linear Control of Legged Robots 🔗 https://t.co/RFnuj4hstR
📄 SplatR : Experience Goal Visual Rearrangement with 3D Gaussian Splatting and Dense Feature Matching 🔗 https://t.co/RDgTj6vgyF
📄 Learning Humanoid Locomotion with Perceptive Internal Model 🔗 https://t.co/MdaznUqgB8
📄 23 DoF Grasping Policies from a Raw Point Cloud 🔗 https://t.co/bwmX05tkDS
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gc9jhxqaAAIwG2H.jpg)
#SimulatelyPapers | November 18, 2024
📄 Whole-Body Impedance Coordinative Control of Wheel-Legged Robot on Uncertain Terrain 🔗 https://t.co/1hniSq2QR5
📄 ALPHA-$α$ and Bi-ACT Are All You Need: Importance of Position and Force Information/Control for Imitation Learning of Unimanual and Bimanual Robotic Manipulation with Low-Cost System 🔗 https://t.co/UJJ91YgqRi | [Project](https://t.co/AbcetX3qoh)
Find more daily insights here: https://t.co/nXJyIf9GmN

Autonomous actions are executed based on learned Bi-ACT from only 5 collected demonstration data. The findings demonstrated that Bi-ACT model with force control, utilizing the ALPHA-α, exhibited high success rates and confirmed its applicability to bimanual tasks.
Last Seen Hashtags on Sotwe
minichat()********* filter:videos
Seen from Brazil
minichat
Seen from Mexico
anxiouspanda
Seen from United States
anxiouspanda #minichat #snapchat
Seen from United States
人前露出
Seen from United States
minichat(())**********() +filter:native_video
Seen from Turkey
minichat https video
Seen from Germany
dickflash(*****************)
Seen from Turkey
JaninaMolina
Most Popular Users

Elon Musk 
@elonmusk
241.7M followers

Barack Obama
@barackobama
119M followers

Cristiano Ronaldo
@cristiano
114.6M followers

Donald J. Trump
@realdonaldtrump
111.9M followers

Narendra Modi
@narendramodi
107.2M followers

Rihanna
@rihanna
98.7M followers

NASA
@nasa
92.4M followers

Justin Bieber
@justinbieber
91.8M followers

KATY PERRY
@katyperry
90.1M followers

Taylor Swift
@taylorswift13
84M followers

Lady Gaga
@ladygaga
75.5M followers

Virat Kohli
@imvkohli
73.5M followers

Kim Kardashian
@kimkardashian
70.9M followers

YouTube
@youtube
68.8M followers

Neymar Jr
@neymarjr
66.5M followers

Bill Gates
@billgates
65.2M followers

Selena Gomez
@selenagomez
63.1M followers

The Ellen Show
@theellenshow
62.3M followers

CNN
@cnn
61.8M followers

X
@x
60.7M followers