(1/3)
🚀Excited to announce Simulately🤖, a go-to toolkit for robotics researchers navigating diverse simulators!
💻 Github: https://t.co/GlNWqtBtHc
🔗 Website: https://t.co/i73EkUQbqw
Let’s level up our robotics research with Simulately!
#Robotics#Simulators#ResearchTool
#SimulatelyPapers | July 03, 2025
📄 AC-DiT: Adaptive Coordination Diffusion Transformer for Mobile Manipulation 🔗 https://t.co/sGPHf77I9T
📄 RoboEval: Where Robotic Manipulation Meets Structured and Scalable Evaluation 🔗 https://t.co/dDZgv08zdP
📄 Robotic Manipulation by Imitating Generated Videos Without Physical Demonstrations 🔗 https://t.co/iwfB2LfSEs
📄 DexH2R: A Benchmark for Dynamic Dexterous Grasping in Human-to-Robot Handover 🔗 https://t.co/ZEfpsHpHP0
📄 SAM4D: Segment Anything in Camera and LiDAR Streams 🔗 https://t.co/u1EPZzrEn1
Find more daily insights here: https://t.co/nXJyIf9GmN
#SimulatelyPapers | June 26, 2025
📄 DemoDiffusion: One-Shot Human Imitation using pre-trained Diffusion Policy 🔗 https://t.co/v3wtjn17mR | [Project](https://t.co/HGhcBeRojS)
📄 FORTE: Tactile Force and Slip Sensing on Compliant Fingers for Delicate Manipulation 🔗 https://t.co/yAezwm7lG0 | [Project](https://t.co/NvGucgPNdT)
📄 RoboTwin 2.0: A Scalable Data Generator and Benchmark with Strong Domain Randomization for Robust Bimanual Robotic Manipulation 🔗 https://t.co/hK7a71GpCc
📄 RoboArena: Distributed Real-World Evaluation of Generalist Robot Policies 🔗 https://t.co/R80fSufg08
📄 Learning Accurate Whole-body Throwing with High-frequency Residual Policy and Pullback Tube Acceleration 🔗 https://t.co/jyFBdmMIB3
📄 Dex1B: Learning with 1B Demonstrations for Dexterous Manipulation 🔗 https://t.co/nwL3rnjpjf | [Project](https://t.co/9D0A998yE9)
📄 Vision in Action: Learning Active Perception from Human Demonstrations 🔗 https://t.co/02Emx67fDA
Find more daily insights here: https://t.co/nXJyIf9GmN
#SimulatelyPapers | June 18, 2025
📄 ClutterDexGrasp: A Sim-to-Real System for General Dexterous Grasping in Cluttered Scenes 🔗 https://t.co/ysi3Lqiwnu | [Project](https://t.co/V6OIG0QkEI.)
📄 Tactile Beyond Pixels: Multisensory Touch Representations for Robot Manipulation 🔗 https://t.co/HDjlys2JYC
📄 GMT: General Motion Tracking for Humanoid Whole-Body Control 🔗 https://t.co/X739r3qJkx | [Project](https://t.co/HTedIwkSFx.)
📄 RL from Physical Feedback: Aligning Large Motion Models with Humanoid Control 🔗 https://t.co/m1JVHBqRHE
📄 From Experts to a Generalist: Toward General Whole-Body Control for Humanoid Robots 🔗 https://t.co/ujJDvXF1l8
📄 KungfuBot: Physics-Based Humanoid Whole-Body Control for Learning Highly-Dynamic Skills 🔗 https://t.co/gzgWHjffCL | [Project](https://t.co/jfCNmr0f2Q.)
📄 LeVERB: Humanoid Whole-Body Control with Latent Vision-Language Instruction 🔗 https://t.co/7q1OjpD2mo
📄 Prompting with the Future: Open-World Model Predictive Control with Interactive Digital Twins 🔗 https://t.co/Y5SOcnP1RR
📄 Touch begins where vision ends: Generalizable policies for contact-rich manipulation 🔗 https://t.co/VOYZgqjzDS | [Project](https://t.co/56gdGY7NY3.)
📄 Construction of a Multiple-DOF Under-actuated Gripper with Force-Sensing via Deep Learning 🔗 https://t.co/Qeb6R3H7cs
Find more daily insights here: https://t.co/nXJyIf9GmN
#SimulatelyPapers | June 03, 2025
📄 FreeTacMan: Robot-free Visuo-Tactile Data Collection System for Contact-rich Manipulation 🔗 https://t.co/0zNf1cZmAO
📄 Feel the Force: Contact-Driven Learning from Humans 🔗 https://t.co/3aUYQW8y3P | [Project](https://t.co/NyEVI3v02j.)
📄 Hold My Beer: Learning Gentle Humanoid Locomotion and End-Effector Stabilization Control 🔗 https://t.co/YyivLo1LOw
📄 SR3D: Unleashing Single-view 3D Reconstruction for Transparent and Specular Object Grasping 🔗 https://t.co/iThXIZpvzh
📄 DexMachina: Functional Retargeting for Bimanual Dexterous Manipulation 🔗 https://t.co/k45vhrPlDn | [Project](https://t.co/Tq52zAum9B)
Find more daily insights here: https://t.co/nXJyIf9GmN
#SimulatelyPapers | May 29, 2025
📄 DexUMI: Using Human Hand as the Universal Manipulation Interface for Dexterous Manipulation 🔗 https://t.co/0QwdpHKcLM
📄 SCIZOR: A Self-Supervised Approach to Data Curation for Large-Scale Imitation Learning 🔗 https://t.co/L0tc9Ht48P | [Project](https://t.co/fEoli6PwHS)
📄 LabUtopia: High-Fidelity Simulation and Hierarchical Benchmark for Scientific Embodied Agents 🔗 https://t.co/TMD5N1IrH7
📄 FastTD3: Simple, Fast, and Capable Reinforcement Learning for Humanoid Control 🔗 https://t.co/TMBJ0wMayZ
📄 Learning Generalizable Robot Policy with Human Demonstration Video as a Prompt 🔗 https://t.co/Otb1bWLZ89
📄 Learning Unified Force and Position Control for Legged Loco-Manipulation 🔗 https://t.co/bCiyruZVMR
📄 Hume: Introducing System-2 Thinking in Visual-Language-Action Model 🔗 https://t.co/tdH6nSVTQm
📄 CLAMP: Crowdsourcing a LArge-scale in-the-wild haptic dataset with an open-source device for Multimodal robot Perception 🔗 https://t.co/KNT2SkGaKo | [Project](https://t.co/zYgleu2ShT)
📄 MaskedManipulator: Versatile Whole-Body Control for Loco-Manipulation 🔗 https://t.co/HS1H3J0kOI
📄 Genie Centurion: Accelerating Scalable Real-World Robot Training with Human Rewind-and-Refine Guidance 🔗 https://t.co/gYSxqPtsYT
📄 ManiFeel: Benchmarking and Understanding Visuotactile Manipulation Policy Learning 🔗 https://t.co/cEeYXHRQZW | [Project](https://t.co/dEanxRhHYM)
📄 EgoZero: Robot Learning from Smart Glasses 🔗 https://t.co/9wQUHnaUJh | [Project](https://t.co/OYA6IvH26s.)
Find more daily insights here: https://t.co/nXJyIf9GmN
#SimulatelyPapers | May 25, 2025
📄 EasyInsert: A Data-Efficient and Generalizable Insertion Policy 🔗 https://t.co/EkMOunwRiH
📄 FLARE: Robot Learning with Implicit World Modeling 🔗 https://t.co/S6649Vw3jl
📄 FLARE: Robot Learning with Implicit World Modeling 🔗 https://t.co/S6649Vw3jl
📄 LaDi-WM: A Latent Diffusion-based World Model for Predictive Manipulation 🔗 https://t.co/8RUiZUY2uL
📄 H2R: A Human-to-Robot Data Augmentation for Robot Pre-training from Videos 🔗 https://t.co/TnIwXEQw7k
📄 OneTwoVLA: A Unified Vision-Language-Action Model with Adaptive Reasoning 🔗 https://t.co/FfMIY8q4R1
📄 Emergent Active Perception and Dexterity of Simulated Humanoids from Visual Reinforcement Learning 🔗 https://t.co/VnxzvLWm18
📄 DreamGen: Unlocking Generalization in Robot Learning through Neural Trajectories 🔗 https://t.co/9QcuIcR4ZC
📄 TeleOpBench: A Simulator-Centric Benchmark for Dual-Arm Dexterous Teleoperation 🔗 https://t.co/2dVIcoby3W
📄 GraspMolmo: Generalizable Task-Oriented Grasping via Large-Scale Synthetic Data Generation 🔗 https://t.co/8MPKGyxysL | [Project](https://t.co/ZtOWoEaQaV.)
📄 TartanGround: A Large-Scale Dataset for Ground Robot Perception and Navigation 🔗 https://t.co/rJXxjalQsv | [Project](https://t.co/OzVPZkuN07)
📄 Infinigen-Sim: Procedural Generation of Articulated Simulation Assets 🔗 https://t.co/pSBJlQnept
📄 DexGarmentLab: Dexterous Garment Manipulation Environment with Generalizable Policy 🔗 https://t.co/x00x7Ulpfl | [Project](https://t.co/toGl98zRAY.)
Find more daily insights here: https://t.co/nXJyIf98xf
#SimulatelyPapers | May 07, 2025
📄 MetaScenes: Towards Automated Replica Creation for Real-world 3D Scans 🔗 https://t.co/DZhLvV1O3b | [Project](https://t.co/5Fmvrefmnz.)
📄 TWIST: Teleoperated Whole-Body Imitation System 🔗 https://t.co/WdyrbaGtsR | [Project](https://t.co/mP9dpJie9y)
📄 GENMO: A GENeralist Model for Human MOtion 🔗 https://t.co/k2HErgIWGy
📄 IK Seed Generator for Dual-Arm Human-like Physicality Robot with Mobile Base 🔗 https://t.co/Vyzl4e4iK2
📄 Towards Autonomous Micromobility through Scalable Urban Simulation 🔗 https://t.co/pxAaxGokld
Find more daily insights here: https://t.co/nXJyIf9GmN
#SimulatelyPapers | April 20, 2025
📄 UniPhys: Unified Planner and Controller with Diffusion for Flexible Physics-Based Character Control 🔗 https://t.co/7E1EiXbvCq
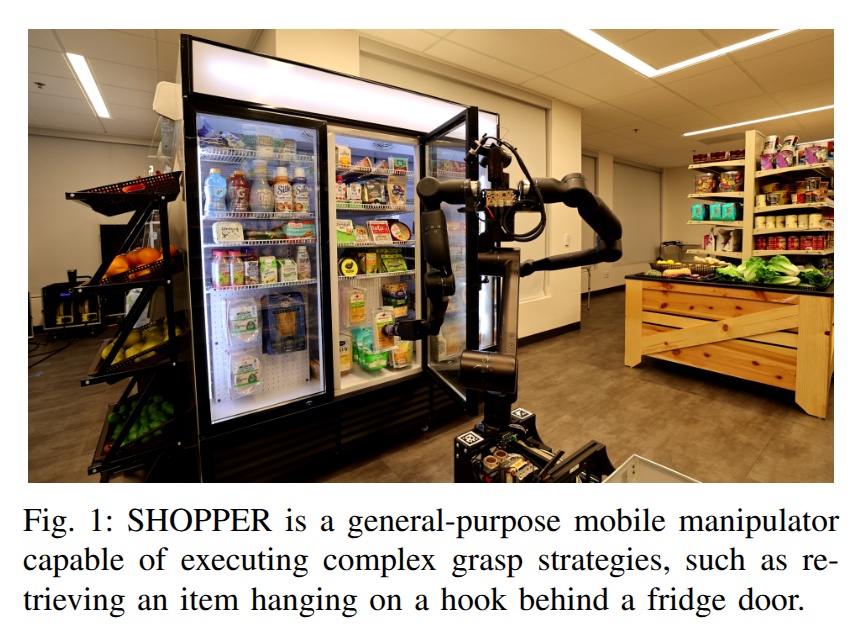
📄 Practical Insights on Grasp Strategies for Mobile Manipulation in the Wild 🔗 https://t.co/QdkuHH1D3E
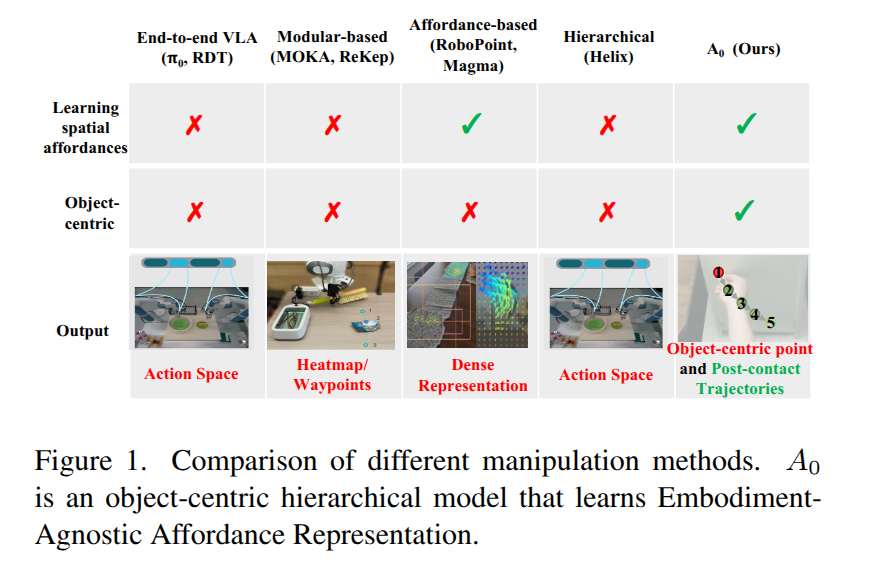
📄 A0: An Affordance-Aware Hierarchical Model for General Robotic Manipulation 🔗 https://t.co/o0fJBhHDQo
📄 B*: Efficient and Optimal Base Placement for Fixed-Base Manipulators 🔗 https://t.co/U9GPJGGRXi
📄 RoboTwin: Dual-Arm Robot Benchmark with Generative Digital Twins 🔗 https://t.co/IjDEf28gtQ
Find more daily insights here: https://t.co/nXJyIf9GmN
In my past research experience, finding or developing an appropriate simulation environment, dataset, and benchmark has always been a challenge. Missing features, limited support, or unexpected bugs often occupied my days and nights. Moreover, current simulation platforms are relatively fragmented—making it challenging to replicate the success of the RT-X dataset in unifying community efforts.
Introducing RoboVerse, we provide a unified platform, dataset, and benchmark for scalable and generalizable robot learning. We hope to build a shared foundation to combine the community efforts. RoboVerse includes:
MetaSim: We carefully designed a configuration system and a universal interface to align current robotic simulators. With MetaSim, you can use any simulator with the same code—bringing together the community’s diverse efforts under one framework!
RoboVerse Dataset and Benchmark: We unify popular simulation environments and benchmarks into a single cohesive system and introduce the RoboVerse dataset—a large-scale, high-quality synthetic dataset. Additionally, we propose a standardized benchmark across both imitation learning and reinforcement learning.
A cool feature enabled by our unified framework: Hybrid Simulation! You can now integrate physics engines and renderers from different simulators—e.g., using MuJoCo precise physics with Isaac photorealistic rendering. This not only elevates simulation fidelity but also significantly enhances real-world transfer performance across complex robotic applications.
Hopefully, our team’s efforts could serve the robotic community to thrive vibrantly in the years to come.
RoboVerse is open-sourced🥳!!!
Project Page: https://t.co/IJR1iuEW1L
Documentation: https://t.co/7Ff4uhbJR0
Github Repo: https://t.co/iLRpjSNokQ
Paper: https://t.co/LUMJrd6i5I
#SimulatelyPapers | March 27, 2025
📄 Gemini Robotics: Bringing AI into the Physical World 🔗 https://t.co/NneKfdvxMF
📄 MoLe-VLA: Dynamic Layer-skipping Vision Language Action Model via Mixture-of-Layers for Efficient Robot Manipulation 🔗 https://t.co/9GfMfYwE2B
📄 OpenLex3D: A New Evaluation Benchmark for Open-Vocabulary 3D Scene Representations 🔗 https://t.co/dO7MAyFqfB | [Project](https://t.co/IoLtbt6hln.)
📄 G-DexGrasp: Generalizable Dexterous Grasping Synthesis Via Part-Aware Prior Retrieval and Prior-Assisted Generation 🔗 https://t.co/pNYGStcG2a | [Project](https://t.co/OfspEbuG5P)
📄 SG-Tailor: Inter-Object Commonsense Relationship Reasoning for Scene Graph Manipulation 🔗 https://t.co/SFOnYlJaf2
📄 Dita: Scaling Diffusion Transformer for Generalist Vision-Language-Action Policy 🔗 https://t.co/wnkiZJQWpI | [Project](https://t.co/TaAsuogaqm.)
📄 Visuo-Tactile Object Pose Estimation for a Multi-Finger Robot Hand with Low-Resolution In-Hand Tactile Sensing 🔗 https://t.co/GNSKSErhEB
📄 Any6D: Model-free 6D Pose Estimation of Novel Objects 🔗 https://t.co/MaJFBNE6yK | [Project](https://t.co/lkoHnBq9yh)
📄 RoboEngine: Plug-and-Play Robot Data Augmentation with Semantic Robot Segmentation and Background Generation 🔗 https://t.co/Oz0O7pIGz8
📄 Unraveling the Effects of Synthetic Data on End-to-End Autonomous Driving 🔗 https://t.co/i10oqeA3vT
Find more daily insights here: https://t.co/nXJyIf9GmN


📄 Touch in the Wild: Learning Fine-Grained Manipulation with a Portable Visuo-Tactile Gripper 🔗 https://t.co/vFubzvVo7s | [Project](https://t.co/ETelxAcbIy)
📄 GR-3 Technical Report 🔗 https://t.co/oayyqVQX0Q
📄 AnyPos: Automated Task-Agnostic Actions for Bimanual Manipulation 🔗 https://t.co/LOGstCNMVG | [Project](https://t.co/aWE5wQZoNj)
📄 Generalist Bimanual Manipulation via Foundation Video Diffusion Models 🔗 https://t.co/4uYHIj2mjd
📄 GraspGen: A Diffusion-based Framework for 6-DOF Grasping with On-Generator Training 🔗 https://t.co/zEoiPZpe6f
📄 Latent Policy Steering with Embodiment-Agnostic Pretrained World Models 🔗 https://t.co/iNFlbor5Lr
📄 EgoVLA: Learning Vision-Language-Action Models from Egocentric Human Videos 🔗 https://t.co/gLTxiraTs7 | [Project](https://t.co/1Ey70yeiEN)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gwbx4r7a4AAsog1.jpg)

📄 Touch in the Wild: Learning Fine-Grained Manipulation with a Portable Visuo-Tactile Gripper 🔗 https://t.co/vFubzvVo7s | [Project](https://t.co/ETelxAcbIy)
📄 GR-3 Technical Report 🔗 https://t.co/oayyqVQX0Q
📄 AnyPos: Automated Task-Agnostic Actions for Bimanual Manipulation 🔗 https://t.co/LOGstCNMVG | [Project](https://t.co/aWE5wQZoNj)
📄 Generalist Bimanual Manipulation via Foundation Video Diffusion Models 🔗 https://t.co/4uYHIj2mjd
📄 GraspGen: A Diffusion-based Framework for 6-DOF Grasping with On-Generator Training 🔗 https://t.co/zEoiPZpe6f
📄 Latent Policy Steering with Embodiment-Agnostic Pretrained World Models 🔗 https://t.co/iNFlbor5Lr
📄 EgoVLA: Learning Vision-Language-Action Models from Egocentric Human Videos 🔗 https://t.co/gLTxiraTs7 | [Project](https://t.co/1Ey70yeiEN)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gwbx4o2bEAEA4UL.jpg)

📄 Touch in the Wild: Learning Fine-Grained Manipulation with a Portable Visuo-Tactile Gripper 🔗 https://t.co/vFubzvVo7s | [Project](https://t.co/ETelxAcbIy)
📄 GR-3 Technical Report 🔗 https://t.co/oayyqVQX0Q
📄 AnyPos: Automated Task-Agnostic Actions for Bimanual Manipulation 🔗 https://t.co/LOGstCNMVG | [Project](https://t.co/aWE5wQZoNj)
📄 Generalist Bimanual Manipulation via Foundation Video Diffusion Models 🔗 https://t.co/4uYHIj2mjd
📄 GraspGen: A Diffusion-based Framework for 6-DOF Grasping with On-Generator Training 🔗 https://t.co/zEoiPZpe6f
📄 Latent Policy Steering with Embodiment-Agnostic Pretrained World Models 🔗 https://t.co/iNFlbor5Lr
📄 EgoVLA: Learning Vision-Language-Action Models from Egocentric Human Videos 🔗 https://t.co/gLTxiraTs7 | [Project](https://t.co/1Ey70yeiEN)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gwbx4oxbEAI5av5.jpg)

📄 SimLauncher: Launching Sample-Efficient Real-world Robotic Reinforcement Learning via Simulation Pre-training 🔗 https://t.co/WLCguXbMTG
📄 DexVLG: Dexterous Vision-Language-Grasp Model at Scale 🔗 https://t.co/SuX7ROEyhZ
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gv5pDaZWgAAdjV4.jpg)

📄 SimLauncher: Launching Sample-Efficient Real-world Robotic Reinforcement Learning via Simulation Pre-training 🔗 https://t.co/WLCguXbMTG
📄 DexVLG: Dexterous Vision-Language-Grasp Model at Scale 🔗 https://t.co/SuX7ROEyhZ
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gv5pDZza4AUZ-mg.jpg)

📄 SimLauncher: Launching Sample-Efficient Real-world Robotic Reinforcement Learning via Simulation Pre-training 🔗 https://t.co/WLCguXbMTG
📄 DexVLG: Dexterous Vision-Language-Grasp Model at Scale 🔗 https://t.co/SuX7ROEyhZ
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gv5pDZza4AMk7fm.png)

📄 FORTE: Tactile Force and Slip Sensing on Compliant Fingers for Delicate Manipulation 🔗 https://t.co/yAezwm7lG0 | [Project](https://t.co/NvGucgPNdT)
📄 RoboTwin 2.0: A Scalable Data Generator and Benchmark with Strong Domain Randomization for Robust Bimanual Robotic Manipulation 🔗 https://t.co/hK7a71GpCc
📄 RoboArena: Distributed Real-World Evaluation of Generalist Robot Policies 🔗 https://t.co/R80fSufg08
📄 Learning Accurate Whole-body Throwing with High-frequency Residual Policy and Pullback Tube Acceleration 🔗 https://t.co/jyFBdmMIB3
📄 Dex1B: Learning with 1B Demonstrations for Dexterous Manipulation 🔗 https://t.co/nwL3rnjpjf | [Project](https://t.co/9D0A998yE9)
📄 Vision in Action: Learning Active Perception from Human Demonstrations 🔗 https://t.co/02Emx67fDA
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gu74ZAFb0AUswSP.jpg)

📄 FORTE: Tactile Force and Slip Sensing on Compliant Fingers for Delicate Manipulation 🔗 https://t.co/yAezwm7lG0 | [Project](https://t.co/NvGucgPNdT)
📄 RoboTwin 2.0: A Scalable Data Generator and Benchmark with Strong Domain Randomization for Robust Bimanual Robotic Manipulation 🔗 https://t.co/hK7a71GpCc
📄 RoboArena: Distributed Real-World Evaluation of Generalist Robot Policies 🔗 https://t.co/R80fSufg08
📄 Learning Accurate Whole-body Throwing with High-frequency Residual Policy and Pullback Tube Acceleration 🔗 https://t.co/jyFBdmMIB3
📄 Dex1B: Learning with 1B Demonstrations for Dexterous Manipulation 🔗 https://t.co/nwL3rnjpjf | [Project](https://t.co/9D0A998yE9)
📄 Vision in Action: Learning Active Perception from Human Demonstrations 🔗 https://t.co/02Emx67fDA
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gu74ZADb0AIpDM2.jpg)

📄 FORTE: Tactile Force and Slip Sensing on Compliant Fingers for Delicate Manipulation 🔗 https://t.co/yAezwm7lG0 | [Project](https://t.co/NvGucgPNdT)
📄 RoboTwin 2.0: A Scalable Data Generator and Benchmark with Strong Domain Randomization for Robust Bimanual Robotic Manipulation 🔗 https://t.co/hK7a71GpCc
📄 RoboArena: Distributed Real-World Evaluation of Generalist Robot Policies 🔗 https://t.co/R80fSufg08
📄 Learning Accurate Whole-body Throwing with High-frequency Residual Policy and Pullback Tube Acceleration 🔗 https://t.co/jyFBdmMIB3
📄 Dex1B: Learning with 1B Demonstrations for Dexterous Manipulation 🔗 https://t.co/nwL3rnjpjf | [Project](https://t.co/9D0A998yE9)
📄 Vision in Action: Learning Active Perception from Human Demonstrations 🔗 https://t.co/02Emx67fDA
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gu74ZACb0AEck7a.jpg)

📄 FORTE: Tactile Force and Slip Sensing on Compliant Fingers for Delicate Manipulation 🔗 https://t.co/yAezwm7lG0 | [Project](https://t.co/NvGucgPNdT)
📄 RoboTwin 2.0: A Scalable Data Generator and Benchmark with Strong Domain Randomization for Robust Bimanual Robotic Manipulation 🔗 https://t.co/hK7a71GpCc
📄 RoboArena: Distributed Real-World Evaluation of Generalist Robot Policies 🔗 https://t.co/R80fSufg08
📄 Learning Accurate Whole-body Throwing with High-frequency Residual Policy and Pullback Tube Acceleration 🔗 https://t.co/jyFBdmMIB3
📄 Dex1B: Learning with 1B Demonstrations for Dexterous Manipulation 🔗 https://t.co/nwL3rnjpjf | [Project](https://t.co/9D0A998yE9)
📄 Vision in Action: Learning Active Perception from Human Demonstrations 🔗 https://t.co/02Emx67fDA
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GuXEYh1bYAElUWR.jpg)

📄 FORTE: Tactile Force and Slip Sensing on Compliant Fingers for Delicate Manipulation 🔗 https://t.co/yAezwm7lG0 | [Project](https://t.co/NvGucgPNdT)
📄 RoboTwin 2.0: A Scalable Data Generator and Benchmark with Strong Domain Randomization for Robust Bimanual Robotic Manipulation 🔗 https://t.co/hK7a71GpCc
📄 RoboArena: Distributed Real-World Evaluation of Generalist Robot Policies 🔗 https://t.co/R80fSufg08
📄 Learning Accurate Whole-body Throwing with High-frequency Residual Policy and Pullback Tube Acceleration 🔗 https://t.co/jyFBdmMIB3
📄 Dex1B: Learning with 1B Demonstrations for Dexterous Manipulation 🔗 https://t.co/nwL3rnjpjf | [Project](https://t.co/9D0A998yE9)
📄 Vision in Action: Learning Active Perception from Human Demonstrations 🔗 https://t.co/02Emx67fDA
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GuXEYhzbEAQ6jRj.jpg)

📄 FORTE: Tactile Force and Slip Sensing on Compliant Fingers for Delicate Manipulation 🔗 https://t.co/yAezwm7lG0 | [Project](https://t.co/NvGucgPNdT)
📄 RoboTwin 2.0: A Scalable Data Generator and Benchmark with Strong Domain Randomization for Robust Bimanual Robotic Manipulation 🔗 https://t.co/hK7a71GpCc
📄 RoboArena: Distributed Real-World Evaluation of Generalist Robot Policies 🔗 https://t.co/R80fSufg08
📄 Learning Accurate Whole-body Throwing with High-frequency Residual Policy and Pullback Tube Acceleration 🔗 https://t.co/jyFBdmMIB3
📄 Dex1B: Learning with 1B Demonstrations for Dexterous Manipulation 🔗 https://t.co/nwL3rnjpjf | [Project](https://t.co/9D0A998yE9)
📄 Vision in Action: Learning Active Perception from Human Demonstrations 🔗 https://t.co/02Emx67fDA
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GuXEYhtaMAATJoX.png)

📄 Tactile Beyond Pixels: Multisensory Touch Representations for Robot Manipulation 🔗 https://t.co/HDjlys2JYC
📄 GMT: General Motion Tracking for Humanoid Whole-Body Control 🔗 https://t.co/X739r3qJkx | [Project](https://t.co/HTedIwkSFx.)
📄 RL from Physical Feedback: Aligning Large Motion Models with Humanoid Control 🔗 https://t.co/m1JVHBqRHE
📄 From Experts to a Generalist: Toward General Whole-Body Control for Humanoid Robots 🔗 https://t.co/ujJDvXF1l8
📄 KungfuBot: Physics-Based Humanoid Whole-Body Control for Learning Highly-Dynamic Skills 🔗 https://t.co/gzgWHjffCL | [Project](https://t.co/jfCNmr0f2Q.)
📄 LeVERB: Humanoid Whole-Body Control with Latent Vision-Language Instruction 🔗 https://t.co/7q1OjpD2mo
📄 Prompting with the Future: Open-World Model Predictive Control with Interactive Digital Twins 🔗 https://t.co/Y5SOcnP1RR
📄 Touch begins where vision ends: Generalizable policies for contact-rich manipulation 🔗 https://t.co/VOYZgqjzDS | [Project](https://t.co/56gdGY7NY3.)
📄 Construction of a Multiple-DOF Under-actuated Gripper with Force-Sensing via Deep Learning 🔗 https://t.co/Qeb6R3H7cs
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gttm7t5WMAAFvM-.jpg)

📄 Tactile Beyond Pixels: Multisensory Touch Representations for Robot Manipulation 🔗 https://t.co/HDjlys2JYC
📄 GMT: General Motion Tracking for Humanoid Whole-Body Control 🔗 https://t.co/X739r3qJkx | [Project](https://t.co/HTedIwkSFx.)
📄 RL from Physical Feedback: Aligning Large Motion Models with Humanoid Control 🔗 https://t.co/m1JVHBqRHE
📄 From Experts to a Generalist: Toward General Whole-Body Control for Humanoid Robots 🔗 https://t.co/ujJDvXF1l8
📄 KungfuBot: Physics-Based Humanoid Whole-Body Control for Learning Highly-Dynamic Skills 🔗 https://t.co/gzgWHjffCL | [Project](https://t.co/jfCNmr0f2Q.)
📄 LeVERB: Humanoid Whole-Body Control with Latent Vision-Language Instruction 🔗 https://t.co/7q1OjpD2mo
📄 Prompting with the Future: Open-World Model Predictive Control with Interactive Digital Twins 🔗 https://t.co/Y5SOcnP1RR
📄 Touch begins where vision ends: Generalizable policies for contact-rich manipulation 🔗 https://t.co/VOYZgqjzDS | [Project](https://t.co/56gdGY7NY3.)
📄 Construction of a Multiple-DOF Under-actuated Gripper with Force-Sensing via Deep Learning 🔗 https://t.co/Qeb6R3H7cs
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gttm7tOaQAYZD02.jpg)

📄 GENMANIP: LLM-driven Simulation for Generalizable Instruction-Following Manipulation 🔗 https://t.co/84WjQbNWmQ | [Project](https://t.co/nNSY84ZKGd.)
📄 Eye, Robot: Learning to Look to Act with a BC-RL Perception-Action Loop 🔗 https://t.co/ybNgIh2dGA | [Project](https://t.co/z2FFgEsd93)
📄 UAD: Unsupervised Affordance Distillation for Generalization in Robotic Manipulation 🔗 https://t.co/jS4ryGdJlR | [Project](https://t.co/h2bbTghqh5)
📄 SkillBlender: Towards Versatile Humanoid Whole-Body Loco-Manipulation via Skill Blending 🔗 https://t.co/Nmo8sMpvKg | [Project](https://t.co/lT40txN3R3.)
📄 CLONE: Closed-Loop Whole-Body Humanoid Teleoperation for Long-Horizon Tasks 🔗 https://t.co/rdh7jtIitL
📄 Real-Time Execution of Action Chunking Flow Policies 🔗 https://t.co/0yhGhwVDAX | [Project](https://t.co/p04ZvnW83e)
📄 Versatile Loco-Manipulation through Flexible Interlimb Coordination 🔗 https://t.co/9c0Gwpw4ps | [Project](https://t.co/0kuHPsoHuF.)
📄 Improving Long-Range Navigation with Spatially-Enhanced Recurrent Memory via End-to-End Reinforcement Learning 🔗 https://t.co/yK9GVYphqb
📄 3DFlowAction: Learning Cross-Embodiment Manipulation from 3D Flow World Model 🔗 https://t.co/LEjaEDieH8
📄 BiAssemble: Learning Collaborative Affordance for Bimanual Geometric Assembly 🔗 https://t.co/0yia0hiw2D | [Project](https://t.co/lzBloNA41P.)
📄 DemoSpeedup: Accelerating Visuomotor Policies via Entropy-Guided Demonstration Acceleration 🔗 https://t.co/Nu8ZSdcOs7 | [Project](https://t.co/VEIxCixOVk)
📄 Fabrica: Dual-Arm Assembly of General Multi-Part Objects via Integrated Planning and Learning 🔗 https://t.co/33tYFBretr | [Project](https://t.co/tJuosLUJyb)
📄 OWMM-Agent: Open World Mobile Manipulation With Multi-modal Agentic Data Synthesis 🔗 https://t.co/htgPsDz7fF | [Project](https://t.co/udtHe3a4JH)
📄 Object-centric 3D Motion Field for Robot Learning from Human Videos 🔗 https://t.co/KYuNboOomD
📄 Rodrigues Network for Learning Robot Actions 🔗 https://t.co/zBp5vEVeAp
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GtZxX6waQAAyF9l.jpg)

📄 GENMANIP: LLM-driven Simulation for Generalizable Instruction-Following Manipulation 🔗 https://t.co/84WjQbNWmQ | [Project](https://t.co/nNSY84ZKGd.)
📄 Eye, Robot: Learning to Look to Act with a BC-RL Perception-Action Loop 🔗 https://t.co/ybNgIh2dGA | [Project](https://t.co/z2FFgEsd93)
📄 UAD: Unsupervised Affordance Distillation for Generalization in Robotic Manipulation 🔗 https://t.co/jS4ryGdJlR | [Project](https://t.co/h2bbTghqh5)
📄 SkillBlender: Towards Versatile Humanoid Whole-Body Loco-Manipulation via Skill Blending 🔗 https://t.co/Nmo8sMpvKg | [Project](https://t.co/lT40txN3R3.)
📄 CLONE: Closed-Loop Whole-Body Humanoid Teleoperation for Long-Horizon Tasks 🔗 https://t.co/rdh7jtIitL
📄 Real-Time Execution of Action Chunking Flow Policies 🔗 https://t.co/0yhGhwVDAX | [Project](https://t.co/p04ZvnW83e)
📄 Versatile Loco-Manipulation through Flexible Interlimb Coordination 🔗 https://t.co/9c0Gwpw4ps | [Project](https://t.co/0kuHPsoHuF.)
📄 Improving Long-Range Navigation with Spatially-Enhanced Recurrent Memory via End-to-End Reinforcement Learning 🔗 https://t.co/yK9GVYphqb
📄 3DFlowAction: Learning Cross-Embodiment Manipulation from 3D Flow World Model 🔗 https://t.co/LEjaEDieH8
📄 BiAssemble: Learning Collaborative Affordance for Bimanual Geometric Assembly 🔗 https://t.co/0yia0hiw2D | [Project](https://t.co/lzBloNA41P.)
📄 DemoSpeedup: Accelerating Visuomotor Policies via Entropy-Guided Demonstration Acceleration 🔗 https://t.co/Nu8ZSdcOs7 | [Project](https://t.co/VEIxCixOVk)
📄 Fabrica: Dual-Arm Assembly of General Multi-Part Objects via Integrated Planning and Learning 🔗 https://t.co/33tYFBretr | [Project](https://t.co/tJuosLUJyb)
📄 OWMM-Agent: Open World Mobile Manipulation With Multi-modal Agentic Data Synthesis 🔗 https://t.co/htgPsDz7fF | [Project](https://t.co/udtHe3a4JH)
📄 Object-centric 3D Motion Field for Robot Learning from Human Videos 🔗 https://t.co/KYuNboOomD
📄 Rodrigues Network for Learning Robot Actions 🔗 https://t.co/zBp5vEVeAp
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GtZxX6ubUAAhDPe.jpg)

📄 GENMANIP: LLM-driven Simulation for Generalizable Instruction-Following Manipulation 🔗 https://t.co/84WjQbNWmQ | [Project](https://t.co/nNSY84ZKGd.)
📄 Eye, Robot: Learning to Look to Act with a BC-RL Perception-Action Loop 🔗 https://t.co/ybNgIh2dGA | [Project](https://t.co/z2FFgEsd93)
📄 UAD: Unsupervised Affordance Distillation for Generalization in Robotic Manipulation 🔗 https://t.co/jS4ryGdJlR | [Project](https://t.co/h2bbTghqh5)
📄 SkillBlender: Towards Versatile Humanoid Whole-Body Loco-Manipulation via Skill Blending 🔗 https://t.co/Nmo8sMpvKg | [Project](https://t.co/lT40txN3R3.)
📄 CLONE: Closed-Loop Whole-Body Humanoid Teleoperation for Long-Horizon Tasks 🔗 https://t.co/rdh7jtIitL
📄 Real-Time Execution of Action Chunking Flow Policies 🔗 https://t.co/0yhGhwVDAX | [Project](https://t.co/p04ZvnW83e)
📄 Versatile Loco-Manipulation through Flexible Interlimb Coordination 🔗 https://t.co/9c0Gwpw4ps | [Project](https://t.co/0kuHPsoHuF.)
📄 Improving Long-Range Navigation with Spatially-Enhanced Recurrent Memory via End-to-End Reinforcement Learning 🔗 https://t.co/yK9GVYphqb
📄 3DFlowAction: Learning Cross-Embodiment Manipulation from 3D Flow World Model 🔗 https://t.co/LEjaEDieH8
📄 BiAssemble: Learning Collaborative Affordance for Bimanual Geometric Assembly 🔗 https://t.co/0yia0hiw2D | [Project](https://t.co/lzBloNA41P.)
📄 DemoSpeedup: Accelerating Visuomotor Policies via Entropy-Guided Demonstration Acceleration 🔗 https://t.co/Nu8ZSdcOs7 | [Project](https://t.co/VEIxCixOVk)
📄 Fabrica: Dual-Arm Assembly of General Multi-Part Objects via Integrated Planning and Learning 🔗 https://t.co/33tYFBretr | [Project](https://t.co/tJuosLUJyb)
📄 OWMM-Agent: Open World Mobile Manipulation With Multi-modal Agentic Data Synthesis 🔗 https://t.co/htgPsDz7fF | [Project](https://t.co/udtHe3a4JH)
📄 Object-centric 3D Motion Field for Robot Learning from Human Videos 🔗 https://t.co/KYuNboOomD
📄 Rodrigues Network for Learning Robot Actions 🔗 https://t.co/zBp5vEVeAp
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GtZxX6ubQAAIz3b.jpg)

📄 Hold My Beer: Learning Gentle Humanoid Locomotion and End-Effector Stabilization Control 🔗 https://t.co/YyivLo1LOw
📄 SR3D: Unleashing Single-view 3D Reconstruction for Transparent and Specular Object Grasping 🔗 https://t.co/iThXIZpvzh
📄 DexMachina: Functional Retargeting for Bimanual Dexterous Manipulation 🔗 https://t.co/k45vhrPlDn | [Project](https://t.co/Tq52zAum9B)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GtYDLWbbcAAAuun.jpg)

📄 Hold My Beer: Learning Gentle Humanoid Locomotion and End-Effector Stabilization Control 🔗 https://t.co/YyivLo1LOw
📄 SR3D: Unleashing Single-view 3D Reconstruction for Transparent and Specular Object Grasping 🔗 https://t.co/iThXIZpvzh
📄 DexMachina: Functional Retargeting for Bimanual Dexterous Manipulation 🔗 https://t.co/k45vhrPlDn | [Project](https://t.co/Tq52zAum9B)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GtYDLWabMAAZtX4.jpg)

📄 Hold My Beer: Learning Gentle Humanoid Locomotion and End-Effector Stabilization Control 🔗 https://t.co/YyivLo1LOw
📄 SR3D: Unleashing Single-view 3D Reconstruction for Transparent and Specular Object Grasping 🔗 https://t.co/iThXIZpvzh
📄 DexMachina: Functional Retargeting for Bimanual Dexterous Manipulation 🔗 https://t.co/k45vhrPlDn | [Project](https://t.co/Tq52zAum9B)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GtYDLWYaoAAkY3S.jpg)

📄 LabUtopia: High-Fidelity Simulation and Hierarchical Benchmark for Scientific Embodied Agents 🔗 https://t.co/TMD5N1IrH7
📄 FastTD3: Simple, Fast, and Capable Reinforcement Learning for Humanoid Control 🔗 https://t.co/TMBJ0wMayZ
📄 Learning Generalizable Robot Policy with Human Demonstration Video as a Prompt 🔗 https://t.co/Otb1bWLZ89
📄 Learning Unified Force and Position Control for Legged Loco-Manipulation 🔗 https://t.co/bCiyruZVMR
📄 Hume: Introducing System-2 Thinking in Visual-Language-Action Model 🔗 https://t.co/tdH6nSVTQm
📄 CLAMP: Crowdsourcing a LArge-scale in-the-wild haptic dataset with an open-source device for Multimodal robot Perception 🔗 https://t.co/KNT2SkGaKo | [Project](https://t.co/zYgleu2ShT)
📄 MaskedManipulator: Versatile Whole-Body Control for Loco-Manipulation 🔗 https://t.co/HS1H3J0kOI
📄 Genie Centurion: Accelerating Scalable Real-World Robot Training with Human Rewind-and-Refine Guidance 🔗 https://t.co/gYSxqPtsYT
📄 ManiFeel: Benchmarking and Understanding Visuotactile Manipulation Policy Learning 🔗 https://t.co/cEeYXHRQZW | [Project](https://t.co/dEanxRhHYM)
📄 EgoZero: Robot Learning from Smart Glasses 🔗 https://t.co/9wQUHnaUJh | [Project](https://t.co/OYA6IvH26s.)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GtImk0kboAAqVYv.jpg)

📄 LabUtopia: High-Fidelity Simulation and Hierarchical Benchmark for Scientific Embodied Agents 🔗 https://t.co/TMD5N1IrH7
📄 FastTD3: Simple, Fast, and Capable Reinforcement Learning for Humanoid Control 🔗 https://t.co/TMBJ0wMayZ
📄 Learning Generalizable Robot Policy with Human Demonstration Video as a Prompt 🔗 https://t.co/Otb1bWLZ89
📄 Learning Unified Force and Position Control for Legged Loco-Manipulation 🔗 https://t.co/bCiyruZVMR
📄 Hume: Introducing System-2 Thinking in Visual-Language-Action Model 🔗 https://t.co/tdH6nSVTQm
📄 CLAMP: Crowdsourcing a LArge-scale in-the-wild haptic dataset with an open-source device for Multimodal robot Perception 🔗 https://t.co/KNT2SkGaKo | [Project](https://t.co/zYgleu2ShT)
📄 MaskedManipulator: Versatile Whole-Body Control for Loco-Manipulation 🔗 https://t.co/HS1H3J0kOI
📄 Genie Centurion: Accelerating Scalable Real-World Robot Training with Human Rewind-and-Refine Guidance 🔗 https://t.co/gYSxqPtsYT
📄 ManiFeel: Benchmarking and Understanding Visuotactile Manipulation Policy Learning 🔗 https://t.co/cEeYXHRQZW | [Project](https://t.co/dEanxRhHYM)
📄 EgoZero: Robot Learning from Smart Glasses 🔗 https://t.co/9wQUHnaUJh | [Project](https://t.co/OYA6IvH26s.)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GtImk0hbMAYL9tC.jpg)

📄 TartanGround: A Large-Scale Dataset for Ground Robot Perception and Navigation 🔗 https://t.co/rJXxjalQsv | [Project](https://t.co/OzVPZkuN07)
📄 Infinigen-Sim: Procedural Generation of Articulated Simulation Assets 🔗 https://t.co/pSBJlQnept
📄 DexGarmentLab: Dexterous Garment Manipulation Environment with Generalizable Policy 🔗 https://t.co/x00x7Ulpfl | [Project](https://t.co/toGl98zRAY.)
Find more daily insights here: https://t.co/nXJyIf98xf](https://pbs.twimg.com/media/GrzqMyFW4AATqNL.jpg)

📄 TartanGround: A Large-Scale Dataset for Ground Robot Perception and Navigation 🔗 https://t.co/rJXxjalQsv | [Project](https://t.co/OzVPZkuN07)
📄 Infinigen-Sim: Procedural Generation of Articulated Simulation Assets 🔗 https://t.co/pSBJlQnept
📄 DexGarmentLab: Dexterous Garment Manipulation Environment with Generalizable Policy 🔗 https://t.co/x00x7Ulpfl | [Project](https://t.co/toGl98zRAY.)
Find more daily insights here: https://t.co/nXJyIf98xf](https://pbs.twimg.com/media/GrzqMyAXcAAriWy.jpg)

📄 Real2Render2Real: Scaling Robot Data Without Dynamics Simulation or Robot Hardware 🔗 https://t.co/oZ7MNGYQgh | [Project](https://t.co/qwcC4OVUY3)
📄 What Matters for Batch Online Reinforcement Learning in Robotics? 🔗 https://t.co/9S8FbDvg1b
📄 NavDP: Learning Sim-to-Real Navigation Diffusion Policy with Privileged Information Guidance 🔗 https://t.co/LRQxCnlQPW
📄 DexWild: Dexterous Human Interactions for In-the-Wild Robot Policies 🔗 https://t.co/wd45liuWHk | [Project](https://t.co/KA1F3j0bov)
📄 H$^{\mathbf{3}}$DP: Triply-Hierarchical Diffusion Policy for Visuomotor Learning 🔗 https://t.co/YVnfhL4Pgj | [Project](https://t.co/jgphjgNUJ9.)
📄 Web2Grasp: Learning Functional Grasps from Web Images of Hand-Object Interactions 🔗 https://t.co/gdnSNV5MFw | [Project](https://t.co/SsmriV8ZFy.)
📄 Occupancy World Model for Robots 🔗 https://t.co/nzQfnboRoV
📄 UniVLA: Learning to Act Anywhere with Task-centric Latent Actions 🔗 https://t.co/nnyNiwvAej
📄 Let Humanoids Hike! Integrative Skill Development on Complex Trails 🔗 https://t.co/6iZIKabHte
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Grj28rSboAUseZJ.jpg)

📄 Real2Render2Real: Scaling Robot Data Without Dynamics Simulation or Robot Hardware 🔗 https://t.co/oZ7MNGYQgh | [Project](https://t.co/qwcC4OVUY3)
📄 What Matters for Batch Online Reinforcement Learning in Robotics? 🔗 https://t.co/9S8FbDvg1b
📄 NavDP: Learning Sim-to-Real Navigation Diffusion Policy with Privileged Information Guidance 🔗 https://t.co/LRQxCnlQPW
📄 DexWild: Dexterous Human Interactions for In-the-Wild Robot Policies 🔗 https://t.co/wd45liuWHk | [Project](https://t.co/KA1F3j0bov)
📄 H$^{\mathbf{3}}$DP: Triply-Hierarchical Diffusion Policy for Visuomotor Learning 🔗 https://t.co/YVnfhL4Pgj | [Project](https://t.co/jgphjgNUJ9.)
📄 Web2Grasp: Learning Functional Grasps from Web Images of Hand-Object Interactions 🔗 https://t.co/gdnSNV5MFw | [Project](https://t.co/SsmriV8ZFy.)
📄 Occupancy World Model for Robots 🔗 https://t.co/nzQfnboRoV
📄 UniVLA: Learning to Act Anywhere with Task-centric Latent Actions 🔗 https://t.co/nnyNiwvAej
📄 Let Humanoids Hike! Integrative Skill Development on Complex Trails 🔗 https://t.co/6iZIKabHte
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Grj28rRakAAEu7T.jpg)

📄 Real2Render2Real: Scaling Robot Data Without Dynamics Simulation or Robot Hardware 🔗 https://t.co/oZ7MNGYQgh | [Project](https://t.co/qwcC4OVUY3)
📄 What Matters for Batch Online Reinforcement Learning in Robotics? 🔗 https://t.co/9S8FbDvg1b
📄 NavDP: Learning Sim-to-Real Navigation Diffusion Policy with Privileged Information Guidance 🔗 https://t.co/LRQxCnlQPW
📄 DexWild: Dexterous Human Interactions for In-the-Wild Robot Policies 🔗 https://t.co/wd45liuWHk | [Project](https://t.co/KA1F3j0bov)
📄 H$^{\mathbf{3}}$DP: Triply-Hierarchical Diffusion Policy for Visuomotor Learning 🔗 https://t.co/YVnfhL4Pgj | [Project](https://t.co/jgphjgNUJ9.)
📄 Web2Grasp: Learning Functional Grasps from Web Images of Hand-Object Interactions 🔗 https://t.co/gdnSNV5MFw | [Project](https://t.co/SsmriV8ZFy.)
📄 Occupancy World Model for Robots 🔗 https://t.co/nzQfnboRoV
📄 UniVLA: Learning to Act Anywhere with Task-centric Latent Actions 🔗 https://t.co/nnyNiwvAej
📄 Let Humanoids Hike! Integrative Skill Development on Complex Trails 🔗 https://t.co/6iZIKabHte
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Grj28rPboAE2GyP.jpg)

📄 PlaceIt3D: Language-Guided Object Placement in Real 3D Scenes 🔗 https://t.co/wJ7fqkHDNe
📄 Steerable Scene Generation with Post Training and Inference-Time Search 🔗 https://t.co/i2b7pEMXt1 | [Project](https://t.co/K4w9XYsc2c)
📄 Robust Model-Based In-Hand Manipulation with Integrated Real-Time Motion-Contact Planning and Tracking 🔗 https://t.co/5nyHX2eJ1G
📄 Morphologically Symmetric Reinforcement Learning for Ambidextrous Bimanual Manipulation 🔗 https://t.co/S3RpOSkTjr
📄 GraspVLA: a Grasping Foundation Model Pre-trained on Billion-scale Synthetic Action Data 🔗 https://t.co/OCnWwghnhT
📄 RoboOS: A Hierarchical Embodied Framework for Cross-Embodiment and Multi-Agent Collaboration 🔗 https://t.co/qB4pyg1jBO | [Project](https://t.co/4YUflz0GFK)
📄 Demonstrating ViSafe: Vision-enabled Safety for High-speed Detect and Avoid 🔗 https://t.co/nvuuM3gCK3
📄 PyRoki: A Modular Toolkit for Robot Kinematic Optimization 🔗 https://t.co/i1kUIU9BYG
📄 Visual Imitation Enables Contextual Humanoid Control 🔗 https://t.co/fgdRzS7WcH
📄 AMO: Adaptive Motion Optimization for Hyper-Dexterous Humanoid Whole-Body Control 🔗 https://t.co/pstizXGBu9
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GrY2mZxbAAMx099.jpg)

📄 PlaceIt3D: Language-Guided Object Placement in Real 3D Scenes 🔗 https://t.co/wJ7fqkHDNe
📄 Steerable Scene Generation with Post Training and Inference-Time Search 🔗 https://t.co/i2b7pEMXt1 | [Project](https://t.co/K4w9XYsc2c)
📄 Robust Model-Based In-Hand Manipulation with Integrated Real-Time Motion-Contact Planning and Tracking 🔗 https://t.co/5nyHX2eJ1G
📄 Morphologically Symmetric Reinforcement Learning for Ambidextrous Bimanual Manipulation 🔗 https://t.co/S3RpOSkTjr
📄 GraspVLA: a Grasping Foundation Model Pre-trained on Billion-scale Synthetic Action Data 🔗 https://t.co/OCnWwghnhT
📄 RoboOS: A Hierarchical Embodied Framework for Cross-Embodiment and Multi-Agent Collaboration 🔗 https://t.co/qB4pyg1jBO | [Project](https://t.co/4YUflz0GFK)
📄 Demonstrating ViSafe: Vision-enabled Safety for High-speed Detect and Avoid 🔗 https://t.co/nvuuM3gCK3
📄 PyRoki: A Modular Toolkit for Robot Kinematic Optimization 🔗 https://t.co/i1kUIU9BYG
📄 Visual Imitation Enables Contextual Humanoid Control 🔗 https://t.co/fgdRzS7WcH
📄 AMO: Adaptive Motion Optimization for Hyper-Dexterous Humanoid Whole-Body Control 🔗 https://t.co/pstizXGBu9
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GrY2mZqbkAAIyo1.jpg)

📄 TWIST: Teleoperated Whole-Body Imitation System 🔗 https://t.co/WdyrbaGtsR | [Project](https://t.co/mP9dpJie9y)
📄 GENMO: A GENeralist Model for Human MOtion 🔗 https://t.co/k2HErgIWGy
📄 IK Seed Generator for Dual-Arm Human-like Physicality Robot with Mobile Base 🔗 https://t.co/Vyzl4e4iK2
📄 Towards Autonomous Micromobility through Scalable Urban Simulation 🔗 https://t.co/pxAaxGokld
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GrT4Tx6WoAA8_ks.jpg)

📄 TWIST: Teleoperated Whole-Body Imitation System 🔗 https://t.co/WdyrbaGtsR | [Project](https://t.co/mP9dpJie9y)
📄 GENMO: A GENeralist Model for Human MOtion 🔗 https://t.co/k2HErgIWGy
📄 IK Seed Generator for Dual-Arm Human-like Physicality Robot with Mobile Base 🔗 https://t.co/Vyzl4e4iK2
📄 Towards Autonomous Micromobility through Scalable Urban Simulation 🔗 https://t.co/pxAaxGokld
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GrT4Tx1WAAABU7e.jpg)

📄 TWIST: Teleoperated Whole-Body Imitation System 🔗 https://t.co/WdyrbaGtsR | [Project](https://t.co/mP9dpJie9y)
📄 GENMO: A GENeralist Model for Human MOtion 🔗 https://t.co/k2HErgIWGy
📄 IK Seed Generator for Dual-Arm Human-like Physicality Robot with Mobile Base 🔗 https://t.co/Vyzl4e4iK2
📄 Towards Autonomous Micromobility through Scalable Urban Simulation 🔗 https://t.co/pxAaxGokld
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GrT4TxvXgAEPKVG.jpg)

📄 PolyTouch: A Robust Multi-Modal Tactile Sensor for Contact-rich Manipulation Using Tactile-Diffusion Policies 🔗 https://t.co/gO5C8jTbvK | [Project](https://t.co/NjgcxvwSeD)
📄 Demonstrating Berkeley Humanoid Lite: An Open-source, Accessible, and Customizable 3D-printed Humanoid Robot 🔗 https://t.co/0tllfaUem0 | [Project](https://t.co/FdWTRrzizY.)
📄 Gripper Keypose and Object Pointflow as Interfaces for Bimanual Robotic Manipulation 🔗 https://t.co/dDMbIjdyGW | [Project](https://t.co/NLGems6JxN)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GrOOdadXkAAIE1G.jpg)

📄 PolyTouch: A Robust Multi-Modal Tactile Sensor for Contact-rich Manipulation Using Tactile-Diffusion Policies 🔗 https://t.co/gO5C8jTbvK | [Project](https://t.co/NjgcxvwSeD)
📄 Demonstrating Berkeley Humanoid Lite: An Open-source, Accessible, and Customizable 3D-printed Humanoid Robot 🔗 https://t.co/0tllfaUem0 | [Project](https://t.co/FdWTRrzizY.)
📄 Gripper Keypose and Object Pointflow as Interfaces for Bimanual Robotic Manipulation 🔗 https://t.co/dDMbIjdyGW | [Project](https://t.co/NLGems6JxN)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GrOOdaOXoAAOLTI.jpg)

📄 Offline Robotic World Model: Learning Robotic Policies without a Physics Simulator 🔗 https://t.co/XHy8tmWjkK
📄 MOSAIC: A Skill-Centric Algorithmic Framework for Long-Horizon Manipulation Planning 🔗 https://t.co/vftxeBOP1n | [Project](https://t.co/HL6If0WTRl)
📄 Physically Consistent Humanoid Loco-Manipulation using Latent Diffusion Models 🔗 https://t.co/lRTJ8WkT85
📄 Latent Diffusion Planning for Imitation Learning 🔗 https://t.co/21SWKYdq8B
📄 $π_{0.5}$: a Vision-Language-Action Model with Open-World Generalization 🔗 https://t.co/v8Ai4aWJA6
📄 BiDexHand: Design and Evaluation of an Open-Source 16-DoF Biomimetic Dexterous Hand 🔗 https://t.co/WkQMILV8ZY
📄 Automatic Generation of Aerobatic Flight in Complex Environments via Diffusion Models 🔗 https://t.co/jqwIbbH33Q
Find more daily insights here: https://t.co/nXJyIf98xf](https://pbs.twimg.com/media/GrN6QX4XcAA6UBq.jpg)

📄 Offline Robotic World Model: Learning Robotic Policies without a Physics Simulator 🔗 https://t.co/XHy8tmWjkK
📄 MOSAIC: A Skill-Centric Algorithmic Framework for Long-Horizon Manipulation Planning 🔗 https://t.co/vftxeBOP1n | [Project](https://t.co/HL6If0WTRl)
📄 Physically Consistent Humanoid Loco-Manipulation using Latent Diffusion Models 🔗 https://t.co/lRTJ8WkT85
📄 Latent Diffusion Planning for Imitation Learning 🔗 https://t.co/21SWKYdq8B
📄 $π_{0.5}$: a Vision-Language-Action Model with Open-World Generalization 🔗 https://t.co/v8Ai4aWJA6
📄 BiDexHand: Design and Evaluation of an Open-Source 16-DoF Biomimetic Dexterous Hand 🔗 https://t.co/WkQMILV8ZY
📄 Automatic Generation of Aerobatic Flight in Complex Environments via Diffusion Models 🔗 https://t.co/jqwIbbH33Q
Find more daily insights here: https://t.co/nXJyIf98xf](https://pbs.twimg.com/media/GrN6QX3XEAEW9nO.jpg)

📄 Offline Robotic World Model: Learning Robotic Policies without a Physics Simulator 🔗 https://t.co/XHy8tmWjkK
📄 MOSAIC: A Skill-Centric Algorithmic Framework for Long-Horizon Manipulation Planning 🔗 https://t.co/vftxeBOP1n | [Project](https://t.co/HL6If0WTRl)
📄 Physically Consistent Humanoid Loco-Manipulation using Latent Diffusion Models 🔗 https://t.co/lRTJ8WkT85
📄 Latent Diffusion Planning for Imitation Learning 🔗 https://t.co/21SWKYdq8B
📄 $π_{0.5}$: a Vision-Language-Action Model with Open-World Generalization 🔗 https://t.co/v8Ai4aWJA6
📄 BiDexHand: Design and Evaluation of an Open-Source 16-DoF Biomimetic Dexterous Hand 🔗 https://t.co/WkQMILV8ZY
📄 Automatic Generation of Aerobatic Flight in Complex Environments via Diffusion Models 🔗 https://t.co/jqwIbbH33Q
Find more daily insights here: https://t.co/nXJyIf98xf](https://pbs.twimg.com/media/GrN6QX3WwAAzoyn.jpg)
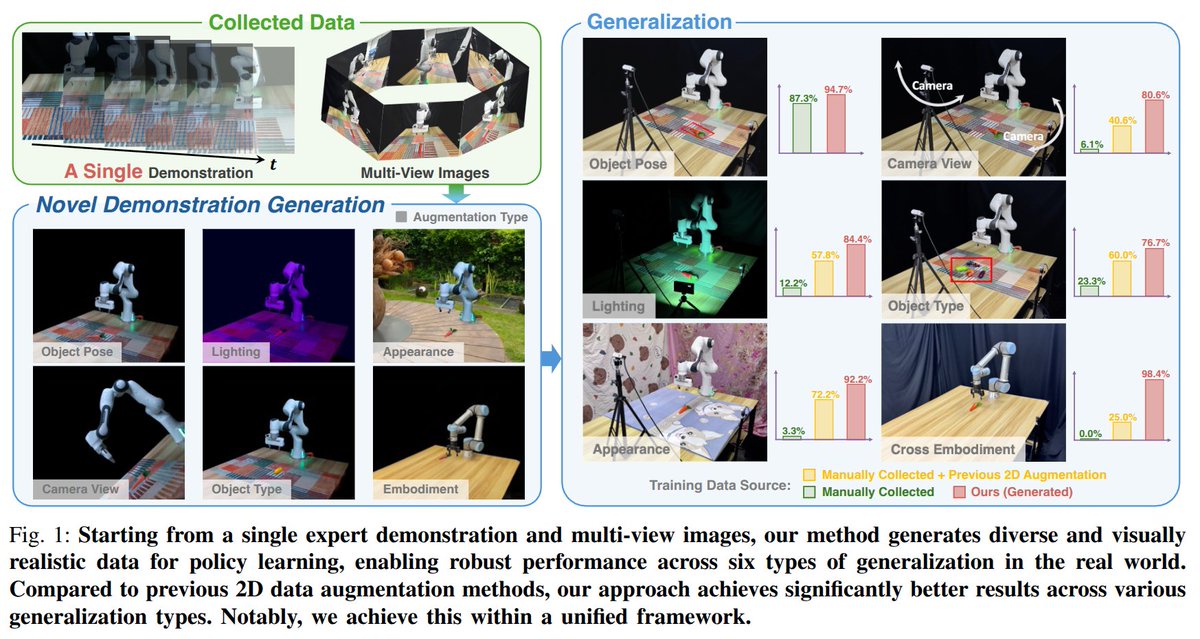


📄 RobustDexGrasp: Robust Dexterous Grasping of General Objects from Single-view Perception 🔗 https://t.co/NkuR9dqpIS | [Project](https://t.co/LnT0BJnDW1)
📄 Unified World Models: Coupling Video and Action Diffusion for Pretraining on Large Robotic Datasets 🔗 https://t.co/ds65zEStew | [Project](https://t.co/VARLpDuD7A.)
📄 Dexterous Non-Prehensile Manipulation for Ungraspable Object via Extrinsic Dexterity 🔗 https://t.co/Rzg6fmSWiu | [Project](https://t.co/xICOrjAbOX.)
📄 ZeroMimic: Distilling Robotic Manipulation Skills from Web Videos 🔗 https://t.co/y6zrvSXBdS
📄 AutoEval: Autonomous Evaluation of Generalist Robot Manipulation Policies in the Real World 🔗 https://t.co/1JLd2KsAa6
📄 Sim-and-Real Co-Training: A Simple Recipe for Vision-Based Robotic Manipulation 🔗 https://t.co/ZQVnQKC2c2 | [Project](https://t.co/k5hDiBpMyf)
📄 CoT-VLA: Visual Chain-of-Thought Reasoning for Vision-Language-Action Models 🔗 https://t.co/SReFAm1tMv | [Project](https://t.co/sjNBGK1IzS)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GoKniBsbIAA5Jj_.jpg)

📄 RobustDexGrasp: Robust Dexterous Grasping of General Objects from Single-view Perception 🔗 https://t.co/NkuR9dqpIS | [Project](https://t.co/LnT0BJnDW1)
📄 Unified World Models: Coupling Video and Action Diffusion for Pretraining on Large Robotic Datasets 🔗 https://t.co/ds65zEStew | [Project](https://t.co/VARLpDuD7A.)
📄 Dexterous Non-Prehensile Manipulation for Ungraspable Object via Extrinsic Dexterity 🔗 https://t.co/Rzg6fmSWiu | [Project](https://t.co/xICOrjAbOX.)
📄 ZeroMimic: Distilling Robotic Manipulation Skills from Web Videos 🔗 https://t.co/y6zrvSXBdS
📄 AutoEval: Autonomous Evaluation of Generalist Robot Manipulation Policies in the Real World 🔗 https://t.co/1JLd2KsAa6
📄 Sim-and-Real Co-Training: A Simple Recipe for Vision-Based Robotic Manipulation 🔗 https://t.co/ZQVnQKC2c2 | [Project](https://t.co/k5hDiBpMyf)
📄 CoT-VLA: Visual Chain-of-Thought Reasoning for Vision-Language-Action Models 🔗 https://t.co/SReFAm1tMv | [Project](https://t.co/sjNBGK1IzS)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GoKniBCbQAARUnd.jpg)

📄 RobustDexGrasp: Robust Dexterous Grasping of General Objects from Single-view Perception 🔗 https://t.co/NkuR9dqpIS | [Project](https://t.co/LnT0BJnDW1)
📄 Unified World Models: Coupling Video and Action Diffusion for Pretraining on Large Robotic Datasets 🔗 https://t.co/ds65zEStew | [Project](https://t.co/VARLpDuD7A.)
📄 Dexterous Non-Prehensile Manipulation for Ungraspable Object via Extrinsic Dexterity 🔗 https://t.co/Rzg6fmSWiu | [Project](https://t.co/xICOrjAbOX.)
📄 ZeroMimic: Distilling Robotic Manipulation Skills from Web Videos 🔗 https://t.co/y6zrvSXBdS
📄 AutoEval: Autonomous Evaluation of Generalist Robot Manipulation Policies in the Real World 🔗 https://t.co/1JLd2KsAa6
📄 Sim-and-Real Co-Training: A Simple Recipe for Vision-Based Robotic Manipulation 🔗 https://t.co/ZQVnQKC2c2 | [Project](https://t.co/k5hDiBpMyf)
📄 CoT-VLA: Visual Chain-of-Thought Reasoning for Vision-Language-Action Models 🔗 https://t.co/SReFAm1tMv | [Project](https://t.co/sjNBGK1IzS)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GoKniBBbYAAMd7f.jpg)


📄 G-DexGrasp: Generalizable Dexterous Grasping Synthesis Via Part-Aware Prior Retrieval and Prior-Assisted Generation 🔗 https://t.co/pNYGStcG2a | [Project](https://t.co/OfspEbuG5P)
📄 SG-Tailor: Inter-Object Commonsense Relationship Reasoning for Scene Graph Manipulation 🔗 https://t.co/SFOnYlJaf2
📄 Dita: Scaling Diffusion Transformer for Generalist Vision-Language-Action Policy 🔗 https://t.co/wnkiZJQWpI | [Project](https://t.co/TaAsuogaqm.)
📄 Visuo-Tactile Object Pose Estimation for a Multi-Finger Robot Hand with Low-Resolution In-Hand Tactile Sensing 🔗 https://t.co/GNSKSErhEB
📄 Any6D: Model-free 6D Pose Estimation of Novel Objects 🔗 https://t.co/MaJFBNE6yK | [Project](https://t.co/lkoHnBq9yh)
📄 RoboEngine: Plug-and-Play Robot Data Augmentation with Semantic Robot Segmentation and Background Generation 🔗 https://t.co/Oz0O7pIGz8
📄 Unraveling the Effects of Synthetic Data on End-to-End Autonomous Driving 🔗 https://t.co/i10oqeA3vT
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GnBzlJzbkAAUfjG.jpg)

📄 G-DexGrasp: Generalizable Dexterous Grasping Synthesis Via Part-Aware Prior Retrieval and Prior-Assisted Generation 🔗 https://t.co/pNYGStcG2a | [Project](https://t.co/OfspEbuG5P)
📄 SG-Tailor: Inter-Object Commonsense Relationship Reasoning for Scene Graph Manipulation 🔗 https://t.co/SFOnYlJaf2
📄 Dita: Scaling Diffusion Transformer for Generalist Vision-Language-Action Policy 🔗 https://t.co/wnkiZJQWpI | [Project](https://t.co/TaAsuogaqm.)
📄 Visuo-Tactile Object Pose Estimation for a Multi-Finger Robot Hand with Low-Resolution In-Hand Tactile Sensing 🔗 https://t.co/GNSKSErhEB
📄 Any6D: Model-free 6D Pose Estimation of Novel Objects 🔗 https://t.co/MaJFBNE6yK | [Project](https://t.co/lkoHnBq9yh)
📄 RoboEngine: Plug-and-Play Robot Data Augmentation with Semantic Robot Segmentation and Background Generation 🔗 https://t.co/Oz0O7pIGz8
📄 Unraveling the Effects of Synthetic Data on End-to-End Autonomous Driving 🔗 https://t.co/i10oqeA3vT
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GnBzlJzaoAACFHb.jpg)

📄 G-DexGrasp: Generalizable Dexterous Grasping Synthesis Via Part-Aware Prior Retrieval and Prior-Assisted Generation 🔗 https://t.co/pNYGStcG2a | [Project](https://t.co/OfspEbuG5P)
📄 SG-Tailor: Inter-Object Commonsense Relationship Reasoning for Scene Graph Manipulation 🔗 https://t.co/SFOnYlJaf2
📄 Dita: Scaling Diffusion Transformer for Generalist Vision-Language-Action Policy 🔗 https://t.co/wnkiZJQWpI | [Project](https://t.co/TaAsuogaqm.)
📄 Visuo-Tactile Object Pose Estimation for a Multi-Finger Robot Hand with Low-Resolution In-Hand Tactile Sensing 🔗 https://t.co/GNSKSErhEB
📄 Any6D: Model-free 6D Pose Estimation of Novel Objects 🔗 https://t.co/MaJFBNE6yK | [Project](https://t.co/lkoHnBq9yh)
📄 RoboEngine: Plug-and-Play Robot Data Augmentation with Semantic Robot Segmentation and Background Generation 🔗 https://t.co/Oz0O7pIGz8
📄 Unraveling the Effects of Synthetic Data on End-to-End Autonomous Driving 🔗 https://t.co/i10oqeA3vT
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GnBzlJxbEAAzZpt.jpg)





📄 Touch in the Wild: Learning Fine-Grained Manipulation with a Portable Visuo-Tactile Gripper 🔗 https://t.co/vFubzvVo7s | [Project](https://t.co/ETelxAcbIy)
📄 GR-3 Technical Report 🔗 https://t.co/oayyqVQX0Q
📄 AnyPos: Automated Task-Agnostic Actions for Bimanual Manipulation 🔗 https://t.co/LOGstCNMVG | [Project](https://t.co/aWE5wQZoNj)
📄 Generalist Bimanual Manipulation via Foundation Video Diffusion Models 🔗 https://t.co/4uYHIj2mjd
📄 GraspGen: A Diffusion-based Framework for 6-DOF Grasping with On-Generator Training 🔗 https://t.co/zEoiPZpe6f
📄 Latent Policy Steering with Embodiment-Agnostic Pretrained World Models 🔗 https://t.co/iNFlbor5Lr
📄 EgoVLA: Learning Vision-Language-Action Models from Egocentric Human Videos 🔗 https://t.co/gLTxiraTs7 | [Project](https://t.co/1Ey70yeiEN)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gwbx4sKbEAIiahP.jpg)

📄 SimLauncher: Launching Sample-Efficient Real-world Robotic Reinforcement Learning via Simulation Pre-training 🔗 https://t.co/WLCguXbMTG
📄 DexVLG: Dexterous Vision-Language-Grasp Model at Scale 🔗 https://t.co/SuX7ROEyhZ
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gv5pDfxakAAvdfQ.jpg)

📄 FORTE: Tactile Force and Slip Sensing on Compliant Fingers for Delicate Manipulation 🔗 https://t.co/yAezwm7lG0 | [Project](https://t.co/NvGucgPNdT)
📄 RoboTwin 2.0: A Scalable Data Generator and Benchmark with Strong Domain Randomization for Robust Bimanual Robotic Manipulation 🔗 https://t.co/hK7a71GpCc
📄 RoboArena: Distributed Real-World Evaluation of Generalist Robot Policies 🔗 https://t.co/R80fSufg08
📄 Learning Accurate Whole-body Throwing with High-frequency Residual Policy and Pullback Tube Acceleration 🔗 https://t.co/jyFBdmMIB3
📄 Dex1B: Learning with 1B Demonstrations for Dexterous Manipulation 🔗 https://t.co/nwL3rnjpjf | [Project](https://t.co/9D0A998yE9)
📄 Vision in Action: Learning Active Perception from Human Demonstrations 🔗 https://t.co/02Emx67fDA
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gu74ZAXaIAAIurL.jpg)

📄 FORTE: Tactile Force and Slip Sensing on Compliant Fingers for Delicate Manipulation 🔗 https://t.co/yAezwm7lG0 | [Project](https://t.co/NvGucgPNdT)
📄 RoboTwin 2.0: A Scalable Data Generator and Benchmark with Strong Domain Randomization for Robust Bimanual Robotic Manipulation 🔗 https://t.co/hK7a71GpCc
📄 RoboArena: Distributed Real-World Evaluation of Generalist Robot Policies 🔗 https://t.co/R80fSufg08
📄 Learning Accurate Whole-body Throwing with High-frequency Residual Policy and Pullback Tube Acceleration 🔗 https://t.co/jyFBdmMIB3
📄 Dex1B: Learning with 1B Demonstrations for Dexterous Manipulation 🔗 https://t.co/nwL3rnjpjf | [Project](https://t.co/9D0A998yE9)
📄 Vision in Action: Learning Active Perception from Human Demonstrations 🔗 https://t.co/02Emx67fDA
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GuXEYiCbEAI8c1V.jpg)

📄 Tactile Beyond Pixels: Multisensory Touch Representations for Robot Manipulation 🔗 https://t.co/HDjlys2JYC
📄 GMT: General Motion Tracking for Humanoid Whole-Body Control 🔗 https://t.co/X739r3qJkx | [Project](https://t.co/HTedIwkSFx.)
📄 RL from Physical Feedback: Aligning Large Motion Models with Humanoid Control 🔗 https://t.co/m1JVHBqRHE
📄 From Experts to a Generalist: Toward General Whole-Body Control for Humanoid Robots 🔗 https://t.co/ujJDvXF1l8
📄 KungfuBot: Physics-Based Humanoid Whole-Body Control for Learning Highly-Dynamic Skills 🔗 https://t.co/gzgWHjffCL | [Project](https://t.co/jfCNmr0f2Q.)
📄 LeVERB: Humanoid Whole-Body Control with Latent Vision-Language Instruction 🔗 https://t.co/7q1OjpD2mo
📄 Prompting with the Future: Open-World Model Predictive Control with Interactive Digital Twins 🔗 https://t.co/Y5SOcnP1RR
📄 Touch begins where vision ends: Generalizable policies for contact-rich manipulation 🔗 https://t.co/VOYZgqjzDS | [Project](https://t.co/56gdGY7NY3.)
📄 Construction of a Multiple-DOF Under-actuated Gripper with Force-Sensing via Deep Learning 🔗 https://t.co/Qeb6R3H7cs
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Gttm7t9WEAAsKWQ.jpg)

📄 GENMANIP: LLM-driven Simulation for Generalizable Instruction-Following Manipulation 🔗 https://t.co/84WjQbNWmQ | [Project](https://t.co/nNSY84ZKGd.)
📄 Eye, Robot: Learning to Look to Act with a BC-RL Perception-Action Loop 🔗 https://t.co/ybNgIh2dGA | [Project](https://t.co/z2FFgEsd93)
📄 UAD: Unsupervised Affordance Distillation for Generalization in Robotic Manipulation 🔗 https://t.co/jS4ryGdJlR | [Project](https://t.co/h2bbTghqh5)
📄 SkillBlender: Towards Versatile Humanoid Whole-Body Loco-Manipulation via Skill Blending 🔗 https://t.co/Nmo8sMpvKg | [Project](https://t.co/lT40txN3R3.)
📄 CLONE: Closed-Loop Whole-Body Humanoid Teleoperation for Long-Horizon Tasks 🔗 https://t.co/rdh7jtIitL
📄 Real-Time Execution of Action Chunking Flow Policies 🔗 https://t.co/0yhGhwVDAX | [Project](https://t.co/p04ZvnW83e)
📄 Versatile Loco-Manipulation through Flexible Interlimb Coordination 🔗 https://t.co/9c0Gwpw4ps | [Project](https://t.co/0kuHPsoHuF.)
📄 Improving Long-Range Navigation with Spatially-Enhanced Recurrent Memory via End-to-End Reinforcement Learning 🔗 https://t.co/yK9GVYphqb
📄 3DFlowAction: Learning Cross-Embodiment Manipulation from 3D Flow World Model 🔗 https://t.co/LEjaEDieH8
📄 BiAssemble: Learning Collaborative Affordance for Bimanual Geometric Assembly 🔗 https://t.co/0yia0hiw2D | [Project](https://t.co/lzBloNA41P.)
📄 DemoSpeedup: Accelerating Visuomotor Policies via Entropy-Guided Demonstration Acceleration 🔗 https://t.co/Nu8ZSdcOs7 | [Project](https://t.co/VEIxCixOVk)
📄 Fabrica: Dual-Arm Assembly of General Multi-Part Objects via Integrated Planning and Learning 🔗 https://t.co/33tYFBretr | [Project](https://t.co/tJuosLUJyb)
📄 OWMM-Agent: Open World Mobile Manipulation With Multi-modal Agentic Data Synthesis 🔗 https://t.co/htgPsDz7fF | [Project](https://t.co/udtHe3a4JH)
📄 Object-centric 3D Motion Field for Robot Learning from Human Videos 🔗 https://t.co/KYuNboOomD
📄 Rodrigues Network for Learning Robot Actions 🔗 https://t.co/zBp5vEVeAp
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GtZxX6wbAAAS6sP.jpg)

📄 Hold My Beer: Learning Gentle Humanoid Locomotion and End-Effector Stabilization Control 🔗 https://t.co/YyivLo1LOw
📄 SR3D: Unleashing Single-view 3D Reconstruction for Transparent and Specular Object Grasping 🔗 https://t.co/iThXIZpvzh
📄 DexMachina: Functional Retargeting for Bimanual Dexterous Manipulation 🔗 https://t.co/k45vhrPlDn | [Project](https://t.co/Tq52zAum9B)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GtYDLWhbwAA1fGR.jpg)

📄 LabUtopia: High-Fidelity Simulation and Hierarchical Benchmark for Scientific Embodied Agents 🔗 https://t.co/TMD5N1IrH7
📄 FastTD3: Simple, Fast, and Capable Reinforcement Learning for Humanoid Control 🔗 https://t.co/TMBJ0wMayZ
📄 Learning Generalizable Robot Policy with Human Demonstration Video as a Prompt 🔗 https://t.co/Otb1bWLZ89
📄 Learning Unified Force and Position Control for Legged Loco-Manipulation 🔗 https://t.co/bCiyruZVMR
📄 Hume: Introducing System-2 Thinking in Visual-Language-Action Model 🔗 https://t.co/tdH6nSVTQm
📄 CLAMP: Crowdsourcing a LArge-scale in-the-wild haptic dataset with an open-source device for Multimodal robot Perception 🔗 https://t.co/KNT2SkGaKo | [Project](https://t.co/zYgleu2ShT)
📄 MaskedManipulator: Versatile Whole-Body Control for Loco-Manipulation 🔗 https://t.co/HS1H3J0kOI
📄 Genie Centurion: Accelerating Scalable Real-World Robot Training with Human Rewind-and-Refine Guidance 🔗 https://t.co/gYSxqPtsYT
📄 ManiFeel: Benchmarking and Understanding Visuotactile Manipulation Policy Learning 🔗 https://t.co/cEeYXHRQZW | [Project](https://t.co/dEanxRhHYM)
📄 EgoZero: Robot Learning from Smart Glasses 🔗 https://t.co/9wQUHnaUJh | [Project](https://t.co/OYA6IvH26s.)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GtImk2DaoAA9sbB.jpg)

📄 TartanGround: A Large-Scale Dataset for Ground Robot Perception and Navigation 🔗 https://t.co/rJXxjalQsv | [Project](https://t.co/OzVPZkuN07)
📄 Infinigen-Sim: Procedural Generation of Articulated Simulation Assets 🔗 https://t.co/pSBJlQnept
📄 DexGarmentLab: Dexterous Garment Manipulation Environment with Generalizable Policy 🔗 https://t.co/x00x7Ulpfl | [Project](https://t.co/toGl98zRAY.)
Find more daily insights here: https://t.co/nXJyIf98xf](https://pbs.twimg.com/media/GrzqR2gXUAA7hWA.jpg)

📄 Real2Render2Real: Scaling Robot Data Without Dynamics Simulation or Robot Hardware 🔗 https://t.co/oZ7MNGYQgh | [Project](https://t.co/qwcC4OVUY3)
📄 What Matters for Batch Online Reinforcement Learning in Robotics? 🔗 https://t.co/9S8FbDvg1b
📄 NavDP: Learning Sim-to-Real Navigation Diffusion Policy with Privileged Information Guidance 🔗 https://t.co/LRQxCnlQPW
📄 DexWild: Dexterous Human Interactions for In-the-Wild Robot Policies 🔗 https://t.co/wd45liuWHk | [Project](https://t.co/KA1F3j0bov)
📄 H$^{\mathbf{3}}$DP: Triply-Hierarchical Diffusion Policy for Visuomotor Learning 🔗 https://t.co/YVnfhL4Pgj | [Project](https://t.co/jgphjgNUJ9.)
📄 Web2Grasp: Learning Functional Grasps from Web Images of Hand-Object Interactions 🔗 https://t.co/gdnSNV5MFw | [Project](https://t.co/SsmriV8ZFy.)
📄 Occupancy World Model for Robots 🔗 https://t.co/nzQfnboRoV
📄 UniVLA: Learning to Act Anywhere with Task-centric Latent Actions 🔗 https://t.co/nnyNiwvAej
📄 Let Humanoids Hike! Integrative Skill Development on Complex Trails 🔗 https://t.co/6iZIKabHte
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/Grj28rbboAIwXJI.jpg)

📄 PlaceIt3D: Language-Guided Object Placement in Real 3D Scenes 🔗 https://t.co/wJ7fqkHDNe
📄 Steerable Scene Generation with Post Training and Inference-Time Search 🔗 https://t.co/i2b7pEMXt1 | [Project](https://t.co/K4w9XYsc2c)
📄 Robust Model-Based In-Hand Manipulation with Integrated Real-Time Motion-Contact Planning and Tracking 🔗 https://t.co/5nyHX2eJ1G
📄 Morphologically Symmetric Reinforcement Learning for Ambidextrous Bimanual Manipulation 🔗 https://t.co/S3RpOSkTjr
📄 GraspVLA: a Grasping Foundation Model Pre-trained on Billion-scale Synthetic Action Data 🔗 https://t.co/OCnWwghnhT
📄 RoboOS: A Hierarchical Embodied Framework for Cross-Embodiment and Multi-Agent Collaboration 🔗 https://t.co/qB4pyg1jBO | [Project](https://t.co/4YUflz0GFK)
📄 Demonstrating ViSafe: Vision-enabled Safety for High-speed Detect and Avoid 🔗 https://t.co/nvuuM3gCK3
📄 PyRoki: A Modular Toolkit for Robot Kinematic Optimization 🔗 https://t.co/i1kUIU9BYG
📄 Visual Imitation Enables Contextual Humanoid Control 🔗 https://t.co/fgdRzS7WcH
📄 AMO: Adaptive Motion Optimization for Hyper-Dexterous Humanoid Whole-Body Control 🔗 https://t.co/pstizXGBu9
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GrY2mZ2bAAcBxGm.jpg)

📄 TWIST: Teleoperated Whole-Body Imitation System 🔗 https://t.co/WdyrbaGtsR | [Project](https://t.co/mP9dpJie9y)
📄 GENMO: A GENeralist Model for Human MOtion 🔗 https://t.co/k2HErgIWGy
📄 IK Seed Generator for Dual-Arm Human-like Physicality Robot with Mobile Base 🔗 https://t.co/Vyzl4e4iK2
📄 Towards Autonomous Micromobility through Scalable Urban Simulation 🔗 https://t.co/pxAaxGokld
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GrT4TyWWcAA_rGl.jpg)

📄 PolyTouch: A Robust Multi-Modal Tactile Sensor for Contact-rich Manipulation Using Tactile-Diffusion Policies 🔗 https://t.co/gO5C8jTbvK | [Project](https://t.co/NjgcxvwSeD)
📄 Demonstrating Berkeley Humanoid Lite: An Open-source, Accessible, and Customizable 3D-printed Humanoid Robot 🔗 https://t.co/0tllfaUem0 | [Project](https://t.co/FdWTRrzizY.)
📄 Gripper Keypose and Object Pointflow as Interfaces for Bimanual Robotic Manipulation 🔗 https://t.co/dDMbIjdyGW | [Project](https://t.co/NLGems6JxN)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GrOOdajXAAECwcD.jpg)

📄 Offline Robotic World Model: Learning Robotic Policies without a Physics Simulator 🔗 https://t.co/XHy8tmWjkK
📄 MOSAIC: A Skill-Centric Algorithmic Framework for Long-Horizon Manipulation Planning 🔗 https://t.co/vftxeBOP1n | [Project](https://t.co/HL6If0WTRl)
📄 Physically Consistent Humanoid Loco-Manipulation using Latent Diffusion Models 🔗 https://t.co/lRTJ8WkT85
📄 Latent Diffusion Planning for Imitation Learning 🔗 https://t.co/21SWKYdq8B
📄 $π_{0.5}$: a Vision-Language-Action Model with Open-World Generalization 🔗 https://t.co/v8Ai4aWJA6
📄 BiDexHand: Design and Evaluation of an Open-Source 16-DoF Biomimetic Dexterous Hand 🔗 https://t.co/WkQMILV8ZY
📄 Automatic Generation of Aerobatic Flight in Complex Environments via Diffusion Models 🔗 https://t.co/jqwIbbH33Q
Find more daily insights here: https://t.co/nXJyIf98xf](https://pbs.twimg.com/media/GrN6QYAWUAAhEsj.jpg)


📄 RobustDexGrasp: Robust Dexterous Grasping of General Objects from Single-view Perception 🔗 https://t.co/NkuR9dqpIS | [Project](https://t.co/LnT0BJnDW1)
📄 Unified World Models: Coupling Video and Action Diffusion for Pretraining on Large Robotic Datasets 🔗 https://t.co/ds65zEStew | [Project](https://t.co/VARLpDuD7A.)
📄 Dexterous Non-Prehensile Manipulation for Ungraspable Object via Extrinsic Dexterity 🔗 https://t.co/Rzg6fmSWiu | [Project](https://t.co/xICOrjAbOX.)
📄 ZeroMimic: Distilling Robotic Manipulation Skills from Web Videos 🔗 https://t.co/y6zrvSXBdS
📄 AutoEval: Autonomous Evaluation of Generalist Robot Manipulation Policies in the Real World 🔗 https://t.co/1JLd2KsAa6
📄 Sim-and-Real Co-Training: A Simple Recipe for Vision-Based Robotic Manipulation 🔗 https://t.co/ZQVnQKC2c2 | [Project](https://t.co/k5hDiBpMyf)
📄 CoT-VLA: Visual Chain-of-Thought Reasoning for Vision-Language-Action Models 🔗 https://t.co/SReFAm1tMv | [Project](https://t.co/sjNBGK1IzS)
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GoKniCIaAAAlMxy.jpg)

📄 G-DexGrasp: Generalizable Dexterous Grasping Synthesis Via Part-Aware Prior Retrieval and Prior-Assisted Generation 🔗 https://t.co/pNYGStcG2a | [Project](https://t.co/OfspEbuG5P)
📄 SG-Tailor: Inter-Object Commonsense Relationship Reasoning for Scene Graph Manipulation 🔗 https://t.co/SFOnYlJaf2
📄 Dita: Scaling Diffusion Transformer for Generalist Vision-Language-Action Policy 🔗 https://t.co/wnkiZJQWpI | [Project](https://t.co/TaAsuogaqm.)
📄 Visuo-Tactile Object Pose Estimation for a Multi-Finger Robot Hand with Low-Resolution In-Hand Tactile Sensing 🔗 https://t.co/GNSKSErhEB
📄 Any6D: Model-free 6D Pose Estimation of Novel Objects 🔗 https://t.co/MaJFBNE6yK | [Project](https://t.co/lkoHnBq9yh)
📄 RoboEngine: Plug-and-Play Robot Data Augmentation with Semantic Robot Segmentation and Background Generation 🔗 https://t.co/Oz0O7pIGz8
📄 Unraveling the Effects of Synthetic Data on End-to-End Autonomous Driving 🔗 https://t.co/i10oqeA3vT
Find more daily insights here: https://t.co/nXJyIf9GmN](https://pbs.twimg.com/media/GnBzlJ2aAAAgTfH.jpg)


