We're excited to release the first open-source VIO to beat Aria on LaMAria!
Industry level SLAM for everybody will power tons of applications, can't wait to see what people build :)
So how did we beat Aria's SLAM? (1/4)
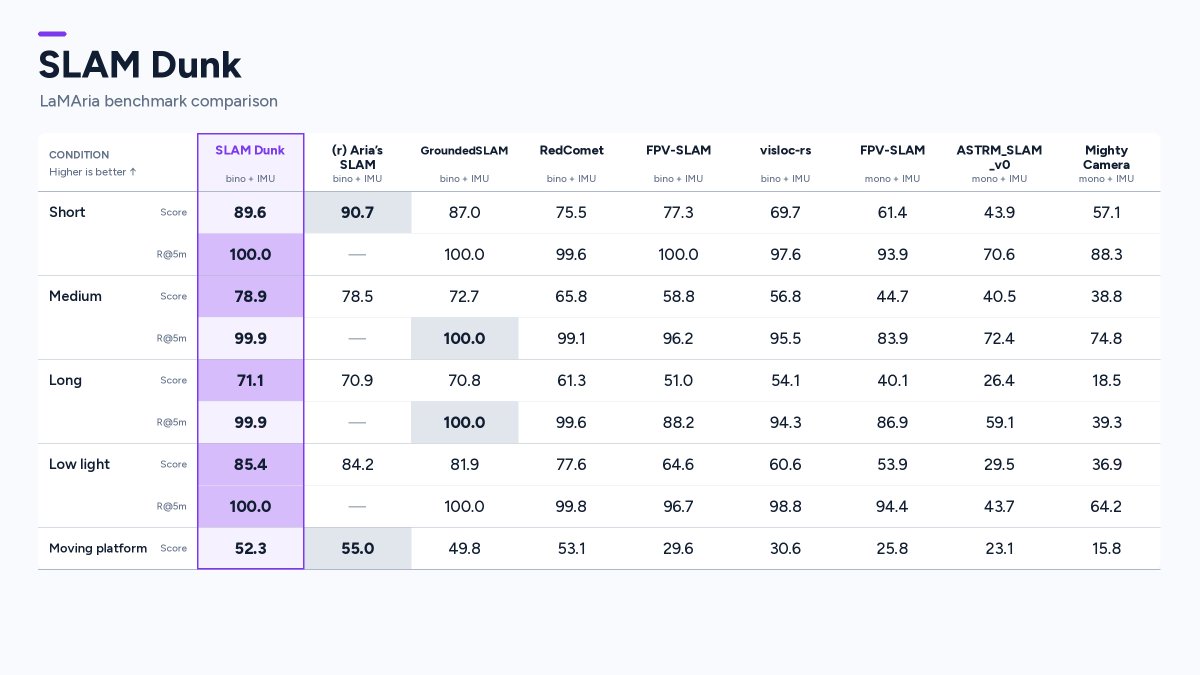
when LaMAria was introduced a year ago, Meta's closed-source Aria SLAM was far ahead of academic systems.
one year later, we've surpassed it in 3/5 categories: medium, long, and low light.
here's what closing that gap looks like:
a camera gives you 2d pictures, not 3d measurements. how do you figure out where you are from that?
turns out SLAM (simultaneous localization and mapping) is one of the hardest problems in robotics. applications range from AR glasses to drones and autonomous cars!
1/5
@ChrisStathis5@gabriberton Yeah in my experience optimizing SLAM systems optimizing hardware is usually higher leverage than optimizing software, and to get really great results codesign is critical
We're excited to release the first open-source VIO to beat Aria on LaMAria!
Industry level SLAM for everybody will power tons of applications, can't wait to see what people build :)
So how did we beat Aria's SLAM? (1/4)
when LaMAria was introduced a year ago, Meta's closed-source Aria SLAM was far ahead of academic systems.
one year later, we've surpassed it in 3/5 categories: medium, long, and low light.
here's what closing that gap looks like:
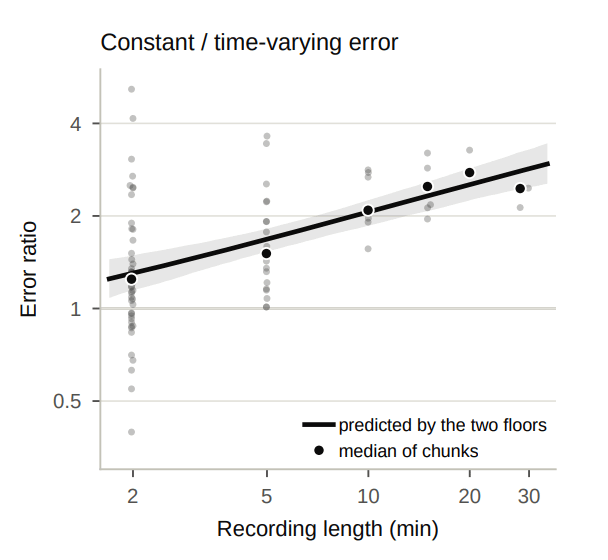
Modeling camera calibration drift is increasingly important as trajectories grow longer. We find that the ratio between the error of the constant calibration system and the time-varying camera calibration system strongly increases with trajectory length. (3/4)
how well can fable 5.2 and gpt-6 astra act as air traffic controllers?
in light of recent atc closures, i wondered how efficiently the most chaotic, high-consequence tasks could be carried out by frontier models.
results below :)
fable 5.2 is surprisingly good at spatial reasoning! here's it scanning and bagging groceries across multiple pick and place steps.
seems like the labs are beginning to scale physical post-training. excited to see where this goes.
i got gpt-2 running purely in css!
all 124m parameters inferencing at 15 sec/tok, with zero lines of js.
i also used a custom font as a BPE tokenizer, and variable fonts for matmuls :)
when LaMAria was introduced a year ago, Meta's closed-source Aria SLAM was far ahead of academic systems.
one year later, we've surpassed it in 3/5 categories: medium, long, and low light.
here's what closing that gap looks like:
@the_shweenz yeah I'm a pretty big fan of the binocular design, in my experience the greater fov from outward facing cameras is more important for tracking robustness in the wild than stereo overlap. especially for egocentric data.
when LaMAria was introduced a year ago, Meta's closed-source Aria SLAM was far ahead of academic systems.
one year later, we've surpassed it in 3/5 categories: medium, long, and low light.
here's what closing that gap looks like: