Even before I started my journey in robotics, I always believed that touch was the most important sense for human dexterous manipulation. But I was never sure whether this intuition was correct.
With LingBot-Touch, we explored self-supervised learning on tactile data and saw encouraging improvements in dexterous manipulation!
Excited to share what we’ve been working on: LingBot-Touch.
Helping robots feel—not just see—with tactile representations that transfer across sensors, hands and tasks.
Models, code and technical report are open source. Would love to hear your thoughts!
What changes when robots can feel—not just see? 🤖✋
Meet LingBot-Touch, our open-source tactile foundation model towards dexterous manipulation, pretrained on nearly 5,000 hours of real tactile data.
Through unified heterogeneous tactile modeling, LingBot-Touch supports transfer across sensors, dexterous hands, tasks, and action models.
Watch it in action. 👇 #LingBot #EmbodiedAI #Robotics
My swag arrived this morning! 🌟 Honored to be listed as a GitHub Star for the second year 🐙🐱
Love the program’s mission: inspire, educate, share, shape communities — it values contributions beyond source code.
Open source has run through my journey from SegmentFault, @ant_oss , to @robbyant_brain . From software to embodied AI open source, building developer ecosystems all the way.
Thank you @github . Onwards 💪⛽️#GitHubStars
The FIRST Robbyant Embodied AI Challenge is live. 🤖🌍
We're inviting builders worldwide to push embodied intelligence forward — real hardware, real environments, real impact. 🦾
Be part of history in the making. Prizes. Recognition. The frontier. 🏆 Learn more & register → https://t.co/6IfjmLYyWG
#EmbodiedAI #Robotics
🌍 What if an AI-generated world didn’t end after a few seconds—but kept running for hours, responded to every move, let you attack, cast spells, shoot, or summon storms, and continued evolving through AI agents?
That’s LingBot-World 2.0: our open-source real-time interactive world model, scaling to 720p/60fps in our full setup.
Today, we’re open-sourcing 3 more models:
🔹 LingBot-World 2.0 Small (1.3B)
🔹 LingBot-World 2.0 Bidirectional
🔹 LingBot-World 2.0 Causal Pretrain
And now, with our 1.3B Small Model, that world can run in real time on a single consumer GPU. 🧵
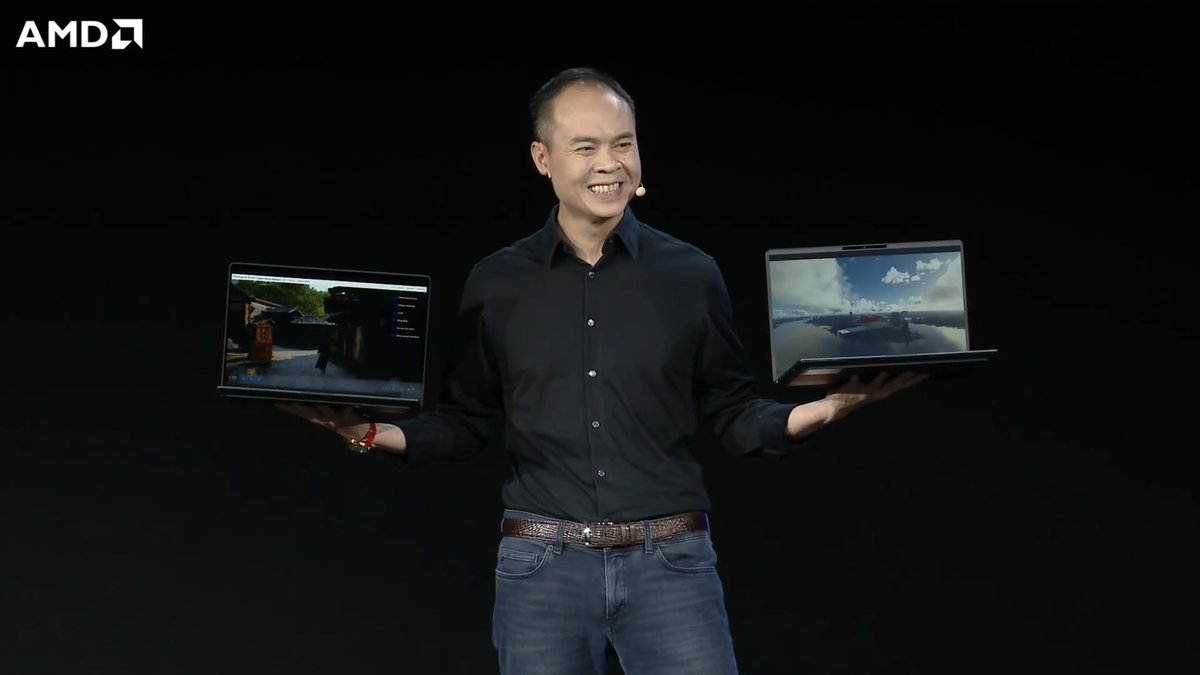
LingBot-World 2.0 made its stunning debut at the IFA Berlin opening keynote!
@jackhuynh from @AMD demonstrated LingBot-World 2.0 live and praised it as “the future of Personal AI.”
With just a single prompt, the LingBot-World 2.0 generated a vivid, interactive 3D world—from traditional Chinese towns to European countryside. 🌍 You can freely roam, observe, move, and interact with the dynamically expanding environment in a long-term, stable, real-time simulation.
#LingBotWorld2 #IFA2026 #PersonalAI #EmbodiedAI #WorldModel
Can robots learn new tasks directly from human‑operation videos?✅
Meet Zero‑WAM: video‑based in‑context learning for robotics.
No heavy retraining, no verbose text instructions.
Given human demo videos, it infers objects, interactions & task flows to generate robot‑executable motions.
- HumanGen dataset: 8.6K tasks / 74.2K human‑robot samples
- IFP training for long‑range video task understanding
- 46.95% avg success rate on 7 unseen RoboTwin 2.0 tasks
Paper out now, code releasing soon.
📄 https://t.co/qukO689tvp
🌐 https://t.co/OwdxOhITe9
Huge shout‑out to the @sgl_project community! 🙌 LingBot‑Video gets native support in SGLang v0.5.18.
Run our 30B‑A3B MoE text‑to‑video model with optimized SGLang‑Diffusion serving.
Cookbook👉 https://t.co/oz2ssi9Chs
Big thanks to everyone I got to meet at WRC! 👋 Coming this September: Inclusion· Conference on the Bund and ECCV 2026. Looking forward to seeing you in Shanghai and Malmö!
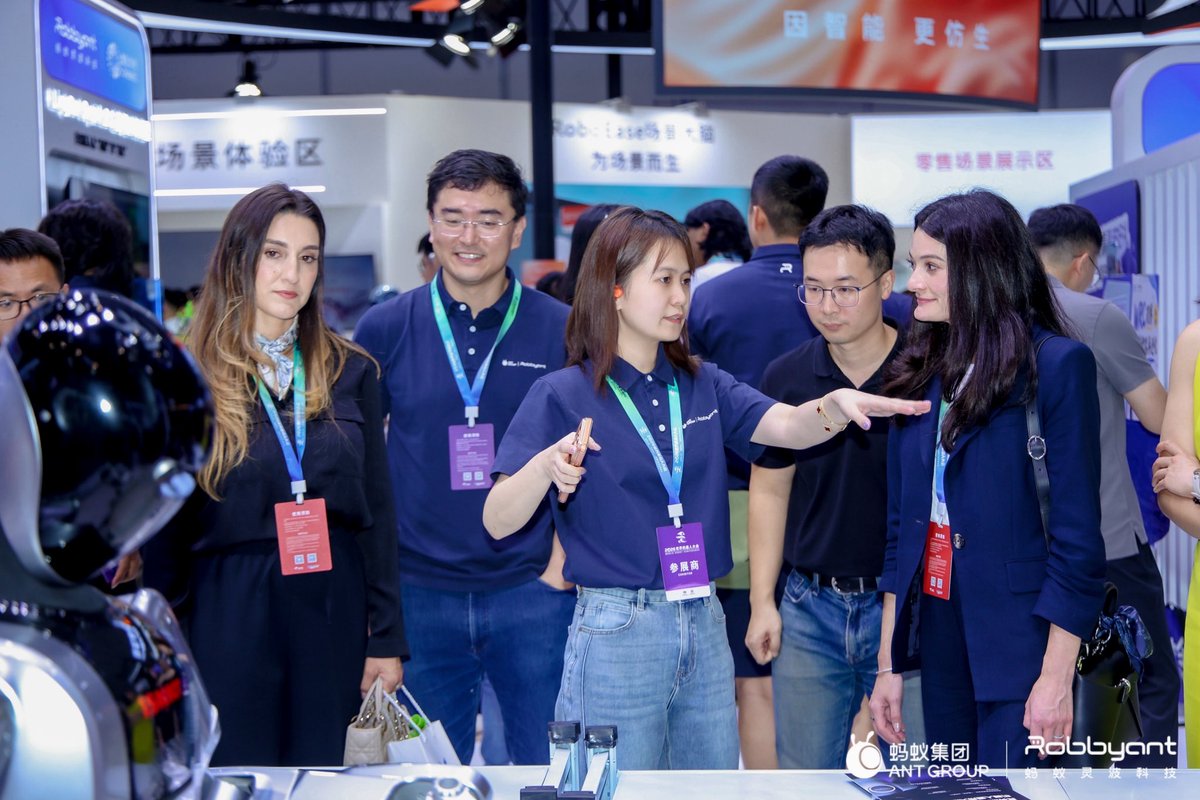
👋 WRC 2026 is a wrap.
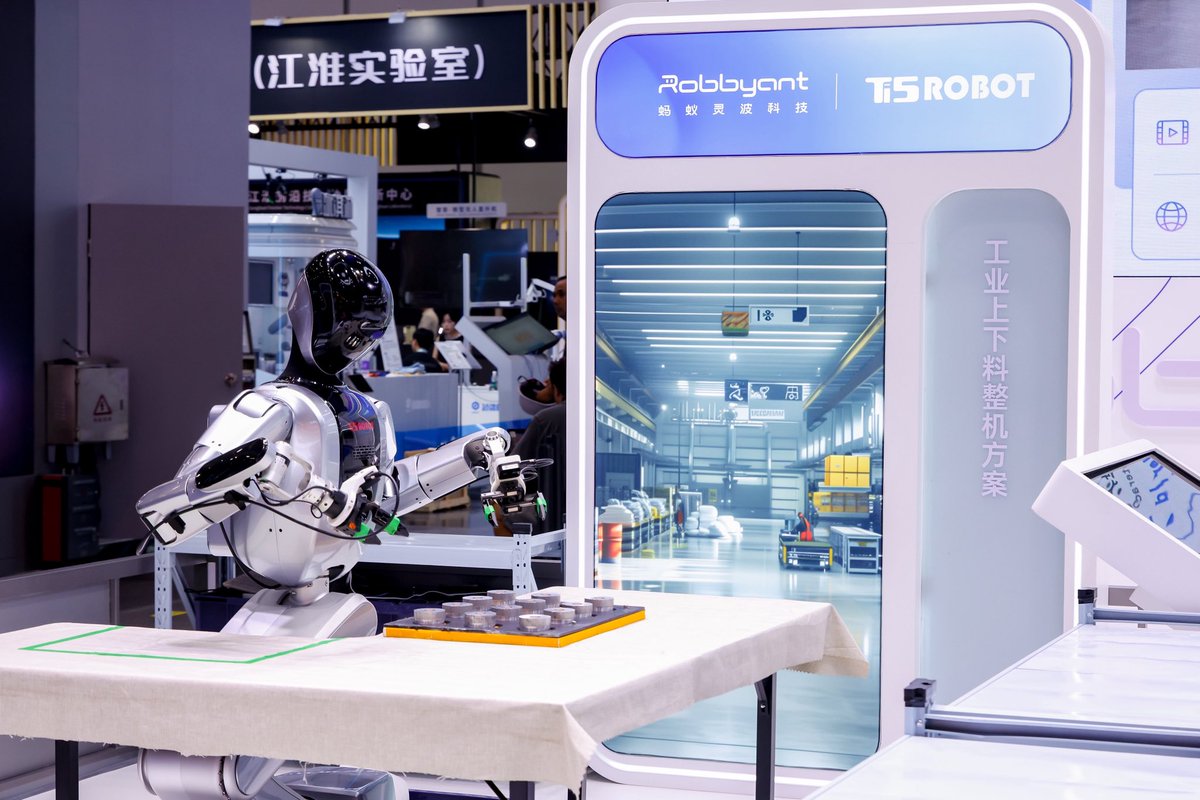
🤖 Thank you to everyone who visited Robbyant booth. We showcased LingBot 2.0 alongside real‑world deployments across smart pharmacy, logistics sorting and industrial machine‑loading scenarios.
🧠 One model, running on 3 distinct robot embodiments for 3 different real‑world tasks.
📍Next stop: ECCV. See you there!
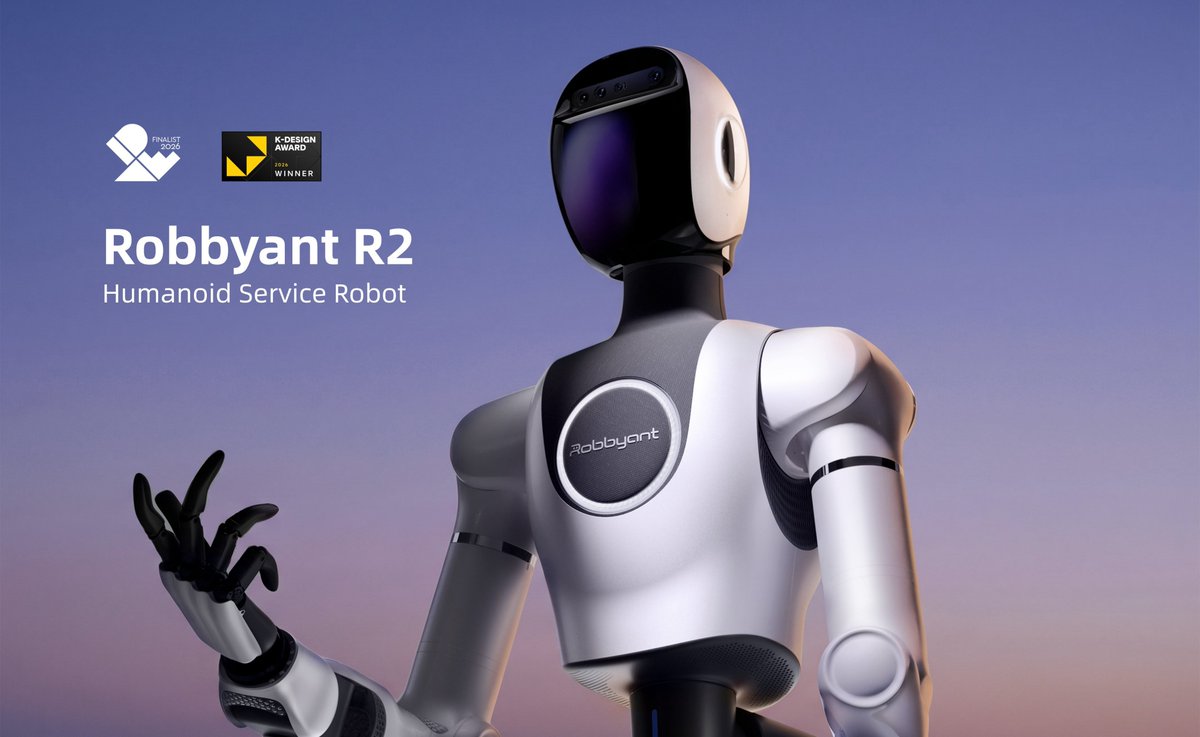
Robbyant R2 has been recognized by IDEA and K-Design Award. 🏅
For humanoid service robots, great design is not just how it looks — it is how safely, efficiently, and naturally it works around people.
Our R2 industry solution will be showcased at WRC this week.
Come meet us at C111.
Jake Zhao is one of the sharpest scientists I’ve collaborated with.
For over a year, he’s led work on the LLaDA Series at Ant Research. It could well be the most widely adopted and capable discrete diffusion LLM by far.
(You can check it out here: https://t.co/GClz0hNlEU)
Discrete diffusion language models have moved from a relatively niche research direction into mainstream conversations around language models.
I hope his insights inspire more builders working on dLLMs.
#dLLM #LLaDA #LLM
After more than a year‑long research journey spanning LLaDA‑MoE to newly‑launched LLaDA2.2, LLaDA series lead Jake Zhao shares his technical insights and forward‑looking outlooks for dLLM.
#llada#dllm#opensource
Brain.md creates a persistent memory layer for coding agents by capturing project knowledge as plain Markdown files inside the repository.
https://t.co/qpwTqGa69F
This week in Shanghai, PyTorch Foundation Executive Director @sparkycollier and PyTorch Foundation CTO @matthew_d_white will speak across three forums at World Artificial Intelligence Conference 2026.
On July 18, Mark will participate in @alibaba_cloud's “Agentic Cloud: The Infrastructure for the Agent Era” forum (Silver Hall C+D, Layer G, Shanghai World Expo Center), when Mark will participate in the 11:40 dialog “Build trusted agents at scale with Agentic Cloud” with Ali AI Group CTO Feifei Li.
On July 19, Mark and Matt will deliver keynote talks at BAAI’s Open Compute for AI and AI Agent Ecosystem Forum (Room 618, Shanghai World Expo Center). Their sessions will address how open source is rewiring the future of AI and technical autonomy across hardware architectures, supply chains, and agentic systems.
Later that day, Mark and Matt will deliver keynote talks at @AntGroup's Making large models accessible: AGI Infrastructure Forum (Room 518, Shanghai World Expo Center). Mark will present “The Open Acceleration: How Open Source is Rewiring the Future of AI” at 14:05, followed by Matt’s “Just Enough Intelligence: Why the Key to Widespread Adoption of Intelligence is Optimization Engineering” at 14:20.
Mark and Matt will then participate in the 14:35 dialogue “Open Foundations, Inclusive Futures: Collaborative Infrastructure for Accessible AGI” with Ant Group CTO Zhengyu He.
📸 Check out Mark exploring the conference and speaking with CCTV during an on-site interview. Stay tuned for more from Shanghai.
🤖Robots that think ahead and act in real time.
LingBot-VA 2.0 — the first embodied-native foundation model. Not fine-tuned from a video generator. Built from scratch for the physical world.
✅ 93.6% success on bimanual tasks
⚡ 150 Hz single-GPU inference
🎯 20 demos to generalize.
This is what happens when you stop adapting and start building natively. 🧵👇
LingBot-VLA 2.0 is bringing causal world modeling to open-source robotics.
By natively unifying visual dynamics prediction and action inference, this new foundation model handles complex, long-horizon tasks with incredible efficiency. It was trained on 60,000 hours of diverse data to achieve true whole-body control - managing everything from dexterous hands to mobile bases seamlessly across 17 different hardware brands.
Despite the heavy lifting, its dual-stream Mixture-of-Transformers architecture keeps inference ultra-fast, under 130ms on a standard RTX 4090.
Explore the pre-trained checkpoints in the Hugging Face collection: https://t.co/O3SDPtPqgl
🌍 10 minutes was just the beginning. What if a world model could run forever — responding to your every action, generating new events, and never losing coherence?
Today, we open-source LingBot-World 2.0 (Infinity) 🔥
The first interactive world model with:
🔷 Hour-long generation with zero quality drift
🔷 Rich actions & events — attack, cast spells, shoot, summon storms
🔷 Agentic world — a Director Agent drives real-time world evolution
720p/60fps. Playable like a game. 🎮 Try it now on @reactorworld — or deploy it yourself with SGLang day-0 support. @lmsysorg
#WorldModel #EmbodiedAI #OpenSource #Robotics