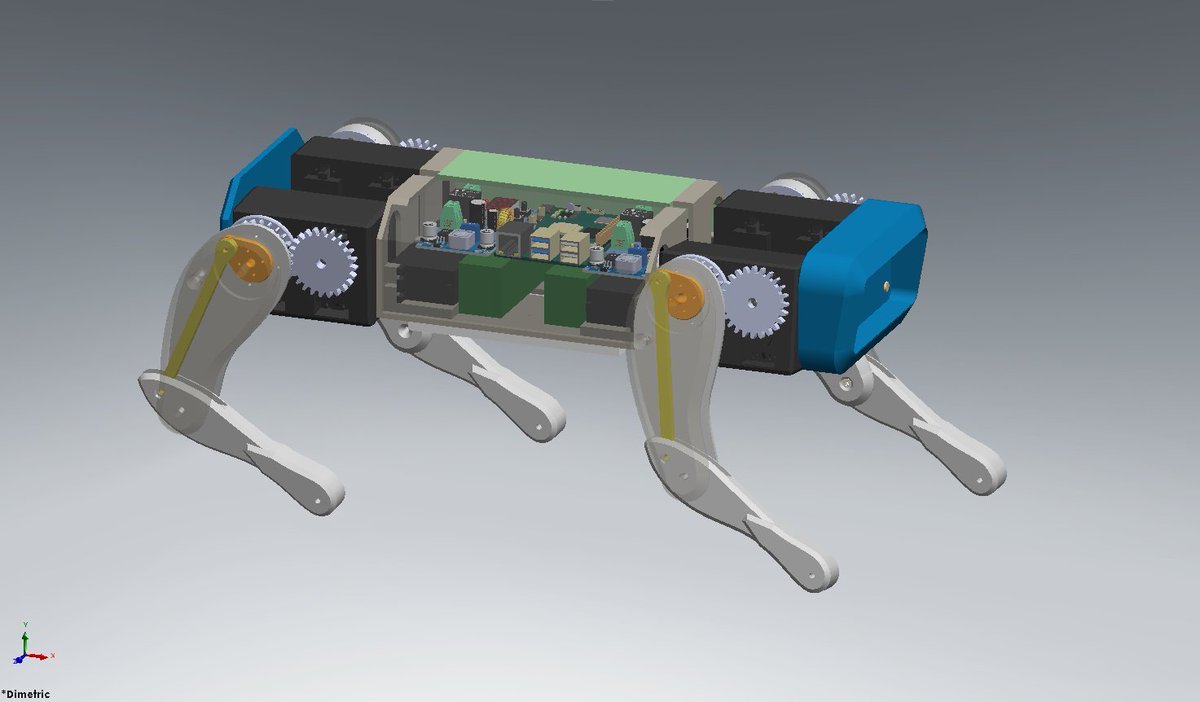
New power supply arrived, powering Cooper with it already.
Whipped up some code to run one leg, notice when the upper leg moves, the knee angle don't change. Concept from 2 weeks ago now proven😎
@greg_schneid@BeaumontQu
Putting Cooper in the air again. Currently using double sided tape to attach motor mount to base plate, these motors still haven't learn to not bump into other components, better to detach tape rather than snapping something.
Trying to keep the gear drive design for more intuitive angle calculations, despite the linkage continues to buckle... When motors rotate in sync, knee angle don't change :)
@greg_schneid@BeaumontQu
No updates on the new leg design. That's becuz I was migrating Cooper's CAD from SolidWorks to Onshape. Clearly, a shared OneDrive folder is not as good of a PDM as Onshape.
I'll need to take the new motor idea back to the discussion board... rn it's a bit too ambitious...
Cooper's getting a hardware change... The servos we had don't give feedback to the controller, and they make initial assembly a pain... So me and @greg_schneid has decided it's time to change the leg design (again)!! This time for NEW SERVOS. Stay tuned to see how this goes.
Almost got rotational gait working on the robot -- looking forward to testing on some hardware shortly!
Working out robot gaits is harder than it looks - mad respect to all those that have done so already.
@BeaumontQu@justin_liu2@localhostHQ
The past two weeks were just... chaos.
I was making hardware design changes while @greg_schneid was servo testing and math-ing.
But now we're actually making progress! Tho I had to remove two legs off the dog because the motors are not turning in the correct directions lol.
Me & @greg_schneid will be posting updates on the development of Cooper. Find out what more about Cooper under @BeaumontQu's account too.
So I completely blanked out about adding screws holes in the prev leg prototype. For like 2 hrs I was punching holes with a screw driver 😂
Had way too many problems with 3D printed linkages, now we're tinkering with gears...
Hoping to increase the range of actuation + precision of movement.