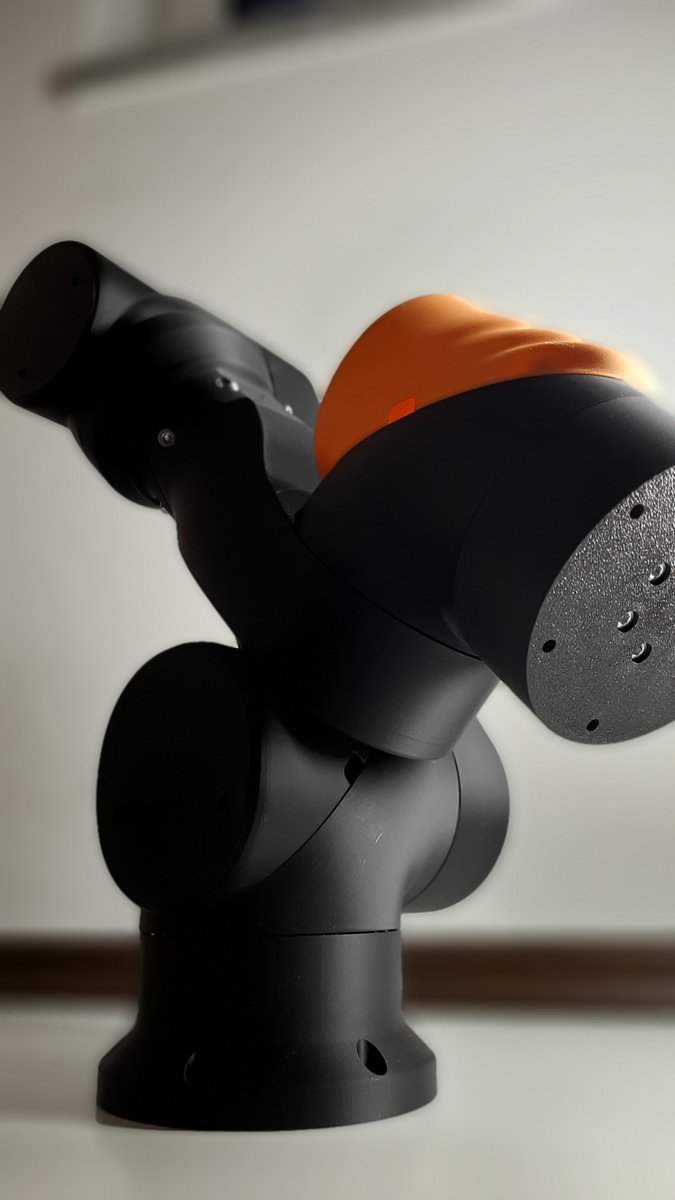
This new gripper is insane! I optimized the closing mechanism and minimized friction. The sensitivity directly through motor current is so satisfying.
-2 to final launch.
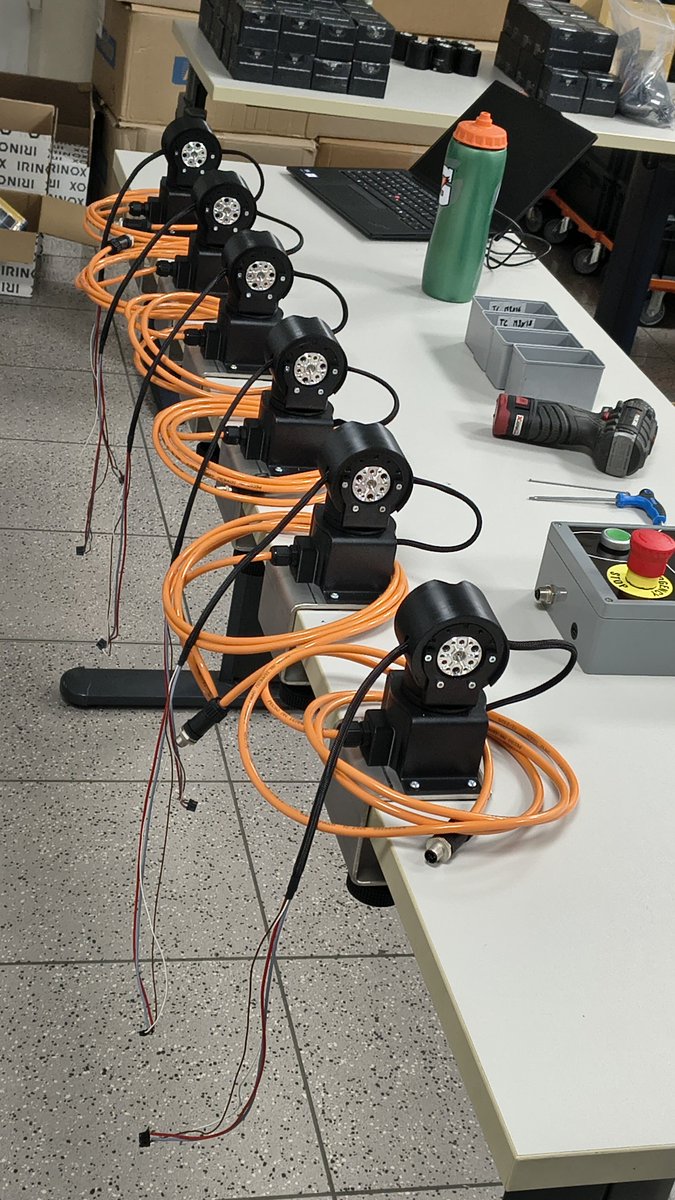
Deploying robots to factories requires industry grade connectors and electrical components. This is why we at Itaca Robotics are obsessed with product quality. Just plug the robot with an M12 connector and press the green button. You are ready to run your policy.
@aurel_arnold Also try with salt and pepper and add or subtract to all pixels a random value, increase or decrease luminosity.
Let me know if that helps :))
@aurel_arnold On a random selected rollout, add one of: gaussian blur (might help with moving cameras), random occlusion boxes (might avoid one master camera - like dropout for cameras or partially) and maybe some images of random distractor objects on some frames (might help robustness)
@aurel_arnold From personal experience working in the machine vision industry. Haven't tested it on robot learning, but in computer vision, that makes a huge difference in changing lighting conditions or blurred images from motion.
I built a robot arm in my dorm room. I designed the entire structure out of aluminum and integrated the full control stack in ROS2 with ros2_control and Moveit2. The demo is using moveit-servo and a joystick. Soon upgrading to the Meta Quest.
I am obsessed with low latency, so I developed a damiao motor ros2_control hardware abstraction interface in C++ to benefit from the amazing Moveit2 package.
You can take a look at https://t.co/sAJpQz3NVC
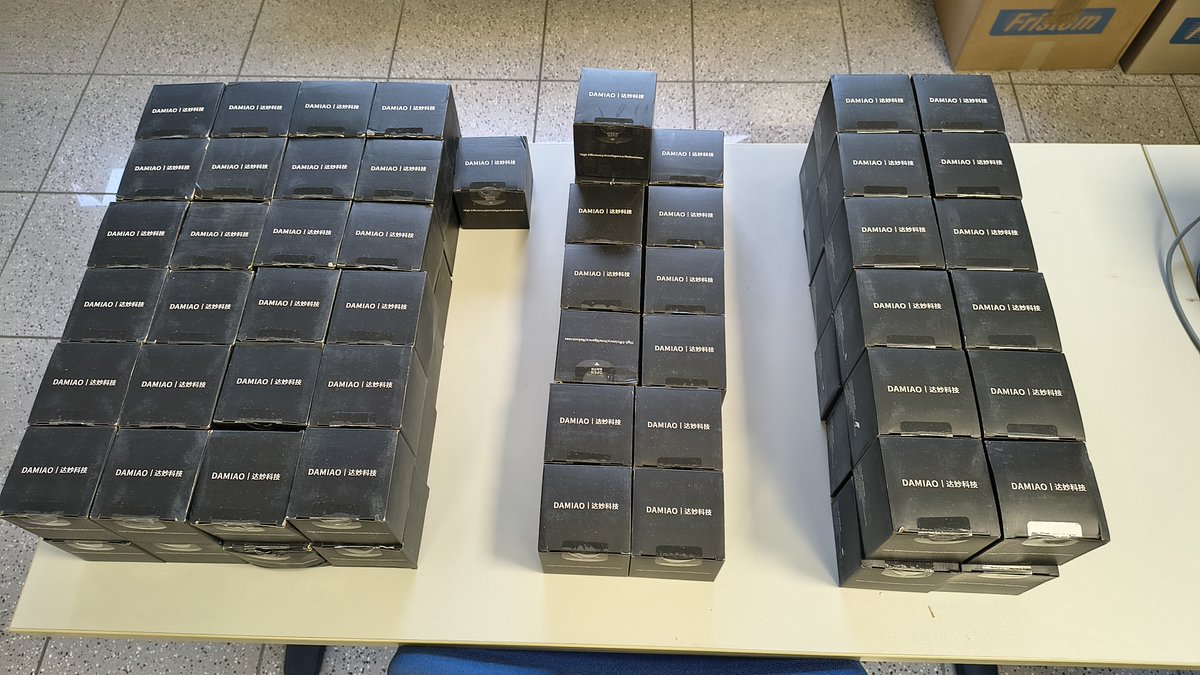
Less than a year ago I invested my first working-student pay check and bought 7 damiao motors and a 3d printer.
My dorm room soon became a lab with a bed. After long CAD nights and a printer running 24/7 I developed the first proof of concept of a robot arm.