We redesigned how Cosmos Policy runs on Jetson Thor:
1.83s → 275ms
p50 per 16-action chunk.
LIBERO-Spatial sim;
Official skip-decode baseline.
I’d love to hear what’s slowing your robot down.
DM me your model + hardware.
Grab a spot here: https://t.co/OVWRvh9VB3
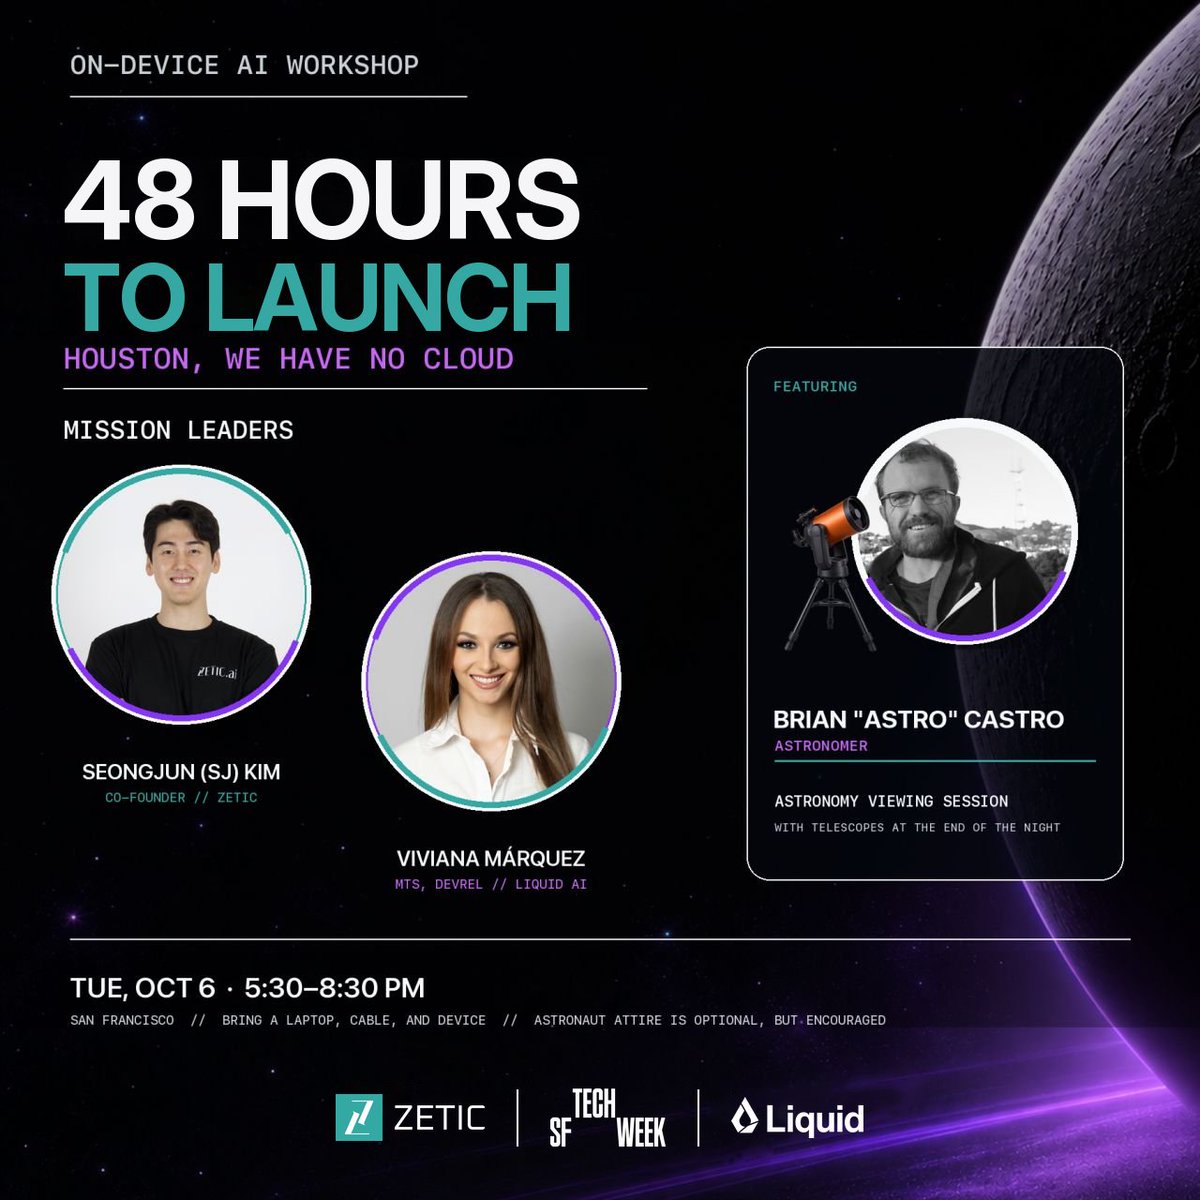
Mission leaders: me + @vivmarquez from Liquid AI's DevRel team. Astronaut attire optional, but encouraged.
#ZETIC#OnDeviceAI#LFM#LiquidAI
48 hours to launch 🚀
Tue 10/6, 5:30 PM in SF: an on-device AI workshop with @liquidai for #SFTechWeek.
Get models running on your own phone, no cloud required.
Bring a laptop, cable, and device. We close with telescopes and an astronomer.
RSVP 👇
@physical_int
pi0.5 policy inference just went sub-20 ms on Jetson Thor by us.
p50: 19.16 ms / p95: 19.20 ms
37.3x vs our original 714 ms PyTorch reference.
Runtime optimization with Execution Design.
Closed-loop success: 448/500 (89.6%).
Make robot to not to be like a sloth anymore!
Jev-style decision AI, on-device. 🎮
KEV-4B on Jetson Thor.
Nine plays at 1,000 km/h simulated speed.
❌ Baseline: 0/9 - all Game Over
✅ ZETIC optimized: 9/9 still running !
We make AI run faster on your hardware.
DM me.
https://t.co/yQ6SMShGDJ
#Jev#DecisionModel#ZETIC
For context, @nvidia's Jetson AI Lab tutorial: ~48 ms with TensorRT FP8 + NVFP4.
https://t.co/tWxwDm08LC
Our 19.20 ms p95 is ~60% below that published figure, a 2.5x ratio between the reported latencies.
With an acceptable 89.6% Closed loop accuracy.
When you get lost zoom out a bit and you'll see a clearer picture. The bulls had several chances to change the picture but failed to do so. The daily and weekly looks like shit
I'm not in this one but this is one of my favorite patterns to trade. Ideally, we start closing above these grey boxes. Look for a retest of the grey's for entries if you are not already in. $cream