Today we announced our initial funding round! Special thanks to Fly Ventures and to co-lead Toyota Ventures. We are excited to be on this path together. Many thanks also to Logos Fund and Sparked Ventures, who participated in the round and provided help and advice.
#Robotics
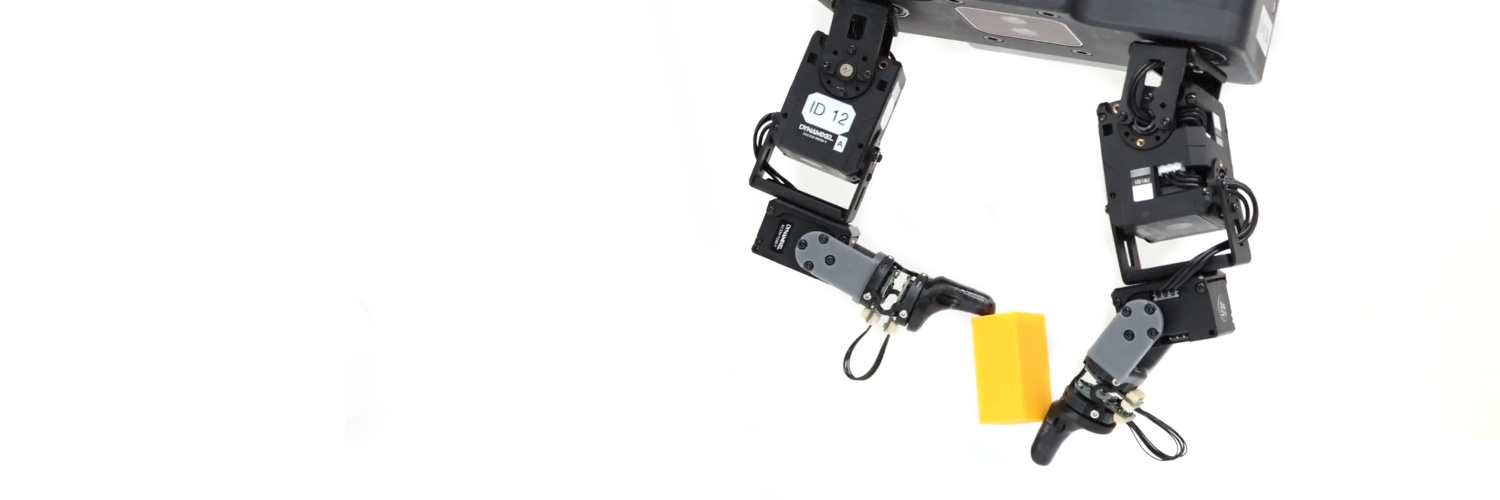
While we’re working on more dexterous policies, a hardware update: our TR01 Hand got an upgrade. The new version has stronger motors at every joint, better packaged electronics, better cable routing, and a new camera model and mounting location.
#Robotics#WeAreHiring
Demonstrating TR02: our new three-finger dexterous hand. With one more finger than its predecessor TR01, it is able to perform not only fingertip fine manipulation, but also tripod grasp, envelop grasp, in-hand reorientation, manipulation while holding, and more!
#WeAreHiring
Today we're demonstrating autonomous dexterous tasks for manufacturing, leveraging our unique hand kinematics and touch sensing. Trained via Imitation Learning on a few dozen demonstrations, all executions are fully autonomous.
#robotics#manipulation#NYC#startup
Touch is one of the hardest senses to give a robot — and one of the most important.
We're publishing our blog post on Popcorn, our miniature touch sensor built for dexterous robot hands. Read more👇https://t.co/yONCeHlg5q
📢 We're hiring! Check out
https://t.co/5wWGbhRJr4
At Tangent Robotics, we are aiming to advance all aspects of dexterous robotic manipulation. We are excited to share our first blog post on the kinematics and teleoperation of TR01, our first robotic hand.
https://t.co/2kyzXUmMQe
Follow and join us! We are hiring!
We’re excited to introduce Tangent Robotics.
We’re building dexterous robot hands for human-level manipulation, spun out of Columbia University’s ROAM Lab.
First prototype + teleoperation teaser below. More to come.