hey, i’m utkarsh.
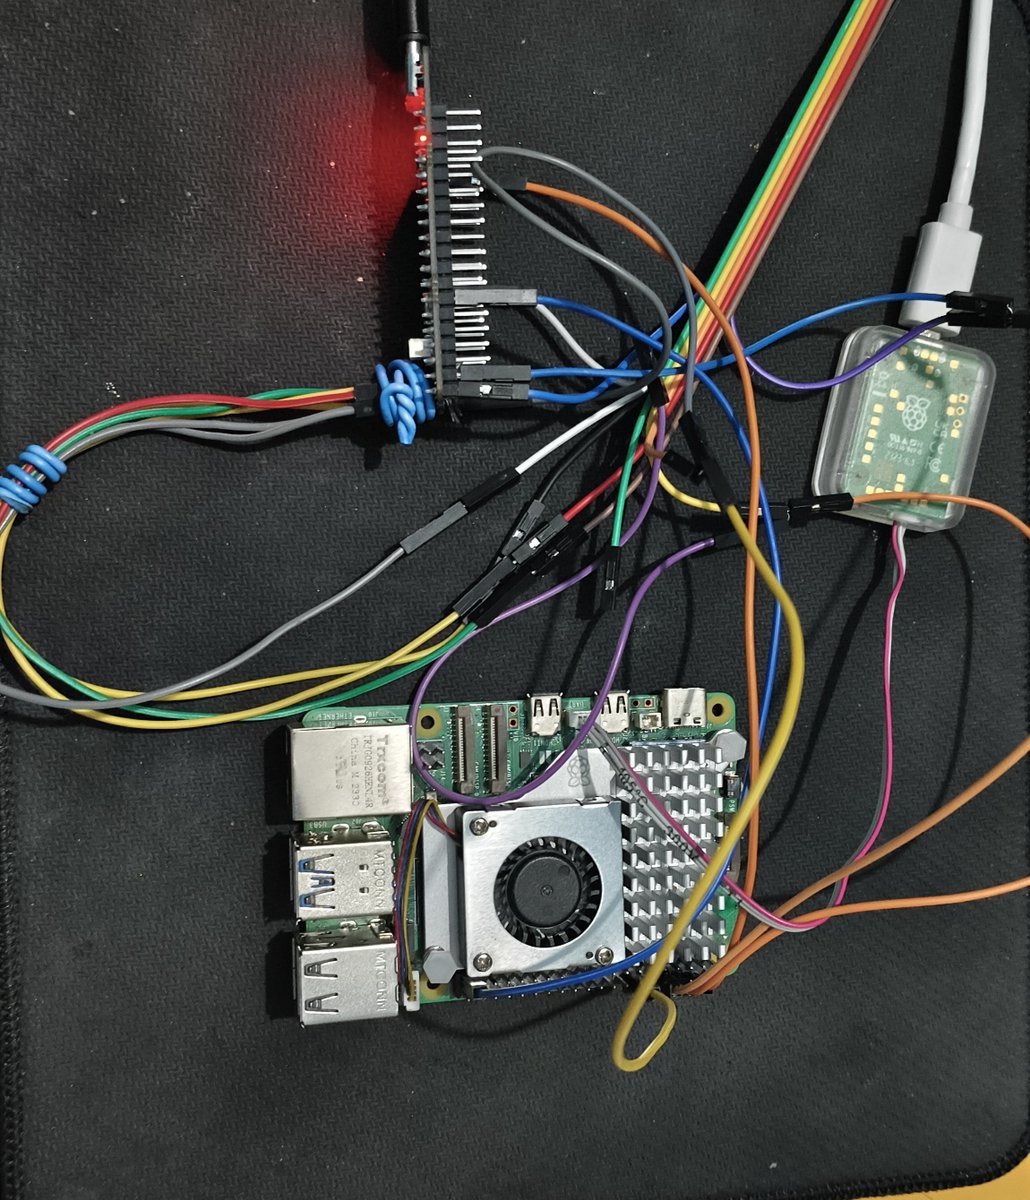
- building voln labs + axiomOS, a runtime OS for robots
- currently at polymath (yc w26), building systems + verifiers for software agents
- previously firmware @ cypherock
- built kernels, distributed systems, drones, and a 6502 computer
- contribute to multikernel linux + erofs + Limine + bpftime
- mostly interested in machines where software eventually has to touch reality
fun fact: i’m still deciding whether i want to spend my life building operating systems, robots, or companies. probably all three.
Imagine asking an AI agent to align a small rover with a marker. The agent looks at a camera image, reasons about the task and proposes a movement. That is the interesting intelligence problem. The product problem is larger: who permitted that movement, how old was the image, which controller received it, what happens if the agent disappears, and what evidence shows the rover actually moved?
Volnlabs is building the execution and evidence system around that intelligence. It gives an operator a repeatable sequence: install, pair, observe, propose, admit, execute locally, interrupt, reconcile, rearm and inspect. A clever proposal is only one input. It cannot create its own permission or declare its own physical success.
Been cooking something... 👀
https://t.co/Pr0CSoEewE
I started building this for myself because I was tired of reading books, but somehow I never get tired of reading manga (lol).
So I thought, why not turn books into manga?
And that's basically what PanelSummary does.
Give it a book PDF, and it turns it into a manga-style experience you can read right in your browser.
Planning to launch it soon, once I figure out how to host the backend without burning a hole in my wallet. Any cheap hosting suggestions are welcome!
Sharing a few samples of what I've tried so far and what it generated 👇
( Fun fact: The whole thing was built using MiniMax M3 as the underlying model.
Now I'm really curious how much better it could get with Sonnet 5.5 or Opus 5.5.
If only I were rich enough to casually run Opus 5.5 experiments 🥲 )
two papers accepted at NeurIPS 2026 workshops :)
both came out of a question i've been thinking about while building AxiomOS:
what happens when robots can rewrite their own behavior while they're still running?
getting better at a task is one problem. making sure the transition itself doesn't violate safety, authority, or timing constraints is another.
the papers explore transactional publication and authority lifecycles for these runtime updates.
accepted at AgenticOS + CL4FMAgents @ NeurIPS 2026.
back to building.
10 NeurIPS 2026 papers in robotics / embodied AI worth watching:
1) Embodied-R1.5
one model for physical reasoning, grounding, planning + robot control
https://t.co/EzvaJdg6e9
2) LaST-R1
reinforcing the latent physical reasoning inside a VLA
https://t.co/ToLGMYbPFb
3) LessMimic
humanoid interaction using local geometry instead of continuously copying human motion
https://t.co/tlhxy68soK
4) Point4D
long-range 4D motion reconstruction through occlusions
https://t.co/QflIuFzByR
5) Grasp-Then-Plan with Failure Attribution
figure out whether the grasp failed or the motion policy failed
https://t.co/0EEh2aKlgv
6) OxyGen
shared KV caches for much faster multi-task VLA inference
https://t.co/AdpC9sRra1
7) PACE
help robots understand how far through a long-horizon task they already are
https://t.co/b7cSDLilzp
8) TDBench
tests whether VLMs really understand top-down / bird’s-eye scenes
https://t.co/AGIFSbZjTI
9) Where to Attend / PaPE
positional encoding designed around visual geometry instead of 1D language
https://t.co/ePwhUTipkL
10) H-GenPO
hierarchical generative policy optimization for Physical AI
https://t.co/WkRu9YjDp7
really interesting batch across robot reasoning, humanoids, VLA post-training, 3D perception, long-horizon manipulation and efficient inference.
Massive week in robotics.
I went through everything from Figure, Agility, Boston Dynamics and even more.
Get your coffee and see what happened in robotics space: