This is a collaboration between @YueLabCaltech and Professor Morteza Gharib’s group, across aerodynamics, machine learning, robotics and control.
I’m especially glad to work on this project with one of my best collaborators, Xiaozhou Fan (https://t.co/DLB4id71Bm). We’re now extending this work toward real-world free flight.
6/6
Fixed-wing UAVs offer long endurance and efficient flight, but agile control remains difficult because their aerodynamics are highly coupled, especially under gusts and changing flow conditions.
Our paper A Narwhal-Inspired Sensing-to-Control Framework for Small Fixed-Wing Aircraft, accepted to ICRA 2026, presents a new sensing-to-control framework for this problem.
Paper: https://t.co/UwOVhN14e7
Project: https://t.co/Koqvz2Xmsi
1/6
We then learn a control-affine aerodynamic model with a soft left/right symmetry prior.
Wing-pressure inputs reduce estimation error by about 25% to 30%, and under wind-speed shift the structured model degrades much less than an unstructured baseline. It also yields smoother force tracking and control.
5/6
Excited to share that we have 3 papers accepted to ICRA 2026, 1 paper accepted to the CVPR 2026 Findings Track, and 1 paper presented at 3DV 2026! 🎉 🎉
[1] GaussianFormer3D: Multi-Modal Gaussian-based Semantic Occupancy Prediction with 3D Deformable Attention - https://t.co/EhB9eU38NM
Lingjun Zhao, Sizhe Wei @SizheWei, James Hays @jhhays , Lu Gan
ICRA 2026, RSS 2025 Gaussian Representations for Robot Autonomy Workshop
[2] STATE-NAV: Stability-Aware Traversability Estimation for Bipedal Navigation on Rough Terrain - https://t.co/iNZbXfgW4K
Ziwon Yoon, Lawrence Y Zhu @LawrenceZhu22, Jingxi Lu, Lu Gan, Ye Zhao
IEEE Robotics and Automation Letters 2025, ICRA 2026
[3] A Generalizable Physics-guided Causal Model for Trajectory Prediction in Autonomous Driving - https://t.co/wz7yDLE9VR
Zhenyu Zong, Yuchen Wang, Haohong Lin, Lu Gan @ganlumomo, Huajie Shao @HuajieShaoML
ICRA, 2026
[4] ShelfGaussian: Shelf-Supervised Open-Vocabulary Gaussian-based 3D Scene Understanding - https://t.co/hx0gQ1MEd7
Lingjun Zhao*, Yandong Luo*, James Hays @jhhays, Lu Gan
CVPR 2026 Findings
[5] Diffusion-Denoised Hyperspectral Gaussian Splatting - https://t.co/gJ0K6Gm1N7
Sunil Kumar Narayanan @gaussiannerf, Lingjun Zhao, Lu Gan @ganlumomo, Yongsheng Chen
3DV, 2026
Huge congratulations to all authors and collaborators. Looking forward to connecting in Vienna and Denver!
#lunarlab #Robotics #ICRA2026 #CVPR2026 #3DV2026 #AutonomousDriving #humanoid
Check out our recent work on MS-HGNN. We incorporate morphological symmetry into a graph neural network framework to enable more morphology-aware learning. We demonstrate data- and model-efficient learning on quadruped robots. The framework has the potential to generalize to other rigid body systems such as humanoids, dexterous hands, and bimanual manipulators for learning dynamics and control policies. We’ll present this work at L4DC and the RSS 2025 EquiSystems Workshop. Looking forward to discussions and potential collaborations on morphology-aware learning in robotics.
It's Friday afternoon, and we’re packing for L4DC 2025 @l4dc_conf next week 😎
Excited to share MS-HGNN — our take on bringing morphological symmetry into GNNs for legged robot dynamics.
🧵 (1/4) We bake both kinematics and morphological symmetry into the model →
- Generalizable
- Sample-efficient
- Compact
🌐 Project: https://t.co/1qIqrl0ziX
📄 arXiv: https://t.co/PEgBaIQKj1
💻 Code: https://t.co/Ykb7yXQK1H
Team: @xie_fengze32905, @SizheWei, Yue Song, @yisongyue, @ganlumomo
See you next week in Ann Arbor! #Robotics #L4DC2025 #GeorgiaTech
Our recent paper, "MAGIC-VFM: Meta-learning Adaptation for Ground Interaction Control with Visual Foundation Models," has been accepted for publication in IEEE Transactions on Robotics (TRO)!
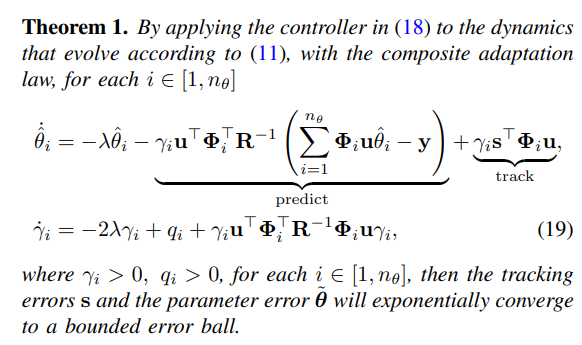
This work presents an offline meta-learning algorithm to build a residual dynamics and disturbance model using Visual Foundation Models (VFM) and vehicle states. This model is integrated with composite adaptive control to adapt to changes in both the terrain and vehicle dynamics conditions in real-time.
Work done with @robot_in_space2 (Co-first author), James A. Preiss, Jedidiah Alindogan, Matthew Anderson, and @SoonJoChung. [1/n]
Paper Link: https://t.co/MeuOTEwDlu
The results demonstrate that the integration of a VFM in an adaptive control framework enhances tracking performance, yielding an average improvement of 53%. [5/n]