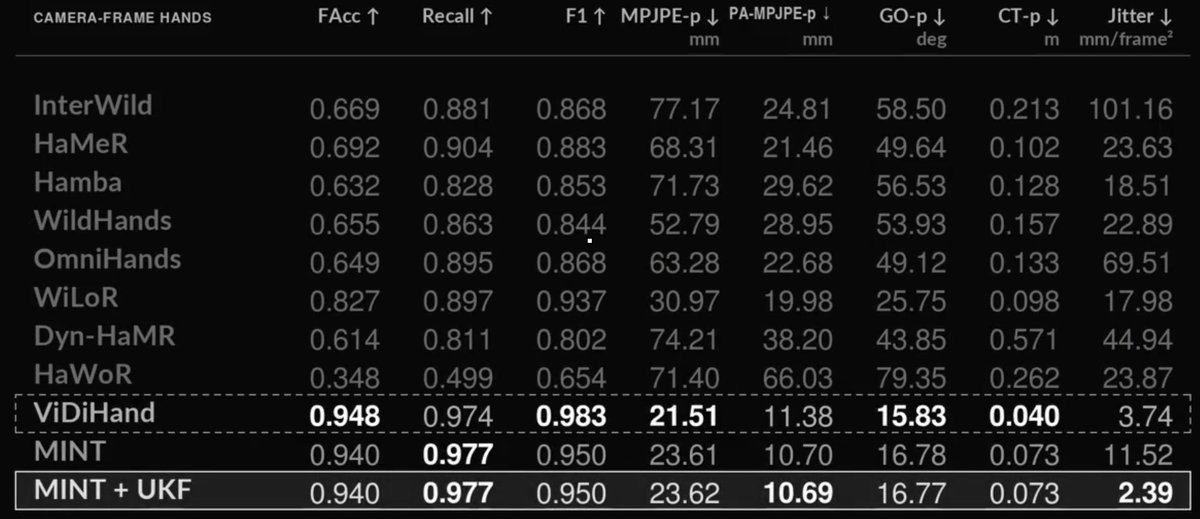
@chris_j_paxton apart from in jitter on hot3D, ACE-Ego-Hand crushes MINT! Open source data is awesome tho!
Also in holdout HOT3D and ARCTIC: ACE-Ego-Hand is much stronger (seems like the "conventional pipeline" Wuji refer to is the HaWoR)
@chris_j_paxton How does it do this tho, its not trained with any state modeling or large state/video context. Nor trained on robotics data(?). Seems like there must be something big I/we don’t know about
@chooi_jeq Have u tried providing some context of certain end effector poses and the corresponding images, to ‘calibrate it’ (seems like it calibrates itself but takes some time). Alo thought about predicting relative pose instead, so just have the api specify velocity of ee?
Introducing FLUX-mimic, a next-generation Video-Action Model for general purpose dexterity, developed in partnership with @bfl_ai.
Late last year we published mimic-video and introduced Video-Action Models (VAM): a new family of robotics foundation models built on top of video generation models. We showed that robot control reduces to visual prediction, and that robot capability is downstream of improvements in video modeling accuracy. The obvious implication was that advances in the video modeling frontier would directly translate to increased capabilities in end-to-end robot learning.
FLUX-mimic is that thesis at frontier scale: We've applied our VAM architecture to the strongest video backbone available today, FLUX 3 from Black Forest Labs, and trained it on data from our own robots and wearables. General-purpose dexterity, running on a single GPU on premises.
Because the model already understands world dynamics, it needs far fewer demonstrations to learn a new task. This is game-changing for our mission to deploy robots to factory floors, where industrial robot data is scarce and expensive to collect.
We're now testing and deploying FLUX-mimic with manufacturing leaders like @Audi, on complex, multi-step manipulation long considered impossible for conventional automation.
The 2026 World Cup Quarter-final between Norway and England is the biggest game in Norway’s football history. In the 47th minute, in the first half, England makes it 1-1. Did Ørjan Nyland’s goal kick preceding England’s goal hit the Spidercam cable? I did a small investigation.
From day one, mimic has been focused on a single goal: general-purpose dexterous manipulation. Today we're proud to announce the mimic hand M1 and the mimic wearable U1.
We believe the only way to solve dexterous manipulation at scale is by going full-stack at the frontier of physical AI, building every layer ourselves around one fixed point, the human hand.
The M1 is a highly backdrivable, tendon-driven hand that covers the full range of human capability, from heavy payloads to fine manipulation.
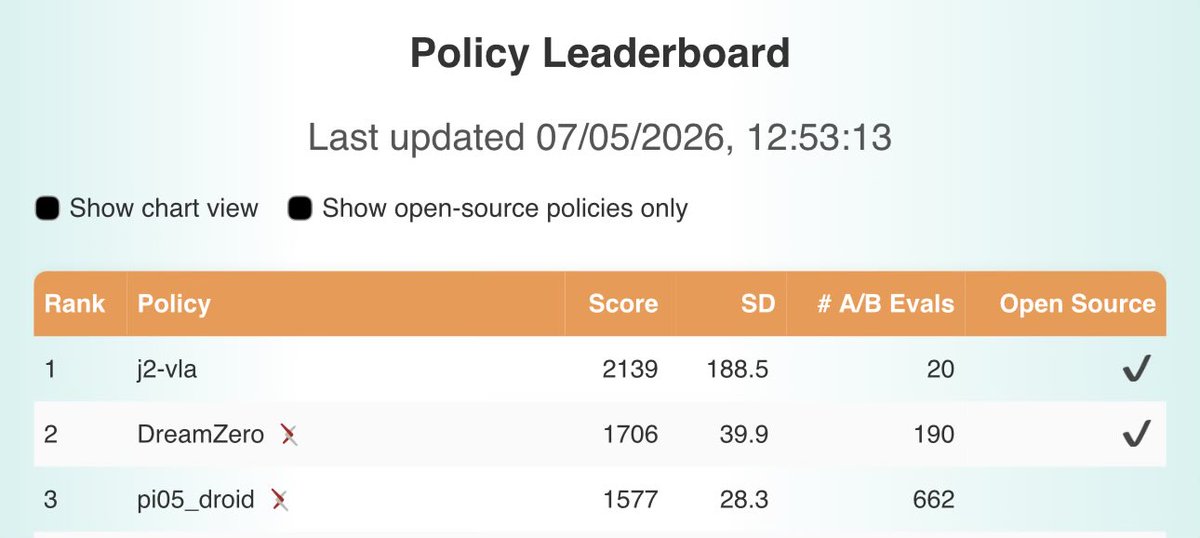
@zhaohang0124@SeonghyeonYe But dreamzero didnt do any ‘imagination’ at their inference time, they just denoise noisy actions (they kept the frame prediction since it didnt affect runtime much, not because it was crucial for performance). Or am i missing smth?
How does Claude Code stack up against all of Norway in developing AI solutions? 🇳🇴
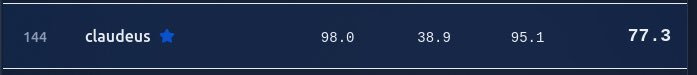
Over 3,000 participants in the norwegian ai championship, competing for 100k USD, and my claude bot running fully autonomously on a single prompt placed top 50 in two out of three problems!