I’m rebuilding this account around what I actually do now:
I build AI + robotics systems for the physical world.
PCB design. Embedded C. Robotics control. ML/computer vision. Mobile apps. Medical-device engineering. Mechanical prototypes. The messy stuff where software has to survive contact with hardware.
I’ve founded and built projects across pathology imaging, automated agriculture, medical devices, AI training tools, PCB automation, and robotics. I’m currently building PromptPCB and leading engineering on AutoTQ.
This account is going to be build logs, technical notes, failures, fixes, prototypes, AI hardware workflows, and lessons learned the hard way.
No guru content. No fake founder theater.
Just engineering, product building, and the grind of making difficult systems work.
@blind_via Little different though my guess is tscircuit here is doing helical escape negotiation for the A*
I think the other video is doing RRT* based routing hence the randomness of the points being placed
Relatively basic sim but produced with no external libraries with integrated physics as well as accurate harmonic drive motion
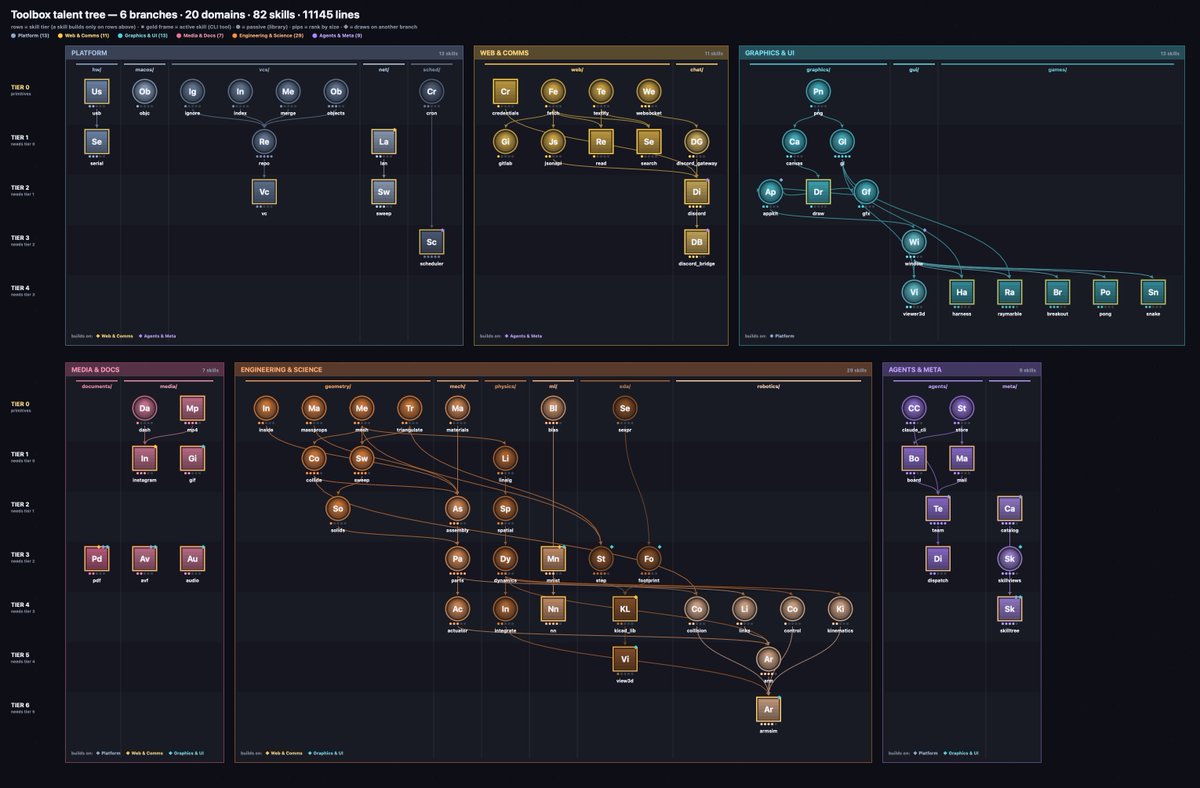
Nothing brand new happening here but trying to push the limits of the models ability to create and organize new tools for itself.
The only prompt given was "make a physics accurate robot arm" it decided fully what tools and framework needed to be created from scratch and reorganized itself merging duplicate tools and code and building on what it had produced prior
Currently working on building the "skill tree" for this agent