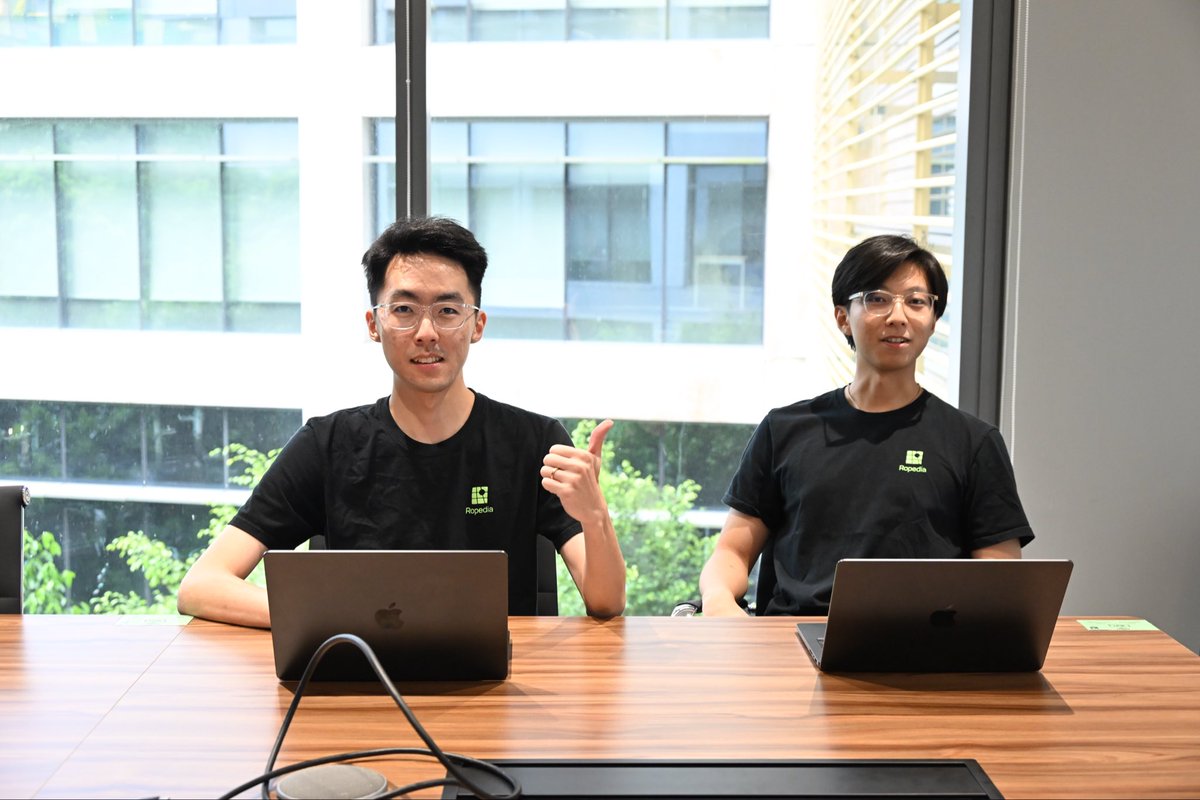
Physical AI starts with real-world data.
Meet Ropedia at #IROS2026:
→ HOMIE Gen2 live demo
→ IROS-exclusive Evaluation Dataset
→ Ropedia merch
📍 Booth 742
📅 Sep 28–30
Come see what we’re building.
Gave GPT-6 Astra a few renders of our office scan. It came back with a full Blender rebuild — 50 desks, 62 chairs, walls, blinds — aligned to the scan within 2 cm and exported to USD. Dropped it straight into Newton with a G1 walking through it. One prompt → a humanoid gym. 🤯
Physical AI will scale with egocentric experience, just as LLMs scaled with tokens.
HOMIE Gen2 is our next step toward making real-world multimodal experience scalable for robots, world models and physical agents, just like Project Index @Figure_robot
The Experience Scaling Law is just getting started!
A first glimpse of the wildest robotics project of my PhD.
🛹 The Blind Skateboarder 🛹
No vision. No markers.
Paper, code, weights — coming soon. And we have more. 😉
Robots in training: #NTUsg spin-off Ropedia has raised US$22 million in a pre-Series A round, bringing its total funding to US$30 million.
Ropedia was co-founded by #NTUsgAlumni CEO Chen Zhaoxi and CTO Hong Fangzhou, along with Assoc Prof Liu Ziwei from NTU’s College of Computing and Data Science (@NTU_ccds). Assoc Prof Liu serves as the company’s Chief Scientist.
Ropedia’s wearable technology captures real-world human activity and turns it into training data for robots and physical AI systems. The new funding will support data collection in Southeast Asia and North America, device production, as well as AI research and engineering.
#NTUsgInnovation #NTUsgResearch #AIatNTUsg #AI
Feet on the ground.
It's always been one of the hardest problems in capturing human motion.
We've released an updated flagship perception model Comic 4.2.
We've focused on an advanced foot physics estimation system, properly estimating force, friction, toe roll, and elevation changes — all from simple video input.
For those making games and doing 3D animation, you can use it directly in Unreal Engine and soon Maya and Blender.
Mocap on tap, as we like to say. It's fast, accurate, and inexpensive 🤸♀️
Live at @getcartwheel. Here's a quick look!
#robotics #unreal #maya #blender #AI
Our CTO @hongfz16 demoed Xperience-10M dataset+ our wearable capture device at #Singapore AI & Robotics Demo Night last night!
Packed room. Sharp questions. The physical AI data bottleneck is real — and we’re solving it.
#PhysicalAI#EmbodiedAI#Robotics
Xperience-10m is living up to the hype! 🚀
The level of detail here—from human skeleton data to intricate dexterous interactions—is exactly what's needed to move Physical AI forward. If you're training robots or working on embodied AI, don't sleep on this dataset.
Leverage your training today!
#Robotics #AI #HuggingFace #EmbodiedAI #Xperience10M
The AI doc comes out today!
Made by the folks who made “everything everywhere all at once”, it captures the AI zeitgeist better than anything I’ve seen.
Showing in theatres across the US, go see it! @theaidocfilm
🚀 Unitree open-sources UnifoLM-WBT-Dataset — a high-quality real-world humanoid robot whole-body teleoperation (WBT) dataset for open environments.
🥳Publicly available since March 5, 2026, the dataset will continue to receive high-frequency rolling updates. It aims to establish the most comprehensive real-world humanoid robot dataset in terms of scenario coverage, task complexity, and manipulation diversity.
👉 Explore the dataset here: https://t.co/8RpMI4qsGG