An RL library designed to be a perfect companion for supporting your (deep) RL research, fully compatible with other libraries, e.g. @pytorch and @openai gym.
Grateful to my amazing PEARL team @TUDarmstadt and @Hessian_AI, my collaborators and mentors—this achievement wouldn’t have been possible without you!
Looking forward to pushing the boundaries of robotics research together! 🤖🚀 #ERC#Research#Robotics#AI#SIREN
(3/3)
SIREN aims to advance #RoboticIntelligence and interactive #learning, introducing a novel holistic modeling of robot and environment that will revolutionize algorithmic developments for embodied AI.
(2/3)
🚨Beyond happy and deeply honored to share that my project, Structured Interactive Perception & Learning for Holistic #Robotic Embodied #Intelligence (SIREN), has been awarded an #ERC Starting Grant! 🎉🤖🧜♀️A massive thank you to the @ERC_Research for believing in my vision (1/3)
LocoMuJoCo natively supports MushroomRL!
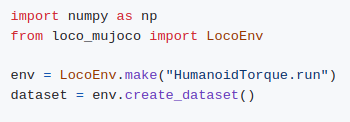
It is extremely easy to create a MushroomRL environment and test it with Mushroom-based implementations of state-of-the-art Inverse Reinforcement Learning algorithms!
https://t.co/tVWoF7EsMv
Introducing LocoMuJoCo, the first imitation learning benchmark tailored towards locomotion! It comes with a diverse set of environments ranging from musculoskeletal models to the brand-new @UnitreeRobotics H1 robot, and also many motion capture datasets!
https://t.co/EAYIjjh23d
As we break the interface for the 2.0 version, we plan to support MushroomRL 1.X with bug fixes for the following years.
If you find any problems in the 1.10 release let us know in #GitHub
MushroomRL 1.10 is out!
Now with video recording functionality, improved MuJoCo interface and viewer, and much more!
This is the last release of the 1.X series of MushroomRL.
Stay tuned for MushroomRL 2.0! We have big updates and major improvements coming!
We look for enthusiastic students that want to perform exciting research in interdisciplinary topics!
See more information about the iROSA group and application details through https://t.co/hzfHx4LujU
Please note the topics you are mostly interested in your application.
(3/3)
- 3D Vision and Neural Representation Learning for Scene-Object Affordance prediction
- Human behaviour understanding, and uncertainty quantification
-Safe and Explainable physical #HumanRobotInteraction (e.g., handovers, etc.)
(2/3)
The iROSA group @CS_TUDarmstadt @Hessian_AI offers multiple Ph.D. positions in the following exciting topics:
- Geometric and Physics-Aware #RobotLearning
- Lifelong Explainable #RobotLearning with pretrained multimodal models (co-supervision with @CarloDeramo)
(1/3)
We warmly welcome @CarloDeramo, new professor for Reinforcement Learning and Computational Decision Making! His goals include to teach #RL systems multitasking and transfer learning. Alumnus @TUDarmstadt@polimi@UICnews ➡️https://t.co/kiWt0aKQVb
For more details about the competition, see the webpage and technical documentation.
https://t.co/22TuBpdpRj
https://t.co/in4UCMMyNY
This competition was made possible by @liu_puze , @davide_tateo , @n_w_funk , @Jan_R_Peters and @Huawei! [3/3]
Open positions alert!
The iROSA group @CS_TUDarmstadt @Hessian_AI is currently looking for motivated researchers, interested in Embodied AI #Robotics! Follow the link for more information.
Please retweet :)
#PhDPosition#AcademicJobs https://t.co/O0k6d16SiL