NEW AI CUSTOMER BUYS 3,000 HOURS OF NATIX DRIVING DATA 🚗
We've signed a six-figure deal with an AI lab pioneering general world models. Real demand for DePIN on @solana.
Not a research collab. Not a free dataset. A paying customer.
Tesla's new robotaxi safety page counts 3.1M autonomous miles 🚕
The split says more than the total: 862K after dark, 113K in rain, 575K in rush hour.
Miles only count for the conditions they cover. Night, rain and traffic are where driving data earns its keep 🌧️
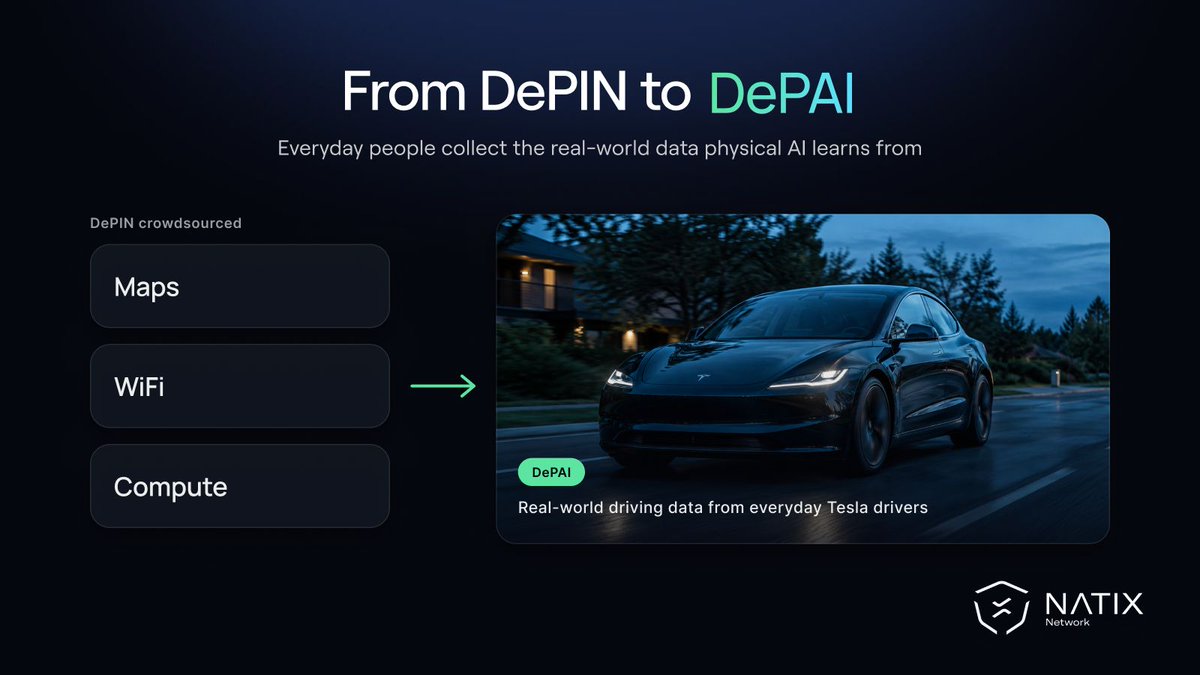
DePIN taught crypto to crowdsource maps, WiFi and compute.
DePAI points the same idea at physical AI: everyday people collect the real-world data robots and self-driving cars learn from, and get rewarded for it.
NATIX drivers do it with the cameras built into their Teslas.
KITTI came out in 2012 and gave self-driving research its first shared benchmark 🏁
BDD100K, nuScenes and Waymo Open followed. Today's world models need more than they were built for: recent multi-camera video from many places.
What they taught us 👇
https://t.co/SSKIOm4gxe
Goldman Sachs puts general-purpose robots about where self-driving was in 2017 or 2018 🦾
Its estimate: they’ll need around 10 million hours of high-quality physical interaction data.
Self-driving learned this first. The models got good once the real-world data caught up.
@CivicNodeX Good catch, thanks! 207K+ is the current figure: hours of multi-camera footage collected as of the end of October.
The 220,000 in the Oct 28 article was an error, and it’s now corrected to 207K+.
October was the month demand showed up 📈
A 3,000 hours data sale to a world model lab, over 931M $NATIX burned in total, and the VX360 Desktop App open beta live in the U.S.
Our October recap is here 👇
https://t.co/89sQZRnrFM
The real line between ADAS and L4 is not capability. It is who catches the mistake when the model is wrong.
Answer that and the training data question mostly answers itself.
Full breakdown on coverage, labels and edge cases 👇
https://t.co/wR07LQVTxP
More world models, more demand for real driving data 📈
This week Rivian bought Third Dimension to turn real footage into 3D worlds, and Baidu is about to reveal its own world model.
Whoever builds the model needs the footage. NATIX has over 200,000 hours of it.
Autonomous driving shouldn’t be locked inside a few companies 🔓
The Autoware Foundation builds open-source self-driving software, backed by members like AMD, AWS and Arm.
As a Premium member, NATIX supplies multi-camera data for Autoware’s open-source end-to-end model 🤝
Over 200,000 hours of driving footage, and none of it came from a test fleet 🚗
It was recorded by drivers in the NATIX network, on their everyday routes.
That’s the network behind every dataset, partnership and world model NATIX powers 🌍
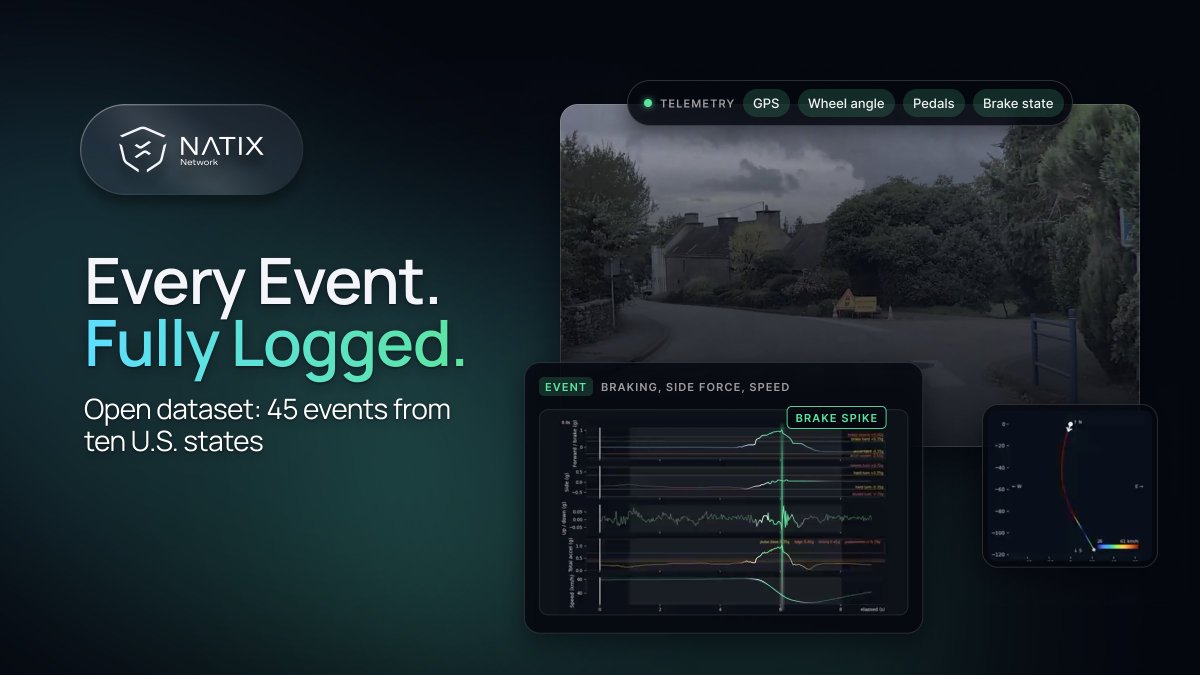
Video shows what happened. Telemetry shows what the driver did.
Our Safety-Critical Driving Events Dataset has both: GPS, wheel angle, pedals and brake state, 45 events in ten U.S. states 🛑
Working on ADAS or world models? It’s on Hugging Face.
https://t.co/wafjBvF8aj
More data from the same city won't teach a model how another city drives.
Two quick headlight flashes mean thanks in Hungary and a warning in Italy. Same signal, opposite meaning 💡
Why validation data has to come from roads a model has never seen 👇
https://t.co/kzf9QUI4G0
Driving video is just storage cost until you can find the moment you need.
With VLMs, NATIX can search its multi-camera data in plain language: describe a scene and get the matching clips.
Hours of manual review become a query that takes seconds 🔍