Humanoid parkour on unseen, extremely challenging terrains... even replicating Boston Dynamics-style moves? 🤖
Introducing TTT-Parkour: A Real-to-Sim-to-Real framework enabling robots to master stakes, beams, and wedges in under 10 minutes! ⏱️
🌐 Project: https://t.co/6pxjL59YGl
🤖✨Excited to share our new work:
OMG: Omni-Modal Motion Generation for Generalist Humanoid Control
What if a humanoid could understand intent from language, music/audio, human motion, or their combinations—and turn it into executable whole-body motion in real time? [🧵1/11]
Flexible Locomotion Learning with Diffusion Model Predictive Control
Excited to share that our paper has been accepted to #ICRA2026@ieee_ras_icra!
A diffusion-planning framework for flexible real-world quadruped locomotion. Instead of learning a fixed RL policy or relying on hand-crafted dynamics for MPC, we train a diffusion trajectory prior that jointly predicts future states and actions.
Key Ideas:
Diffusion-MPC: A diffusion planner unlocks flexible locomotion through test-time reward and constraint adaptation
Interactive reward-weighted finetuning enables continual behavior refinement from online environment feedback
Real-world deployment on Unitree Go2 with efficient and adaptive planning
The same planner can adapt at test time to height changes, posture/joint constraints, balancing under external disturbances, energy-aware locomotion, and zero-shot outdoor walking on grass and slopes.
🌐Homepage: https://t.co/TSXUZAL5nT
📖Paper: https://t.co/de4dUZf5AA
🔗Code: https://t.co/NLFB1alhWJ
This work is by @RunhanH, Haldun Balim, @hankyang94 , and @du_yilun.
#ICRA2026 #Robotics #LeggedRobots #RobotLearning #DiffusionModels #MPC #MachineLearning
We believe robots need instinct, not only reasoning.
Introducing Project-Instinct — a full-stack, instinct-level whole-body control toolkit for legged & humanoid robots.
🔗 https://t.co/F7xRVdUrxP
(1/3)
• Edge-Aware Safety: Novel volumetric edge penalization prevents slipping on terrain edges.
• Extremely dynamic: Robust traversal at up to 2.5 m/s!
• Open-sourced: All codes for training, deployment are open-sourced!
👇 Check out the project page!
https://t.co/Xs4iqy6qAu
🚀 Hiking in the Wild: A Scalable Perceptive Parkour Framework for Humanoids!
Excited to release our latest work! We push the boundaries of humanoid agility in unstructured environments.
Highlights:
• Zero-Shot Sim-to-Real: No mapping, no external state estimation.
🚀 VR-Robo: A Real-to-Sim-to-Real pipeline for RGB vision-based navigation & control in legged robots.
💡 Reconstruct realistic indoor scenes using RGB
🧠 Train RL policies with photorealistic simulation
🤖 Deploy directly on real visual robots!
🔗 https://t.co/2CGgxIUPEZ
🧠+🐶 = Terrain Navigation
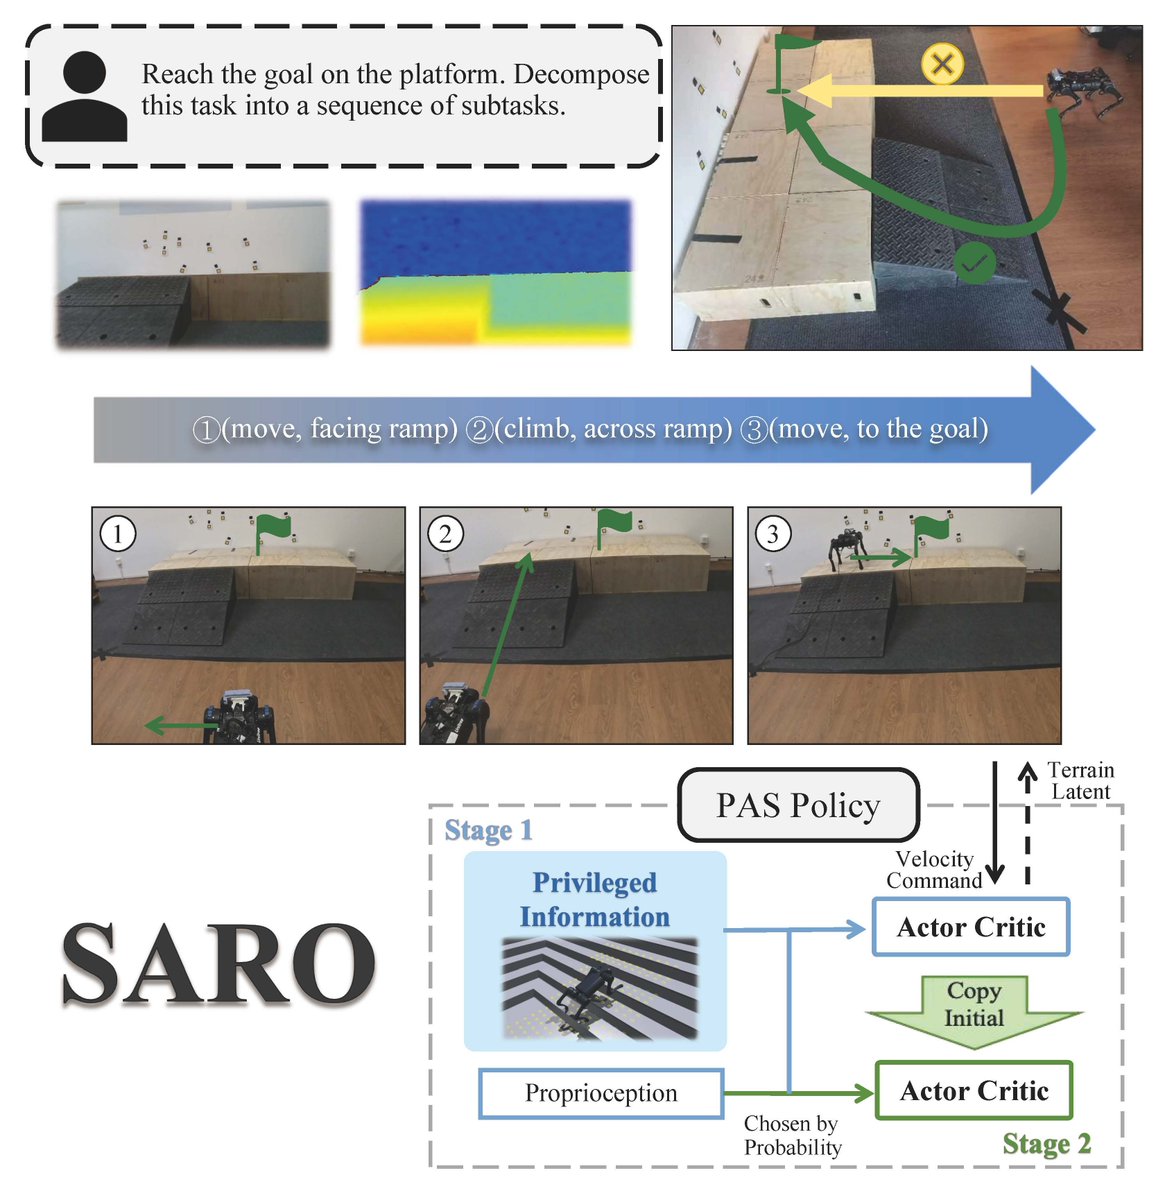
Introducing SARO: a Space-Aware Robot System that combines Vision-Language Models and RL-based control for robust quadruped navigation in 3D terrains 🌄
Catch us at Thursday 15:15pm at Room 309
👉 https://t.co/uBX6uE6iL0
④/④
We design a new Tiny Trap Benchmark in simulation, which consists of a 5m×60m runway and different tiny traps on it. Robots begin on the left side and must pass through tiny traps to reach the goal on the right side.
🚨 New work at #ICRA2025!
Robust Robot Walker 🐾
We enable quadruped robots to pass tiny traps (bars, pits, poles) using only proprioception – no cameras, no depth!
Catch us at Thursday 16:55pm in Room 305!
🔗 https://t.co/571p4xTJ5c
③/④
During deployment, our policy achieves approximate omnidirectional movement by joystick commands without motion capture or other auxiliary localization techniques. A joystick is used to generate fake goal commands, consisting of constant values for Δ𝐺 and Δ𝑡.
②/④
We use explicit-implicit dual-state learning. The contact force is first encoded by a contact encoder to an implicit latent, and concatenated with explicit privileged state to the dual-state. In addition, we introduce a classification head to guide the policy in learning.
Enjoy generalizable robot segmentation and plug-and-play visual augmentation🥳!
RoboEngine enables visual generalization and robustness in almost all scenes with data collected from just one scene! The simplest idea, but useful and effective😂.
https://t.co/AdiNPIrihi