1/ Three years in chip design, five years in software engineering - I’m moving into robotics now.
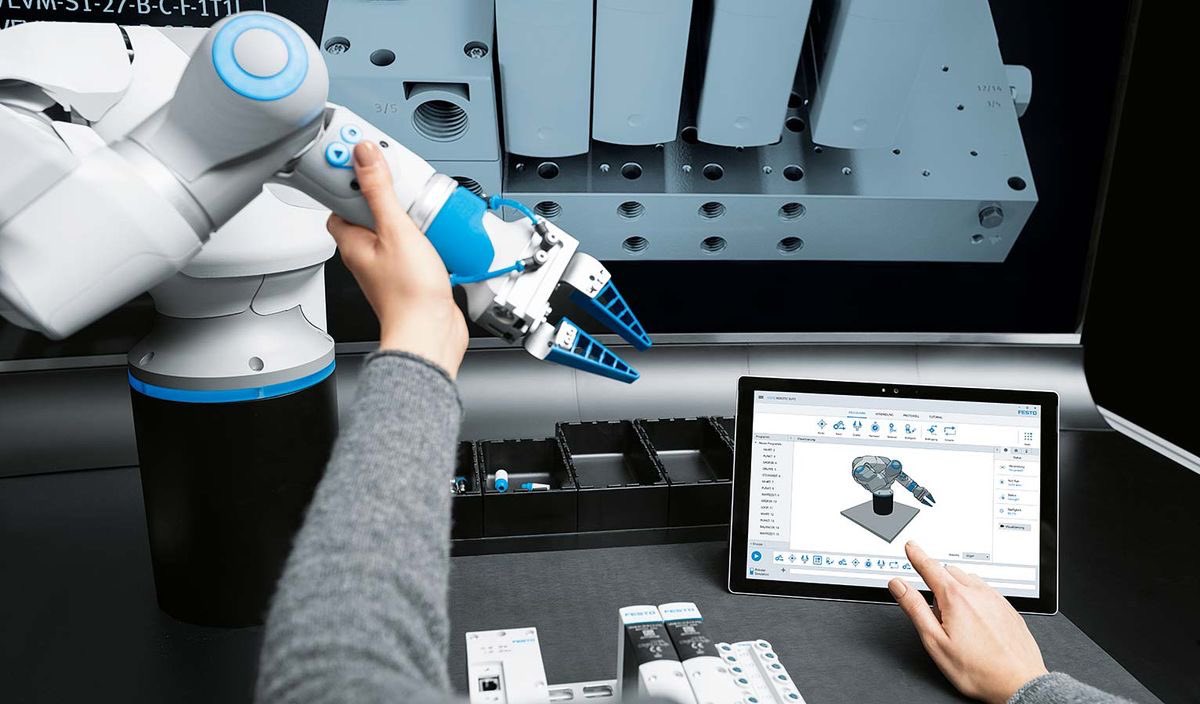
The video is a SO-101 5-DOF arm with an unknown weight in the gripper. It identifies the mass first, then tracks using it.
6/ So hardware identifies mass at rest from motor current, calibrates, freezes, then tracks.
90 g → 83 g. 180 g → 176 g.
Green is that estimate. Orange is uncalibrated — worse than none.
vs empty-model CT: arm RMS −31% / −45%.
how to get started in modern robotics:
don’t learn robotics like it’s 2015.
the stack has changed.
• math first → linear algebra, calculus, probability, optimization. robotics becomes much easier when the math stops looking mysterious.
• python + c++ → python for experimentation and ai, c++ for performance and real-time systems.
• ros2 → nodes, topics, services, actions, tf2, urdf. learn how an actual robot software stack fits together.
• simulation → mujoco, isaac sim, gazebo. build robots, destroy them, reset, repeat.
• control + estimation → pid, mpc, kalman filters, sensor fusion. intelligence is useless if the robot can’t control its own body.
• perception → cameras, lidar, radar, depth sensors. then learn cv, detection, tracking, slam.
• planning → a*, rrt, trajectory optimization, motion planning. perception tells you what exists, planning decides what to do.
• robot learning → imitation learning, reinforcement learning, vision-language-action models, world models.
• data → logging, replay, labeling, evaluation, synthetic data. modern robotics increasingly lives or dies by the quality of its data.
• hardware last → motors, encoders, actuators, batteries, embedded systems, mechanical design. now make everything survive reality.
then build one complete robot.
sensor → perception → state estimation → planning → control → actuator → feedback.
modern robotics isn’t one discipline.
it’s ai + software + math + control + hardware + physics, integrated into one machine that has to work in the real world.
Having firsthand experience building lock-and-mint bridges, I fully understand the severity of this risk. A bug like this on one chain could easily have cascaded across the entire ecosystem through traditional mint/burn bridges.
This is exactly why we need more designs like Agglayer that isolate chain risk with pessimistic zk proofs.
An arbitrary state write bug in Aptos chain was disclosed by @hexens today.
This is the worst kind of bug possible on a chain.
Why? Not only everything on the affected chain can be stolen but also most assets across all chain can be stolen.
Your stablecoins, LSTs, everything