1/ I built an autonomous rover in my mom's basement completely from scratch.
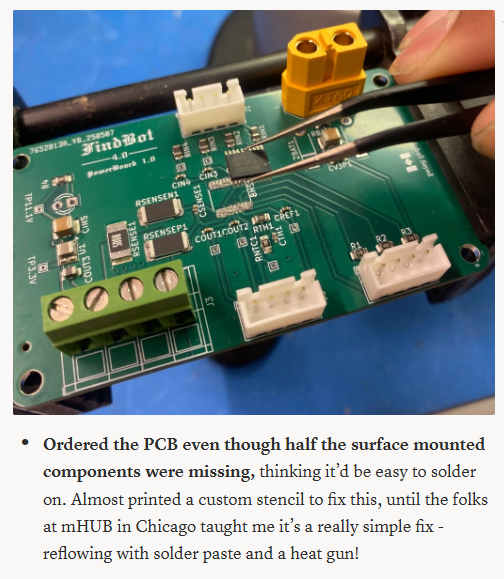
chassis, drivetrain, PCBs, STM32 firmware, controls, inference, all of it.
In this demonstration, it’s controlled by a neural network, trained to push objects into a goal zone (like Ronaldo on wheels).
Here’s everything it took me to bring this rover to life:
@rdotapps The original shunt layout didn’t actually include a Kelvin connection. I never tested those PCBs with any serious current draw - the current shunt layout hasn’t had any problems (yet), the measured current seems to be pretty accurate (from when I testing with a bench supply)!
12/ What's Next (for me)
I graduate Systems Design Engineering at @UWaterloo this month!
DM me if you know any cool teams building in the robotics/Physical AI space that are looking to add engineers! I'm looking for cracked teams to continue building robots at full-time!
Read more about FindBot in the full blog I wrote about it: https://t.co/dOT11AS3WO
11/ What's Next
This was an initial demonstration to prove I could build a robot capable of deploying a learned control policy in the physical world. I want to continue exploring this by:
1) Exploring more capable models (VLAs, RL)
2) Expanding FindBots capabilities, particularly its ability to manipulate and interact with the world (beyond pushing objects)