By day, the World Artificial Intelligence Conference (WAIC)—China’s largest annual AI gathering—puts the country’s AI ecosystem on the world stage.
By night, @Liz_LizLi and I from Research AI+ bring some of the researchers, engineers, open-source builders, and founders shaping its next chapter into a smaller room.
Together with our partners and friends — Rednote @xiaohongshu , Vitalbridge, Shanghai Engine Community, Monolith, Zhihu @ZhihuFrontier , and Shanghai Foundation Model Innovation Center—we’re bringing this Shanghai after-hours series back for a second year.
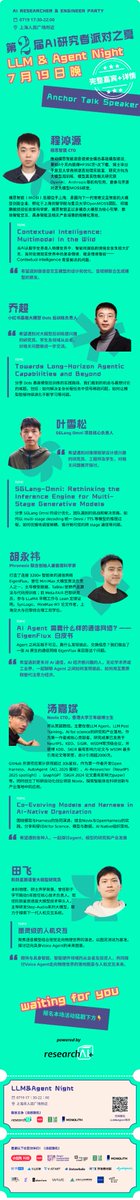
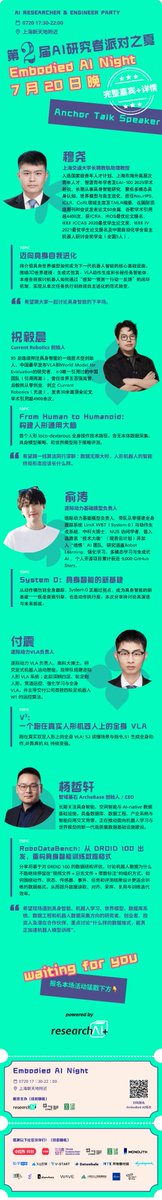
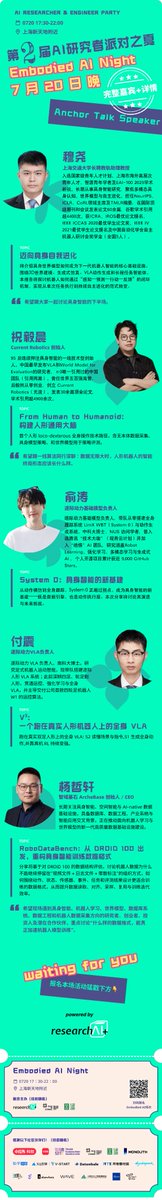
The 2nd AI Researcher & Engineer Summer Party during #WAIC2026 brings together 16 speakers working across three frontiers:
🧬 AI for Science Night: vibe-coding cells, protein R&D agents, embodied AI scientists, brain–AI interaction and and trusted autonomous life-science discovery powered by foundation models and scientific agents.
🧠 LLMs & Agent Night: multimodal intelligence in the wild, long-horizon agents, SGLang-Omni, agent communication networks, co-evolving models and harnesses—and Turing-level human–machine interaction through voice AI.
🤖 Embodied AI Night: self-evolving embodied intelligence, general-purpose humanoid brains, System 0, robot training-data formats, and whole-body VLAs running on real humanoids.
Three curated nights—not another formal forum or mass-networking mixer, but a closer look at what some of China’s most interesting AI builders are actually working on.
Meet the full lineup 🧵👇
How bidirectional + causal pretrain backbones can be reused to build domain-specific worlds (e.g., scientific sims, robotics, social sandboxes) without training from scratch🤔
🌍 What if an AI-generated world didn’t end after a few seconds—but kept running for hours, responded to every move, let you attack, cast spells, shoot, or summon storms, and continued evolving through AI agents?
That’s LingBot-World 2.0: our open-source real-time interactive world model, scaling to 720p/60fps in our full setup.
Today, we’re open-sourcing 3 more models:
🔹 LingBot-World 2.0 Small (1.3B)
🔹 LingBot-World 2.0 Bidirectional
🔹 LingBot-World 2.0 Causal Pretrain
And now, with our 1.3B Small Model, that world can run in real time on a single consumer GPU. 🧵
@robbyant_brain Once a 1.3B model can run this in real time on a consumer GPU, it stops being just a cool video and starts looking like infrastructure for new kinds of sims, games, and research environments. Thanks for releasing!
@ScaleAILabs You’re not trying to “build RSI in the wild”, you’re trying to operationalize and measure the prerequisites of recursive self‑improvement: autonomous experimentation, self‑critique, and iterative refinement under fixed compute and guardrails.
Thanks for joining us these three nights 🍻— loved having the Zhihu Frontier team in the mix of researchers, engineers, open‑source builders, and founders👏
During #WAIC2026, we joined a three-day evening event for AI researchers. 🍻
Huge thanks to the Researcher AI+ Community for the invitation—it's a pleasure spending these inspiring nights together! #AI#Tech
July 18–20 · Shanghai
🚀🚀🚀For researchers and engineers who want sharper ideas, honest conversations, and people worth staying in touch with.
Research AI+, a non-profit community for young technologists—now 1000+ members globally including AI researchers, engineers, devs and builders—across academia, big tech, and startups. 🚀
https://t.co/I9QHoXC4tb
By day, the World Artificial Intelligence Conference (WAIC)—China’s largest annual AI gathering—puts the country’s AI ecosystem on the world stage.
By night, @Liz_LizLi and I from Research AI+ bring some of the researchers, engineers, open-source builders, and founders shaping its next chapter into a smaller room.
Together with our partners and friends — Rednote @xiaohongshu , Vitalbridge, Shanghai Engine Community, Monolith, Zhihu @ZhihuFrontier , and Shanghai Foundation Model Innovation Center—we’re bringing this Shanghai after-hours series back for a second year.
The 2nd AI Researcher & Engineer Summer Party during #WAIC2026 brings together 16 speakers working across three frontiers:
🧬 AI for Science Night: vibe-coding cells, protein R&D agents, embodied AI scientists, brain–AI interaction and and trusted autonomous life-science discovery powered by foundation models and scientific agents.
🧠 LLMs & Agent Night: multimodal intelligence in the wild, long-horizon agents, SGLang-Omni, agent communication networks, co-evolving models and harnesses—and Turing-level human–machine interaction through voice AI.
🤖 Embodied AI Night: self-evolving embodied intelligence, general-purpose humanoid brains, System 0, robot training-data formats, and whole-body VLAs running on real humanoids.
Three curated nights—not another formal forum or mass-networking mixer, but a closer look at what some of China’s most interesting AI builders are actually working on.
Meet the full lineup 🧵👇
💡Night 3 — Embodied AI
• @YaoMarkMu1 — Yao Mu, Shanghai Jiao Tong University
“Toward Self-Evolving Embodied Intelligence”
• Yichen Zhu — @Curr_Robotics
“From Human to Humanoid: Building a General-Purpose Brain for Humanoids”
• Tao Yu — @LimX_Dynamics
“System 0: A New Foundation for Embodied Intelligence”
• Zhen Fu — @LimX_Dynamics
“V³: A Whole-Body VLA Running on a Real Humanoid Robot”
• Zhexuan Yang, ArcheBase
“RoboDataBench: Rethinking Training-Data Formats for Embodied AI, Starting with DROID-100”
Forward to who are (re)entering the ML job market in industry. A journey from a ML PhD to a Research Scientist role (eventually joining DeepMind), covering the whole funnel: getting interviews, choosing between startups vs big tech, interview structure and prep (technical, emotional, logistical), negotiation, and final decision‑making.
After interviewing for Research Scientist roles at DeepMind, Isomorphic, Meta, Cohere and more, I wrote up everything I learned. Technical prep, logistics, negotiation, and emotional breakdowns. Check out my guide: https://t.co/eLh20ggMHW
#CVPR2026 makes one question feel especially timely:
What actually counts as a world model?
Research AI+ recently co-hosted a closed-door roundtable on world models. I joined in person and edited the transcript + synthesis.
The participants remain anonymous, but the perspectives were rare: young researchers, engineers, and tech founders from China working across robotic manipulation, autonomous driving, generative model evaluation, AI infra, 3D generation, and early-stage tech investing. @Liz_LizLi
A few ideas from the discussion:
1. Action may be the real boundary. A model that only rolls video forward is not the same as an action-conditioned world model.
2. The main approaches already look quite different. Sora-like generative models, JEPA-style latent representation learning, and 3D-first spatial intelligence are not solving the problem in the same way.
3. The architecture debate may become an efficiency debate. The question may not be which approach looks more elegant, but which one compresses the useful structure of the world under real latency, compute, and deployment constraints.
4. Benchmarks may be the real bottleneck. For embodied AI, evaluation still feels too much like “Edison testing filaments.” Maybe good world-model benchmarks should behave more like games than exams.
5. Test-time scaling in robotics may not mean “the model thinks longer.” It may mean the robot acts, receives new observations from the world, and uses those observations to reduce uncertainty.
6. The GPT-3 moment for world models will probably not be a prettier demo. It will be real few-shot behavior in robots.
7. The bottleneck in embodied intelligence may not be the model. It may be the missing data flywheel. Ego-view data scaling may be one of the few paths that still looks plausible.
Full article below.
So which path is most likely to scale first?
Video world models, latent world models, 3D spatial intelligence?
@Vtrivedy10 I’m especially interested in the HCI side of this: how we surface eval failures back to builders and even end‑users in a way that builds trust instead of fear, and how communities of users can co‑create evals from their own traces.
@haotian_yeee Very curious how far this evaluation-first perspective can go for more “open-ended” scientific problems (messier objectives, human-in-the-loop feedback, multi-scale hypotheses, etc.🤔
Turning recursive reasoning into a generative trajectory is a very cool idea, but I do have a question: on these benchmarks, how much of GRAM’s gain is coming from a better inductive bias versus simply a wider search?
Maybe evals aren’t a single “metric” but a co-evolving system:
Read traces to surface concrete failure modes
→ abstract them into reusable evaluators (ideally binary pass/fail)
→ ship to prod and mine fresh blind spots from new data.
Without wiring this into tracing / monitoring / dataset management, it’s hard to truly close the loop — you just end up overfitting to offline benchmarks.🫠 @YuChen_ailearn what do you think?
@HuggingPapers Like the TwinBrainVLA + LangForce idea: dual-brain fusion + physics-grounded training sounds like a nice bridge between vision-language understanding and actual force / dynamics reasoning.