A lot of models are full on text. Robots are starving for trajectories.
One grasp, one force adjustment, one obstacle dodge is a training sample. @axisrobotics runs browser sim tasks, scored on quality, difficulty, and diversity, then signed on-chain.
I'm not shilling robots. I'm watching whether Physical AI's bottleneck actually gets solved with real human data.
Chat AI is short on posts. Robots are short on actions with context. Axis is turning those tasks into a training pipeline, not just another post on @KaitoAI.
@axisrobotics@ManycoreTech Moving beyond pixels into real, world physical interaction is the true milestone for robotics. Great to see Axis Suite providing the crucial physics signals for this ecosystem
The @axisrobotics clip I keep rewatching isn’t the sale.
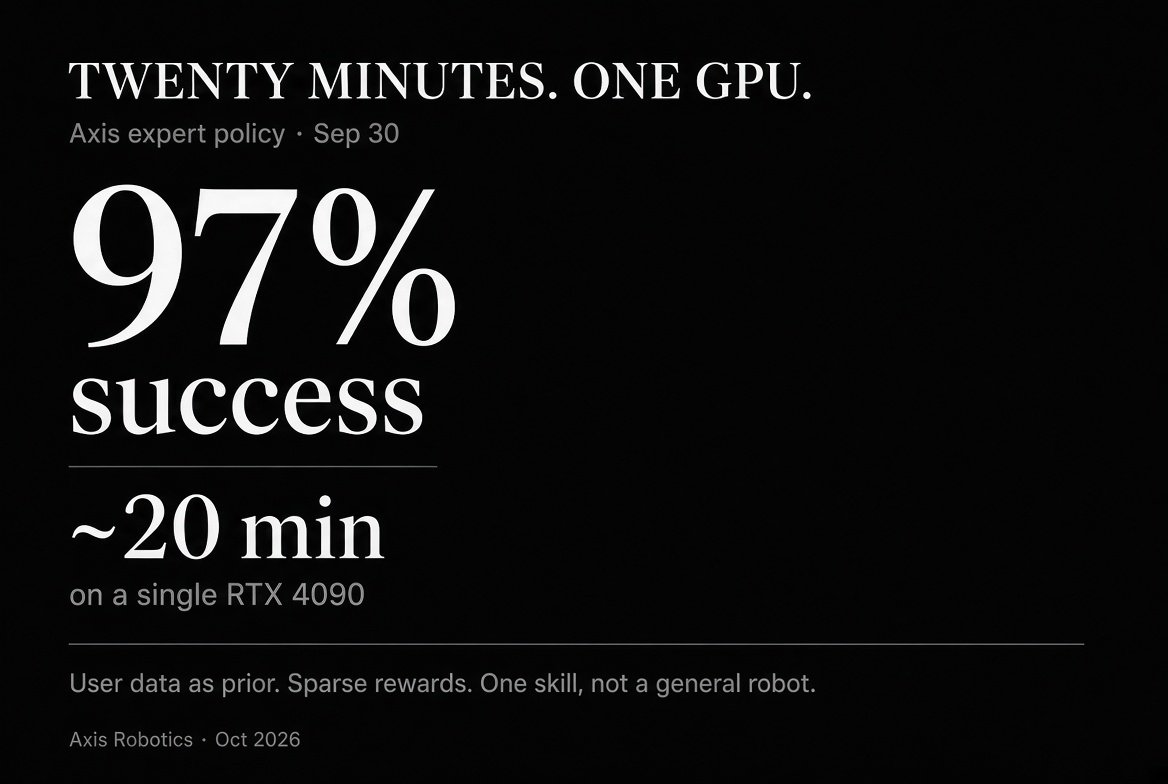
Murphy posted a policy that starts with no idea how to do the task.
Twenty minutes later, on one RTX 4090, it hits 97% and just keeps completing rollouts.
The interesting part is how they get there.
They inject user data as a prior.
Then they use sparse, simple rewards. No reward-model fine-tune. No fancy reward engineering.
That’s a different use of Hub data than “dump trajectories into a giant VLA.”
The crowd prior is there so a cheap expert can stand up fast.
The expert is the thing you compose later.
Caveat.
97% on one task in sim, on one GPU, is not a general robot.
I want the fail cases and whether that expert still works when the object or the scene changes.
But if 20 minutes and a 4090 is the unit cost of a new skill, the bottleneck moves again.
Not more hours of teleop
The new @axisrobotics blog is not "we collected more tasks."
Three results. The middle one is the one I keep turning over.
They trained a small proxy model to score trajectories by utility and coverage.
A filtered subset beat the full pool.
Same idea as the correction work, different layer.
You can have a million valid demos and still be training on the wrong slice.
The other two numbers:
Embodied RSI: the deployed policy generates the data for its next version. 22% → 52%.
Tiny expert models hit near 100% on one skill for about $5–$10 of compute, then get chained.
That last one is the tell.
They are not only trying to grow one giant generalist.
They're trying to grow a library of cheap skills you can compose.
Caveat, because the 22 → 52 line will get screenshotted without context.
I want to know the task family and whether that jump is sim or a real arm. The blog says real-world data from the deployed policy, but it's still worth asking how broad the eval is.
If the proxy result holds, Hub volume matters even less than people think.
The scarce thing is a score for "does this trajectory cover something the model still lacks."
✨ So, @axisrobotics has successfully completed its pre-sale, and what happened afterward seems to line up with the “conspiracy theory” the Axis team had been hinting at throughout the ICO.
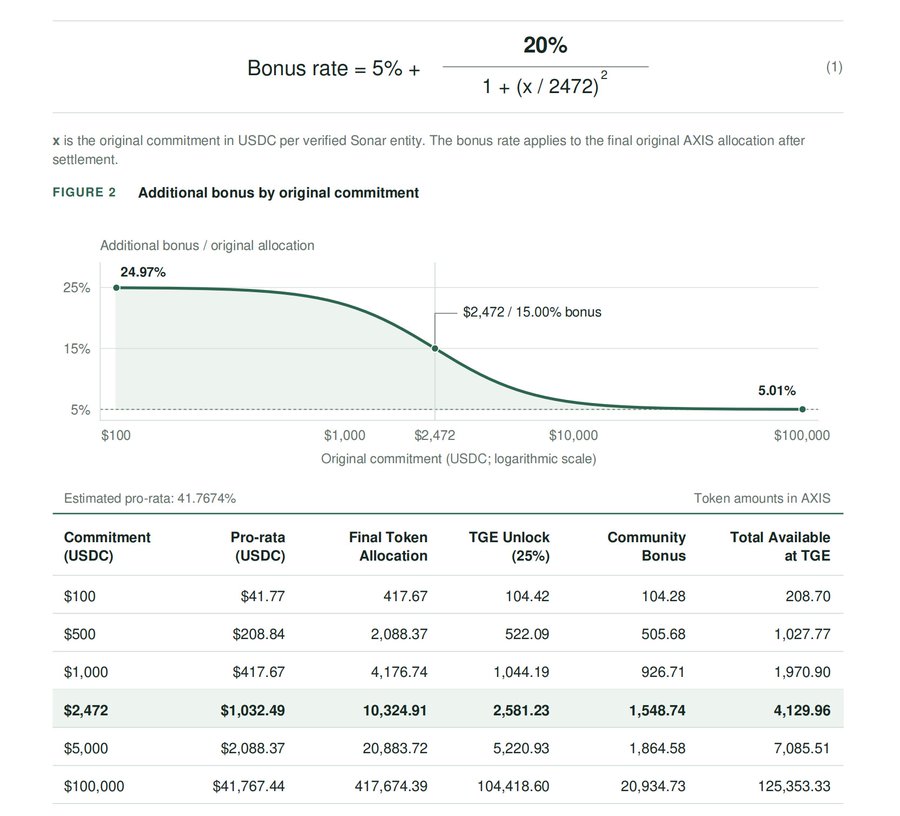
🔸 Buyers will unlock 25% at TGE, instead of the previous 10%.
🔸 Buyers will also receive additional bonus tokens, which will be fully unlocked at TGE. You can read the details of the bonus token plan below.
This means ICO participants now have a much better chance of breaking even at TGE.
To be honest, the Axis team clearly understood that, given the current market conditions, it would have been difficult to sell out under the original terms. In a way, this was also a test for those who genuinely believe in the project and want to stay in it for the long term.
♻️ But to be fair, apart from the team itself, loyal supporters, and those who are willing to take risks and believe in the “conspiracy theory,” I think it would have been difficult for people like me, who are relatively neutral and have limited information, to take the risk. Staying on the sidelines was simply the safer choice.
@lon_rong14459@axisrobotics This is a really important shift: from collecting more data to collecting the right data. The model itself can help reveal where new data creates the most value
Most @axisrobotics posts stop at “complete tasks, earn points.” The actual product is the data engine behind the Hub.
TaskGen generates collectable tasks instead of a frozen quest list. Complex manipulation gets broken into reusable atomic skills (grasp, place, push, rotate), then recomposed. Recent work: cleaner single-scene derived tasks, auto-resized grasp objects, articulated coverage (drawers, cabinets, appliances), dual-arm, basket put-in/take-out. That’s how you scale diversity without hand-authoring every scene.
Axis V2 / Human-Gated DAgger attacks the classic BC problem: compounding error grows with horizon. Policy runs first. Humans gate only when it drifts. Correction segments are filtered for closed-loop impact, not dumped raw. Round 2: 68/160 → 78.3/160 average across seeds. HG-DAgger candidates +4–7 vs source. DreamZero is now in the finetune path.
That’s also why Kaito Epoch 2 referrals are strict: multiplier needs signed trajectories, not link clicks.
If you’re entering this epoch through this track:
https://t.co/9F1NtqjJJv
Then do one real trajectory on https://t.co/CowvmvHKh1 you can write from the loop, not from a banner.