π0.7 from @physical_int was built for robot arms, but with just 1.5 hours of driving data, it drove a real Tesla through multiple cone courses and topped our benchmark. 🚗
I think most people wouldn't expect a VLA/WAM to drive a car at all. Not only are these models pretrained primarly on teleop / egocentric data for (bi)manual style tasks, our action interface is [curvature, speed], which is out of distribution compared to the typical DoF of an arm or gripper. But we fine-tuned 6 of them, and every one was able to drive the Tesla.
See more on our site!
hiring a GM for research ops! looking for someone who can manage managers, build great teams, solve hard problems, and create systems that absorb complexity.
must also be fun. we're going to spend a lot of time together 😇
https://t.co/vacSjhN7As
The Pi API is officially in beta! 🤖
Many people have already been using it to fine-tune π models for their robots -- below are a few
We’re hoping to expand testing significantly. Let us know if you are interested!
Blog: https://t.co/JBTahDOmg7
Signup: https://t.co/pIVpvdGxCN
Announcing the beta release of the Pi API. We’ve partnered with companies across diverse industries to adapt our models to their robots and applications, from harvesting strawberries to assembling servers. Now we’re opening access to more teams.
Congrats to @Ultraroboticsco on the raise! 🚀
Ultra and Pi have been working together to bring our models into real warehouses. We've gone from training ~1 policy per week to 8+, and improved autonomous performance from ~60% to ~95%.
Really cool to see how quickly things can improve when you're iterating on models with real-world robot data.
Robots can already fold laundry, make espresso, clean kitchens, and assemble things. The harder problem is getting them to do those tasks reliably, for long periods of time, without a human babysitting them.
At Startup School 2026, @physical_int cofounder @chelseabfinn explains what it takes to build general-purpose robots that work in the real world.
She shares how reinforcement learning pushed robot throughput up 2x, how their systems can run autonomously for hours, and why she believes robotics is entering its GPT era: moving from specialized models toward general-purpose systems that can work across tasks, robots, and environments.
00:00 — The State of Physical Intelligence
01:23 — What It Takes to Make Robots Useful
05:11 — The Reliability Problem
07:43 — Reinforcement Learning for Robotics
09:35 — Learning From Failures
12:43 — Training Robots to Improve Themselves
14:21 — Can a Robot Work for 13 Hours Straight?
17:36 — Why Robots Need Memory
21:22 — Building a General-Purpose Robot
25:02 — From Fine-Tuning to Out-of-the-Box Models
27:35 — Training on All the Data
30:20 — One Model That Beats the Specialists
31:21 — Compositional Generalization
37:49 — The GPT Era of Robotics
39:49 — Q&A
we’re hiring for three ops roles at @physical_int each focused on a different part of scaling robot data collection:
Product Manager
Strategic Projects Lead
Data Annotation Lead
shoot me a note if one sounds like a fit 😎 https://t.co/Wdfl2mcUkL
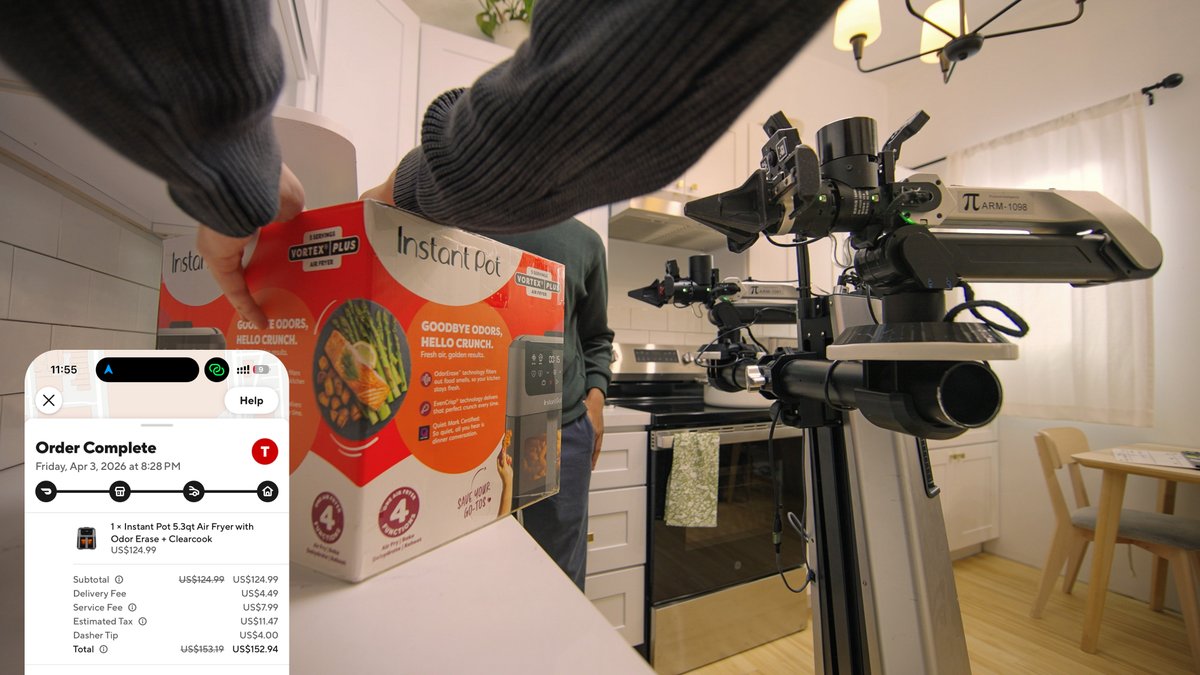
We are especially excited about how π0.7 seems to exhibit emergent compositional generalization: it can put together skills it learned in new ways based on the prompt, for example to figure out how to use an air fryer to cook a sweet potato.
I'm extremely excited to announce that we've successfully inferenced π0.5 on our excavator!
We've collected a massive corpus of real-world data with natural language labels from operators in the industry and are using it to create some really cool policies. Here's our first demo of it successfully completing a task with just 200 trajectories. More on the way :)
Read our blog post: https://t.co/Y5poo1vetf
@physical_int
We’ve developed a memory system for our models that provides both short-term visual memory and long-term semantic memory.
Our approach allows us to train robots to perform long and complex tasks, like cleaning up a kitchen or preparing a grilled cheese sandwich from scratch 👇
new year, new job? we're hiring across many roles: https://t.co/m5w7u7OZ30 -- we're *just* starting to grow out the business side and posted our first business role. this role will be responsible for helping to scale the company and our deployments/partnerships/compute.