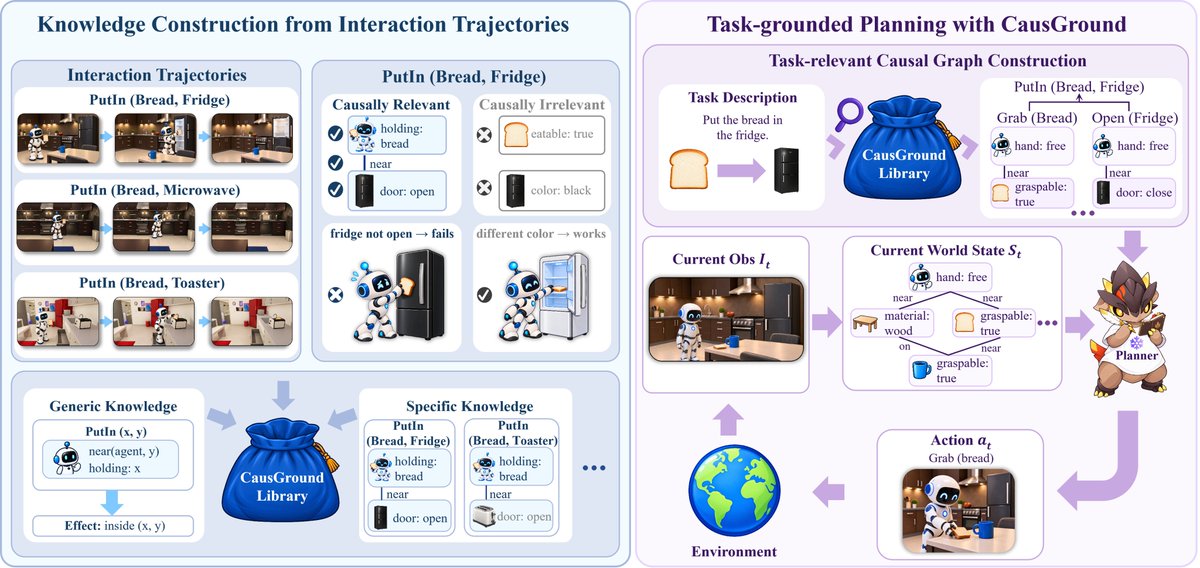
CausGround turns interaction trajectories into reusable action preconditions and effects.
As more data accumulates, it can ground richer causal knowledge in the current world state, helping a frozen planner reason backward over preconditions and forward over effects.
Embodied planning needs to know when actions are executable and what they change.
Introducing 𝗖𝗮𝘂𝘀𝗚𝗿𝗼𝘂𝗻𝗱, our work at BAAI on causal interaction grounding for adaptive planning without model updates.
Paper: https://t.co/V5aW9z70dO
Project: https://t.co/XTYSqvSfbp
Our latest paper, “World Models with Configurable Perception”, explores configurable states as information bottlenecks for robust planning in noisy worlds.
⬇️
Paper: https://t.co/YqvjITUeSp
Web: https://t.co/piXqdM2nhK
Code: https://t.co/6VnlnRnNJe
Data: https://t.co/7J8f74Qsbt
Experimental Results:
1. Task-agnostic representations may retain both task-relevant and irrelevant dynamics, while ConfigWM preserves the task-relevant states according to language queries.
Inspired by the configurator view of autonomous intelligence, we introduce ConfigWM: World Models with Configurable Perception! By using language to configure perception, ConfigWM constructs task-relevant predictive states and learns action-conditioned dynamics for planning.
World modeling needs configurable perception.
A good state should act as an information bottleneck: preserving just enough task-relevant information for planning while filtering out irrelevant distractions.