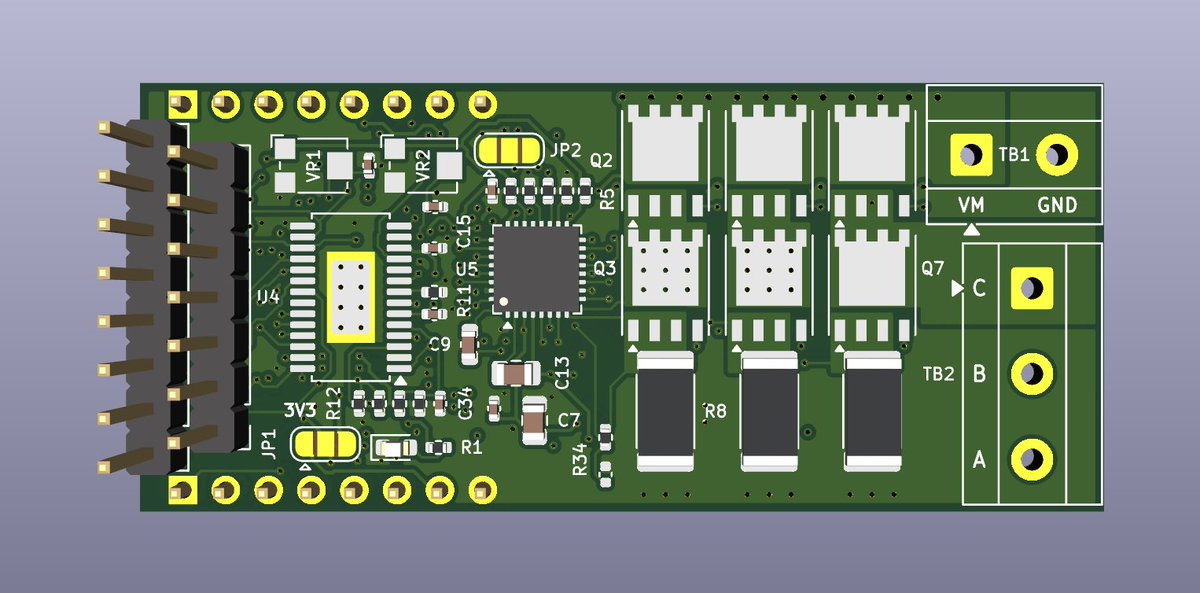
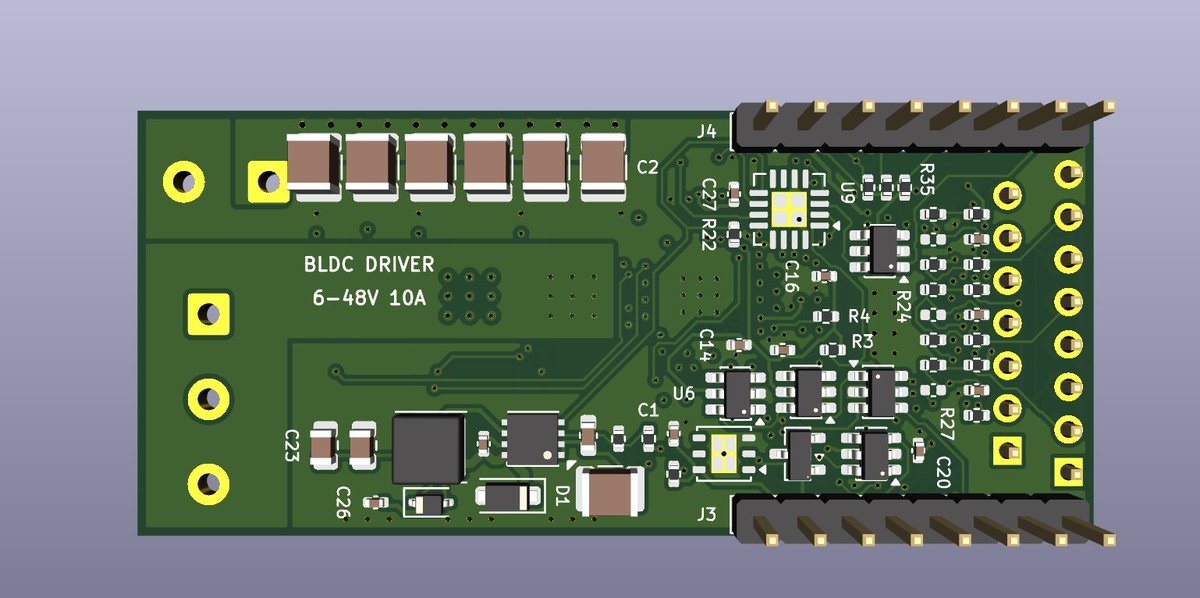
One note. One prompt. Then I went to sleep.
Woke up to Kookabus-06, a 4-layer dual H-bridge motor driver. Claude Code designed it overnight and TraceMaker routed it.
4h 21m, 657 tool calls, 127 parts. KiCad DRC 0. Three independent AI reviews, then 14 fixes before morning. Every assumption it made is written down for me to check.
Not built yet. Kookabus-06 rev 1 is designed, checked and ready to order.
What would you have it build next?
Big news for CAD: SMLIB, NVIDIA's NURBS based kernel is finally open source today 🍻🎉
We have been working with SMLIB and its dev team for more than 20 years. It enables all our products: https://t.co/glvclQnzFt headless CAD, GUI, AI/MCP, PDM, etc
https://t.co/q6hnXDXNdK
(1/5) Everyone says dexterous manipulation needs real-world data. These policies were trained with none. Our robots mesh gears, thread nuts, and insert pegs zero-shot from RGB, and the same recipe works for locomotion across terrains much harder than before.
The missing piece wasn't a better RL algorithm, but a small tweak to what the robot practices.
Today we're releasing Success-Guided Sampling (SGS), a simple change to the task sampler that unlocks new levels of dexterity and agility with large-scale, end-to-end sim2real RL.
No demonstrations, no per-task reward tuning. Just PPO at scale.
Check out the policies yourself at https://t.co/dnwUr0tabh! All videos at 1x speed! 🧵 🔈
The strongest “I’m living in the future” moment was the First Contact demo on the Oculus CV1 in ~2016 and I’ve been chasing it ever since.
Yeah yeah we’ve got AI and self driving cars and stuff now, but it doesn’t hit the same.
Shame that the space kind of fizzled out…but here’s to hoping there’s a resurgence soon.
There’s got to be other technologies that had an extreme “wow future” moment that never panned out. What would your “oculus” moment be in the 90s, 80s, 70s?
Today we give Atlas dexterous hands, with the strength to take on real work, and the simplicity for mass manufacturing. Like the body, the hands are designed with high fidelity simulation in mind, to enable sim-to-real RL. If you give dexterous hands to a robot, make them do dexterous things.
More thoughts here
Blog: https://t.co/z8xNB8KKXV
Video: https://t.co/iETKTwNIXn
Gave Opus 5.5 something a little more complicated, I asked it to layout the PCB for the Mikroe "BRUSHLESS 29 CLICK" which is a BLDC motor driver and it did a great job! It burned 1.28M tokens and took 2 hours and 48 min, but it finished!
The power paths are clearly well thought and planned out. I would say that this design is definitely passable but could use some improvement!
Did some light reverse engineering work on the meta neural band, managed to get it working standalone and reading out EMG and gesture data from my hand
what took Grok 4.7 a whole TWENTY minutes took Opus 5.5 EIGHT minutes and the quality is SO much better. State of the art for electronics right now, possibly better than Astra for schematic capture just w/ speed alone.
Anthropic has cooked
Every new robot hand claims to be the most dexterous. But there's never an objective, useful number behind it.
KaRMA is the first metric to compute a hand's true dexterity using just a kinematic model. (IROS 2026) (1/9)