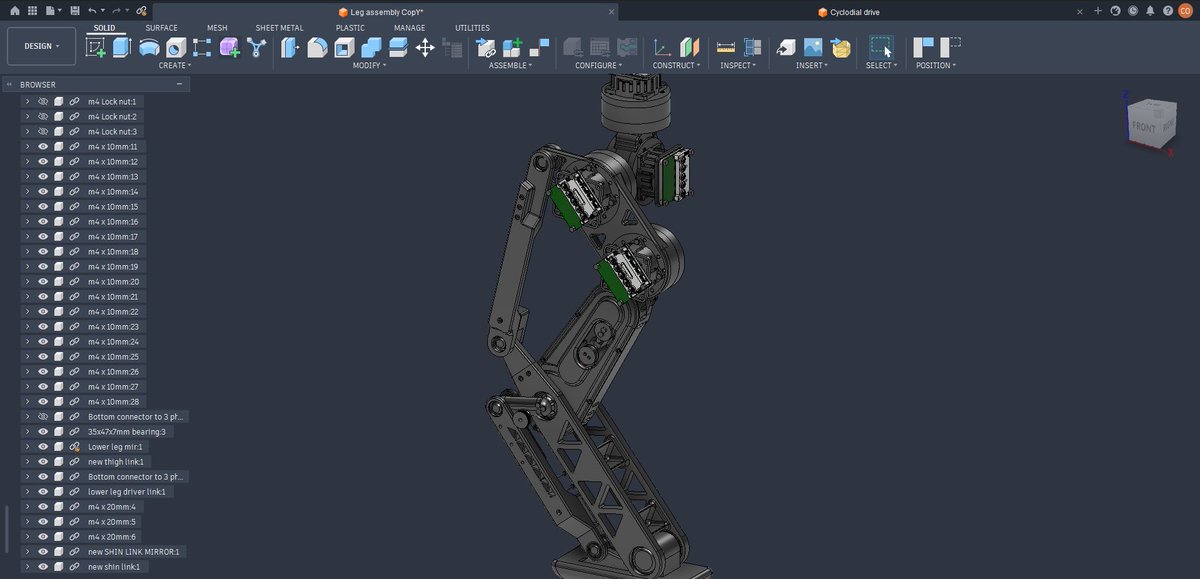
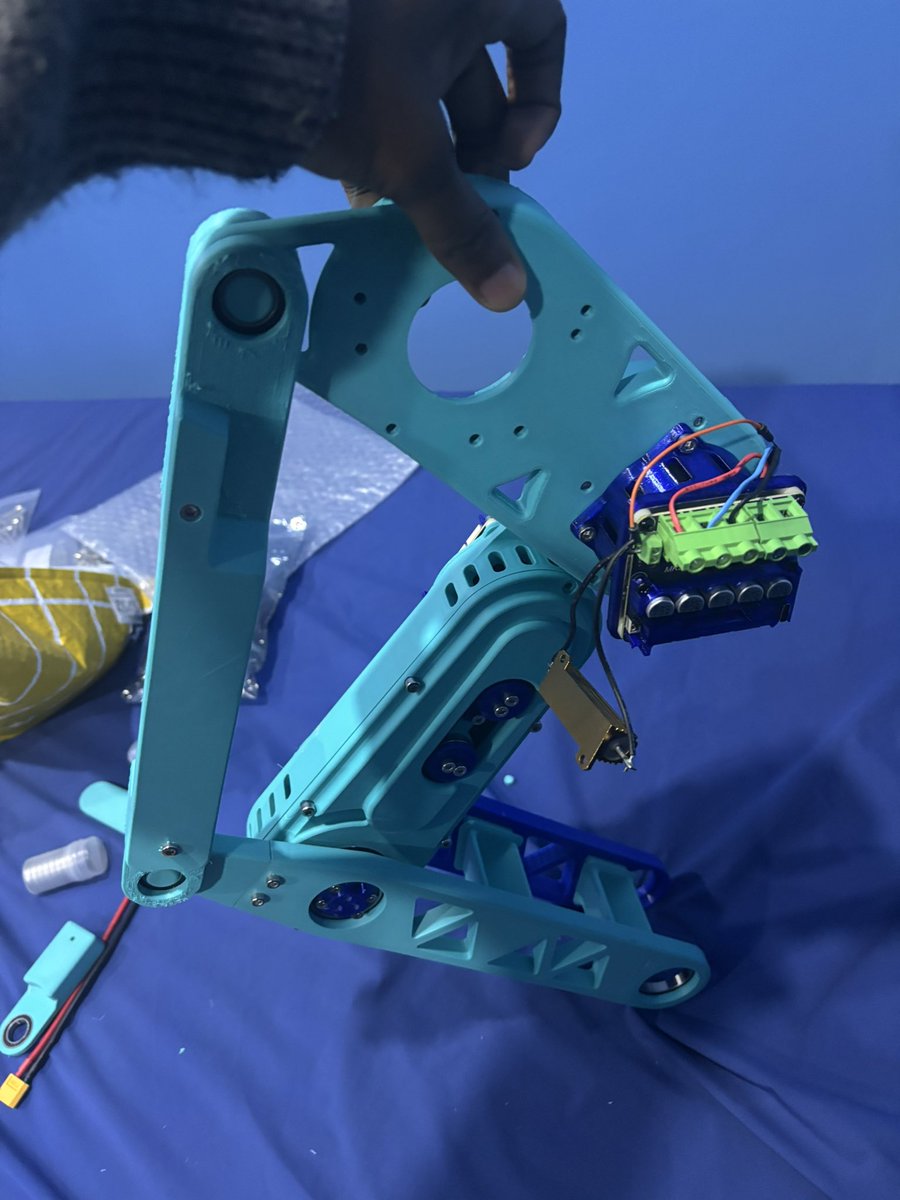
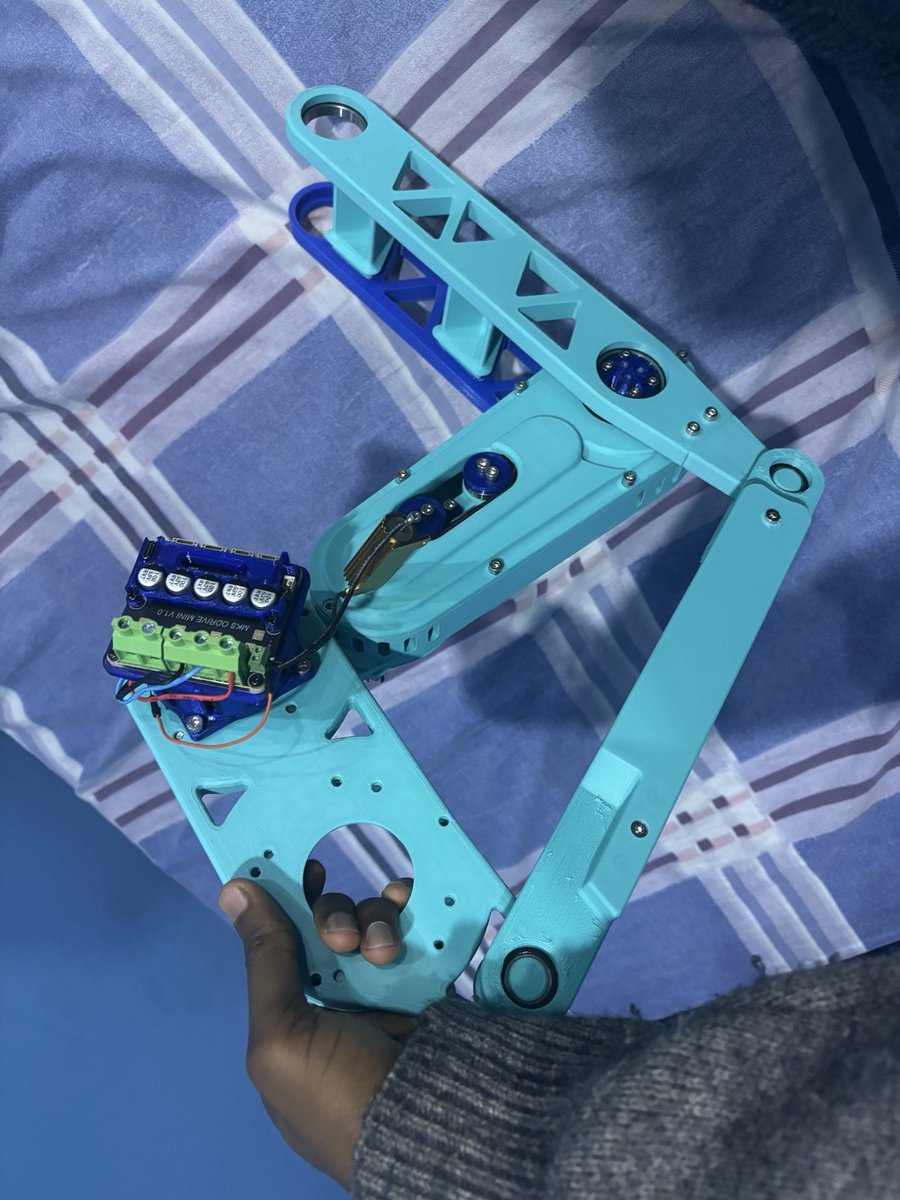
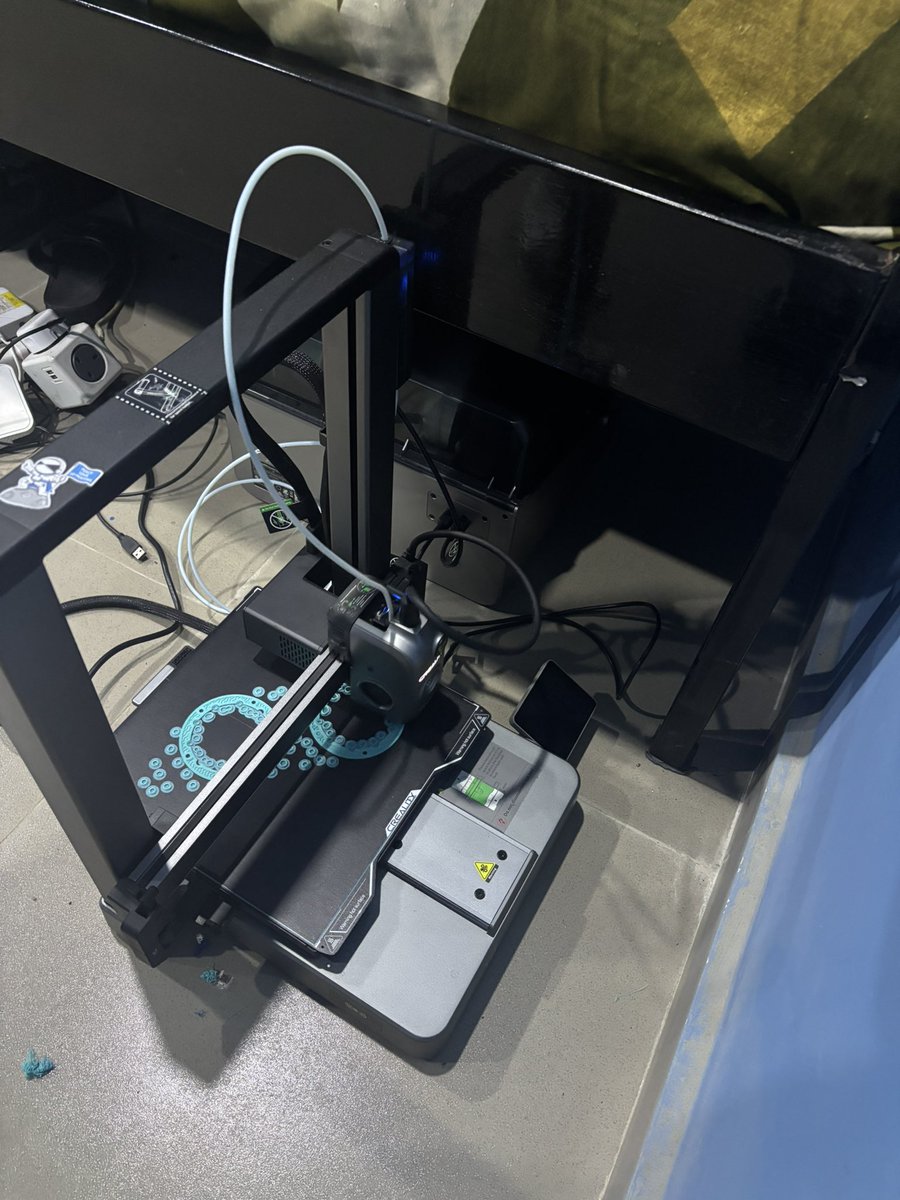
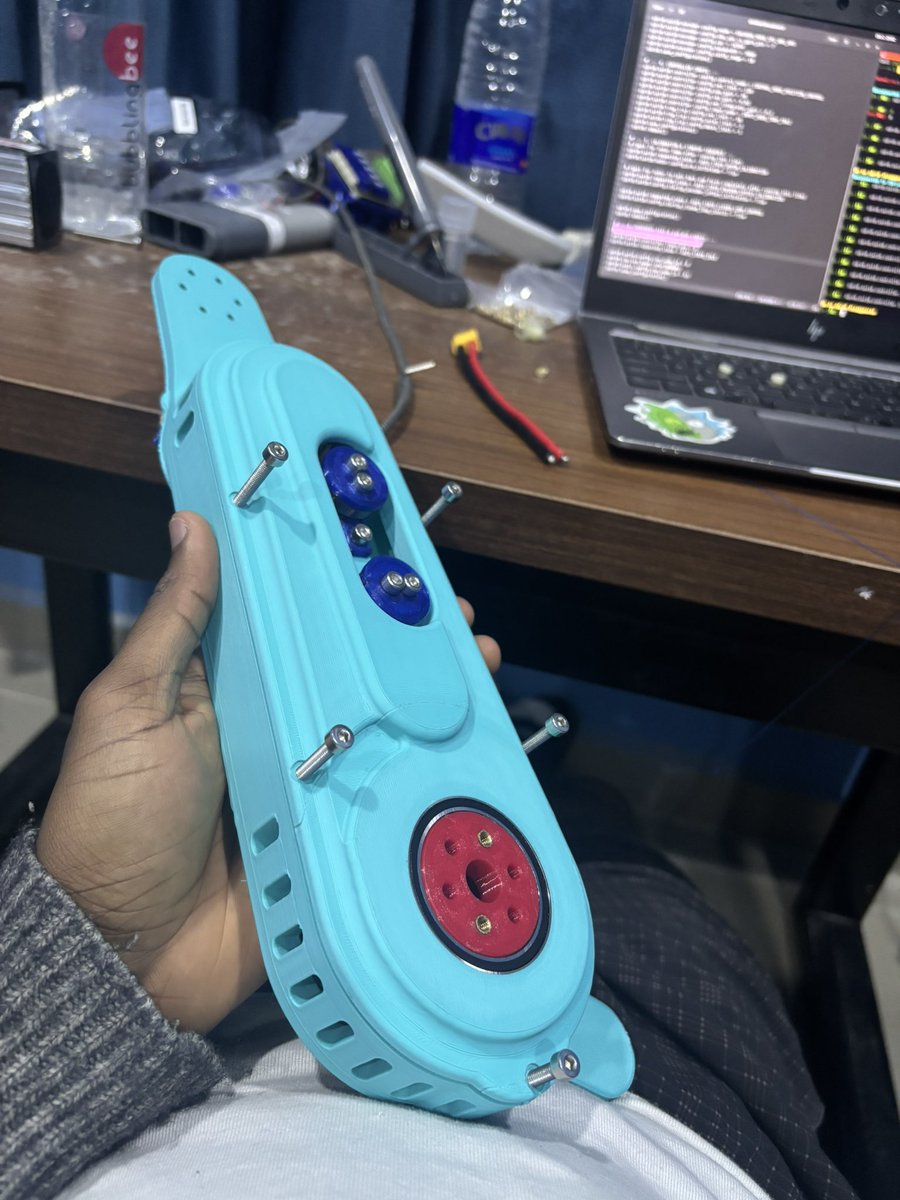
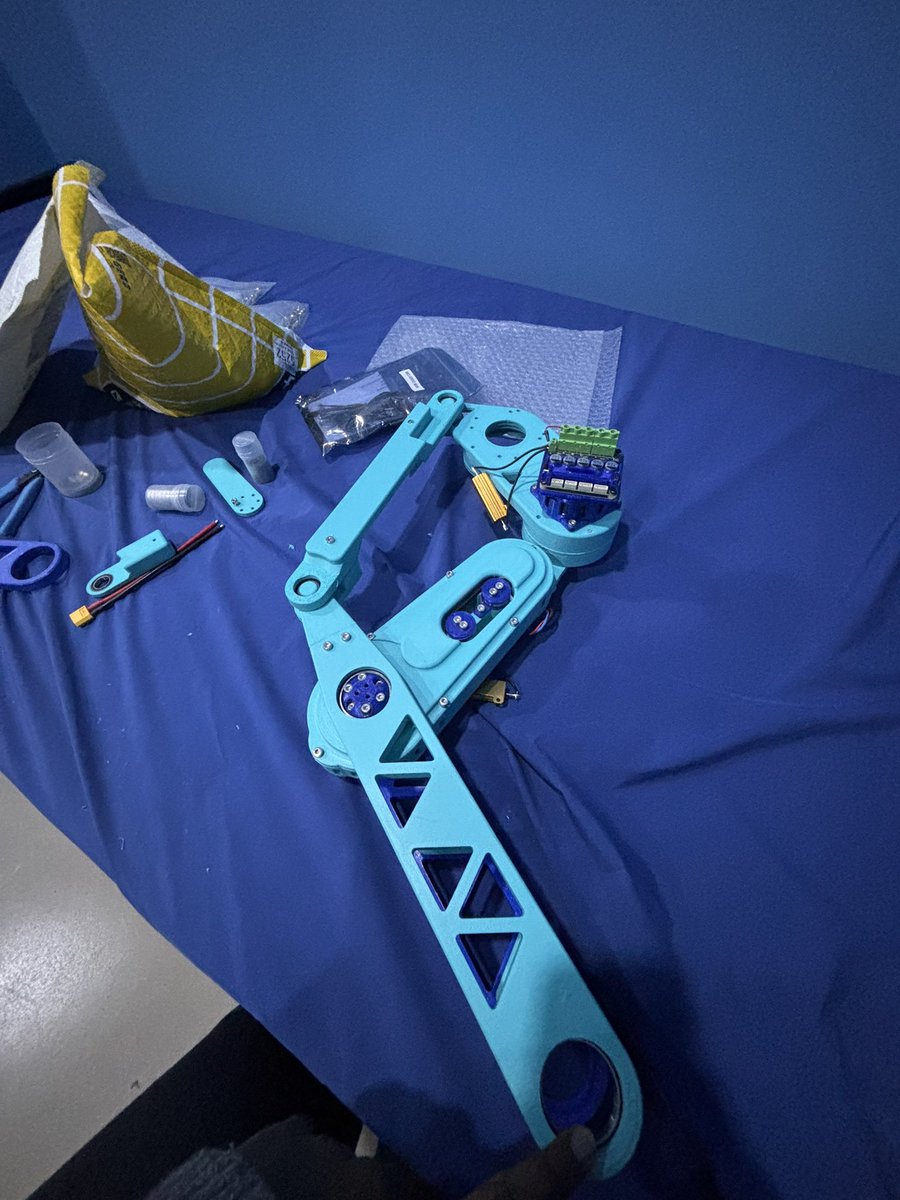
Meet Spike, our first prototype @mecha_corp, the company @localghost and I are building.
Spike was built to learn to walk using reinforcement learning and runs entirely on proprioception. We’re using it as a platform to learn, test, and iterate on both the hardware and software behind legged robots. The end goal is robots for the home. Spike is our first step towards that. If you want to meet Spike in person, feel free to DM me!
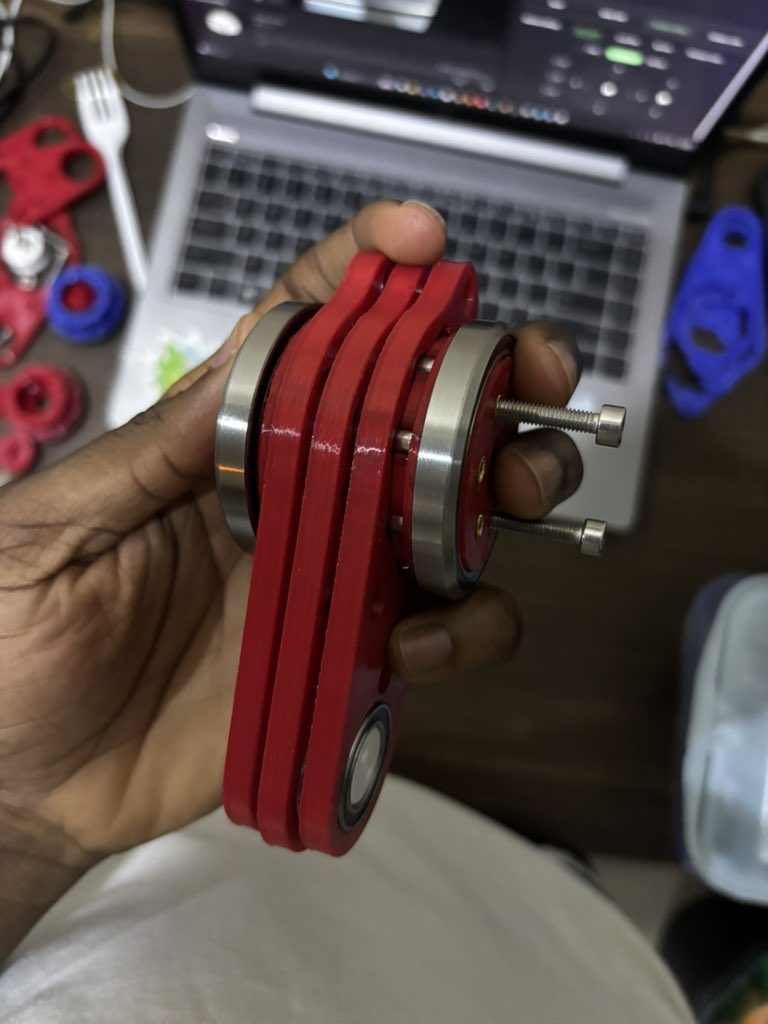
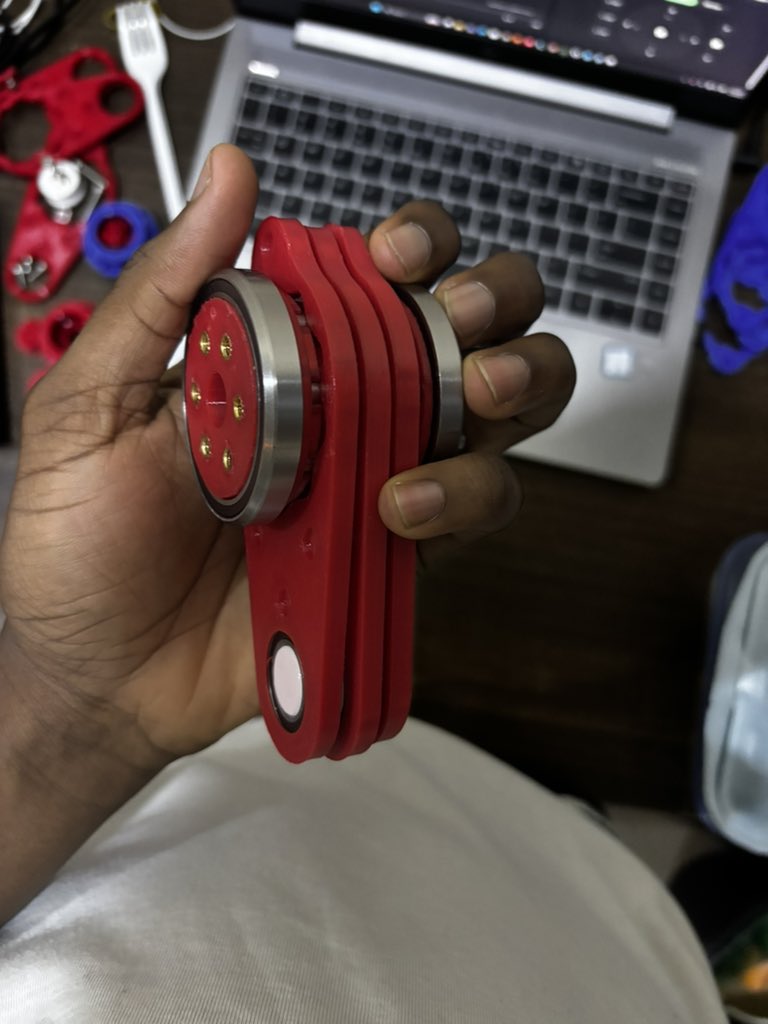
Ran a quick test on the motor and gearbox today.
Still waiting on my batteries to arrive, so I'm making do with a low-power DC adapter. Holding off on full controller calibration until the proper power setup gets here
#robotics#engineering#mechatronics#hardware
Elle m’a dit qu’elle aimait « l’Attaque des Titans » alors je lui ai demandé qui était le méchant, et elle m’a répondu : « Ça dépend de quel côté de la mer tu te trouves. »
@ashi4l The eccentric motion of the input shaft causes the plates to rotate and move around the pins, reducing speed and increasing torque. The gear ratio of this is 9:1
@ashi4l The eccentric motion of the input shaft causes the plates to rotate and move around the pins, reducing speed and increasing torque. The gear ratio of this is 9:1
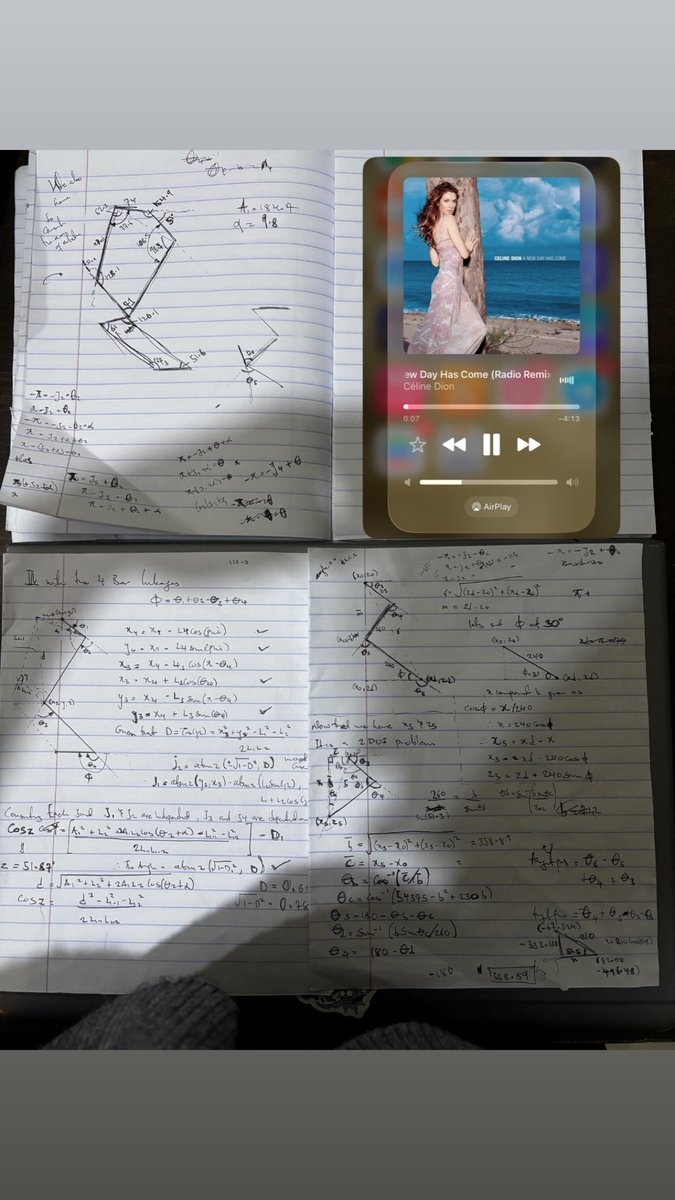
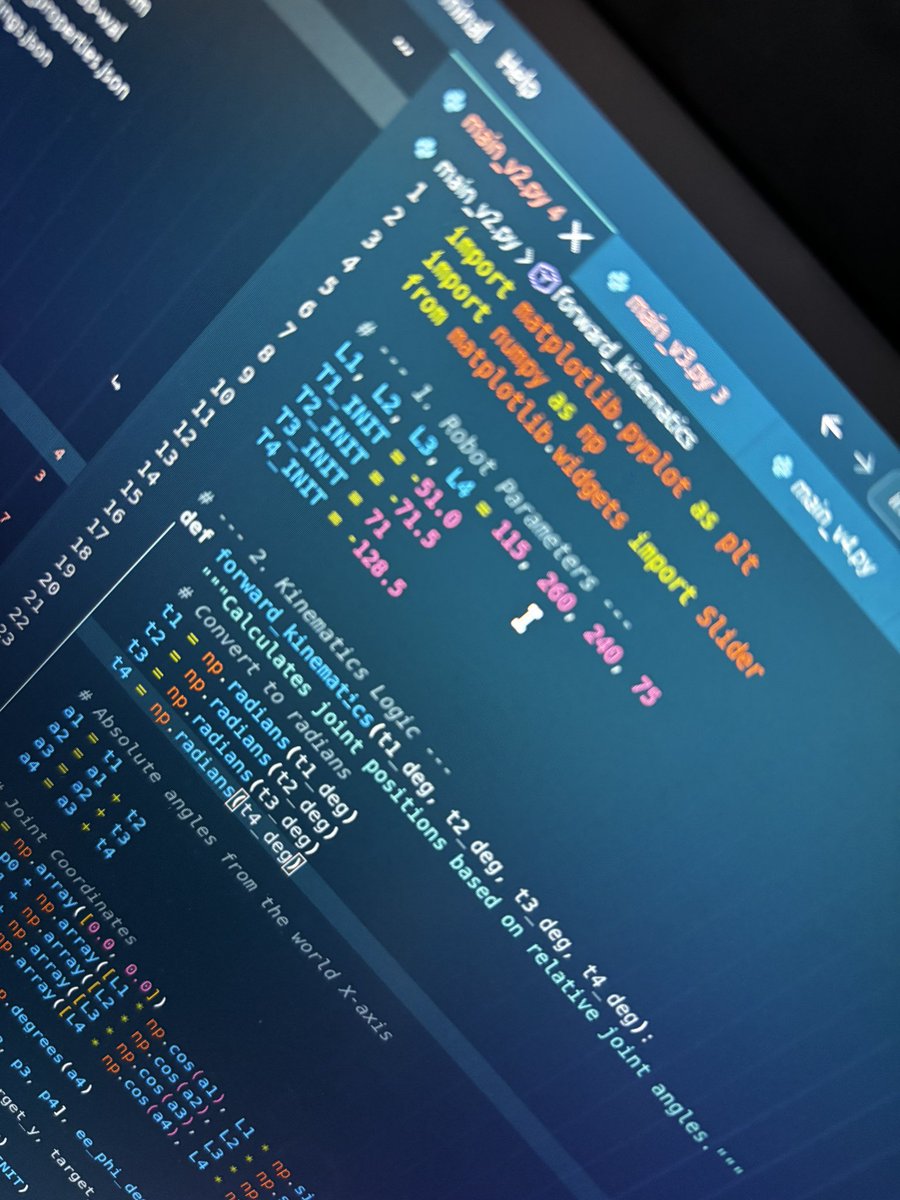
Weekend well spent prototyping the 2D leg ver’s inverse kinematics in py to validate the math before transferring the solutions to the 3d model on RViz.
#robot#robotics#engineering#mechatronics
One of the things we’re working on at the bootcamp is a drone delivery system.
This week we moved part of that idea from CAD into the physical world with the first 3D-printed version of our delivery capsule.
Still an early iteration. There are dimensions to refine, mechanisms to test and plenty of engineering decisions ahead.
But this is exactly the process I want the students to experience: design, build, test, find what doesn’t work, then improve it.
More iterations coming.