📢 Today, our team is excited to announce 𝑺𝒄𝒆𝒏𝒆𝑺𝒄𝒓𝒊𝒑𝒕: an end-to-end method for scene reconstruction from @RealityLabs Research, which enables AI agents to understand and describe 3D spaces.
https://t.co/Te0pNtkFfS
/🧵
Join our Tutorial at #CVPR2023 to learn more about Meta's Project Aria, and how university labs can work with the device for independent research.
Learn more at https://t.co/SPg1UyGQPI
We're presenting our #CVPR2022 paper "NinjaDesc: Content-Concealing Visual Descriptors via Adversarial Learning" during poster session 3.1 tomorrow Jun 23 at 10am. Come check it out - we'll be at stand 211! A short thread 1/N
Made it to #CVPR22 in New Orleans! Come check out my talk about our NeRF inspired -- hybrid sparse / dense 3D representation called Nerfels in the Image Matching Workshop at 3:10-3:20pm local time. Paper link here for more info: https://t.co/YKTnPbpqPO
Ahead of #CVPR2022 , I’m excited to share the open dataset of Project Aria data from Meta Reality Labs, along with accompanying open research tools designed to accelerate AI and ML research. https://t.co/tPuJFLMjG1
A little about the dataset and why I think it’s so exciting…
1/n
The 12th paper in our countdown to #icra2020 is 'RSL-Net: Localising in Satellite Images from a Radar on the Ground' by Tim Y. Tang, Daniele De Martini, @danbarnes333, and @paul_m_newman
Video: https://t.co/1iWYDCTum4
@MRG_Oxford
The tenth paper in our countdown to #icra2020 is 'Kidnapped Radar: Topological Radar Localisation using Rotationally-Invariant Metric Learning' by @StefanSaftescu, @mtt_gdd, D. De Martini, @danbarnes333 and @paul_m_newman
Video: https://t.co/S2d737dZvH
@MRG_Oxford
The seventh paper in our countdown to #icra2020 is 'Under the Radar: Learning to Predict Robust Keypoints for Odometry Estimation and Metric Localisation in Radar' by @danbarnes333 and @IngmarPosner
Video: https://t.co/eEdEJRrFXN
Blog: https://t.co/09AmQEnh49
In our countdown to #ICRA2020, we are sharing one of our accepted papers each day, starting with 'The Oxford Radar RobotCar Dataset'
by @danbarnes333, @mtt_gdd, @PMurcutt, @paul_m_newman, @IngmarPosner
Video: https://t.co/YjL7b4skOv
More Info: https://t.co/weGuLlvZ3e
the pre-print for our paper on learning a metric space for robust topological localisation with FMCW radar is available! https://t.co/QVn82gykNE
@StefanSaftescu @mtt_gdd @danbarnes333@paul_m_newman
Proud to share Masking by Moving: Learning Distraction-Free Radar Odometry from Pose Information with Rob Weston and @IngmarPosner. A new state of the art in Radar Odometry on the Oxford Radar RobotCar Dataset!
https://t.co/WZSWHVjVTg
@a2i_oxford@oxfordrobots#Robotics
@jimdsouza @oxfordrobots @mtt_gdd @PMurcutt@paul_m_newman@IngmarPosner Thanks for your interest in the dataset! Registration is open to any academic institution (.edu / .ac or any address we can verify). If you are not at an academic institution but are interested in using the dataset please get in touch! Thanks
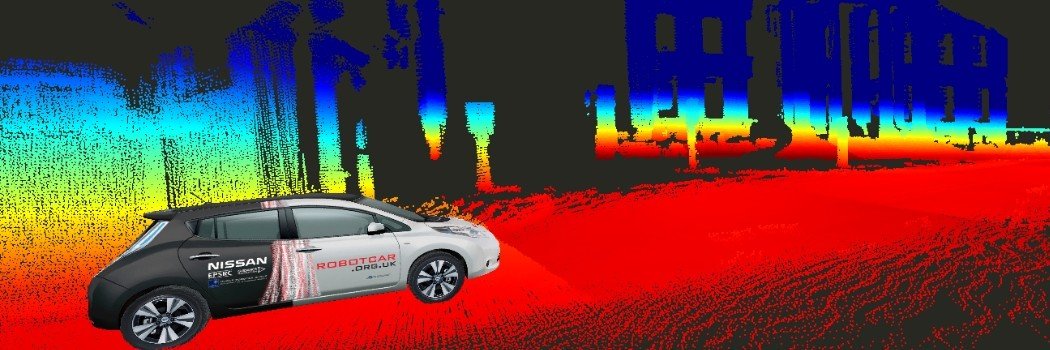
ORI are excited to release the Oxford Radar RobotCar Dataset!
The dataset contains 280km of radar data, on top of a full sensor suite, to accelerate research in this domain.
Visit https://t.co/Hk9DpqgKvm to read more!
@danbarnes333 @mtt_gdd @PMurcutt@paul_m_newman@IngmarPosner