Has Argon solved robot manipulation? Or do the demos fail as task complexity scales
We benchmark Argon, Astra, etc on complex manipulation tasks on real hardware + 1000 simulation runs
Can they one shot complex tasks? Or is a physical harness and tools via dimOS still needed?
SAVE THE DATE (November 7th)
Come join us for a workshop where you will learn how to control a robot dog with the force alone, no touching! (along with a lil computer called an ESP32)
There will be an even bigger game based event later and if you want to participate, you will need an ESP 32 and the knowledge of how to control the robot
This robot dog was granted to us by @dimensionalos who is building opensource operating system for our robotic future!
Link is in the next tweet
I controlled a Robot with my RayBan Meta
Connected my @Meta glasses to my Robot Arm so it can interact with objects
> Glasses detect objects
> Robot interacts with them
Here’s how you can vibecode hardware too:
OPEN CALL TO ROBOT DEPLOYERS.
T-7 to our residency kickoff. Get hyped. Last chance to apply.
Free robots, warehouse space, compute, software support, and connections to customers across data centers, agriculture, construction, manufacturing, real estate, more
anyone interested in trying @huggingface Microduck in this sim playground before it arrives ? Has all the policies + agentic runtime + YOLO object detection + playground. Comment and I'll share the link
Took me a while to get @dimensionalos agentic robot control working reliably for this task. It’s very stable now!
RGB-D (@RealSenseai) and YOLO detects objects. GraspGenX produces the grasp pose which is executed via path planning and some heuristics.
Introducing Nav Arena, over 150 real and simulated environments to benchmark Agents on robots
As a first experiment, we put Jev, Astra, Fable, Dimcode, and other models + harnesses to the test on 2000+ navigation tasks
Fully open source! Code, data, and results below
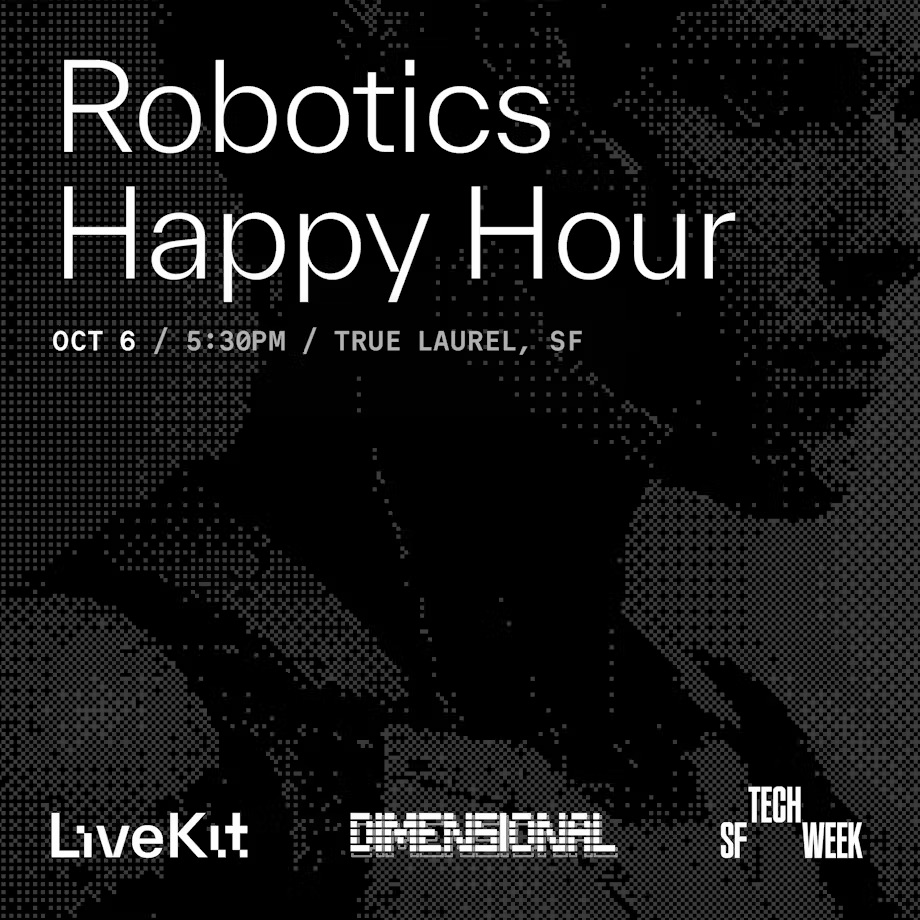
Hosting a Robotics Happy Hour during #SFTechWeek
Tue, Oct 6 · 5:30 PM
True Laurel, SF
For developers and researchers building in robotics and Physical AI.
RSVP: https://t.co/EExdNgnzxD
Dimensional x @livekit
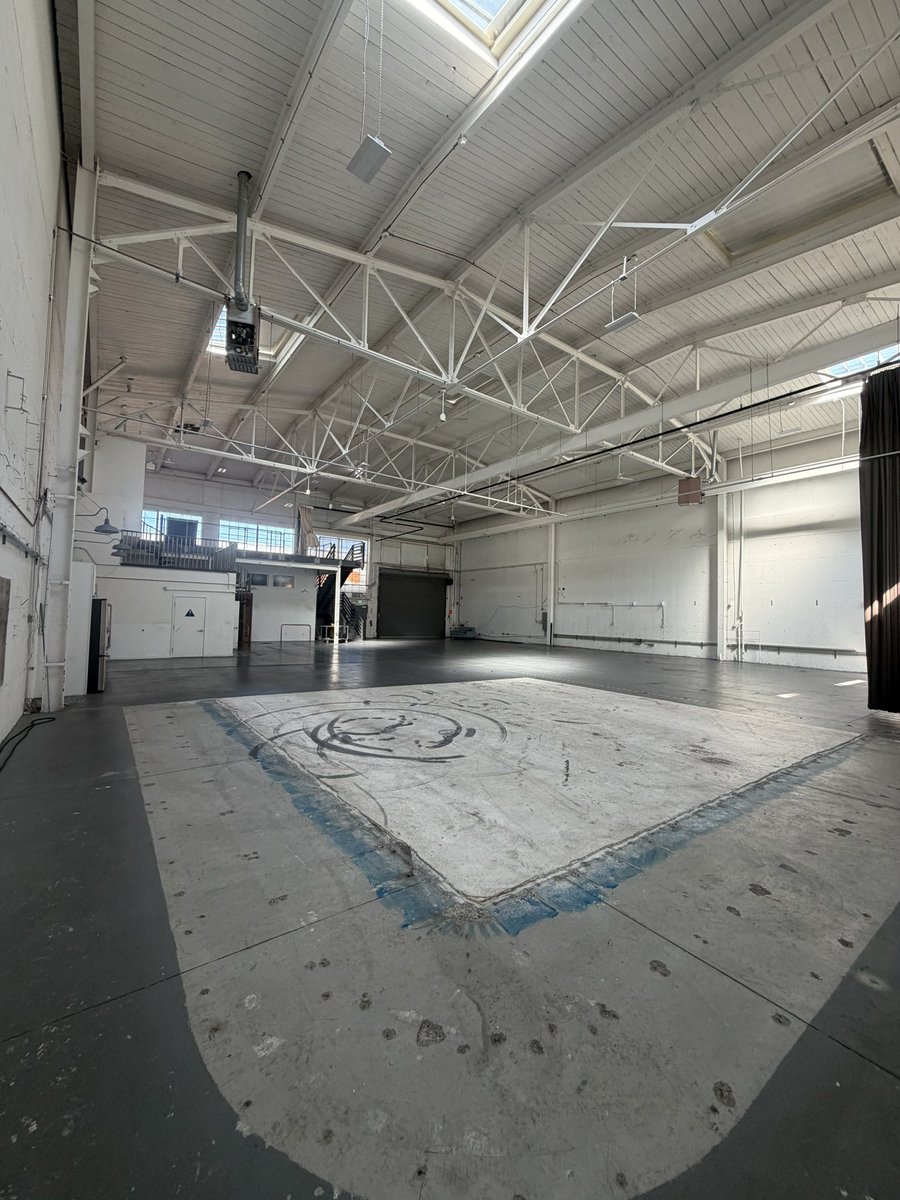
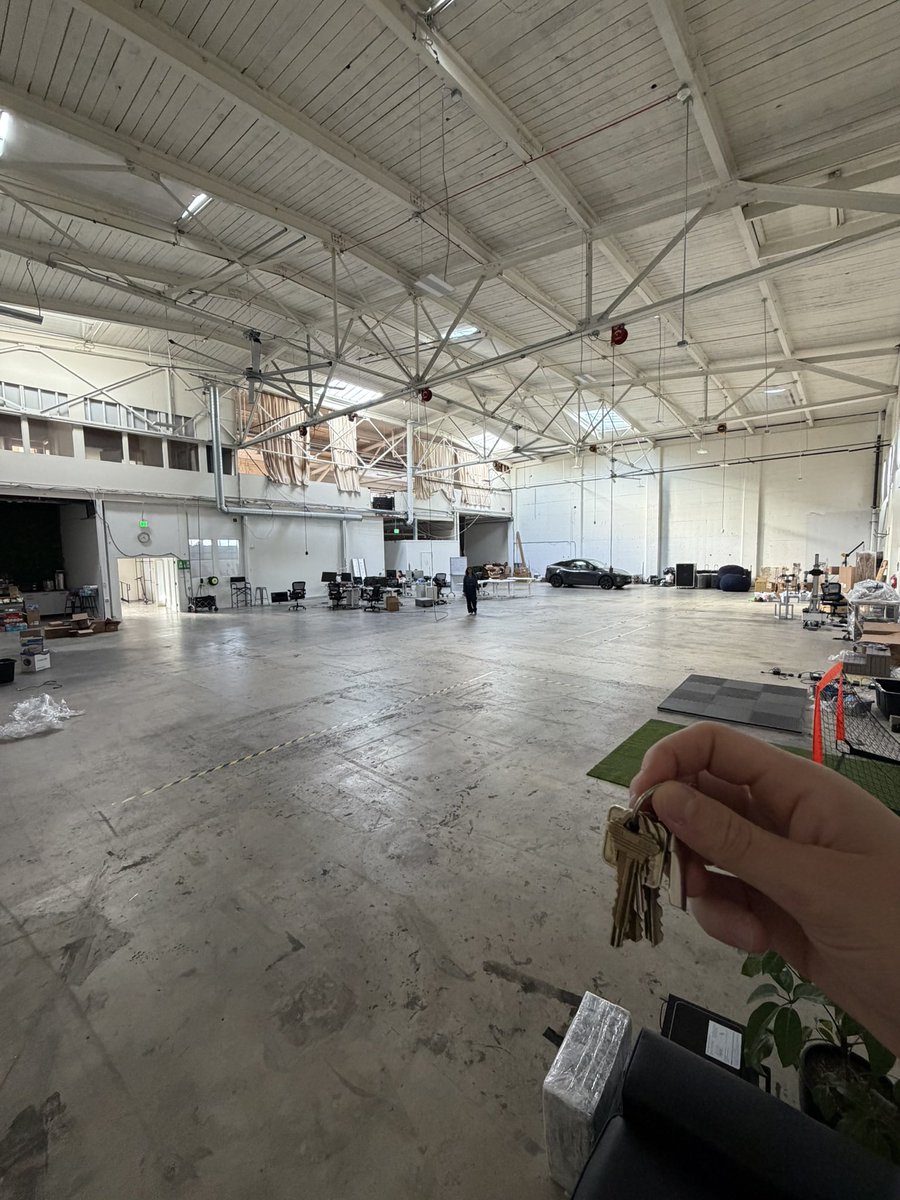
Just got the keys to our new robotics warehouse(s) right in Dogpatch
Will be giving free office space to 15 amazing companies reply here + DM if you or someone you know wants to join!
ROSCon Global 2026, from the Dimensional booth.
Thanks to everyone who stopped by. So many great conversations about bringing agents into real-world robotics.
Great work by @openroboticsorg.
See you next year!
Can Jev Nav?
We put Jev, Astra, Fable, Dimcode, and other models + harnesses to the test on 2000+ navigation tasks in 133 real and simulated environments
How far are LMs from zero-shotting complex real-time control tasks?
Full dataset and code open source ⤵️
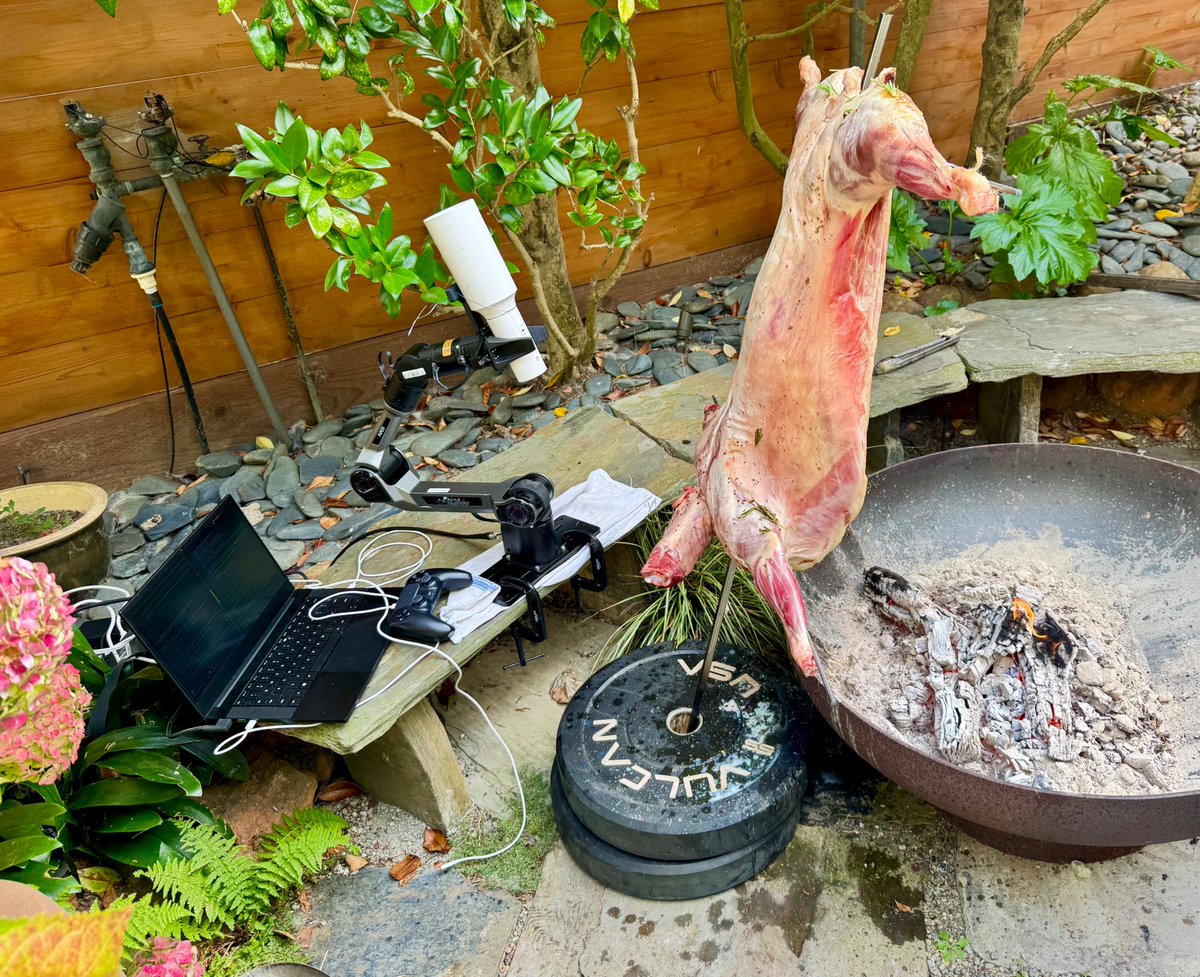
Qué divertido fue organizar este asado!
Alguien tenía que fusionar San Francisco y Argentina
Gracias a @dimensionalos por prestarme el brazo para hacer realidad este proyecto
Se vienen más asados de este estilo para seguir argentinizando el mundo
Amazing opportunity for scrappy founders looking to jumpstart deployments.
We get so much deployment inbound we’ve decided to give it all away to the community 🚀🦾
Apply now
Announcing the Dimensional Residency
For hungry founders eliminating physical labor with robots in any vertical
No equity, just free hardware, access to customers, test environments, and engineering support to scale deployments
3 months. 10 teams. Apply now.
By 2030, 1 in 6 people will be over 60 and providing nursing care will become challenging.
The winners of Dimensional track at @HackMIT turned a wheelchair into a robotic caregiver that helps people bathe, eat, drink, manage medication and more.
Open source code ⬇️
dimOS v0.0.14 is out 🚀🦾
- A browser UI to control your robot: camera feed, 2D costmap, WASD driving, and a chat box for the agent.
- Web SDK for building your own pages.
- Zenoh is the default transport now.
- A new evals framework to score agents against recordings and live sims.
- 3D navigation and ray tracing for dynamic voxel clearing required for global maps.
- Record every topic of any blueprint to replay, visualize, or share.
- New robots: Galaxea R1 Pro, Deep Robotics M20, Boston Dynamics Spot (experimental), OpenYAM, A1Z.
https://t.co/4xgG3ZZ89c