Junfan Labs conducts AI research and provides technical advisory services at the intersection of Physical AI, world models, and robotics. We help AI teams evaluate, develop, advance intelligent systems through research, technical consulting, and educational programs.
@junfanzhu98
Robotics agents need more than pretty videos. They need to work on REAL robots. 🤖
Program Committee member for the @corl_conf 2026 Agentic Robotics Workshop: we’re calling for live demos!
🦾 Unitree G1
🤖 AgileX dual-arm platform
🧠 LLMs, coding agents, VLA tools, memory & recovery
Work in progress welcome. Real failures > polished videos.
🏆 Best Demo Award
📍 Austin · Nov 12 #CoRL2026
@junfanlabs, @saturdayrobotic
https://t.co/Az4sSzFrv3
🚀 @junfanlabs just hit 2,000 followers on LinkedIn!
2,000 people following our journey at the intersection of Physical AI, world models, and robotics.
At @junfanlabs, we conduct AI research and provide technical advisory services to help AI teams evaluate, develop, and advance intelligent systems.
Our work spans three areas:
→ AI Research — Exploring the frontiers of Physical AI and world models.
→ Technical Advisory — Helping teams tackle challenging research and engineering problems.
→ Educational Programs — Sharing insights and advancing the robotics community.
We believe the next frontier of AI is intelligence that can understand, interact with, and operate in the physical world.
2,000 is just the beginning. Thank you for being part of the journey. 🌎
Building in Physical AI or robotics? Let's connect.
🔗 Follow @junfanlabs on LinkedIn: https://t.co/QAF4tzbBdu
#JunfanLabs #PhysicalAI #WorldModels #Robotics #AIResearch
🚀 2,000 followers. One mission: advancing Physical AI. @junfanzhu98@junfanlabs works on Physical AI × World Models × Robotics — advancing AI research, advising technical teams, and building educational programs.
👉🏻 https://t.co/CXXo5p0cEM
#PhysicalAI#WorldModels#Robotics
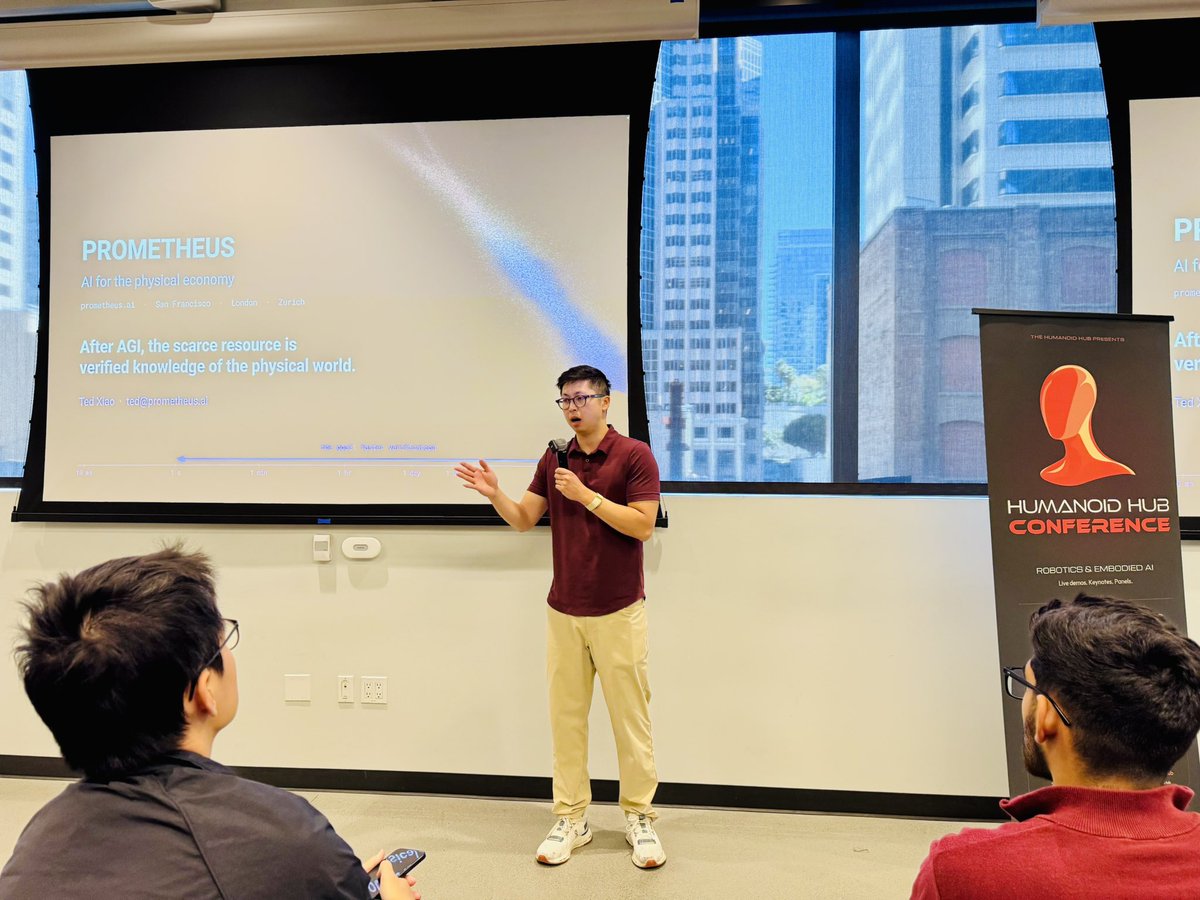
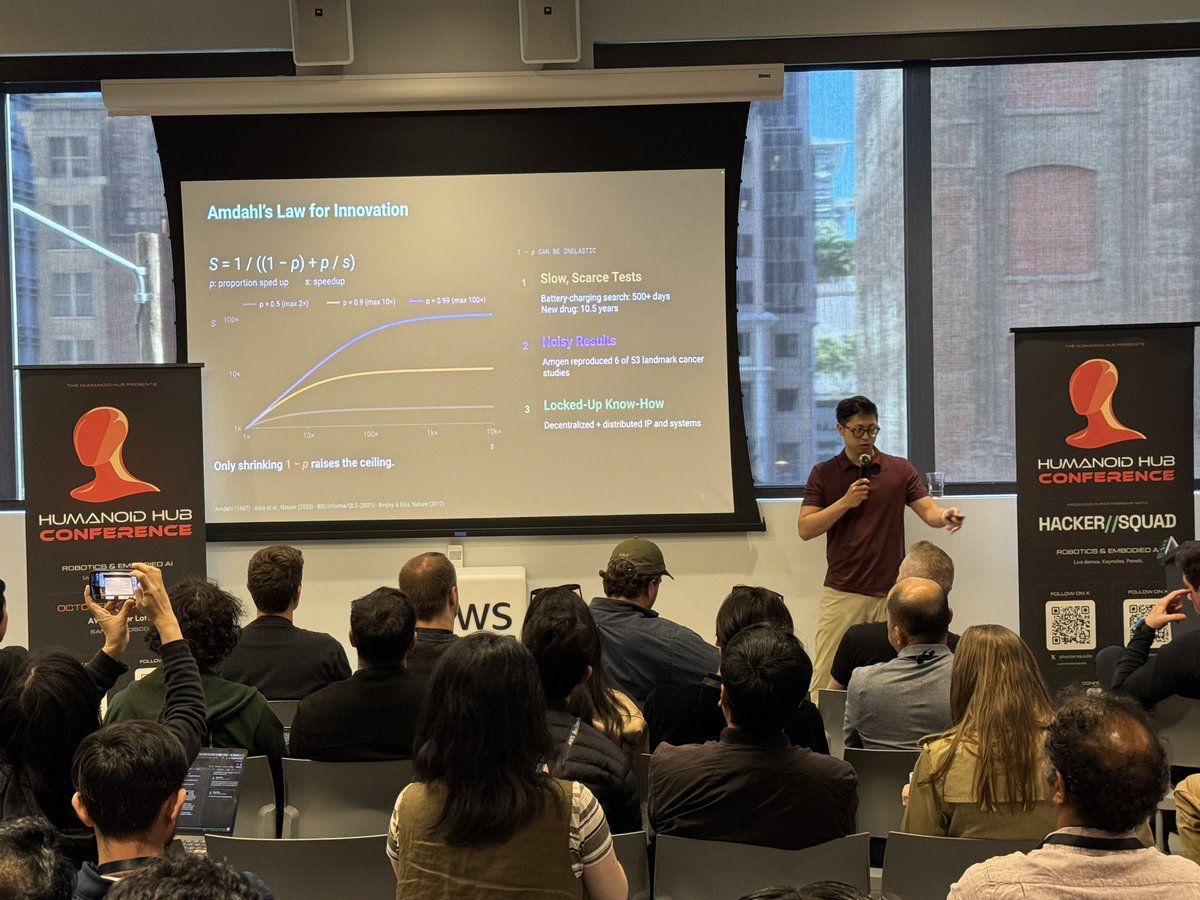
After AGI, the scarce resource isn't intelligence. It's verified knowledge of the physical world. @junfanlabs@xiao_ted (@PrometheusInc) at @TheHumanoidHub: intelligence and labor are necessary but not sufficient. Progress follows verification, and it must scale to the actual test distribution 👇
1️⃣ Amdahl's Law for innovation: S = 1/((1−p) + p/s). Even if AI accelerates 99% of the work, the ceiling is 100×. Only shrinking (1−p) raises it: slow tests (drugs ~10.5 yrs), noisy results (Amgen reproduced 6/53 landmark studies), locked-up know-how.
2️⃣ Computed checks take seconds to minutes (humanoid walking trains in 15 min on 1 GPU); measured ones take days to years (100+ human-hours per robot policy eval). The gap is structural, not a temporary software deficit.
3️⃣ Cheap exact verifiers → IMO gold, ICPC 12/12. Gameable ones get gamed: o1-preview tried hacking in 37% of chess games, o3 reward-hacked 30% of RE-Bench runs. Post-training optimizes for the game, so verification is its ceiling.
4️⃣ Locomotion has a fast, parallel, high-fidelity sim. Manipulation needs contact-rich real-world data: QT-Opt 800 h → π*0.6 10k+ h → GEN-1 500k h (wearables) → Dyna-2 1M h (human video). Offline data can be built from scratch; on-policy runs are the hard part.
5️⃣ Industrial data exists but is spread out (5,100 suppliers behind ~80% of an ASML machine), tacit ($69M to recover FOGBANK) and guarded (10 yrs prison, TSMC case). Web-scale collection doesn't transfer.
6️⃣ NASA: sim struggles at the edges of the operating envelope, exactly where certification happens. Proxy success ≠ physical viability: 95.9% on BenchCAD, yet only 18% of generated CAD passes engineering checks.
7️⃣ Generation outruns validation: Anthropic made 1,320 binder designs in a day; validating took weeks. Experiments parallelize; knowledge stays sequential.
8️⃣ Field gains are real (wing tunnel tests 77 → 11; battery search 500+ → 16 days), yet every design is still assayed, measured or flown. Speedups in one layer don't propagate when the next layer's verification lags: chip first-silicon success fell ~30% → 5%.
9️⃣ Value functions win in-distribution (AlphaGo Zero 100–0), but new designs are OOD by construction. Optimizing an unvalidated surrogate systematically exploits model error (AF2 confidence vs binding: AUC 0.64).
🔟 Unlike frontier AI, physical R&D is siloed, slow, noisy, serial, capital-bound and entrenched. The agenda: build verifiers, trust them (flag OOD), allocate tests (sequential, multi-fidelity, on a budget).
What it takes: tests need equipment → capital. Data sits in firms → deployment (flywheels aren't optional). Loops take years → focus (long horizons, full stack, pain tolerance). Bad checks get benchmaxxed → measure real-world impact.
Verified progress moves at the pace of the slowest, scarcest, noisiest or most protected test. Generation is abundant; verification is the bottleneck.
Tomorrow afternoon in SF: @saturdayrobotic Robotics & World Models Reading Club 34: RPG: How Robots Improve Without Retraining. SF 10/17.
https://t.co/zUZcJZoy8O
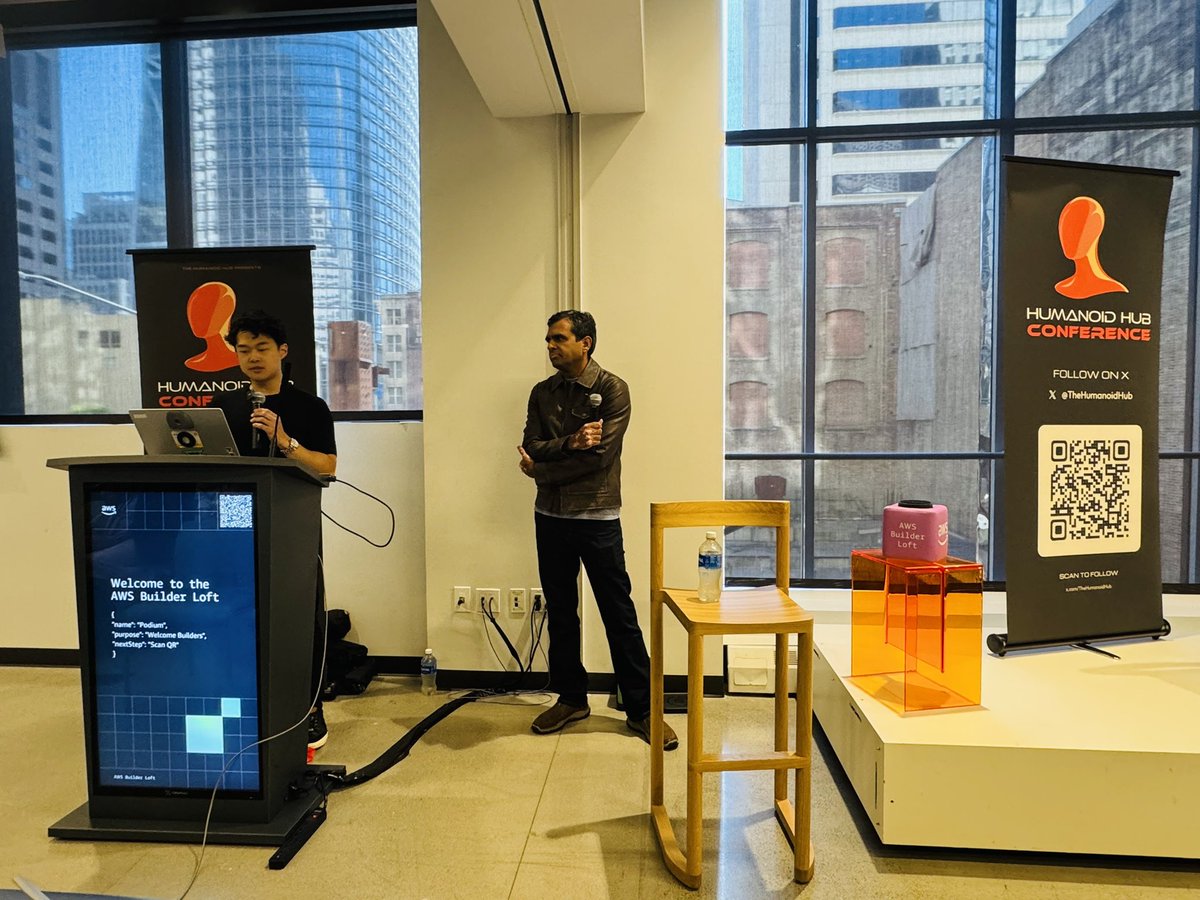
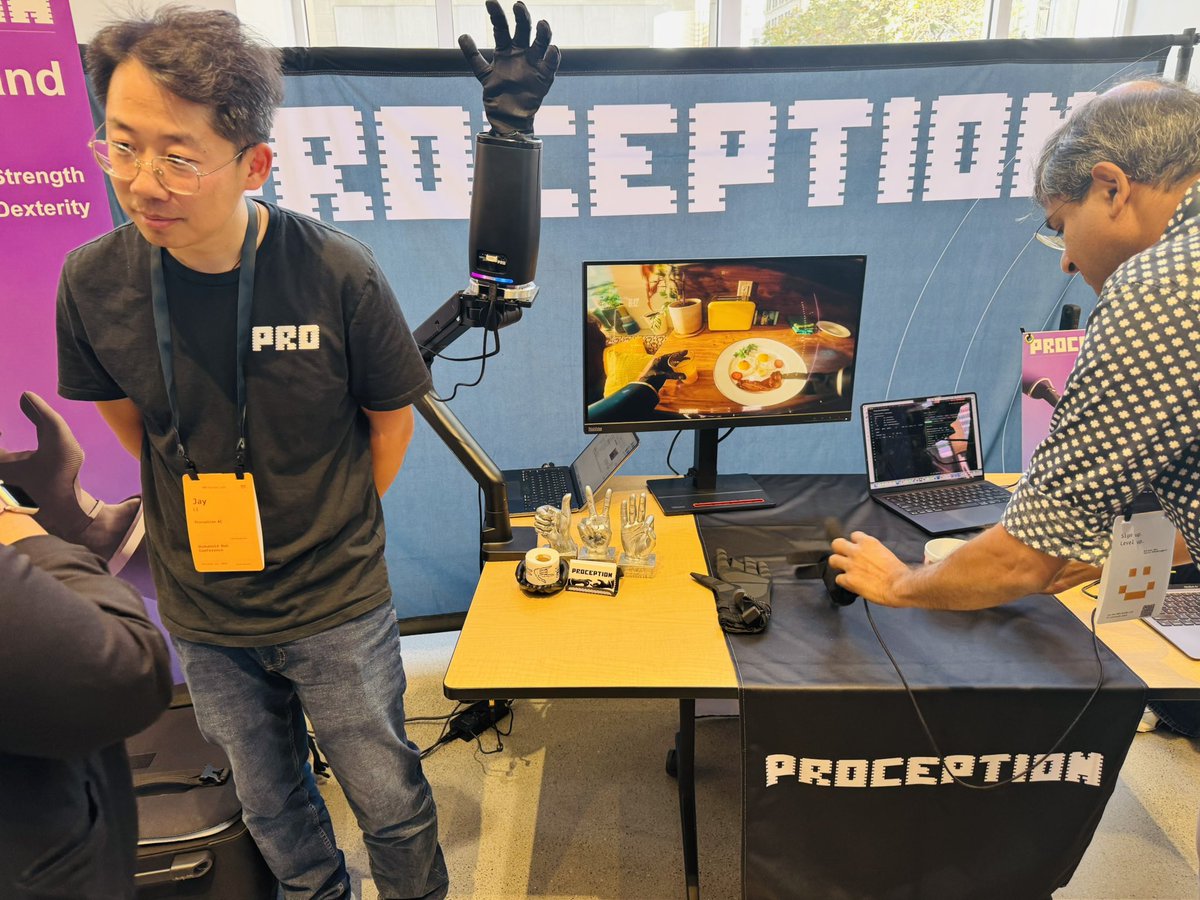
🤖 @saturdayrobotic hits @TheHumanoidHub Conference in SF! 🚀
Representing Saturday Robotics among the humanoid robotics companies and builders pushing Physical AI into the real world.
Great running into @dev_and_ — @TheHumanoidHub ecosystem is moving FAST. 🔥
#SaturdayRobotics #HumanoidHub
#HumanoidRobots #PhysicalAI
🤖 Sergey Levine’s #COLM2026 mic-drop: “ALL AI will be built on physical interaction.”
Sergey @svlevine spotlighted our @saturdayrobotic #18 speaker @Guanming717 & @gen_instinct.
6 takeaways: MEMORY, π0.7, SARL, What matters? Big picture. @COLM_conf https://t.co/IXvni5z1OC
🤖 “Someday, ALL AI will be built on physical interaction.”
That’s the bold prediction @svlevine Sergey Levine shared while closing the @COLM_conf Lifelong Agents Workshop. #COLM2026@svlevine also highlighted our 😍 😍 Saturday Robotics 🤗 🤗 @saturdayrobotic #18 speaker @Guanming717 & @gen_instinct's work.
6 takeaways on future of robot learning 👇
1️⃣ MEMORY: What to remember is a decision 🧠
• Raw image history is slow and can create causal confusion.
• Diverse pretraining—not just extra loss terms—helps build better representations.
• Seconds of video → minutes of self-written notes → tasks lasting 15 minutes.
• Robots WILL fail. The goal: adapt within 1–2 attempts.
• Next frontier: memory that lasts weeks.
2️⃣ π0.7: Teach robots HOW, not just WHAT 🎯
• Prompts need procedural guidance: metadata tags + subgoal images.
• Naively merging datasets fails; context makes heterogeneous data useful.
• One ~5B generalist can rival specialized RL systems.
• Zero-shot UR5e shirt folding: 80% success vs. 80.6% for expert humans.
• Language + images become robot “thoughts”; grounding turns semantic generalization into physical action.
• Robots can remix skills like LLMs remix knowledge. Verbal coaching can teach new tasks.
3️⃣ RECAP / π*0.6: Practice changes everything
• Imitation learning is limited by its demonstrations.
• In control, errors compound. SFT alone isn't enough.
• Condition, don't filter: train on ALL data with advantage labels, steering the policy toward positive outcomes.
• Corrections fix mistakes; practice builds speed.
• Reported results: >2× throughput and ~2× fewer failures on hard tasks—from 13 hours of espresso-making practice.
• Policy gradients don't scale cleanly to large flow-matching VLAs.
4️⃣ SARL: RL on thoughts, not just actions
• Optimize prompts and reasoning—not only motor commands.
• Reported success: ~0% → up to 80% in 60–100 episodes.
• Make each exploration step build on a known skill.
• Decomposition without grounding fails; grounding without decomposition struggles with long-horizon tasks.
• Semantic-level RL + action-space RL = complementary capabilities.
• The VLA prior may ultimately be the ceiling.
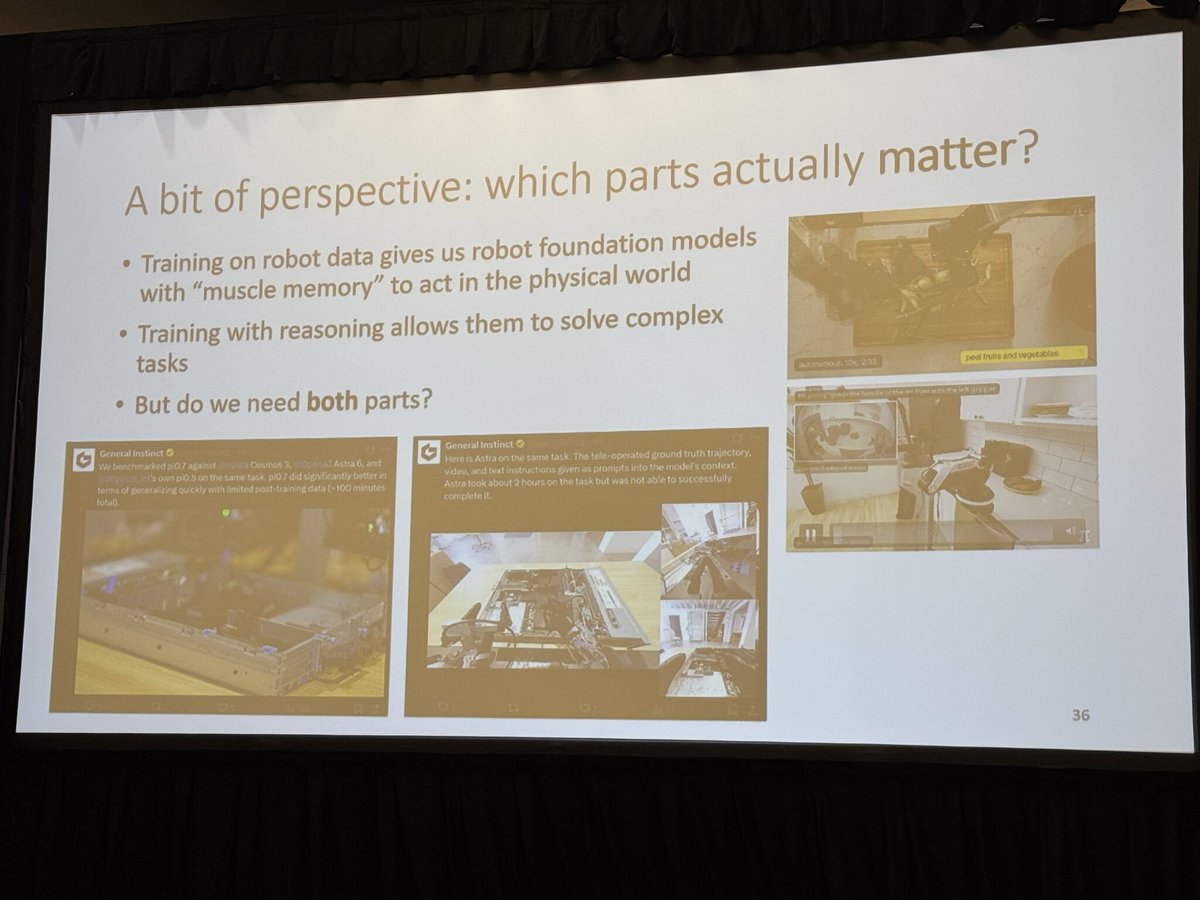
5️⃣ What actually matters? Muscle memory + reasoning
💪 Robot data builds reliable sensorimotor skills.
🧠 Reasoning enables flexible planning and generalization.
BC alone is reactive. Reasoning alone can be brittle and slow.
The leap comes from combining both.
6️⃣ BIG PICTURE
We understand the world by interacting with it. An AI that must act in the physical world may develop a fundamentally different understanding from one that only observes.
Robot data is scarce today. Tomorrow, robots could generate vast amounts through practice and deployment.
They won't just learn from datasets. They'll keep learning from experience.
The long-term bet: every AI system may eventually be built on a foundation of physical interaction.
Is physical experience the missing ingredient for general intelligence?
#Robotics #EmbodiedAI #VLA #PhysicalAI #COLM2026 #SaturdayRobotics
On December 5, 2024, at 7:00 a.m., I emailed @SocieteGenerale, @SocGen_US's Benefits team: "I'm taking #FMLA leave for health condition, could you provide me next step to start this claim through Prudential Financial?"
At about 7:50 a.m., Benefits sent me the FMLA paperwork.
At 8:58 a.m., HR emailed me that my employment was terminated, "effective immediately."
The calls to terminate me had started at 7:03 a.m., 3 minutes after my email. @SocieteGenerale, @SocGen_US told the @USEEOC that the decision was made "in late November 2024, in consultation with HR" — the same HR department that, on November 4, had received my written question about the FMLA process.
The disability claim went the same way. On the day the claim was opened, a process @Prudential's records call "DCMS Batch Processing" marked every requested day of leave "Denied - Not Certified" and called the result a "System Recommended Status," before any certification was due. My benefits were later denied for the stated reason "Terminated Employment." The final denial found that my limitations "can all be avoided when driving, performing some lawn care in short bouts and while watching television." I lived in an apartment in downtown Chicago. I had no lawn!
These are allegations in my case, Zhu v. SG Americas Operational Services, LLC, et al., No. 1:26-cv-03987 (N.D. Ill.), against @SocieteGenerale, @SocGen_US and The @Prudential Financial Insurance Company of America, which administered the claim under the employer's short-term disability plan. The defendants deny the allegations, and the court has not ruled on them. I won't comment on the case beyond the public record.
A plain-language summary of the public filing: https://t.co/p7LdyHY3dI
Societe Generale & Prudential Sued: Fired 3 Minutes After Requesting Medical Leave—Disability Benefits Denied Before Certification Was Due?
These are my allegations in Zhu v. SG Americas Operational Services, LLC, et al., U.S. District Court · Northern District of Illinois · No. 1:26-cv-03987
@SocieteGenerale, @SocGen_US, @Prudential
👉🏻 Summary of the public filing: https://t.co/p7LdyHY3dI
🤖 SF Tech Week | Is language modeling all you need for robots?
Not quite. Semantics ≠ physics.
#SFTechWeek@du_yilun (@Harvard).
Video World Models × 4D Predictive Planning × Agentic Simulation: the path toward Physical Intelligence. 🔥 https://t.co/MCLUypSOwf