Day 3 of building a sentient robot dog (molty)
- It Walks, waves, and dances.
- Powered by a Raspberry Pi, 8 servos, and a fully 3D-printed body.
- Today it's driven by an LLM generating behaviours. Next comes an RL policy that learns instead of following scripted motions.
https://t.co/eC3VOMcrRA
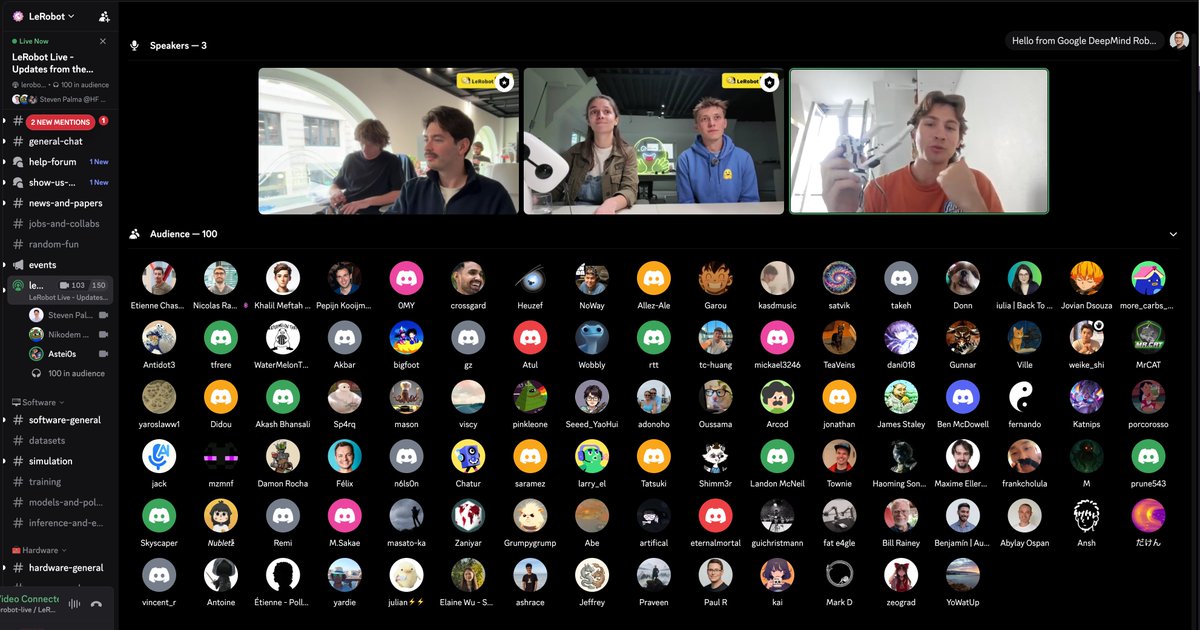
Just watched today’s @LeRobotHF livestream and there’s a LOT coming
0.6 brings:
• World models + more VLAs/reward models
• Depth + large-scale language annotations
• LIBERO, RobotTwin, RobotCasa & VLA Bench
• Rollouts + HF Jobs training
And 0.7 looks even more exciting:
• Streaming for massive datasets
• Full Unitree G1 support + whole-body control
• LLM-driven robot control
• Remote inference + in-context learning
• MicroDuck support
Loved seeing community projects too: especially mobile SO arms, open-source teleoperators, and all the creative robots people are building.
Big thanks to @nikodembartnik@Caro_Nahkriin@NepYope and the LeRobot team for the stream!
https://t.co/FbNIftcDtL
Trading was boring. So we built a handheld arcade.
Meet ETH Arcade 🕹️
A physical console where the ETH price becomes the game. Real buttons. Live market data. Onchain settlement.
And an SDK so you can build the next game.
Try it live 🧵
Caltech taught a Unitree G1 humanoid to play dodgeball. CBF + RL, only a depth cam, 19/20 throws dodged zero-shot from sim. Key finding: match your safety barrier to what your sensors can see.
Google DeepMind's Gemini Robotics ER 2 is a reasoning brain for robots. Orchestrates VLA models, tracks task progress via video. 91.3% moment-finding at 0.96s latency. I charted the key specs.