Can't agree more with the opinion acknowledging onboard perceptions.
In my CoRL'26 work on accurate robot soccer shooting (https://t.co/w5KQ7f5RC2), I used onboard LiDAR+D435I camera for perceptions. I can say >90% of my effort was put on making good ball perception. Robust perception(and also its connections to robot) on a wildly dynamic robot is truly hard. Camera image blurs a lot🥲
Also, when your perception is bad, estimation comes important. We put Kalman Filter here; and MIT's yoga has a learned estimator from real-world data, that's our weapon to work with poor sensors.🥲
What do robot sports teach us?
We have seen incredibly cool progress in robot soccer and tennis recently, but just as interesting is what we definitely do not see.
Robots are increasingly capable of incredibly fluid, reactive whole body control - but their ability to perceive the world while doing so is incredibly limited. And so we see shortcuts being taken, external trackers used, to avoid the limitations of onboard sensing and sensorimotor control while in challenging environments.
The future of robotics will require closing this gap.
Some thoughts ->
https://t.co/7xT0mKyg1I
Can a humanoid be your badminton buddy, learning from just 30 min of human motion data? Humanoid Badminton 🏸, accepted at #CoRL2026, learns diverse racket skills with a single policy, enabling natural whole-body motion and real-world multi-skill rallies with forehand, backhand, and highly dynamic jump returns.
🌐 Project: https://t.co/FxEMgY5gX5
As robot learning leans more and more toward scaling, it can seem like there is less and less left for academic labs to do. I think humanoid ball sports is a topic especially well suited to academia: it doesn't need huge amounts of compute or data, but it does take a lot of effort and ingenuity.
And it's moving fast: my timeline has been full of humanoid robots playing ball lately.
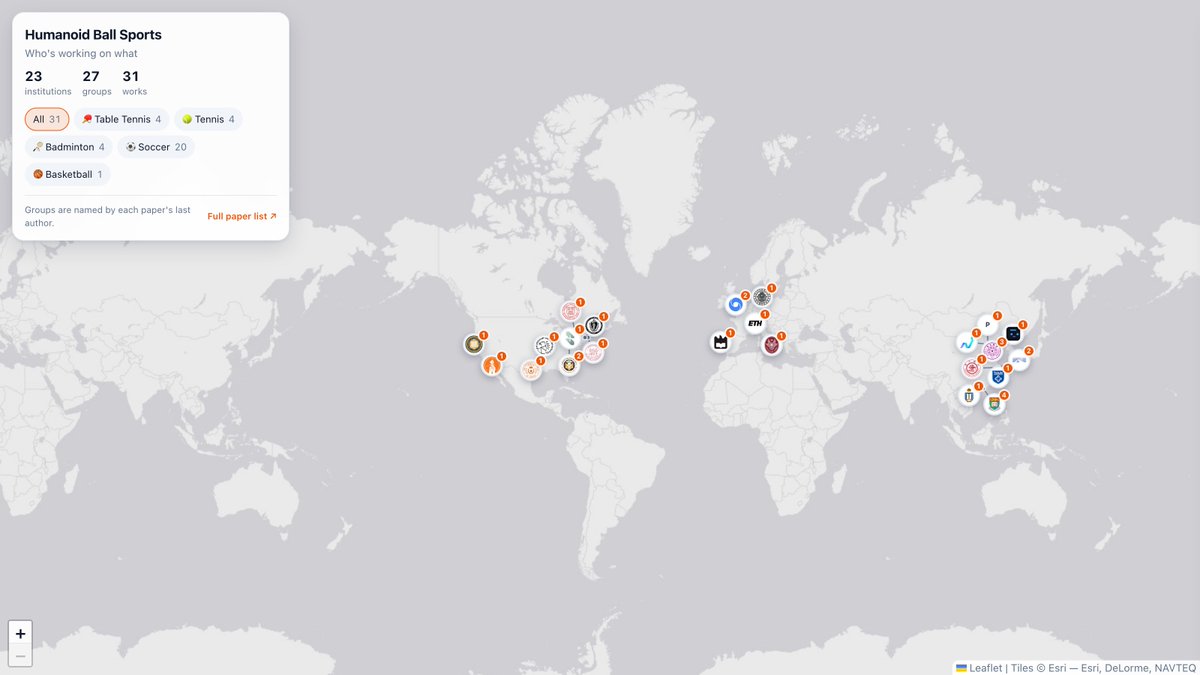
So I made Awesome Humanoid Ball Sports 🏓🎾🏸⚽🏀, a curated list of research on humanoid table tennis, tennis, badminton, soccer and basketball, to make literature review easier and help everyone keep track of the latest work. It also comes with an interactive map of which groups work on which sport.
With huge respects, excellent work!
Also check out our recent open-sourced work on humanoid soccer shooting, lidar+vision-based, mocap-free, in the wild:
Paper: https://t.co/9Twg3DRTaT
Page: https://t.co/3kbO0bWrB3
Code: https://t.co/UfJHFYkDUC
Feels like the sporting humanoids era🥲
Introducing Joga, a full-stack humanoid soccer system with active vision.
Agile dribbling. Tight direction changes. Receive → dribble → shoot/pass.
An actuated neck enables ball tracking with onboard vision.
Residual models for perception + actuation close the sim-to-real gap.
Paper coming soon!
Work done in collaboration with @Avi_Narula14@khai_ngx@venki1899@JohnMarangola@martinpeticco@pulkitology
The ⚽️ #WorldCup2026 kicks off tonight 🏆 — and we're sending a humanoid onto the pitch too!
Meet RoboNaldo: a versatile humanoid football shooter.
It can strike the ball up to 13m/s, accurately lands within 17 cm of a 3 m target away, outdoors on real grass pitch, off a live human pass, with fully onboard perception.
https://t.co/iFV7bINU2p
🧵👇
New paper release: Learning Agile Perceptive Traversal of Sparse 3D Structures for Humanoids
Paper https://t.co/LlrDsajHqx
Videos https://t.co/jXLtG68oUg
We study how to do learning and sim2real for 3d traversal, such as monkey bars and overhanging obstacles.
Very excited to share that I'll be joining UIUC ECE and CS (affiliate) as an Assistant Professor @UofIllinois
I'm recruiting PhD students, interns, and postdocs to build trustworthy AI agents and robots that reason, learn, and grow alongside humans. If you're interested in joining my lab at UIUC, reach out at [email protected]
Many thanks to my advisors and collaborators for all their help and support! @haroldsoh @ Katia_Sycara @RamananDeva @ Alexander_Gray @ David_Hsu @ksmeel @ Mohan_Kankanhalli @joecampb@SimonStepputtis @ Woojun_Kim @yswhynot
The ⚽️ #WorldCup2026 kicks off tonight 🏆 — and we're sending a humanoid onto the pitch too!
Meet RoboNaldo: a versatile humanoid football shooter.
It can strike the ball up to 13m/s, accurately lands within 17 cm of a 3 m target away, outdoors on real grass pitch, off a live human pass, with fully onboard perception.
https://t.co/iFV7bINU2p
🧵👇
Heading to #RSS2026 Sydney 🇦🇺 - I will present RoboNaldo at ExWBC workshop:
https://t.co/hTdMV4Yoyb
Come and try defending the robot banger shoot😆 See you then!
The ⚽️ #WorldCup2026 kicks off tonight 🏆 — and we're sending a humanoid onto the pitch too!
Meet RoboNaldo: a versatile humanoid football shooter.
It can strike the ball up to 13m/s, accurately lands within 17 cm of a 3 m target away, outdoors on real grass pitch, off a live human pass, with fully onboard perception.
https://t.co/iFV7bINU2p
🧵👇
Sydney-bound for #RSS2026, and not gonna lie, we’re buzzing! 🔥
On our slate:
https://t.co/2UsSCILPcw
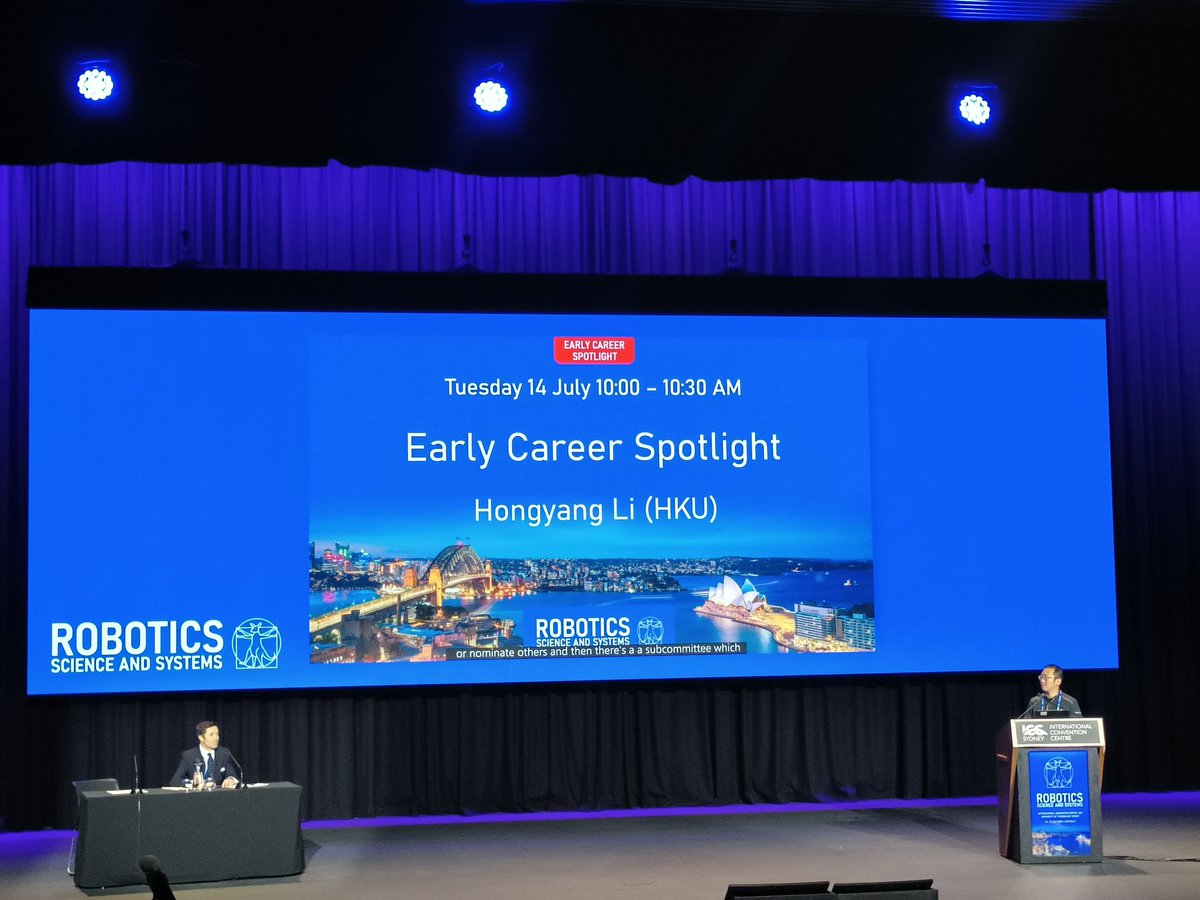
🎤 Dr. Hongyang Li — Early Career Spotlight
📄 Two papers we're proud of: RISE & EgoHumanoid
🤖 A humanoid doing real work on the floor - July 13th Morning Workshop
Full rundown + where to find us 👇
https://t.co/H7sMKj9jTJ
Come have a yarn.
#EmbodiedAI #WholebodyIntelligence #VLA #WorldModels #Sydney #ICC