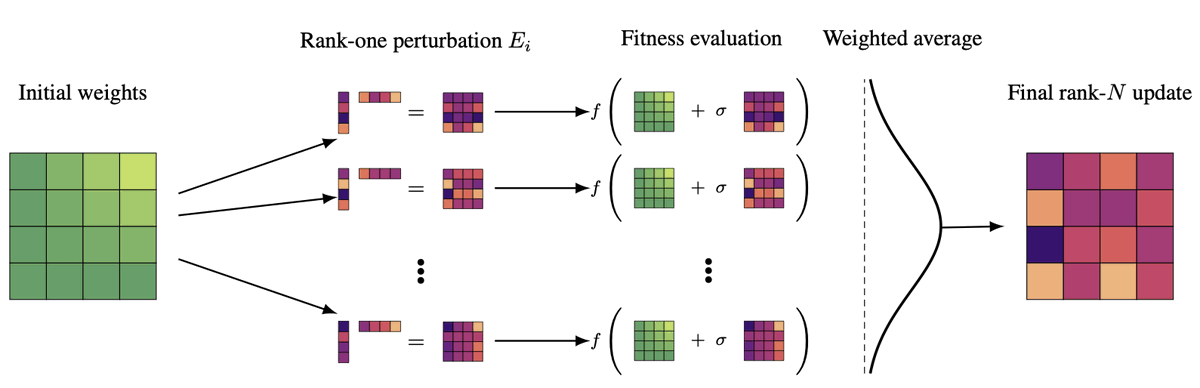
Introducing 🥚EGGROLL 🥚(Evolution Guided General Optimization via Low-rank Learning)! 🚀 Scaling backprop-free Evolution Strategies (ES) for billion-parameter models at large population sizes
⚡100x Training Throughput
🎯Fast Convergence
🔢Pure Int8 Pretraining of RNN LLMs
Hey @MercedesBenz , thought I'd ask, but is it possible to speak to someone who worked on the 722.6's EGS52/53 ECUs back in the early 2000s? - Almost completed reverse engineering the entire ECU, and I'd like to ask a couple questions about its very interesting design choices!
The formulas used in RL papers vs their actual implementation in code and their theoretical meaning is hilarious.
Like the papers will provide the most diabolical equation and it'll just be taking the mean or selecting the top N answers or something
Everything you love about generative models — now powered by real physics!
Announcing the Genesis project — after a 24-month large-scale research collaboration involving over 20 research labs — a generative physics engine able to generate 4D dynamical worlds powered by a physics simulation platform designed for general-purpose robotics and physical AI applications.
Genesis's physics engine is developed in pure Python, while being 10-80x faster than existing GPU-accelerated stacks like Isaac Gym and MJX. It delivers a simulation speed ~430,000 faster than in real-time, and takes only 26 seconds to train a robotic locomotion policy transferrable to the real world on a single RTX4090 (see tutorial: https://t.co/bEkIlCKqdf).
The Genesis physics engine and simulation platform is fully open source at https://t.co/DhBv7NdyqH. We'll gradually roll out access to our generative framework in the near future.
Genesis implements a unified simulation framework all from scratch, integrating a wide spectrum of state-of-the-art physics solvers, allowing simulation of the whole physical world in a virtual realm with the highest realism.
We aim to build a universal data engine that leverages an upper-level generative framework to autonomously create physical worlds, together with various modes of data, including environments, camera motions, robotic task proposals, reward functions, robot policies, character motions, fully interactive 3D scenes, open-world articulated assets, and more, aiming towards fully automated data generation for robotics, physical AI and other applications.
Open Source Code: https://t.co/DhBv7NdyqH
Project webpage: https://t.co/SBNyhFB0yn
Documentation: https://t.co/3yuBoaealV
1/n
Looking for an affordable platform to run popular #genAI models at the edge?
Introducing the NVIDIA Jetson Orin Nano Super Developer Kit, offering up to 67 TOPS of AI performance for $249. Existing users can upgrade their JetPack SDK for a "super" boost. https://t.co/BiTCBke58P